Related Experiment Video
Updated: Mar 15, 2026
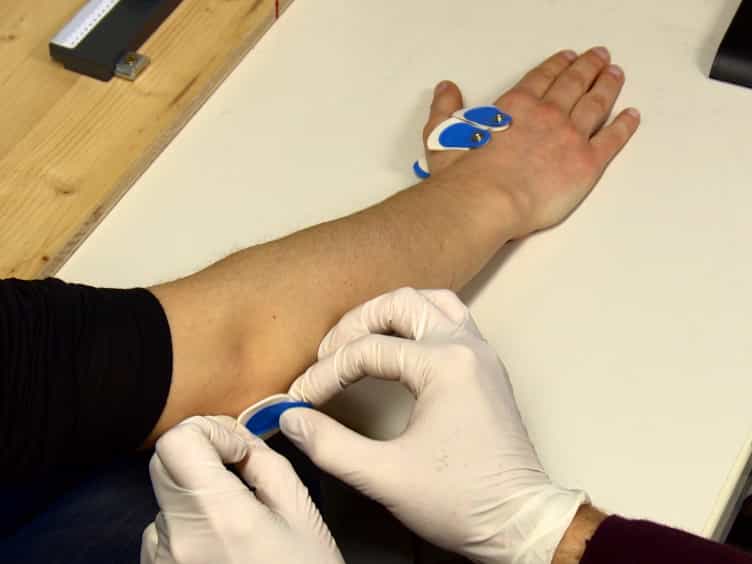
Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Multichannel electrotactile feedback for simultaneous and proportional myoelectric control
Gauravkumar K Patel1, Strahinja Dosen2, Claudio Castellini1
1Institute for Robotics and Mechatronics, German Aerospace Center (DLR), Oberpfaffenhofen Muenchener Str. 20, D-82234 Wessling, Germany.

Objective:
Closing the loop in myoelectric prostheses by providing artificial somatosensory feedback to the user is an important need for prosthetic users. Previous studies investigated feedback strategies in combination with the control of one degree of freedom of simple grippers. Modern hands, however, are sophisticated multifunction systems. In this study, we assessed multichannel electrotactile feedback integrated with an advanced method for the simultaneous and proportional control of individual fingers of a dexterous hand.
Approach:
The feedback used spatial and frequency coding to provide information on the finger positions (normalized flexion angles). A comprehensive set of conditions have been investigated in 28 able-bodied subjects, including feedback modalities (visual, electrotactile and no feedback), control tasks (fingers and grasps), systems (virtual and real hand), control methods (ideal and realistic) and range of motion (low and high). The task for the subjects was to operate the hand using closed-loop myoelectric control and generate the desired movement (e.g., selected finger or grasp at a specific level of closure).
Main Results:
The subjects could perceive the multichannel and multivariable electrotactile feedback and effectively exploit it to improve the control performance with respect to open-loop grasping. The improvement however depended on the reliability of the feedforward control, with less consistent control exhibiting performance trends that were more complex across the conditions.
Significance:
The results are promising for the potential application of advanced feedback to close the control loop in sophisticated prosthetic systems.
More Related Videos
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
 09:14
Surface Electromyographic Biofeedback as a Rehabilitation Tool for Patients with Global Brachial Plexus Injury Receiving Bionic Reconstruction
Published on: September 28, 2019
Related Concept Videos
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...