Related Experiment Video
Updated: Mar 14, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Optimal control of the Lotka-Volterra system: turnpike property and numerical simulations
1a BCAM - Basque Center for Applied Mathematics , Bilbao , Spain.

Abstract:
The Lotka-Volterra model is a differential system of two coupled equations representing the interaction of two species: a prey one and a predator one. We formulate an optimal control problem adding the effect of hunting both species as the control variable. We analyse the optimal hunting problem paying special attention to the nature of the optimal state and control trajectories in long time intervals. To do that, we apply recent theoretical results on the frame to show that, when the time horizon is large enough, optimal strategies are nearly steady-state. Such path is known as turnpike property. Some experiments are performed to observe such turnpike phenomenon in the hunting problem. Based on the turnpike property, we implement a variant of the single shooting method to solve the previous optimisation problem, taking the middle of the time interval as starting point.


Related Concept Videos
 01:19
Root-Locus Method
This system can be represented by a block...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:23
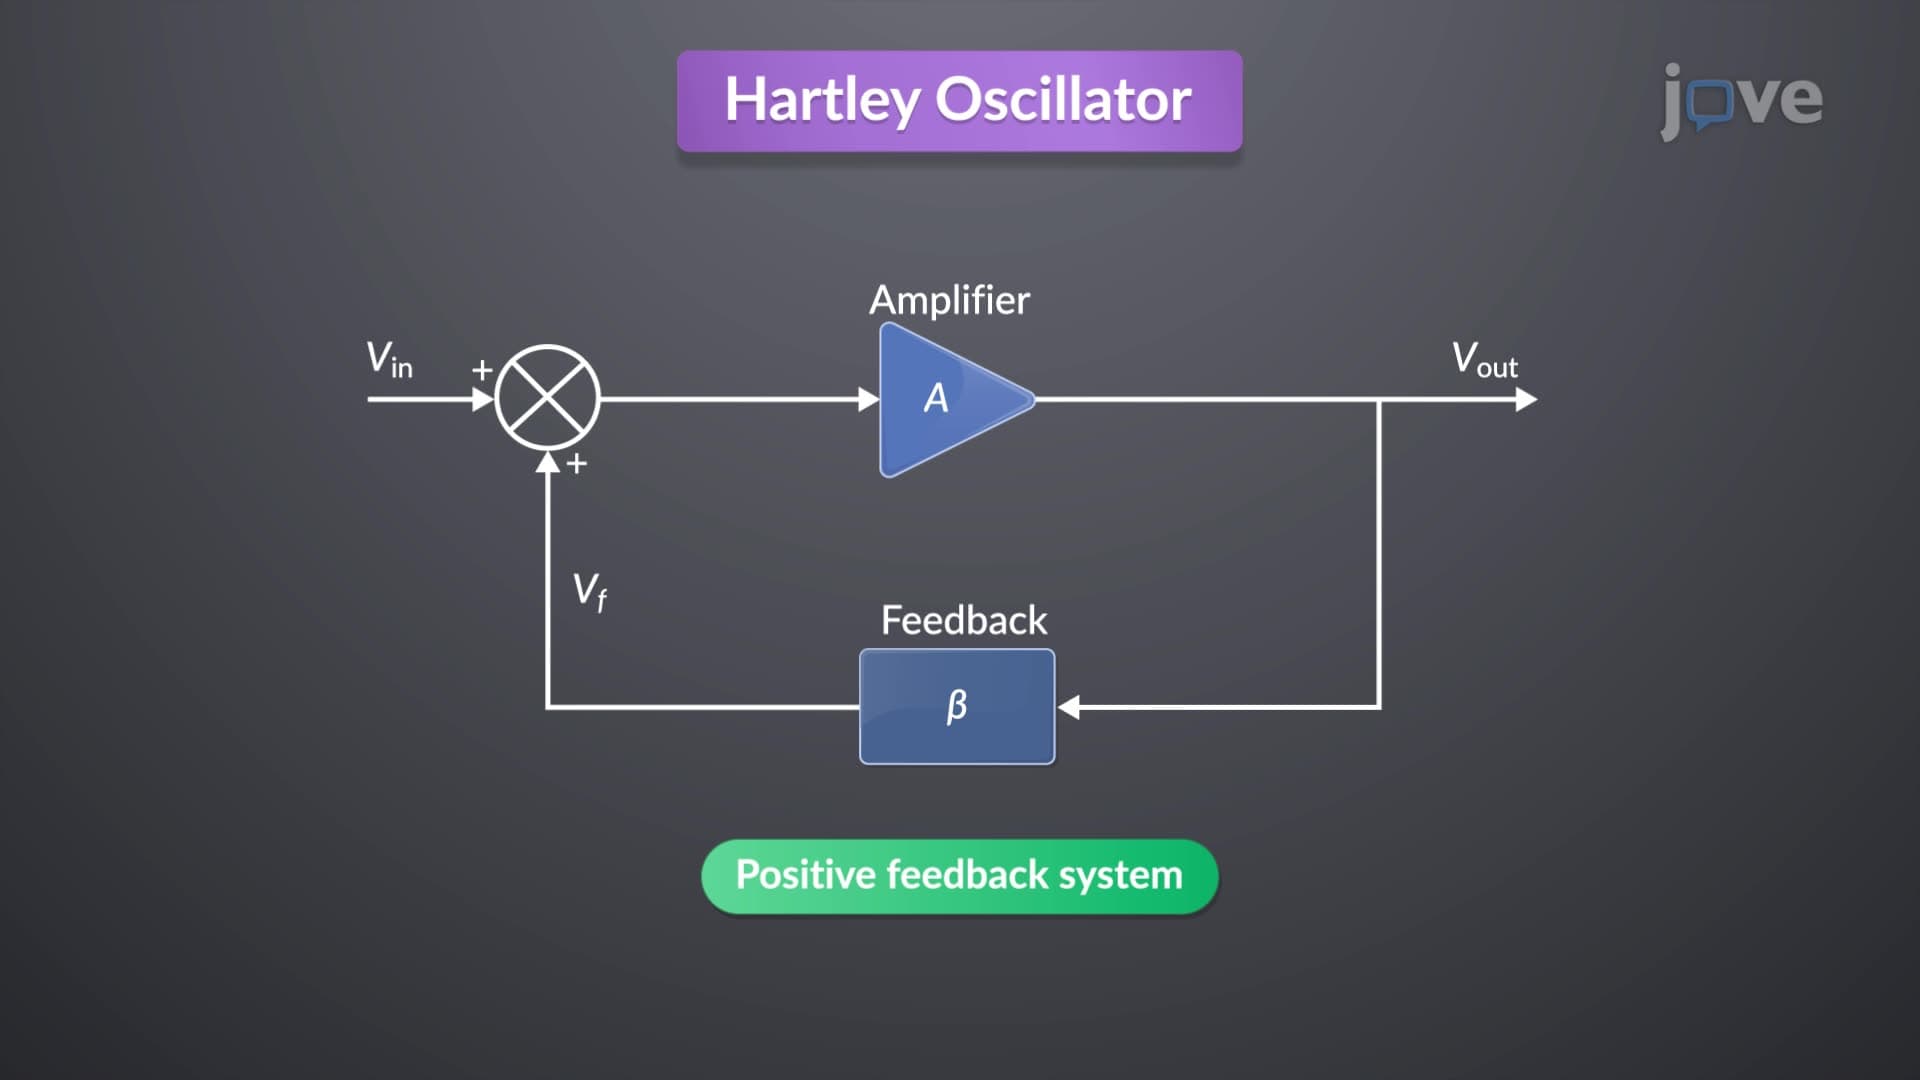
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:19
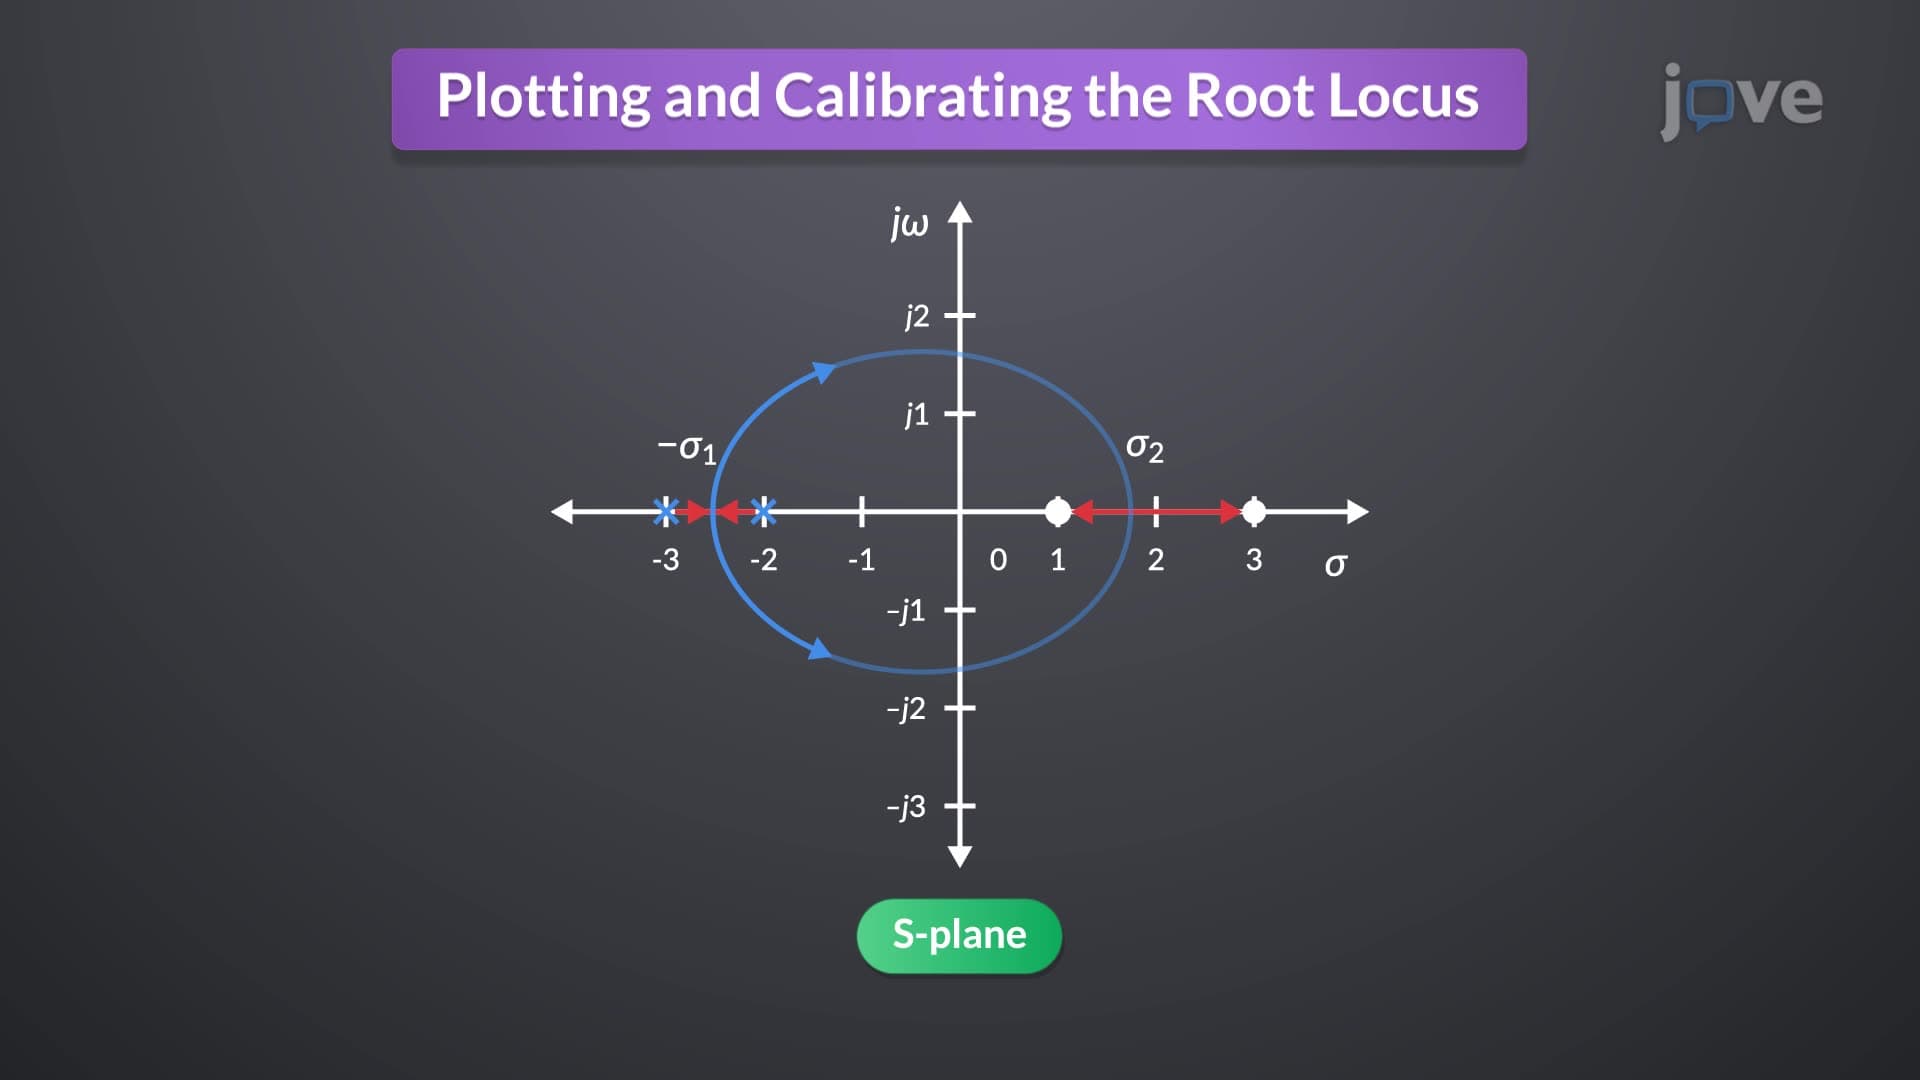
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:21
Differential Equations: Problem Solving