Related Experiment Video
Updated: Mar 14, 2026


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Digit Position and Forces Covary during Anticipatory Control of Whole-Hand Manipulation
Michelle Marneweck1, Trevor Lee-Miller2, Marco Santello3
1Department of Psychological and Brain Sciences, University of California, Santa Barbara Santa Barbara, CA, USA.

Abstract:
Theoretical perspectives on anticipatory planning of object manipulation have traditionally been informed by studies that have investigated kinematics (hand shaping and digit position) and kinetics (forces) in isolation. This poses limitations on our understanding of the integration of such domains, which have recently been shown to be strongly interdependent. Specifically, recent studies revealed strong covariation of digit position and load force during the loading phase of two-digit grasping. Here, we determined whether such digit force-position covariation is a general feature of grasping. We investigated the coordination of digit position and forces during five-digit whole-hand manipulation of an object with a variable mass distribution. Subjects were instructed to prevent object roll during the lift. As found in precision grasping, there was strong trial-to-trial covariation of digit position and force. This suggests that the natural variation of digit position that is compensated for by trial-to-trial variation in digit forces is a fundamental feature of grasp control, and not only specific to precision grasp. However, a main difference with precision grasping was that modulation of digit position to the object's mass distribution was driven predominantly by the thumb, with little to no modulation of finger position. Modulation of thumb position rather than fingers is likely due to its greater range of motion and therefore adaptability to object properties. Our results underscore the flexibility of the central nervous system in implementing a range of solutions along the digit force-to-position continuum for dexterous manipulation.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:10
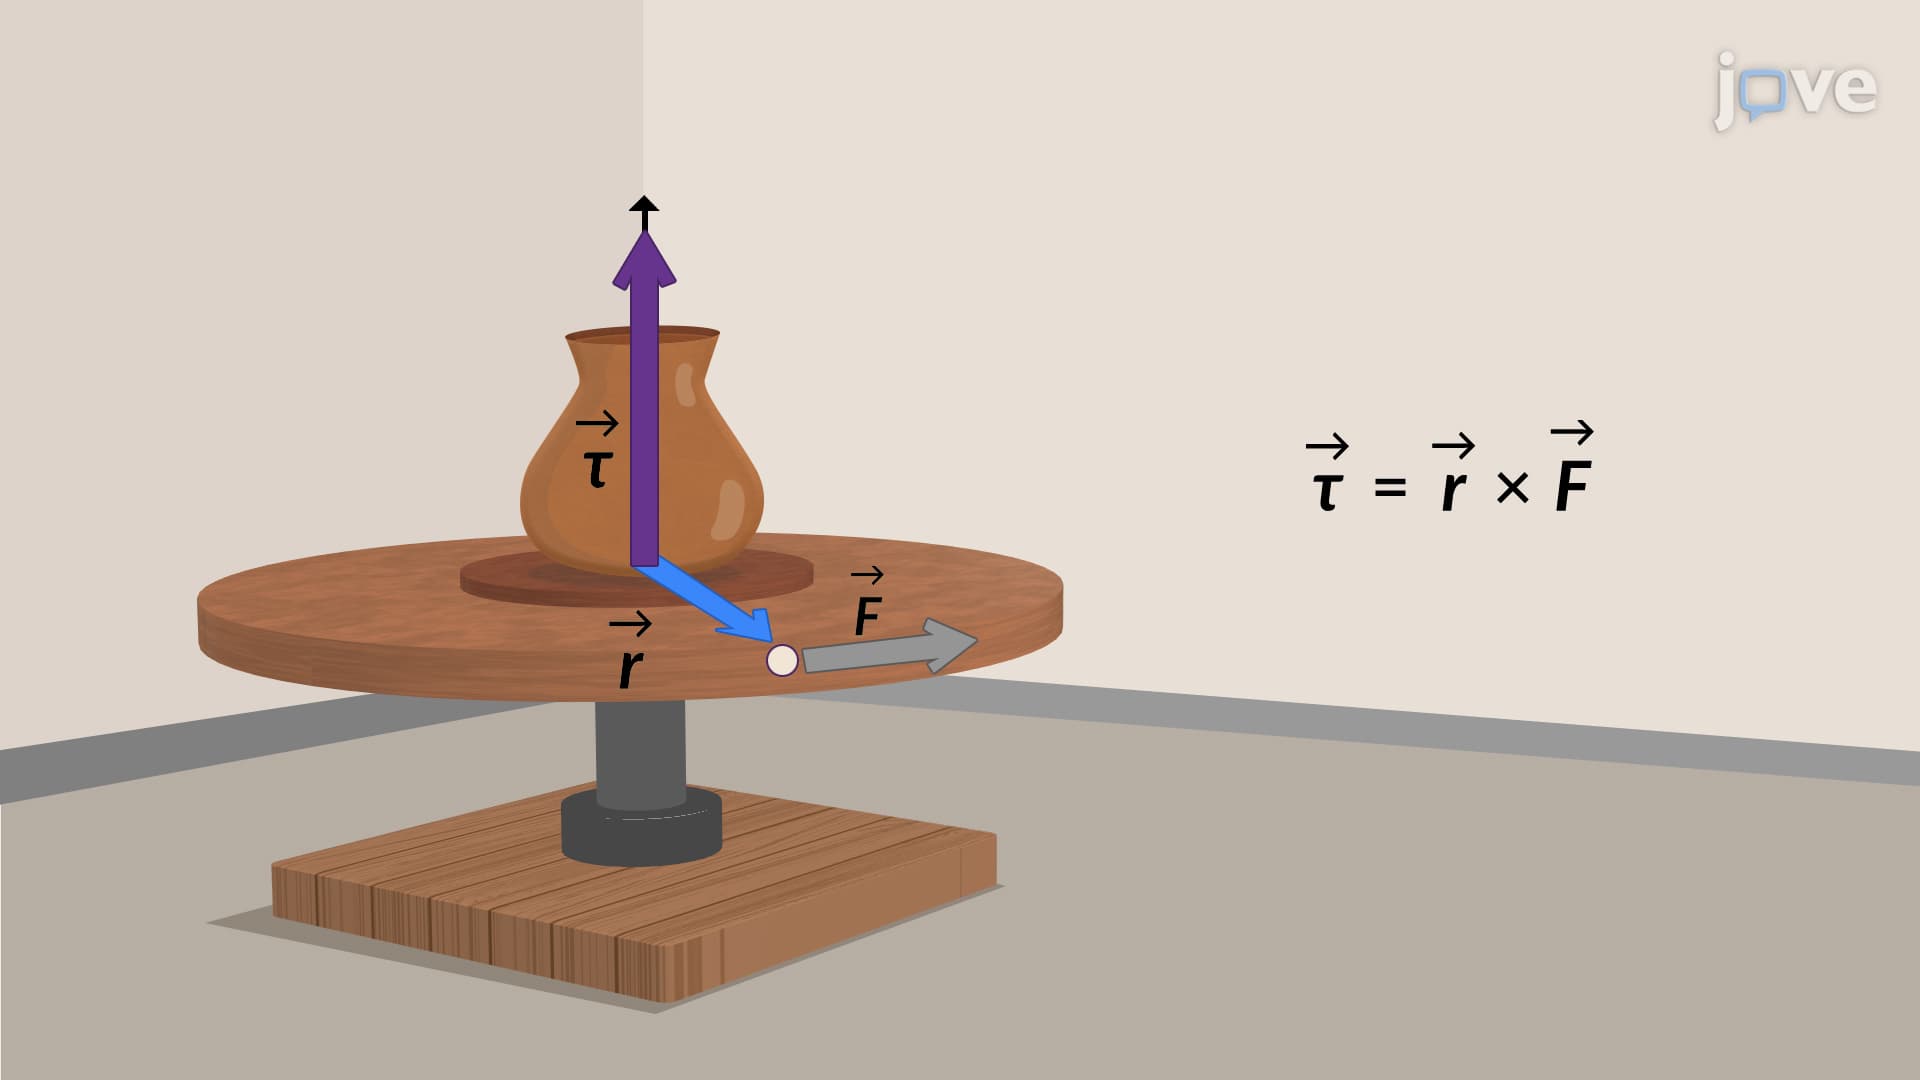
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...