Related Experiment Video
Updated: Mar 14, 2026
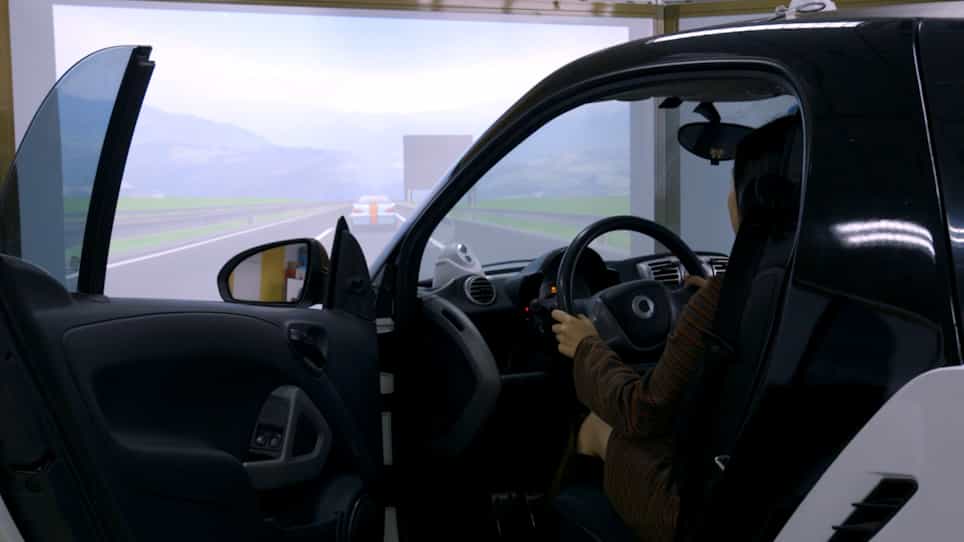
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Evaluation of the impacts of cooperative adaptive cruise control on reducing rear-end collision risks on freeways
1School of Transportation, Southeast University, 2 Si Pai Lou, Nanjing, 210096, PR China.

Abstract:
Although plenty of studies have been conducted recently about the impacts of cooperative adaptive cruise control (CACC) system on traffic efficiency, there are few researches analyzing the safety effects of this advanced driving-assistant system. Thus, the primary objective of this study is to evaluate the impacts of the CACC system on reducing rear-end collision risks on freeways. The CACC model is firstly developed, which is based on the Intelligent Driver Model (IDM). Then, two surrogated safety measures, derived from the time-to-collision (TTC), denoting time exposed time-to-collision (TET) and time integrated time-to-collision (TIT), are introduced for quantifying the collision risks. And the safety effects are analyzed both theoretically and experimentally, by the linear stability analysis and simulations. The theoretical and simulation results conformably indicate that the CACC system brings dramatic benefits for reducing rear-end collision risks (TET and TIT are reduced more than 90%, respectively), when the desired time headway and time delay are set properly. The sensitivity analysis indicates there are few differences among different values of the threshold of TTC and the length of a CACC platoon. The results also show that the safety improvements weaken with the decrease of the penetration rates of CACC on the market and the increase of time delay between platoons. We also evaluate the traffic efficiency of the CACC system with different desired time headway.
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Rolling Resistance: Problem Solving
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:15
Elastic Collisions: Case Study