Related Experiment Video
Updated: Mar 13, 2026

Fabrication and Testing of Microfluidic Optomechanical Oscillators
Published on: May 29, 2014
Dynamics of an optomechanical system with quadratic coupling: Effect of first order correction to adiabatic
Cheng Jiang1,2, Yuanshun Cui1,2, Guibin Chen1,2
1School of Physics and Electronic Electrical Engineering, Huaiyin Normal University, 111 West Chang Jiang Road, Huaian 223300, China.

Abstract:
We explore theoretically the dynamics of an optomechanical system in which a resonantly driven cavity mode is quadratically coupled to the displacement of a mechanical resonator. Considering the first order correction to adiabatic elimination, we obtain the analytical expression of optomechanical damping rate which is negative and depends on the position of the mechanical resonator. After comparing the numerical results between the full simulation of Langevin equations, adiabatic elimination, and first order correction to adiabatic elimination, we explain the dynamics of the system in terms of overall mechanical potential and optomechanical damping rate. The antidamping induced by radiation pressure can result in self-sustained oscillation of the mechanical resonator. Finally, we discuss the time evolution of the intracavity photon number, which also shows that the effect of first order correction cannot be neglected when the ratio of the cavity decay rate to the mechanical resonance frequency becomes smaller than a critical value.
Related Concept Videos
 01:22
Mechanical Systems
 01:18
Second Order systems II
 01:13
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:20
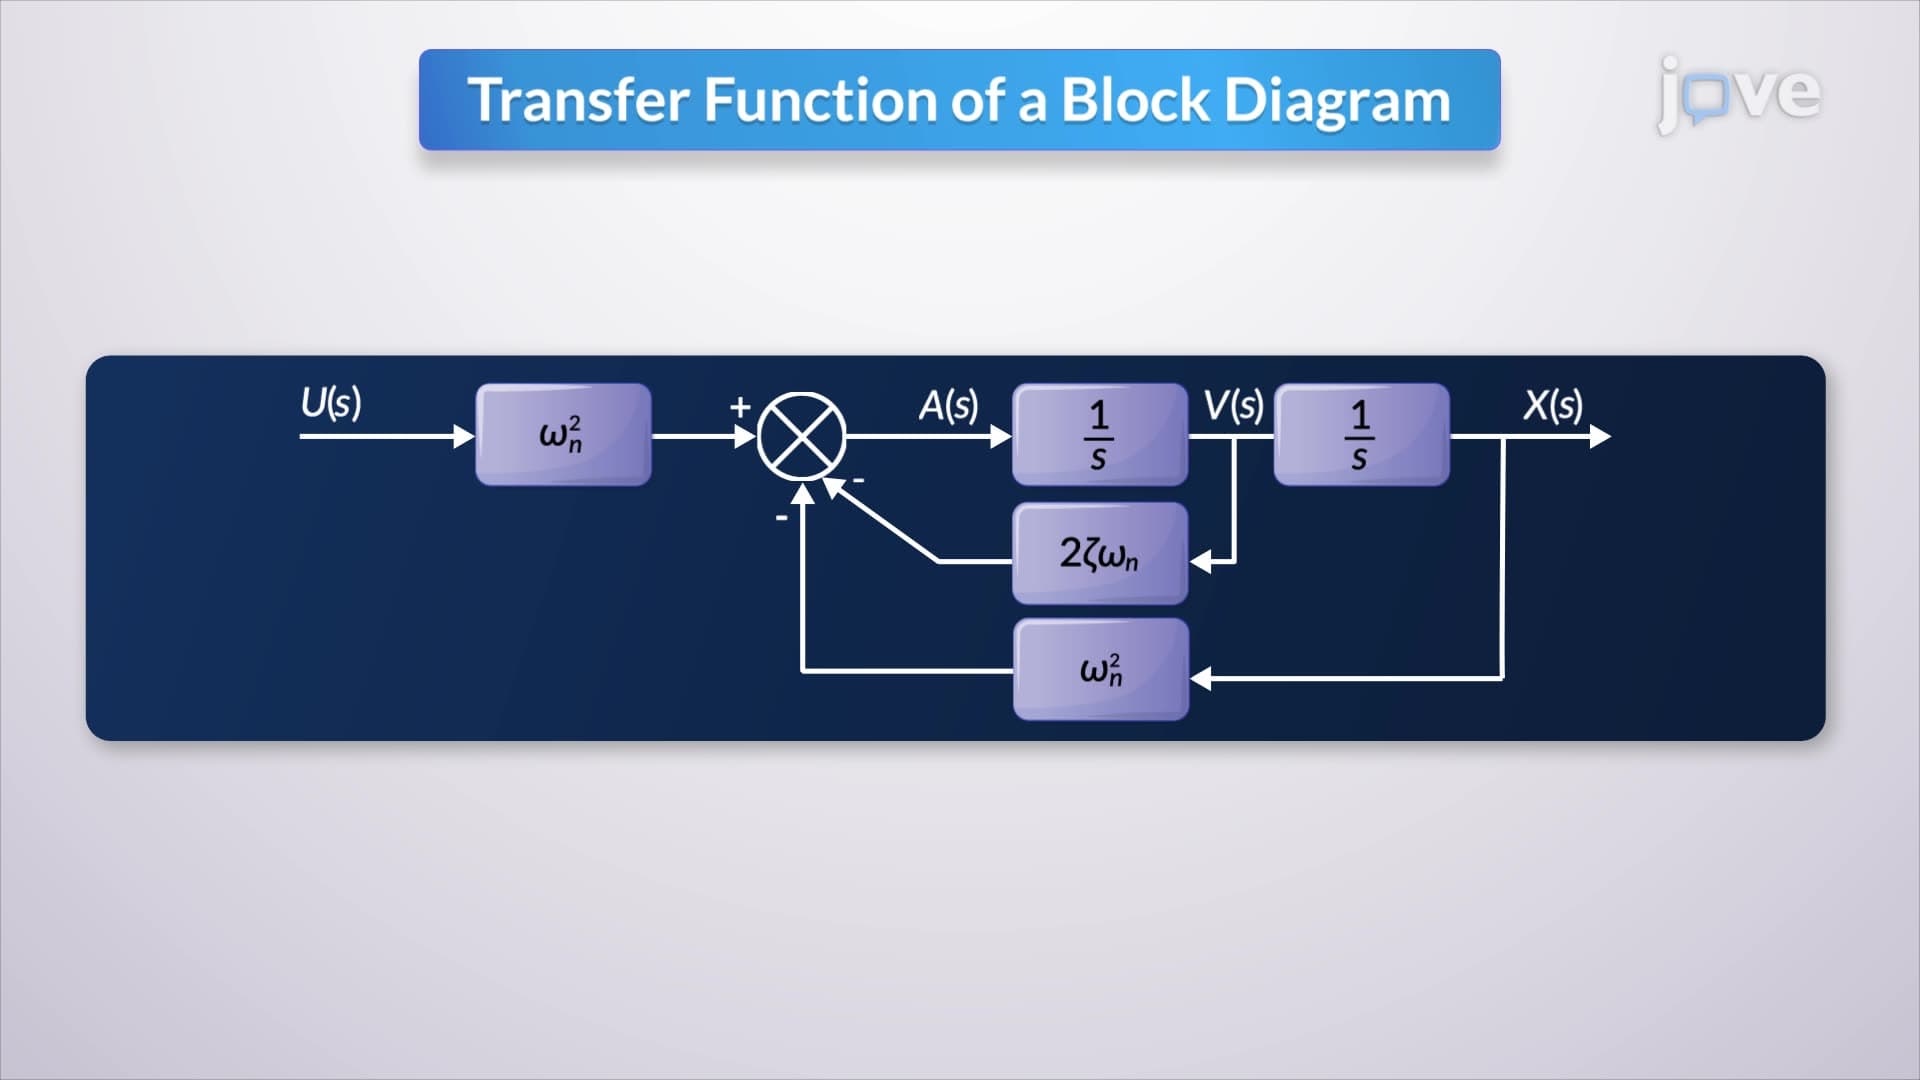
Relation between Mathematical Equations and Block Diagrams
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...