Related Experiment Video
Updated: Mar 13, 2026

Measurement of Dynamic Force Acted on Water Strider Leg Jumping Upward by the PVDF Film Sensor
Published on: August 3, 2018
A water-walking robot mimicking the jumping abilities of water striders
Kai Yang1, Gangfeng Liu, Jihong Yan
1State Key Laboratory of Robotics and Systems, Harbin Institute of Technology, People's Republic of China.

Abstract:
The highly efficient and agile water-surface locomotion of water striders has attracted substantial research attention. Compared with imitating the horizontal rowing motion, imitating the jumping capability of water striders is much more challenging because the strong interaction in the jumping process easily causes the robot to sink. This study focuses on designing a miniature robot capable of continuously jumping on the water surface. A spring-based actuating mechanism is proposed to produce a large jumping force. The center of gravity of the robot is carefully designed to allow the robot to jump on the surface continuously and smoothly. The influences of several critical factors, including the area of the supporting legs, the spring stiffness, the jumping angle, etc on jumping ability are analyzed by means of dynamic simulation and experiments. The jumping performance under different jumping angles is tested. The fabricated robot weighs approximately 10.2 g and can continuously jump on water with a maximum leap height and length of 120 and 410 mm, respectively. This study helps researchers understand the jumping mechanism of water striders and provides a reference for developing water-jumping robots that can perform various aquatic tasks in the future.

Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:16
Hydraulic Jump: Problem Solving
 01:29
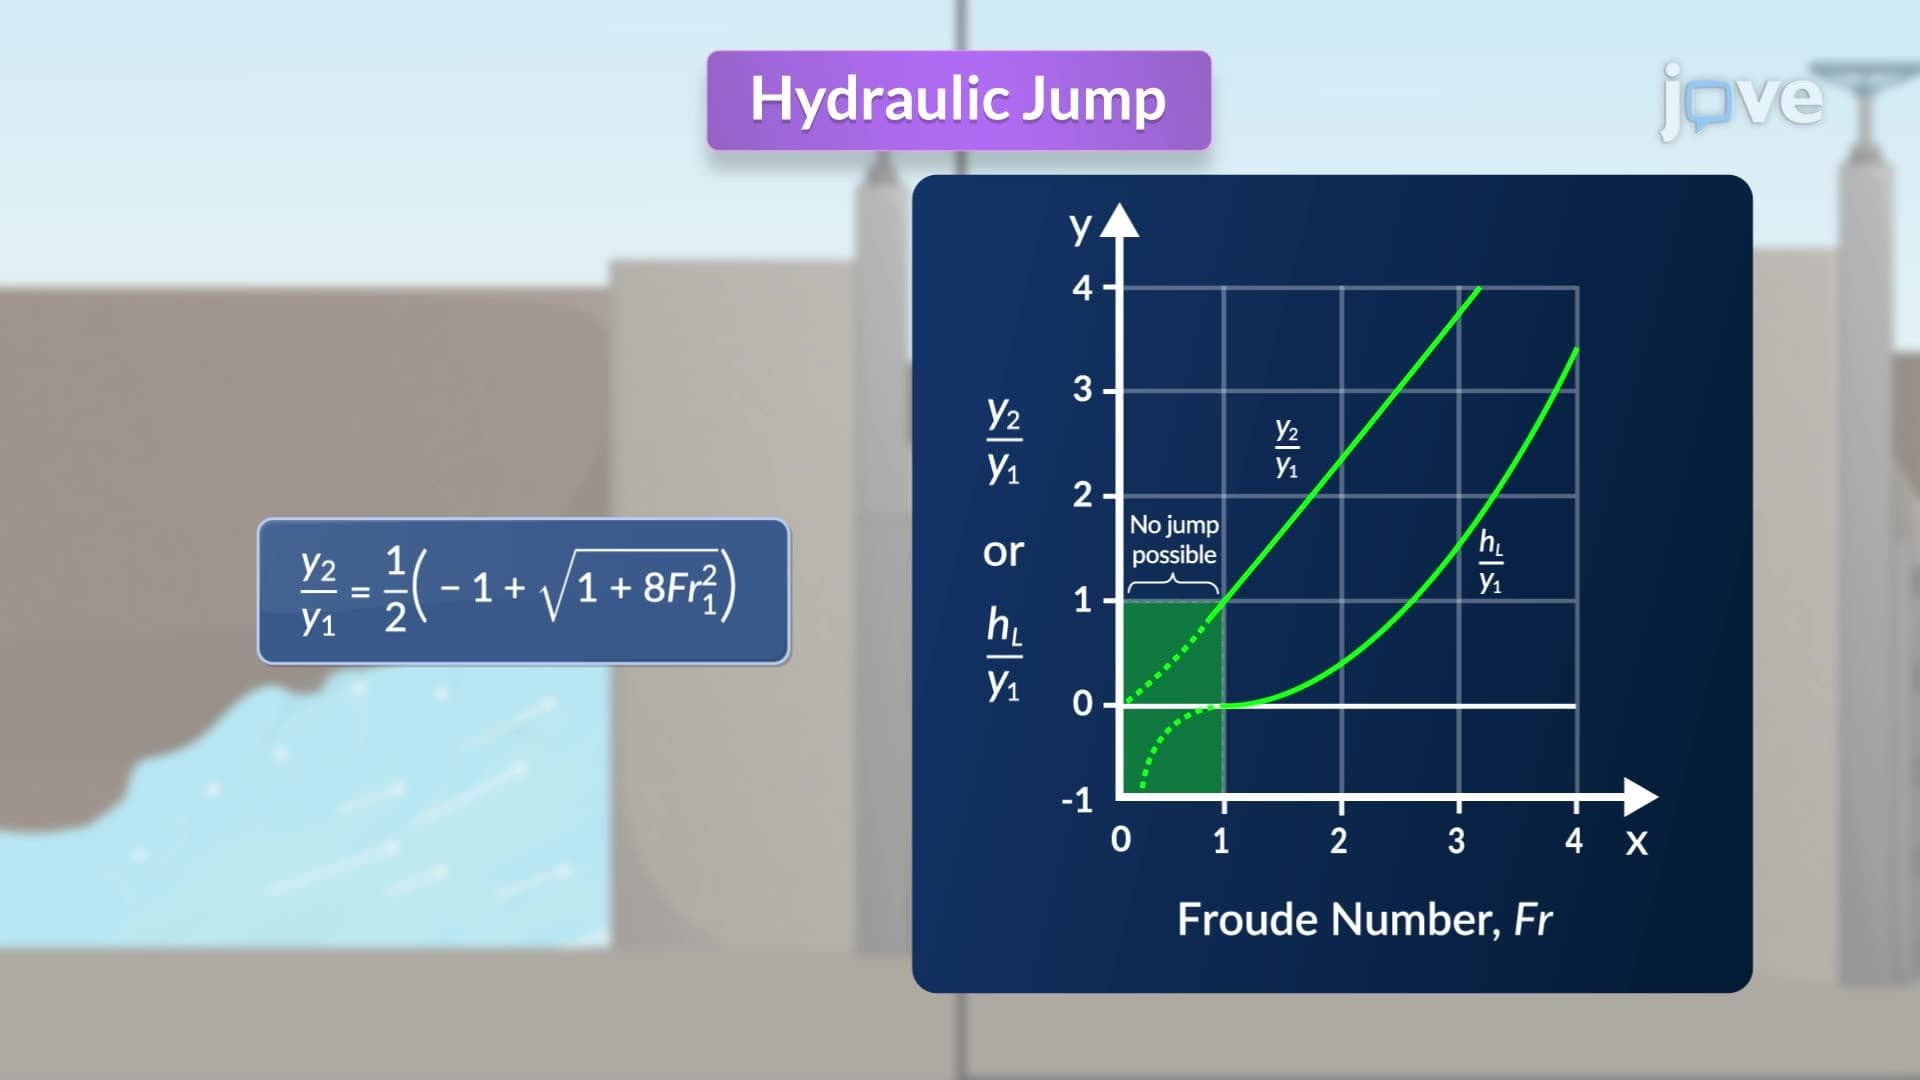
Hydraulic Jump