Related Experiment Video
Updated: Mar 13, 2026


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Bounded-Impedance Absolute Stability of Bilateral Teleoperation Control Systems

Abstract:
Available passivity-based robust stability methods for bilateral teleoperation control systems are generally conservative, as they consider an unbounded range of dynamics for the class of passive operators and environments in the complex plane. In this paper, we introduce a powerful 3D geometrical robust stability analysis method based on the notions of wave variables and scattering parameters. The methodology, which was originally a 2D graphical method used in microwave systems for single-frequency analysis [1], is further developed in this paper for teleoperation and haptic systems. The proposed method provides both mathematical and visual aids to determine bounds or regions on the complex frequency response of the passive environment impedance parameters for which a potentially unstable system connected to any passive operator is stable, and vice-versa. Furthermore, the method allows for the design of bilateral controllers when such bounds are known, or can even be utilized when the environment dynamics are active. The geometrical test can also be replaced by an equivalent mathematical condition, which can easily be checked via a new stability parameter. The proposed method results in less conservative guaranteed stability conditions compared to the Llewellyn's criterion; thus, promising a better compromise between stability and performance. The new method is numerically evaluated for two bilateral control architectures.


Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:28
Stability
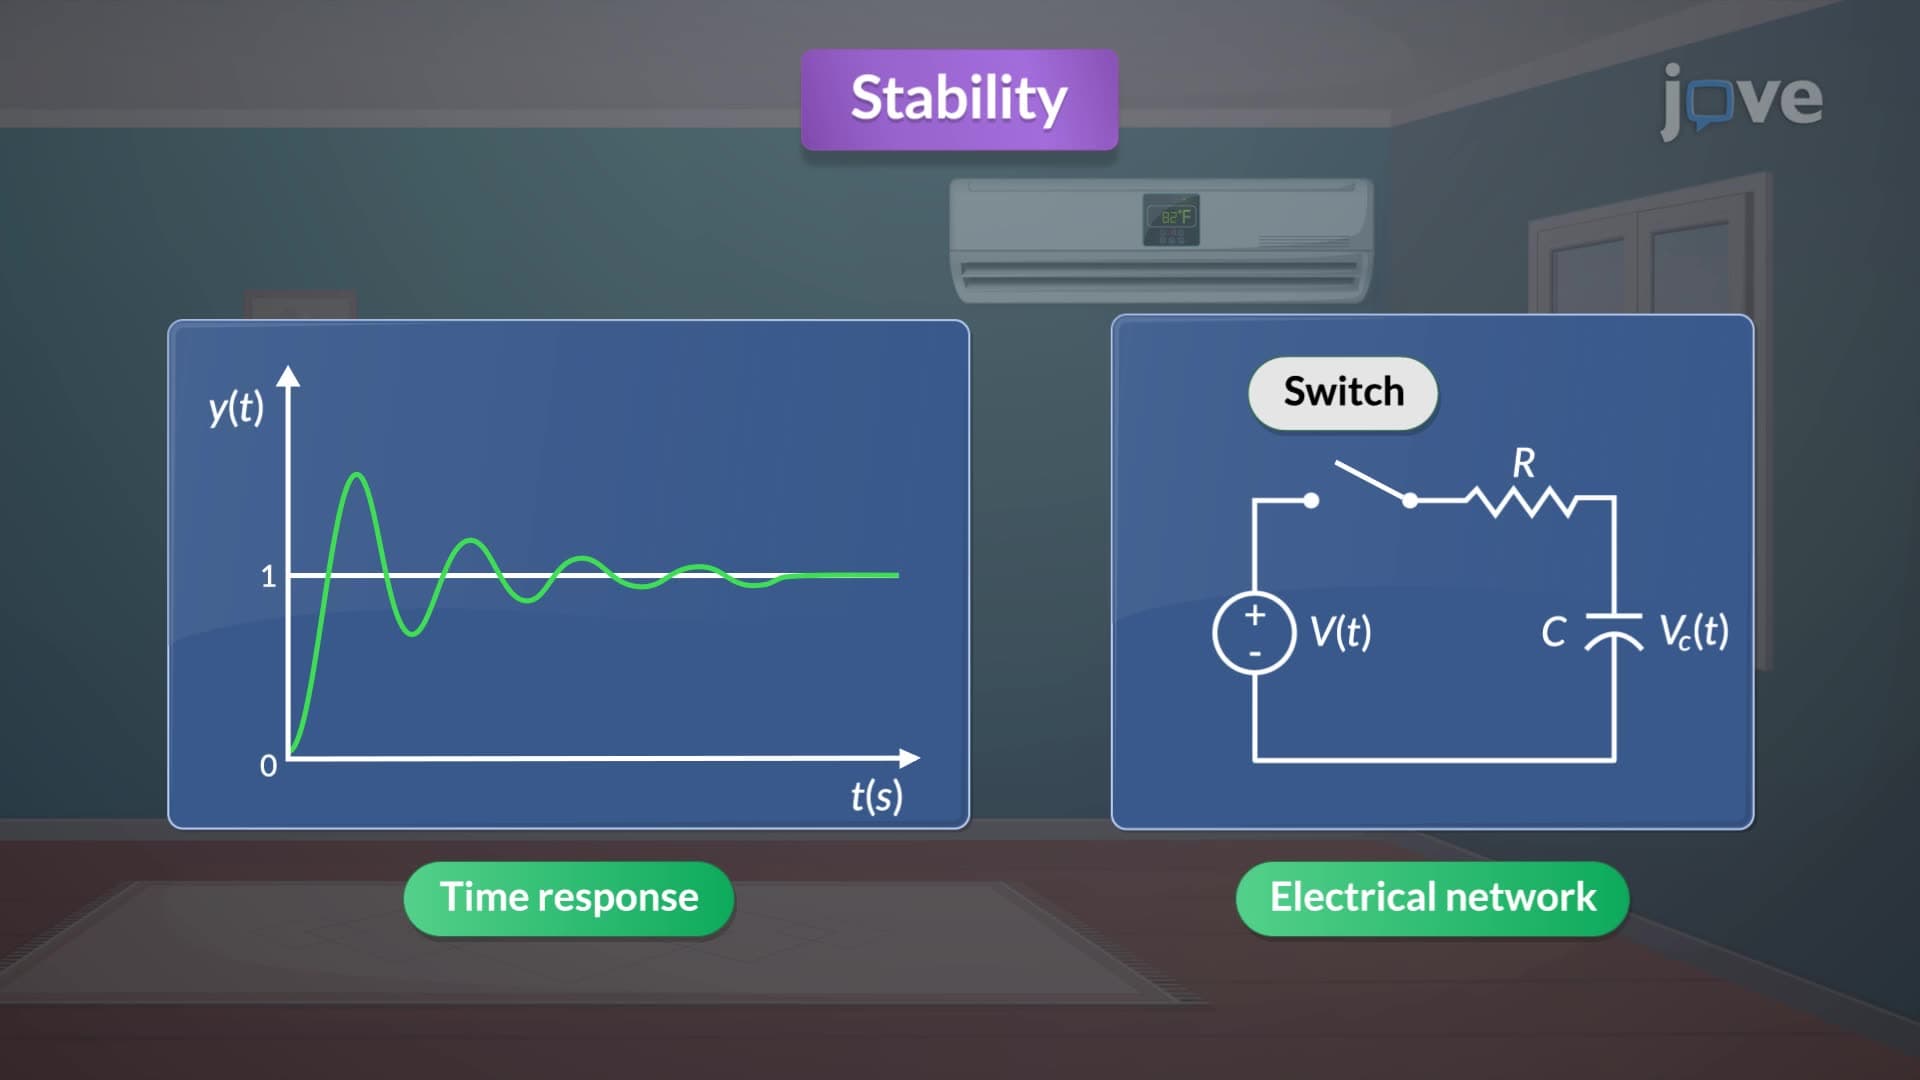
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:10
Control Systems
At the heart...