

Signal Conditioning for the Kalman Filter: Application to Satellite Attitude Estimation with Magnetometer and Sun
Segundo Esteban1, Jose M Girón-Sierra2, Óscar R Polo3
1Department of Computer Architecture and Automatic Control, Faculty of Physic Sciences, Complutense University of Madrid, Madrid 28040, Spain. segundo@dacya.ucm.es.

Abstract:
Most satellites use an on-board attitude estimation system, based on available sensors. In the case of low-cost satellites, which are of increasing interest, it is usual to use magnetometers and Sun sensors. A Kalman filter is commonly recommended for the estimation, to simultaneously exploit the information from sensors and from a mathematical model of the satellite motion. It would be also convenient to adhere to a quaternion representation. This article focuses on some problems linked to this context. The state of the system should be represented in observable form. Singularities due to alignment of measured vectors cause estimation problems. Accommodation of the Kalman filter originates convergence difficulties. The article includes a new proposal that solves these problems, not needing changes in the Kalman filter algorithm. In addition, the article includes assessment of different errors, initialization values for the Kalman filter; and considers the influence of the magnetic dipole moment perturbation, showing how to handle it as part of the Kalman filter framework.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 07:47
Assessing the Influence of Personality on Sensitivity to Magnetic Fields in Zebrafish
Published on: March 18, 2019
Related Concept Videos
 01:28
Magnetostatic Boundary Conditions
 01:19
Magnetic Declination
 01:22
Local Attraction
 01:24
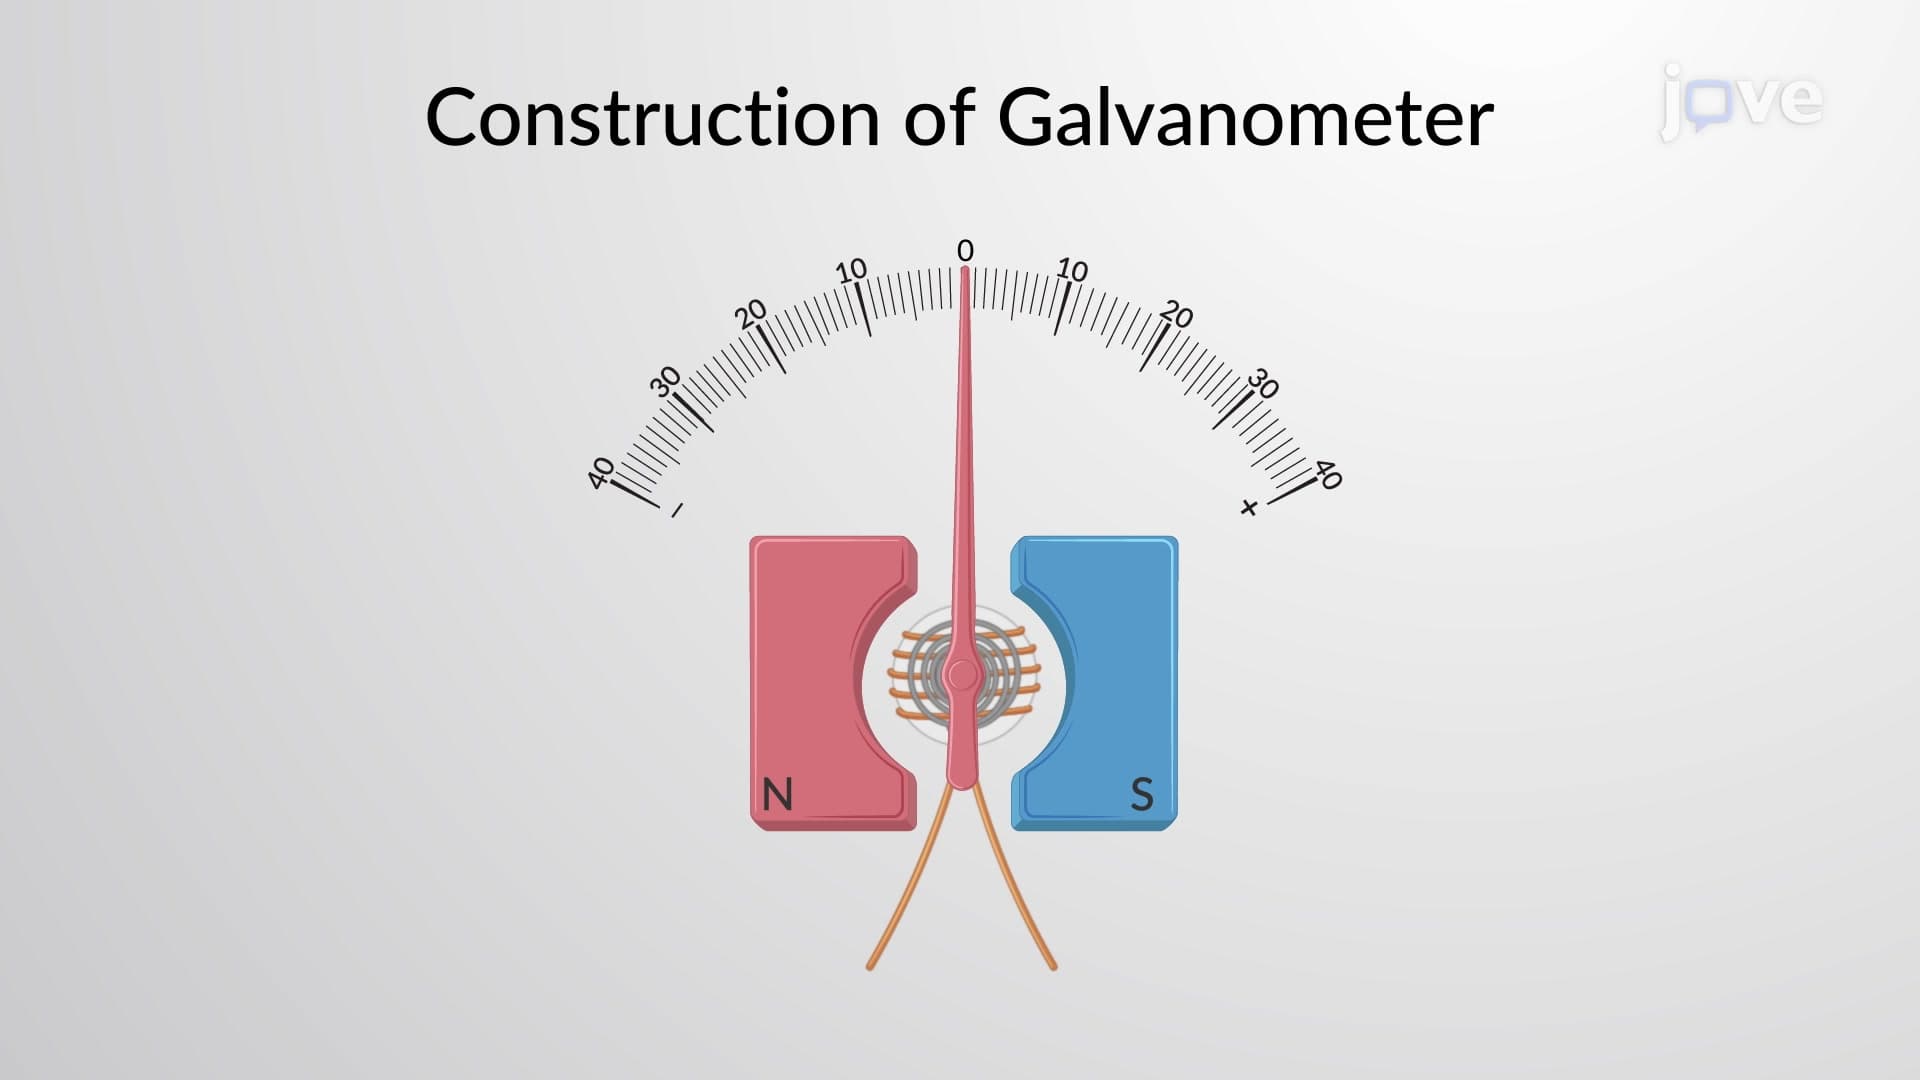
Galvanometer
The galvanometer consists of two concave-shaped permanent magnets, providing a uniform radial magnetic field in the annular region. In the center, a pivoted coil of fine copper wire is placed in the uniform...
 01:29
Application of Linearization and Approximation
 01:26
Errors in Global Positioning System