Affine differential geometry and smoothness maximization as tools for identifying geometric movement primitives
Related Experiment Video
Updated: Mar 12, 2026

Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
1Department of Mathematics, Ariel University, Ariel, Israel. write.to.felixp@gmail.com.

Abstract:
Neuroscientific studies of drawing-like movements usually analyze neural representation of either geometric (e.g., direction, shape) or temporal (e.g., speed) parameters of trajectories rather than trajectory's representation as a whole. This work is about identifying geometric building blocks of movements by unifying different empirically supported mathematical descriptions that characterize relationship between geometric and temporal aspects of biological motion. Movement primitives supposedly facilitate the efficiency of movements' representation in the brain and comply with such criteria for biological movements as kinematic smoothness and geometric constraint. The minimum-jerk model formalizes criterion for trajectories' maximal smoothness of order 3. I derive a class of differential equations obeyed by movement paths whose nth-order maximally smooth trajectories accumulate path measurement with constant rate. Constant rate of accumulating equi-affine arc complies with the 2/3 power-law model. Candidate primitive shapes identified as equations' solutions for arcs in different geometries in plane and in space are presented. Connection between geometric invariance, motion smoothness, compositionality and performance of the compromised motor control system is proposed within single invariance-smoothness framework. The derived class of differential equations is a novel tool for discovering candidates for geometric movement primitives.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
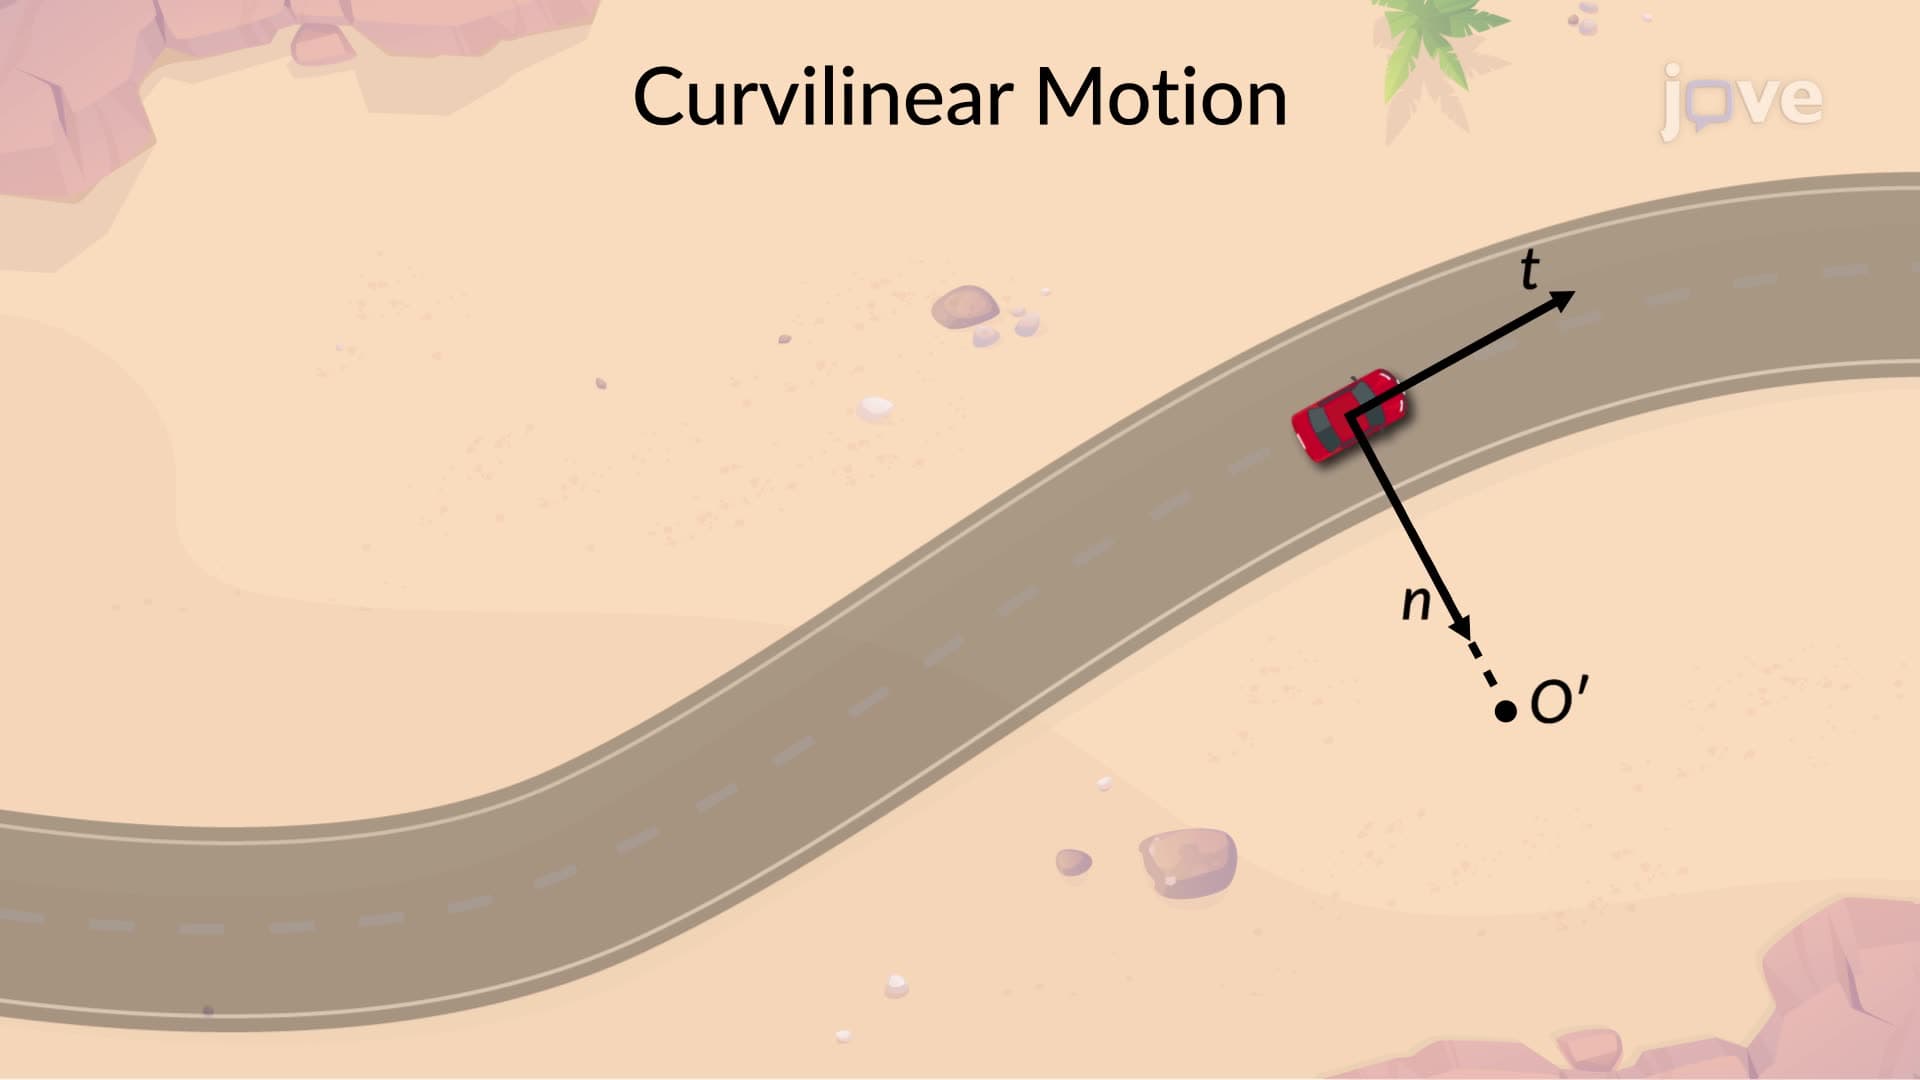
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:21
Plastic Deformations of Members with a Single Plane of Symmetry
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...