Shape Distributions of Nonlinear Dynamical Systems for Video-Based Inference
Related Experiment Video
Updated: Mar 12, 2026
Dynamic Digital Biomarkers of Motor and Cognitive Function in Parkinson's Disease
Published on: July 24, 2019

Abstract:
This paper presents a shape-theoretic framework for dynamical analysis of nonlinear dynamical systems which appear frequently in several video-based inference tasks. Traditional approaches to dynamical modeling have included linear and nonlinear methods with their respective drawbacks. A novel approach we propose is the use of descriptors of the shape of the dynamical attractor as a feature representation of nature of dynamics. The proposed framework has two main advantages over traditional approaches: a) representation of the dynamical system is derived directly from the observational data, without any inherent assumptions, and b) the proposed features show stability under different time-series lengths where traditional dynamical invariants fail. We illustrate our idea using nonlinear dynamical models such as Lorenz and Rossler systems, where our feature representations (shape distribution) support our hypothesis that the local shape of the reconstructed phase space can be used as a discriminative feature. Our experimental analyses on these models also indicate that the proposed framework show stability for different time-series lengths, which is useful when the available number of samples are small/variable. The specific applications of interest in this paper are: 1) activity recognition using motion capture and RGBD sensors, 2) activity quality assessment for applications in stroke rehabilitation, and 3) dynamical scene classification. We provide experimental validation through action and gesture recognition experiments on motion capture and Kinect datasets. In all these scenarios, we show experimental evidence of the favorable properties of the proposed representation.

Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
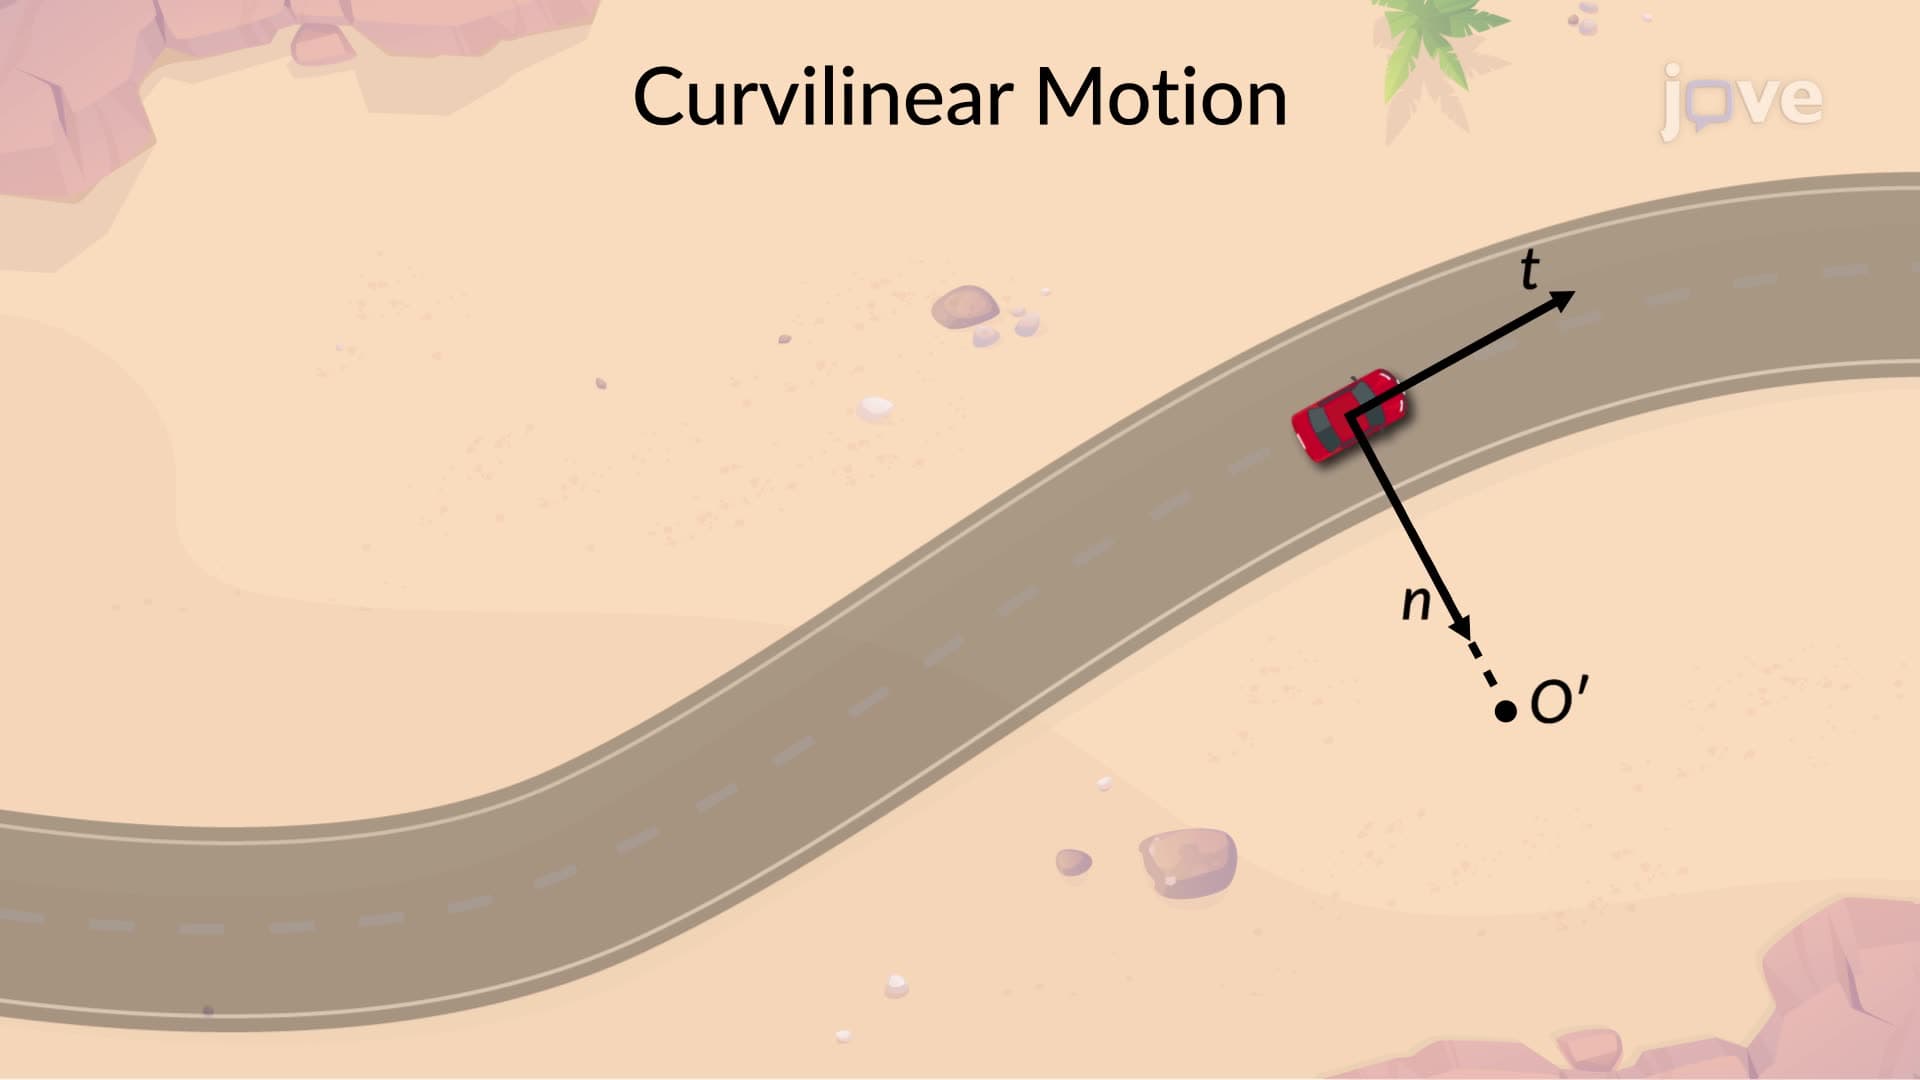
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:29
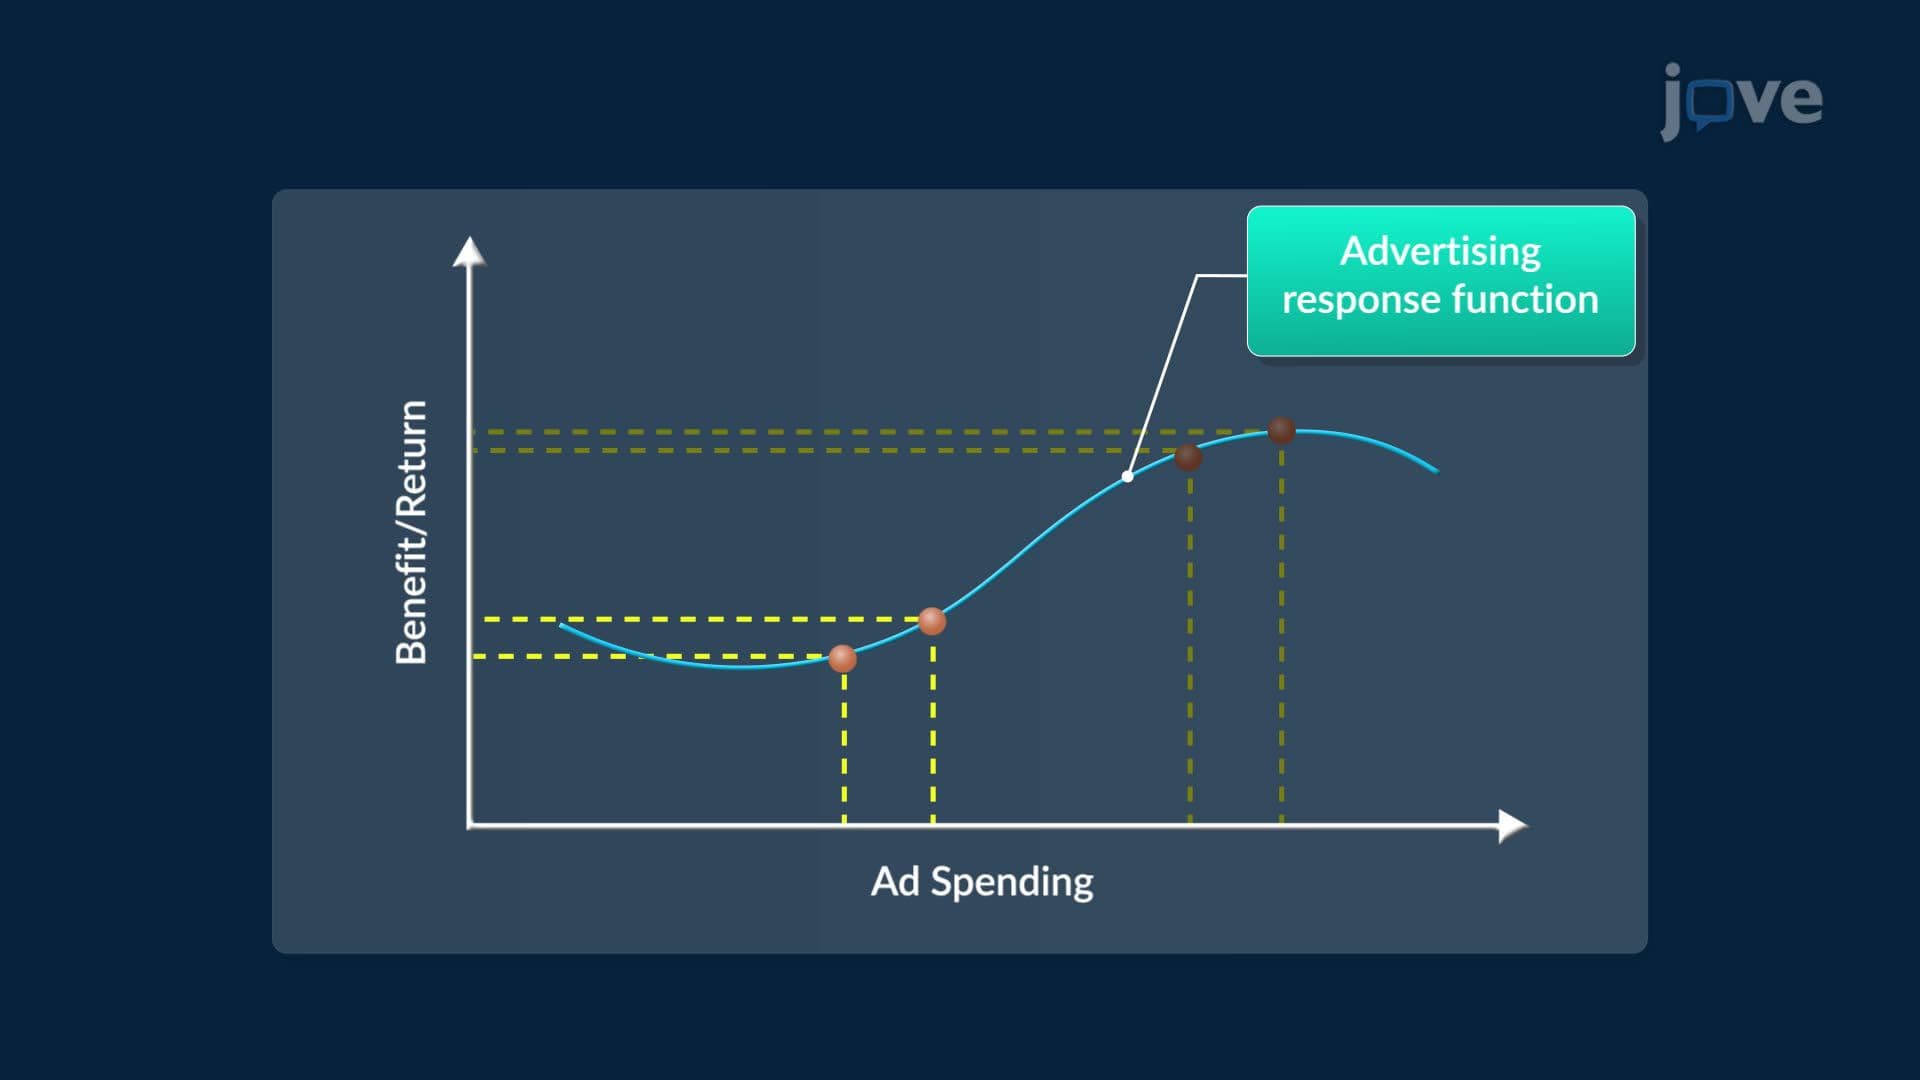
Second Derivatives and the Shape of a Graph
 01:21
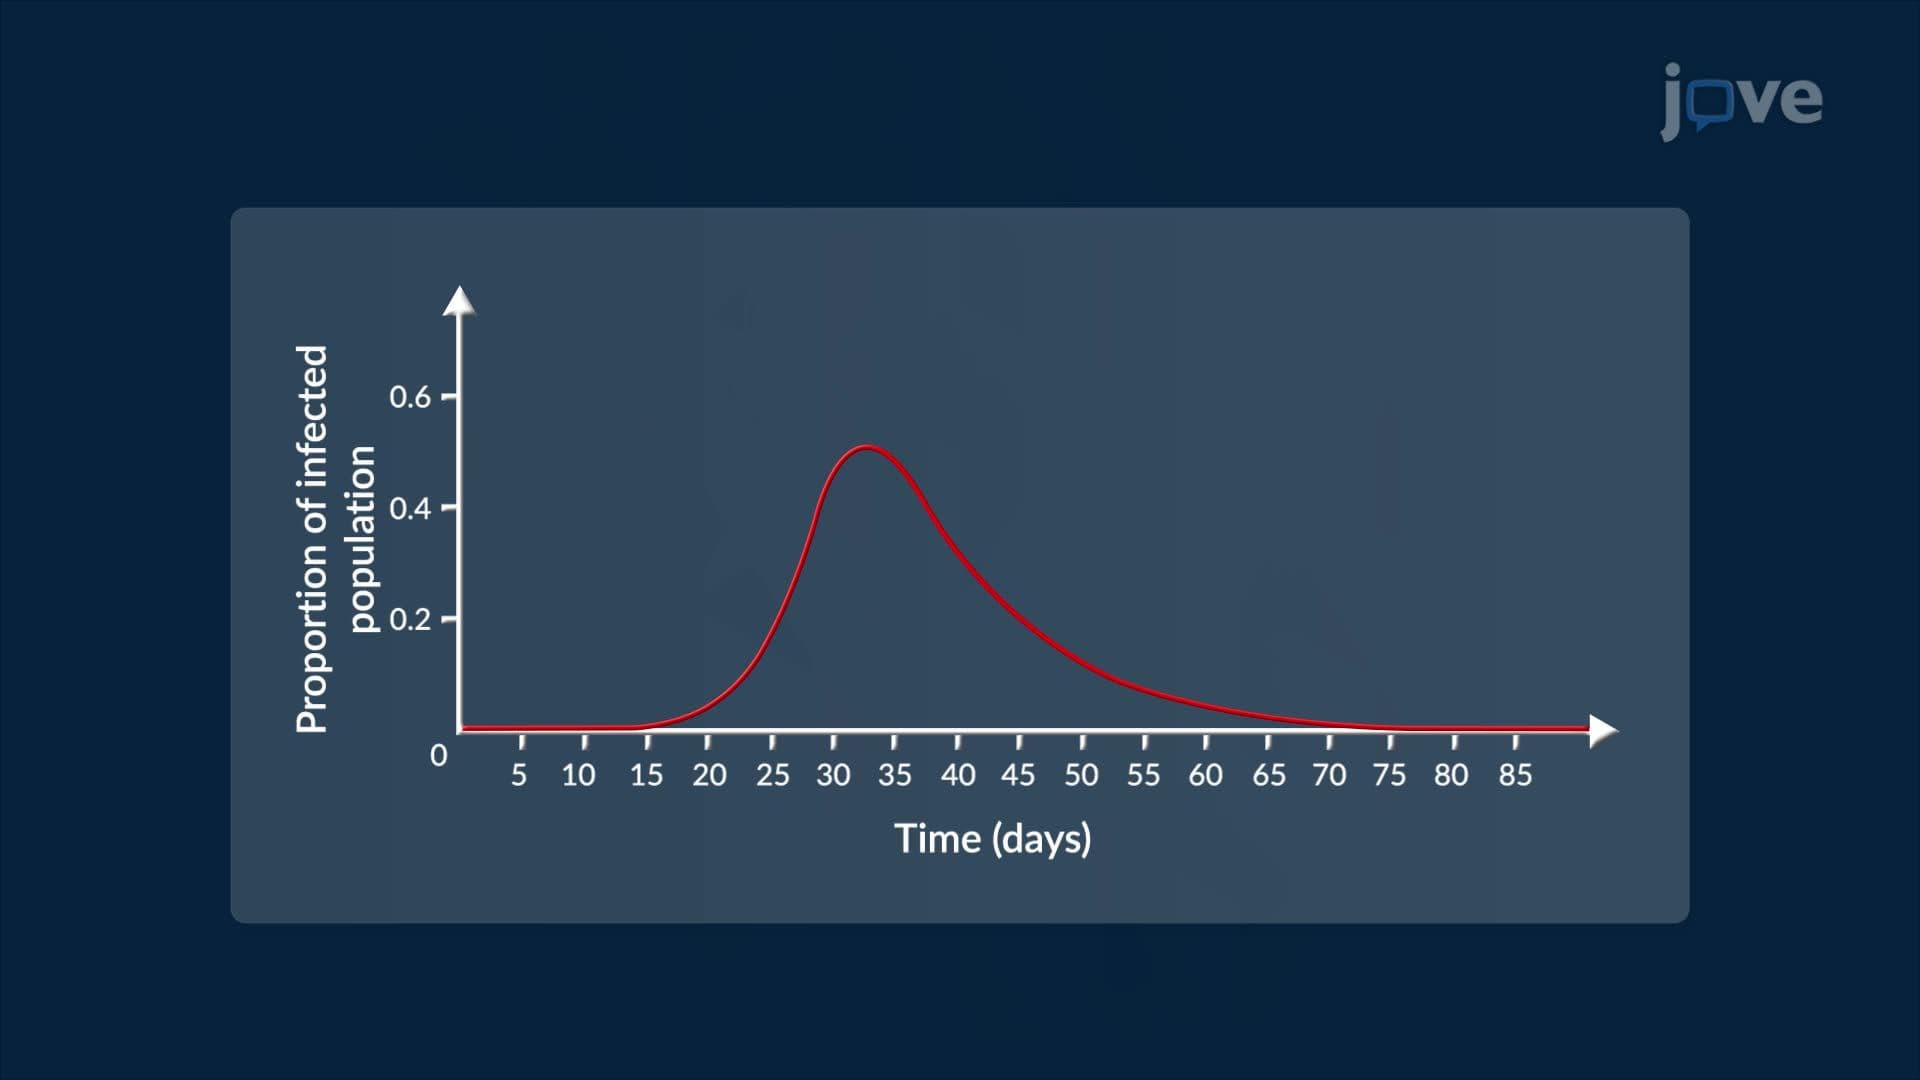
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:22
First Derivatives and the Shape of a Graph
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...