Determination Method of Bridge Rotation Angle Response Using MEMS IMU
Related Experiment Video
Updated: Mar 12, 2026
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Hidehiko Sekiya1, Takeshi Kinomoto2, Chitoshi Miki3
1Advanced Research Laboratories, Tokyo City University, 8-15-1 Todoroki, Setagaya 158-0082, Japan. hsekiya@tcu.ac.jp.

Abstract:
To implement steel bridge maintenance, especially that related to fatigue damage, it is important to monitor bridge deformations under traffic conditions. Bridges deform and rotate differently under traffic load conditions because their structures differ in terms of length and flexibility. Such monitoring enables the identification of the cause of stress concentrations that cause fatigue damage and the proposal of appropriate countermeasures. However, although bridge deformation monitoring requires observations of bridge angle response as well as the bridge displacement response, measuring the rotation angle response of a bridge subject to traffic loads is difficult. Theoretically, the rotation angle response can be calculated by integrating the angular velocity, but for field measurements of actual in-service bridges, estimating the necessary boundary conditions would be difficult due to traffic-induced vibration. To solve the problem, this paper proposes a method for determining the rotation angle response of an in-service bridge from its angular velocity, as measured by a inertial measurement unit (IMU). To verify our proposed method, field measurements were conducted using nine micro-electrical mechanical systems (MEMS) IMUs and two contact displacement gauges. The results showed that our proposed method provided high accuracy when compared to the reference responses calculated by the contact displacement gauges.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:13
Angle of Twist: Problem Solving
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:37
Rotation with Constant Angular Acceleration - I
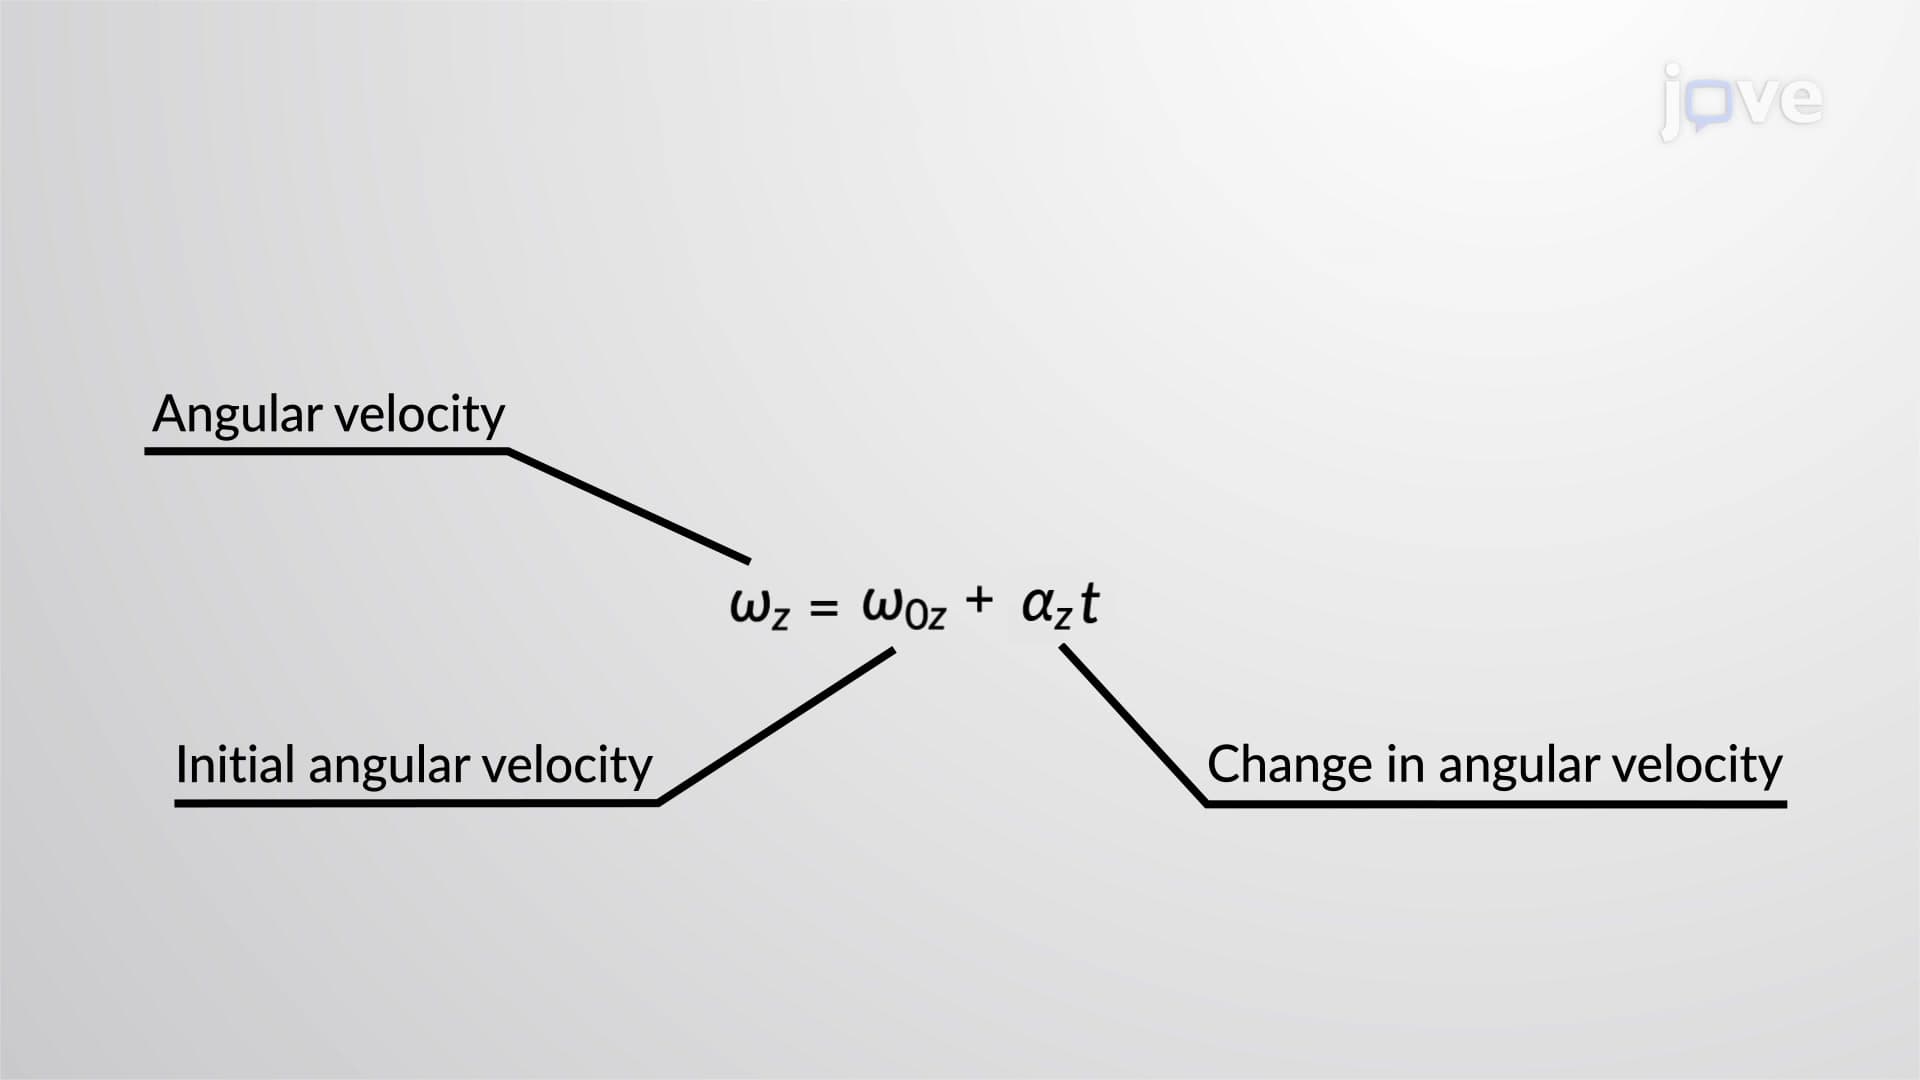
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:19
Euler Equations of Motion