Related Experiment Video
Updated: Mar 11, 2026

Magnetic Tweezers for the Measurement of Twist and Torque
Published on: May 19, 2014
An Integrated MEMS Gyroscope Array with Higher Accuracy Output
Honglong Chang1, Liang Xue2, Wei Qin2
1Micro and Nano Electro Mechanical System Laboratory, Northwestern Polytechnical University, Xi'an City, Shaanxi Province, P. R. China, 710072. changhl@nwpu.edu.cn.

Abstract:
In this paper, an integrated MEMS gyroscope array method composed of two levels of optimal filtering was designed to improve the accuracy of gyroscopes. In the firstlevel filtering, several identical gyroscopes were combined through Kalman filtering into a single effective device, whose performance could surpass that of any individual sensor. The key of the performance improving lies in the optimal estimation of the random noise sources such as rate random walk and angular random walk for compensating the measurement values. Especially, the cross correlation between the noises from different gyroscopes of the same type was used to establish the system noise covariance matrix and the measurement noise covariance matrix for Kalman filtering to improve the performance further. Secondly, an integrated Kalman filter with six states was designed to further improve the accuracy with the aid of external sensors such as magnetometers and accelerometers in attitude determination. Experiments showed that three gyroscopes with a bias drift of 35 degree per hour could be combined into a virtual gyroscope with a drift of 1.07 degree per hour through the first-level filter, and the bias drift was reduced to 0.53 degree per hour after the second-level filtering. It proved that the proposed integrated MEMS gyroscope array is capable of improving the accuracy of the MEMS gyroscopes, which provides the possibility of using these low cost MEMS sensors in high-accuracy application areas.
Related Concept Videos
 01:02
Gyroscope
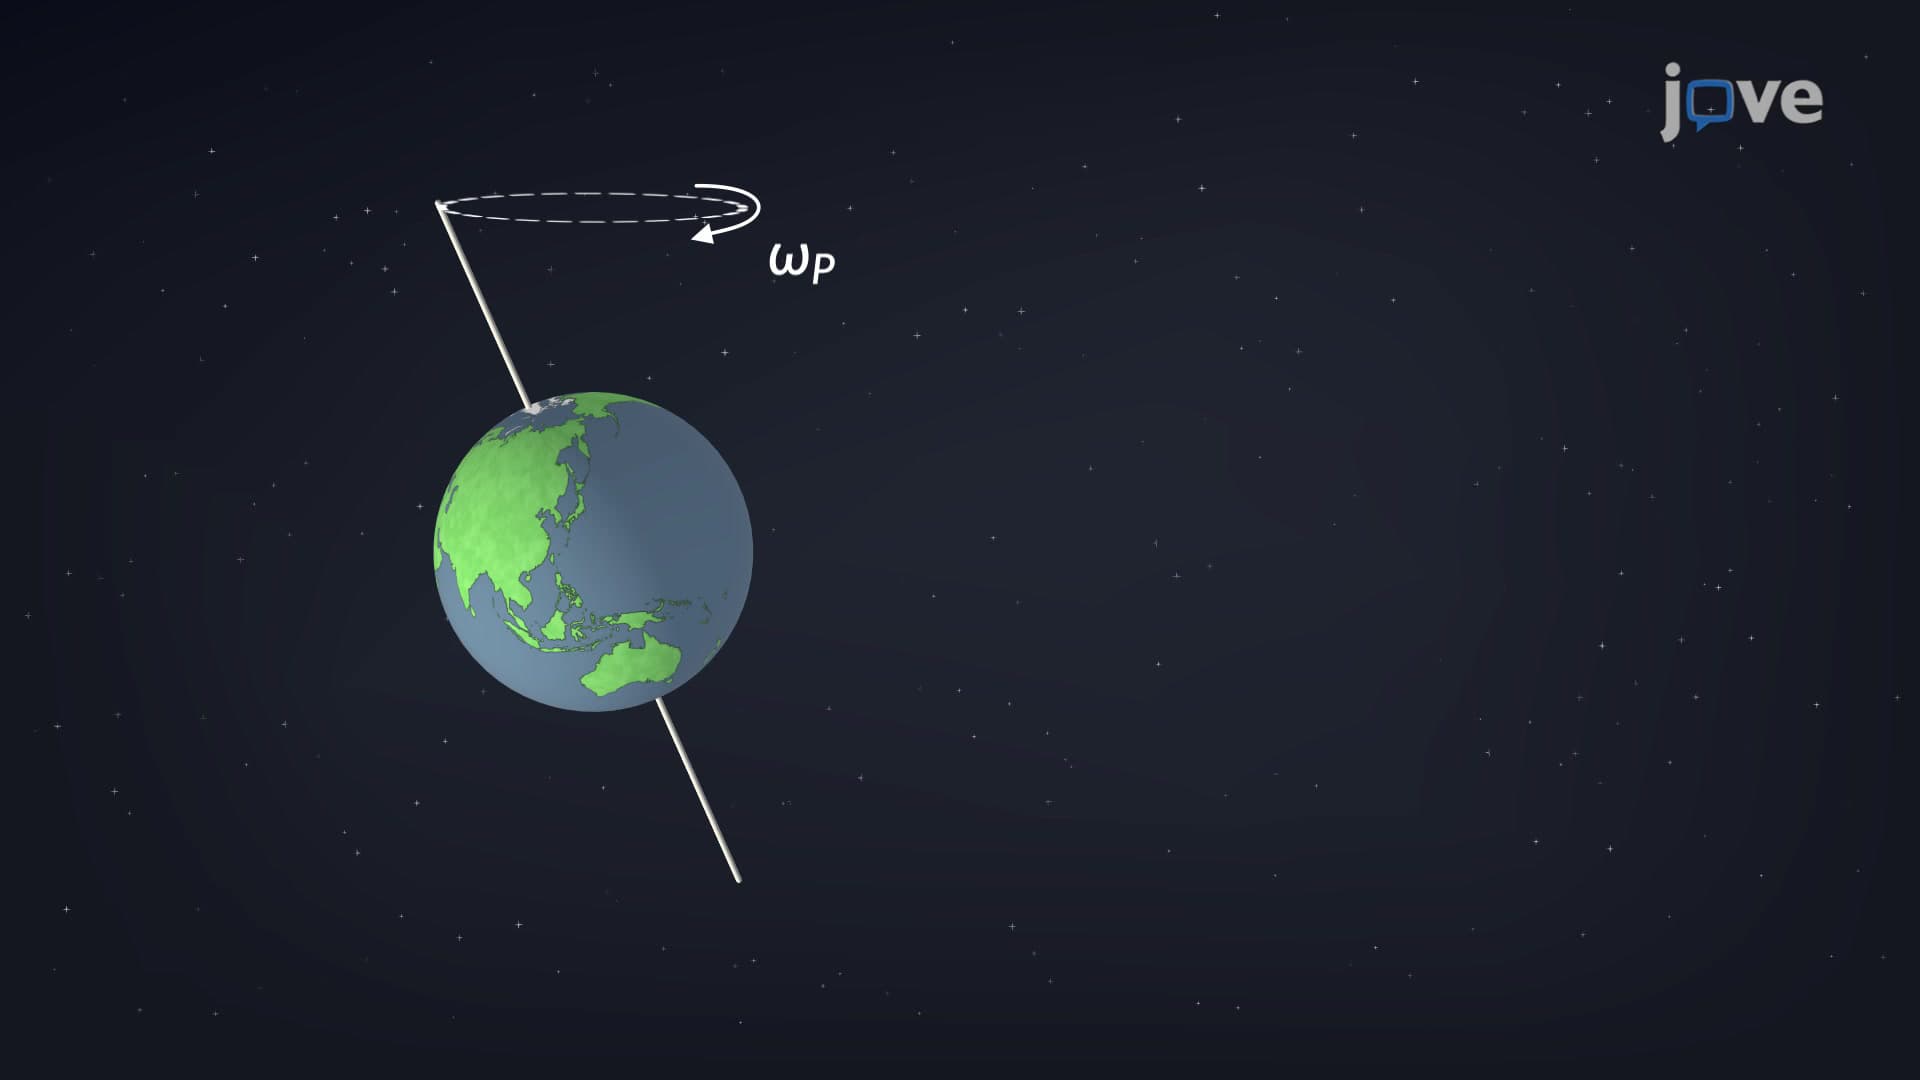 01:24
Gyroscope: Precession
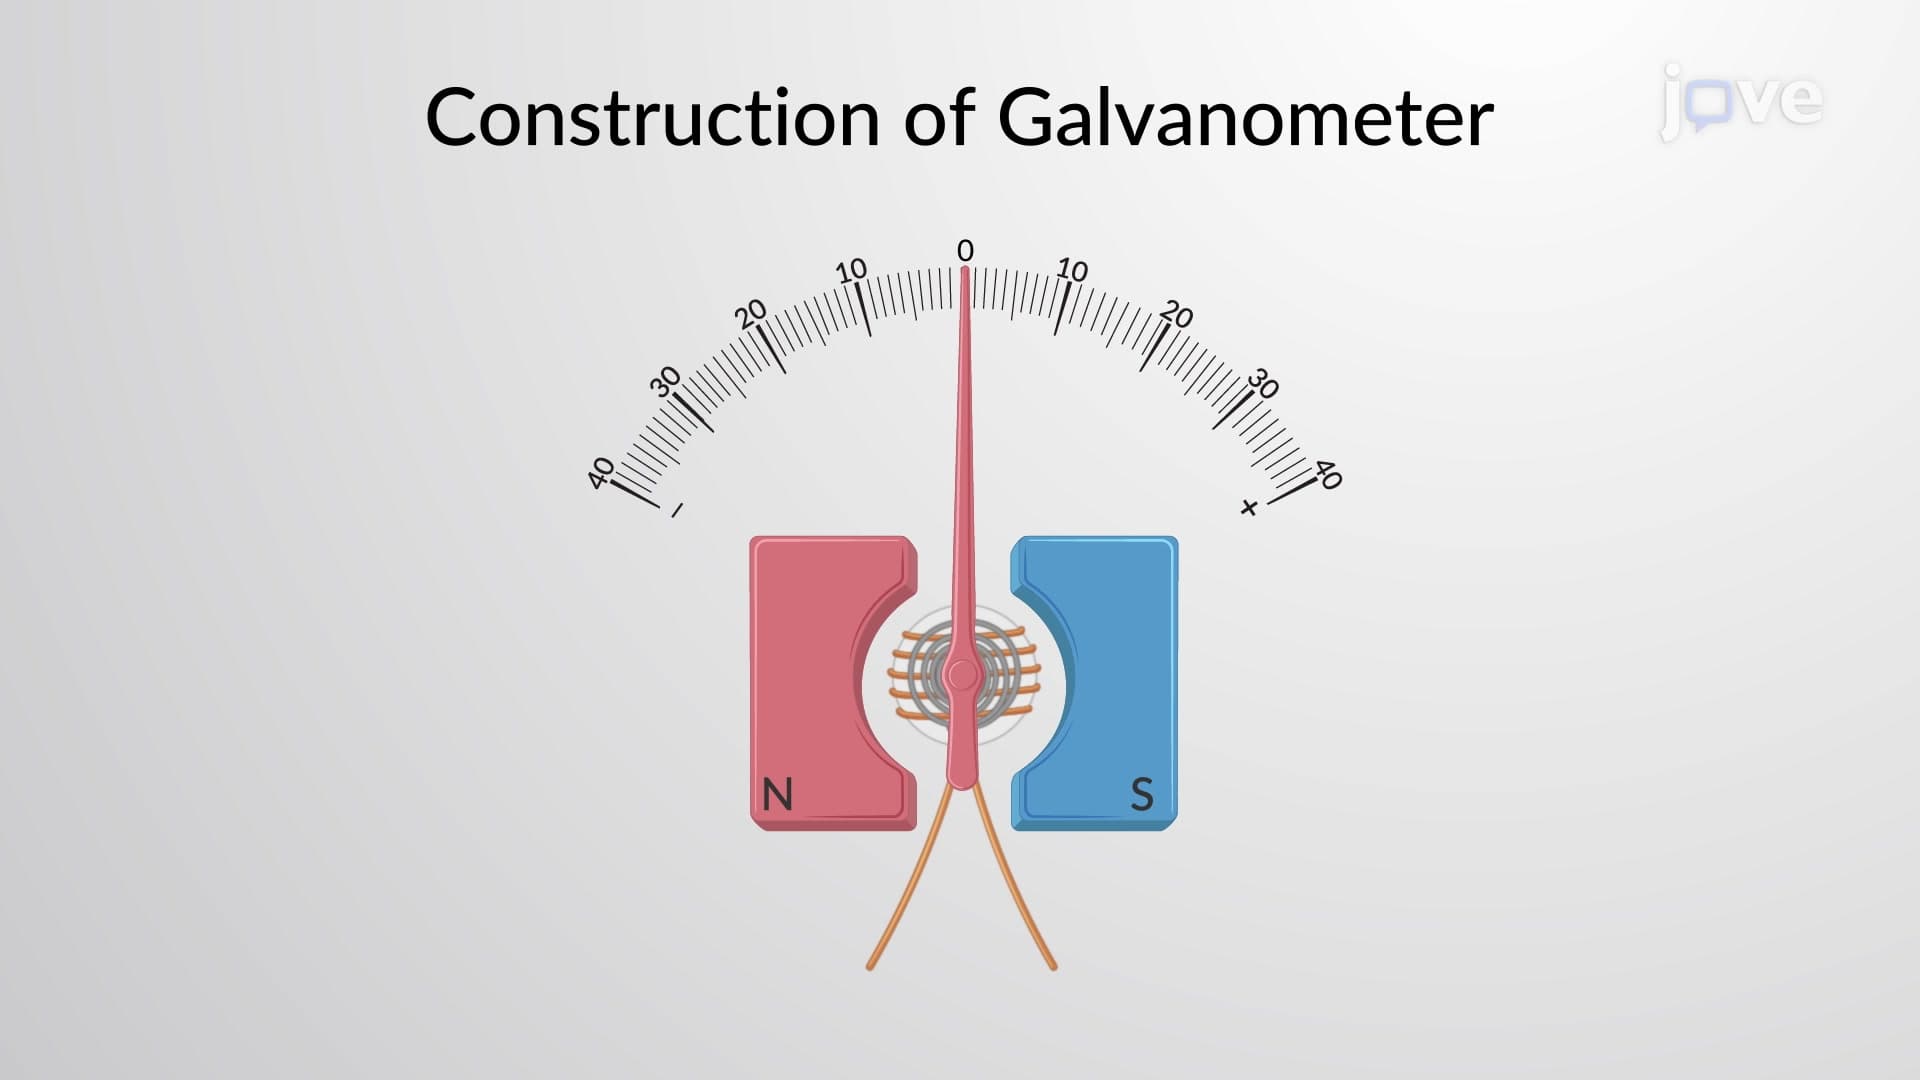 01:24
Galvanometer
The galvanometer consists of two concave-shaped permanent magnets, providing a uniform radial magnetic field in the annular region. In the center, a pivoted coil of fine copper wire is placed in the uniform...
 01:26
Errors in Global Positioning System
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
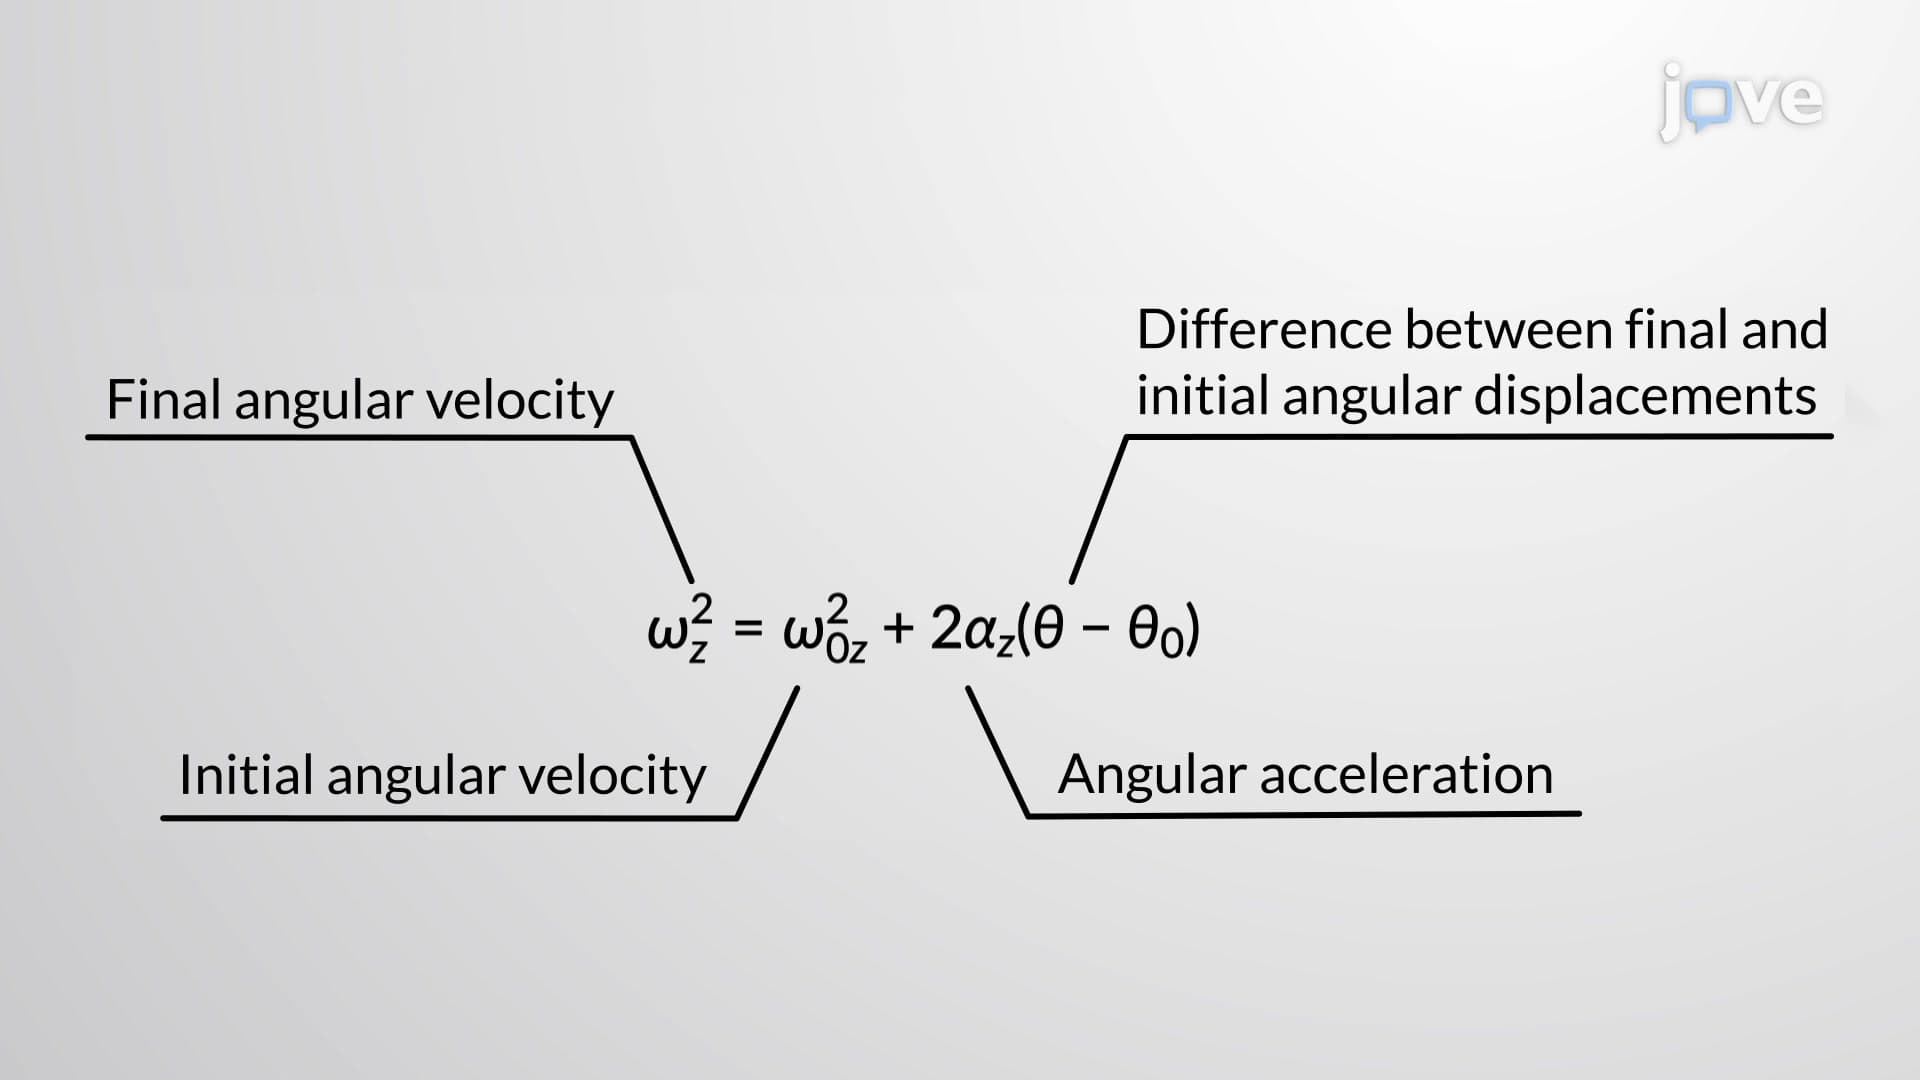 01:16
Rotation with Constant Angular Acceleration - II
The first...