Related Experiment Video
Updated: Mar 11, 2026

Generating Strictly Controlled Stimuli for Figure Recognition Experiments
Published on: March 18, 2019
The mathematics of xenology: di-cographs, symbolic ultrametrics, 2-structures and tree-representable systems of
Marc Hellmuth1,2, Peter F Stadler3,4,5,6,7, Nicolas Wieseke8,9
1Department of Mathematics and Computer Science, University of Greifswald, Walther-Rathenau-Straße 47, 17487 , Greifswald, Germany. mhellmuth@mailbox.org.

Abstract:
The concepts of orthology, paralogy, and xenology play a key role in molecular evolution. Orthology and paralogy distinguish whether a pair of genes originated by speciation or duplication. The corresponding binary relations on a set of genes form complementary cographs. Allowing more than two types of ancestral event types leads to symmetric symbolic ultrametrics. Horizontal gene transfer, which leads to xenologous gene pairs, however, is inherent asymmetric since one offspring copy "jumps" into another genome, while the other continues to be inherited vertically. We therefore explore here the mathematical structure of the non-symmetric generalization of symbolic ultrametrics. Our main results tie non-symmetric ultrametrics together with di-cographs (the directed generalization of cographs), so-called uniformly non-prime ([Formula: see text]) 2-structures, and hierarchical structures on the set of strong modules. This yields a characterization of relation structures that can be explained in terms of trees and types of ancestral events. This framework accommodates a horizontal-transfer relation in terms of an ancestral event and thus, is slightly different from the the most commonly used definition of xenology. As a first step towards a practical use, we present a simple polynomial-time recognition algorithm of [Formula: see text] 2-structures and investigate the computational complexity of several types of editing problems for [Formula: see text] 2-structures. We show, finally that these NP-complete problems can be solved exactly as Integer Linear Programs.
Related Concept Videos
 01:20
Relation between Mathematical Equations and Block Diagrams
 01:28
Graphical Representation of Inequalities
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:28
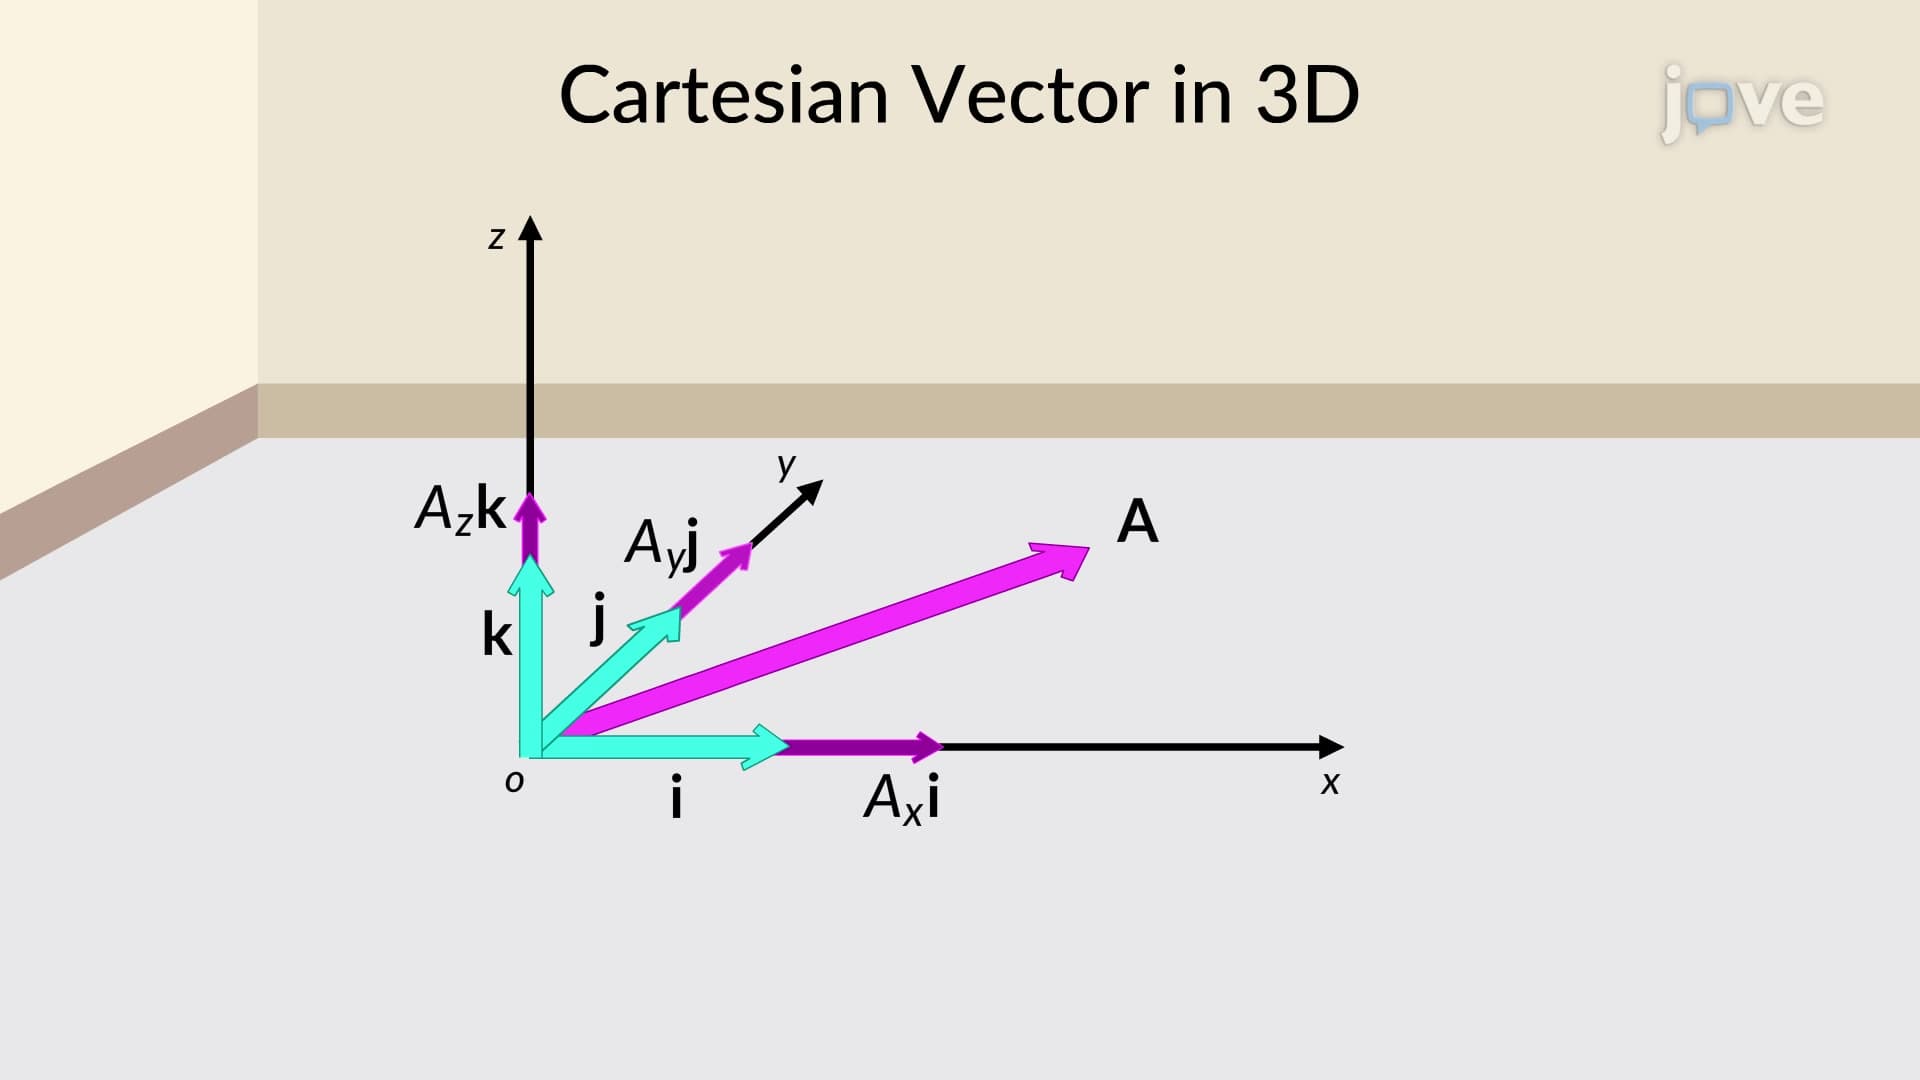
Cartesian Vector Notation
 01:30
Fundamental Theorem of Algebra
 01:10
Vector Algebra: Graphical Method
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...