Related Experiment Video
Updated: Mar 9, 2026

Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Enhanced Locomotion Efficiency of a Bio-inspired Walking Robot using Contact Surfaces with Frictional Anisotropy
Poramate Manoonpong1,2, Dennis Petersen3, Alexander Kovalev3
1Embodied AI and Neurorobotics Lab, Centre for BioRobotics, The Mærsk Mc-Kinney Møller Institute, University of Southern Denmark, Odense M, DK-5230, Denmark.

Abstract:
Based on the principles of morphological computation, we propose a novel approach that exploits the interaction between a passive anisotropic scale-like material (e.g., shark skin) and a non-smooth substrate to enhance locomotion efficiency of a robot walking on inclines. Real robot experiments show that passive tribologically-enhanced surfaces of the robot belly or foot allow the robot to grip on specific surfaces and move effectively with reduced energy consumption. Supplementing the robot experiments, we investigated tribological properties of the shark skin as well as its mechanical stability. It shows high frictional anisotropy due to an array of sloped denticles. The orientation of the denticles to the underlying collagenous material also strongly influences their mechanical interlocking with the substrate. This study not only opens up a new way of achieving energy-efficient legged robot locomotion but also provides a better understanding of the functionalities and mechanical properties of anisotropic surfaces. That understanding will assist developing new types of material for other real-world applications.


Related Concept Videos
 01:05
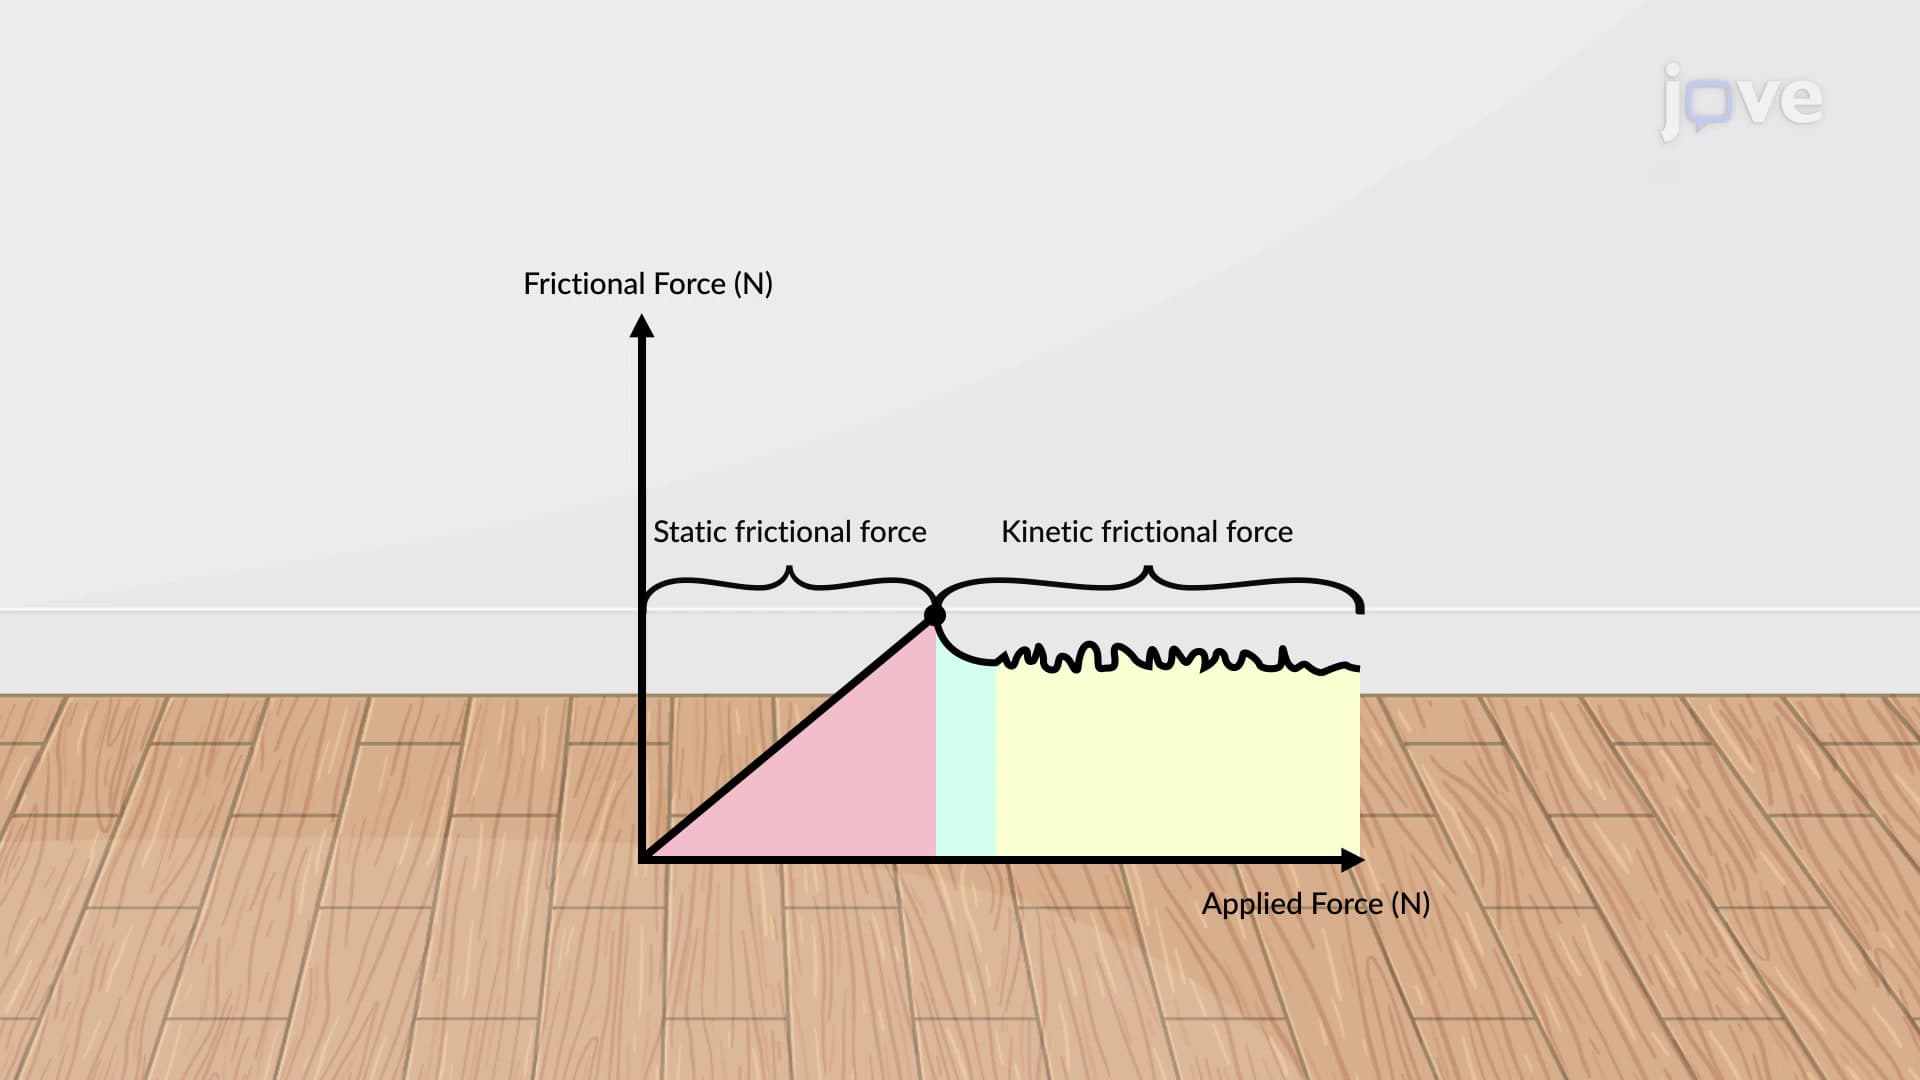
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:26
Kinetic Friction
 01:07
Frictional Force
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion....
 01:28
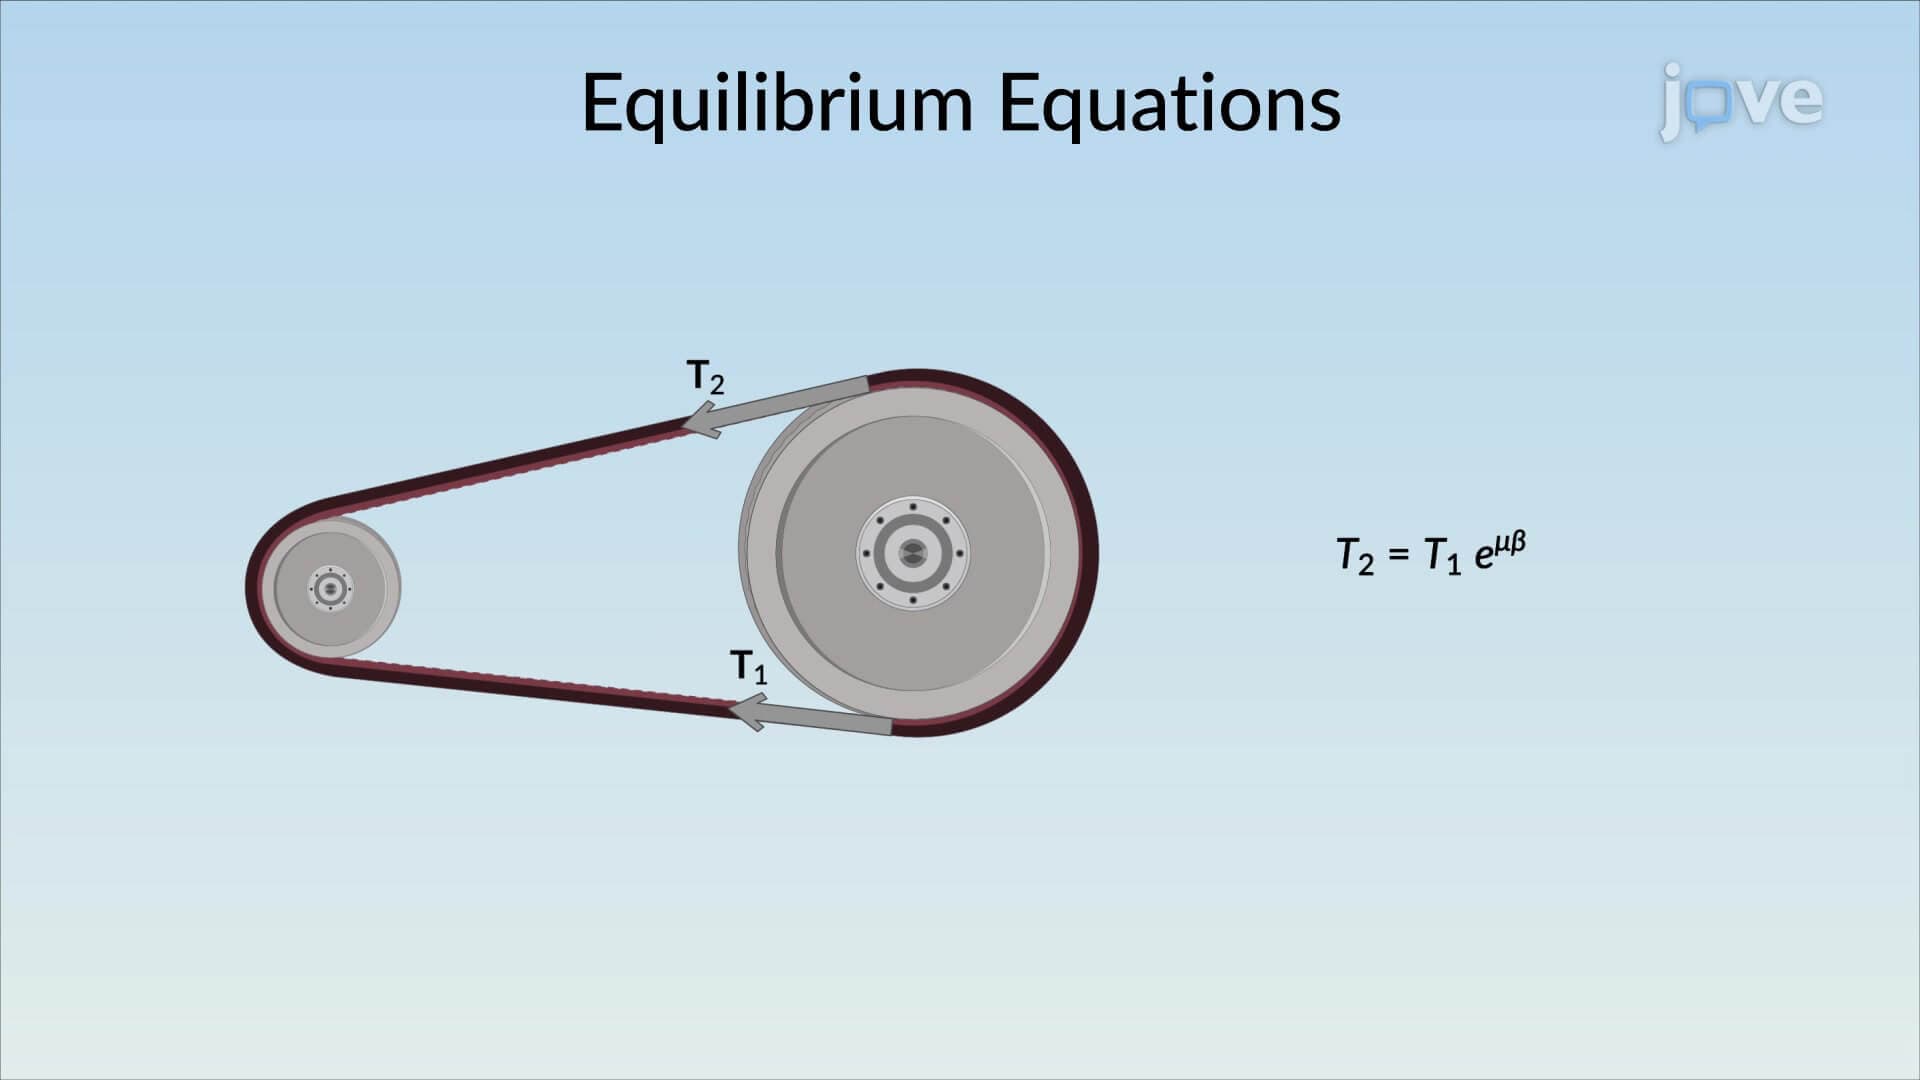
Frictional Forces on Flat Belts
 01:21
Friction: Problem Solving
Initially, a visual representation of the...