Related Experiment Video
Updated: Mar 8, 2026
Long-term Behavioral Tracking of Freely Swimming Weakly Electric Fish
Published on: March 6, 2014
Development of a vortex generator to perturb fish locomotion
Deeksha Seth1, Brooke E Flammang2, George V Lauder3
1Drexel University, Department of Mechanical Engineering and Mechanics, 3141 Chestnut Street, Randell 115, MEM Department, Philadelphia, PA 19104, USA deeksha.seth@drexel.edu.

Abstract:
Knowledge about the stiffness of fish fins, and whether stiffness is modulated during swimming, is important for understanding the mechanics of a fin's force production. However, the mechanical properties of fins have not been studied during natural swimming, in part because of a lack of instrumentation. To remedy this, a vortex generator was developed that produces traveling vortices of adjustable strength which can be used to perturb the fins of swimming fish. Experiments were conducted to understand how the generator's settings affected the resulting vortex rings. A variety of vortices (14-32 mm diameter traveling at 371-2155 mm s-1) were produced that elicited adequate responses from the fish fins to help us to understand the fin's mechanical properties at various swimming speeds (0-350 mm s-1).
Related Concept Videos
 01:13
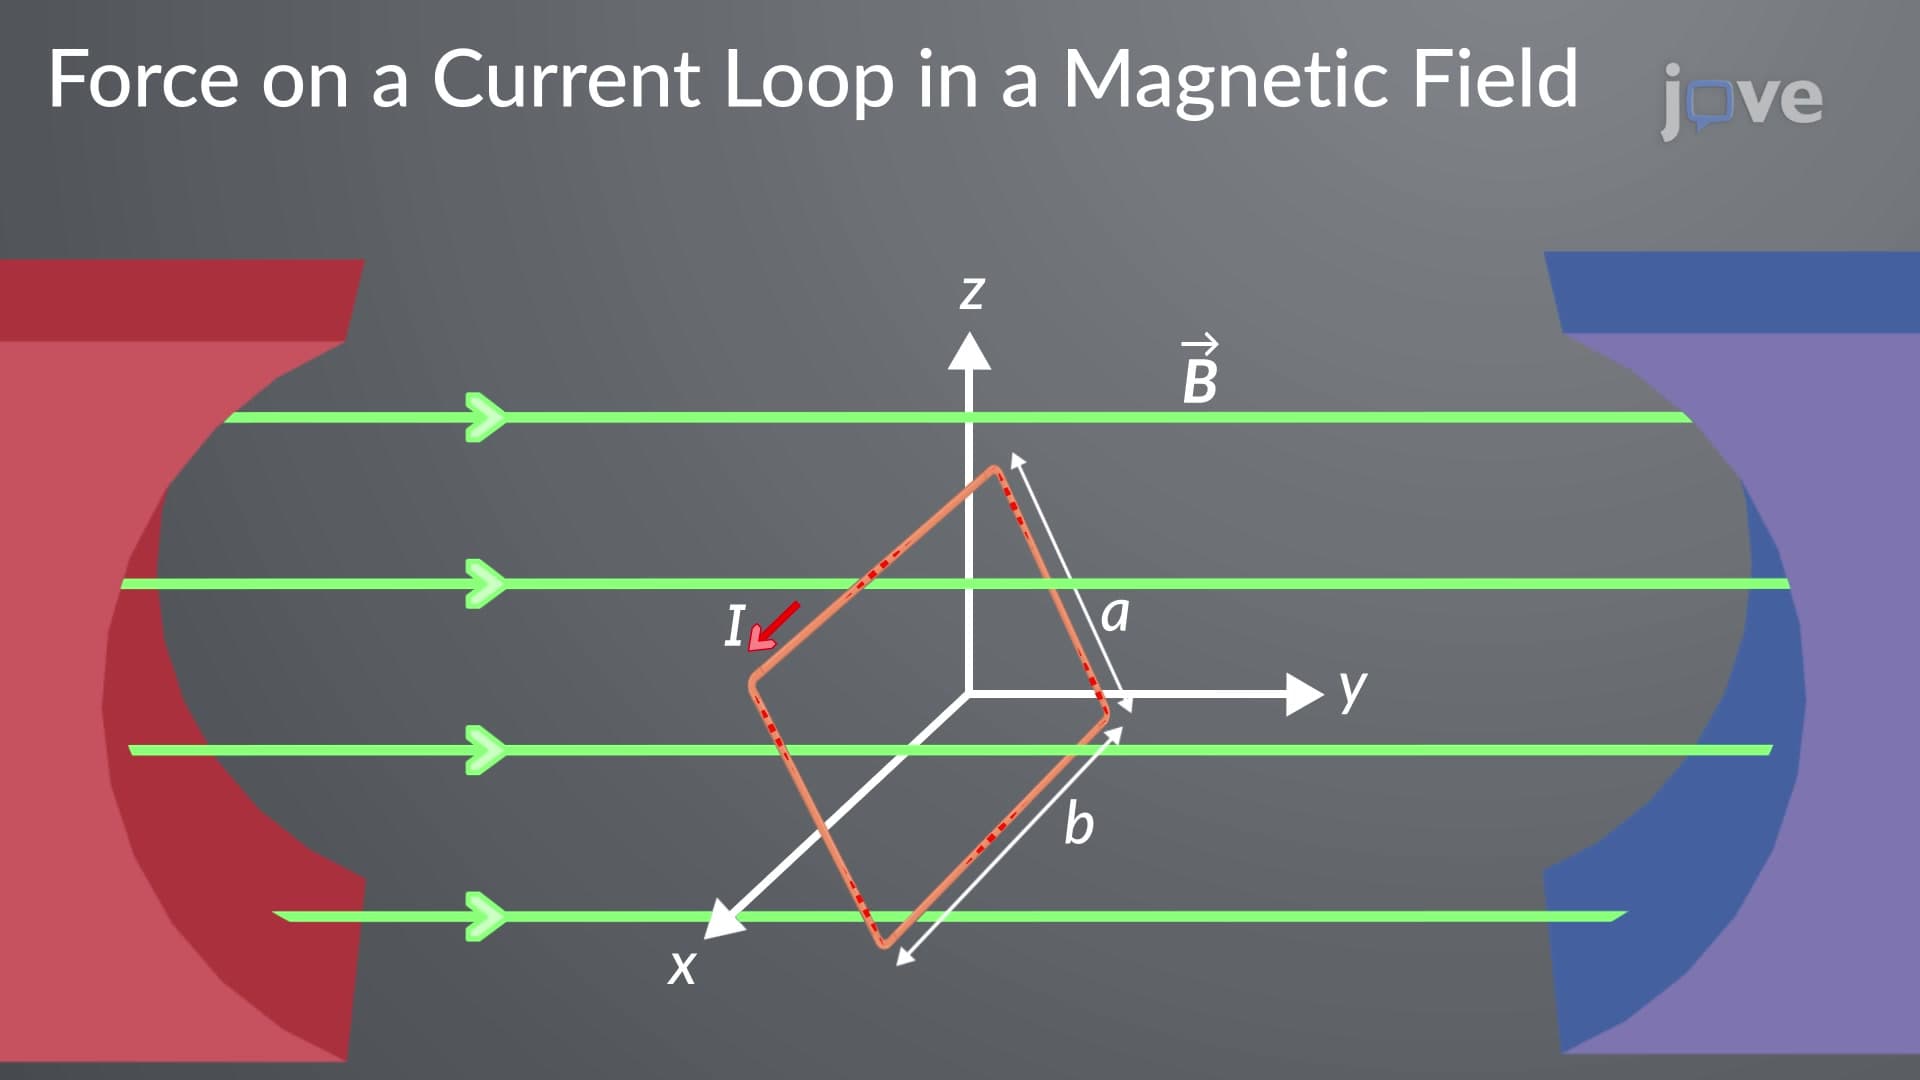
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:17
Force On A Current Loop In A Magnetic Field
 02:32
Osmoregulation in Fishes
 01:23
Faraday Disk Dynamo