Related Experiment Video
Updated: Mar 8, 2026

Flapping Soft Fin Deformation Modeling using Planar Laser-Induced Fluorescence Imaging
Published on: April 28, 2022
Performance variation due to stiffness in a tuna-inspired flexible foil model
Mariel-Luisa N Rosic1, Patrick J M Thornycroft, Kara L Feilich
1The Museum of Comparative Zoology, Harvard University, Cambridge, MA 02138, USA.

Abstract:
Tuna are fast, economical swimmers in part due to their stiff, high aspect ratio caudal fins and streamlined bodies. Previous studies using passive caudal fin models have suggested that while high aspect ratio tail shapes such as a tuna's generally perform well, tail performance cannot be determined from shape alone. In this study, we analyzed the swimming performance of tuna-tail-shaped hydrofoils of a wide range of stiffnesses, heave amplitudes, and frequencies to determine how stiffness and kinematics affect multiple swimming performance parameters for a single foil shape. We then compared the foil models' kinematics with published data from a live swimming tuna to determine how well the hydrofoil models could mimic fish kinematics. Foil kinematics over a wide range of motion programs generally showed a minimum lateral displacement at the narrowest part of the foil, and, immediately anterior to that, a local area of large lateral body displacement. These two kinematic patterns may enhance thrust in foils of intermediate stiffness. Stiffness and kinematics exhibited subtle interacting effects on hydrodynamic efficiency, with no one stiffness maximizing both thrust and efficiency. Foils of intermediate stiffnesses typically had the greatest coefficients of thrust at the highest heave amplitudes and frequencies. The comparison of foil kinematics with tuna kinematics showed that tuna motion is better approximated by a zero angle of attack foil motion program than by programs that do not incorporate pitch. These results indicate that open questions in biomechanics may be well served by foil models, given appropriate choice of model characteristics and control programs. Accurate replication of biological movements will require refinement of motion control programs and physical models, including the creation of models of variable stiffness.
Related Concept Videos
 01:11
Bending of Members Made of Several Materials
Hooke's Law determines stress in each material, stating that stress is proportional to strain but varies due to each material's...
 01:15
Relation between Poisson's ratio, Modulus of Elasticity and Modulus of Rigidity
 01:20
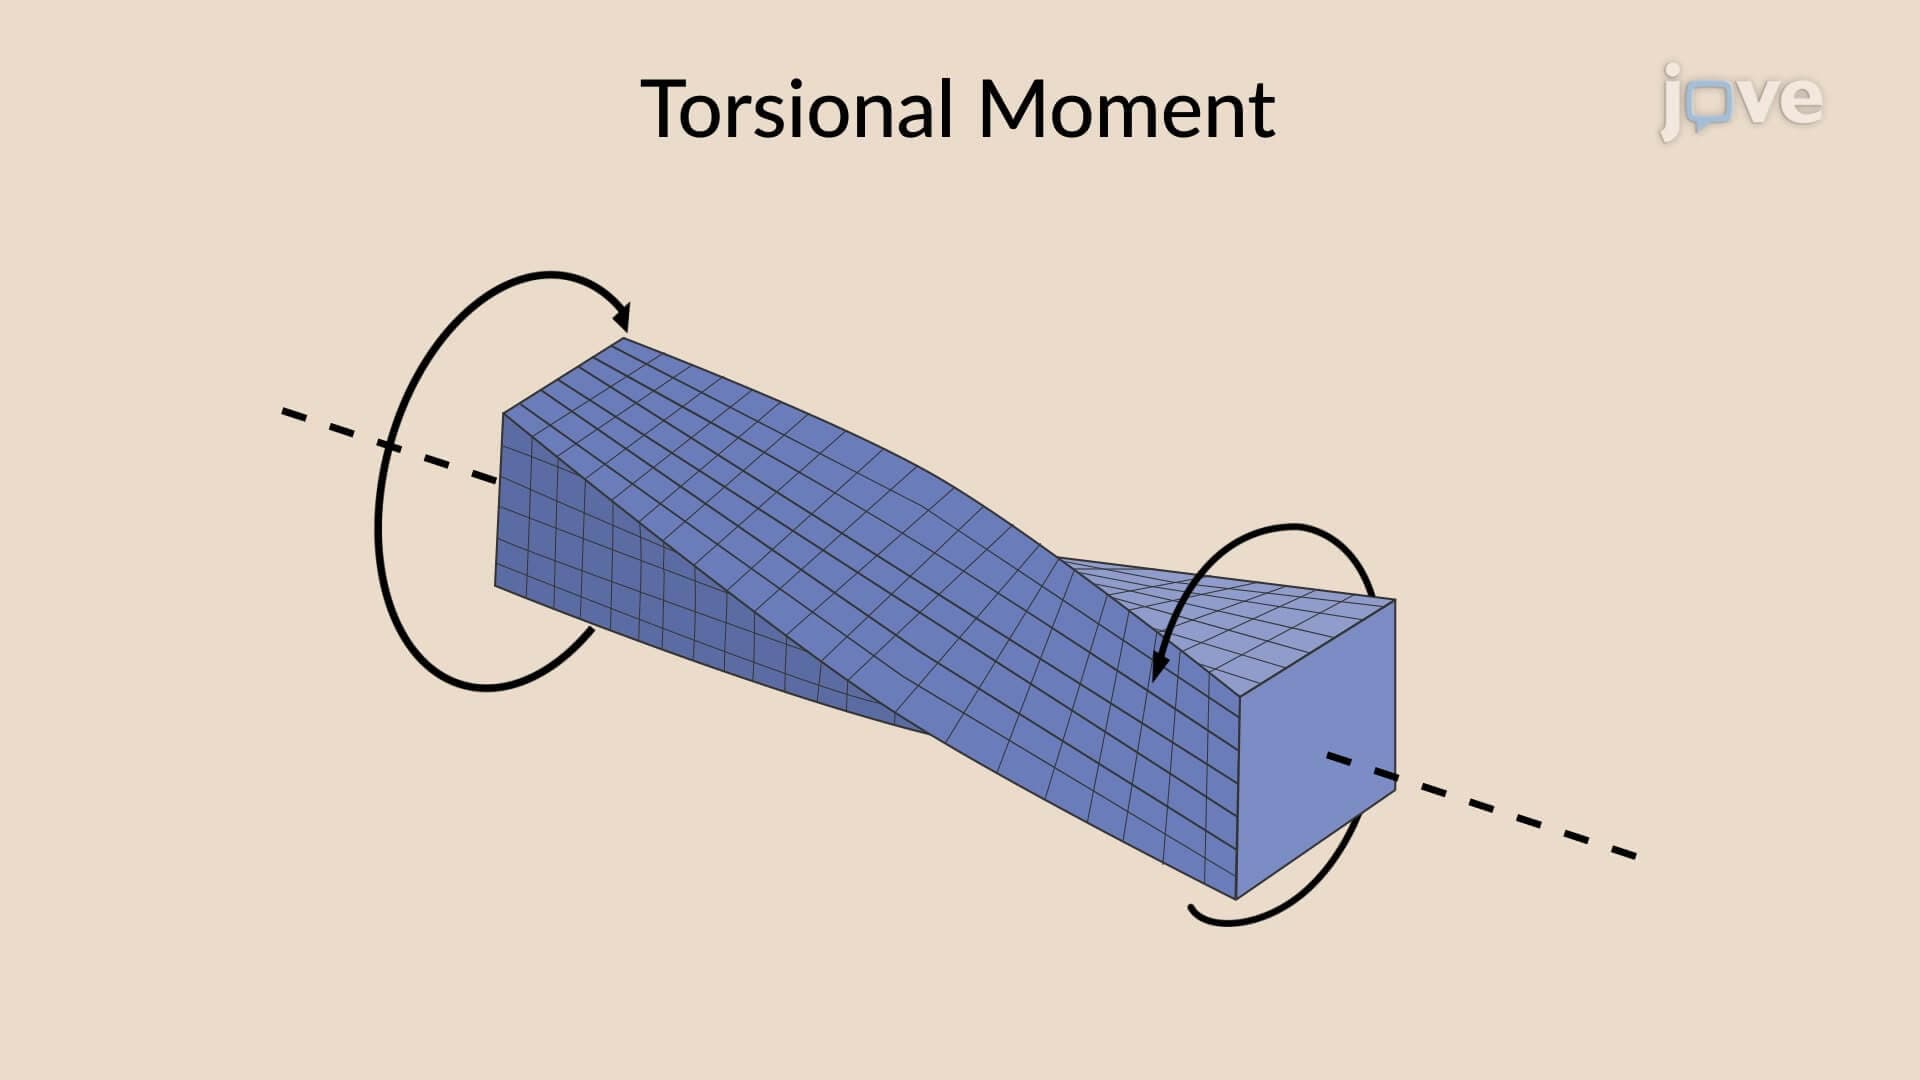
Bending and Torsional Moments
The reaction developed in a structural element when subjected to an external force causes the element to bend. When a structural element bends upwards, it creates compressive normal forces on the top and tensile normal forces on the bottom, resulting in a couple that determines the bending...
 01:16
Flexural Stress
Hooke's Law states that within the material's elastic limits, stress is directly proportional to strain. In a member experiencing a bending moment, the strain at any point is relative to its distance...
 01:18
Stress Concentrations in Circular Shafts
 01:18
Residual Stresses in Bending