Related Experiment Video
Updated: Mar 8, 2026

The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
Network-Based Practical Consensus of Heterogeneous Nonlinear Multiagent Systems

Abstract:
This paper studies network-based practical leader-following consensus problem of heterogeneous multiagent systems with Lipschitz nonlinear dynamics under both fixed and switching topologies. Considering the effect of network-induced delay, a network-based leader-following consensus protocol with heterogeneous gain matrix is proposed for each follower agent. By employing Lyapunov-Krasovskii method, a sufficient condition for designing the network-based consensus controller gain is derived such that the leader-following consensus error exponentially converges to a bounded region under a fixed topology. Correspondingly, the proposed design approach is then extended to the case of switching topology. Two numerical examples with networked Chua's circuits are given to show the efficiency of the design method proposed in this paper.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:21
Distributed Loads: Problem Solving
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:31
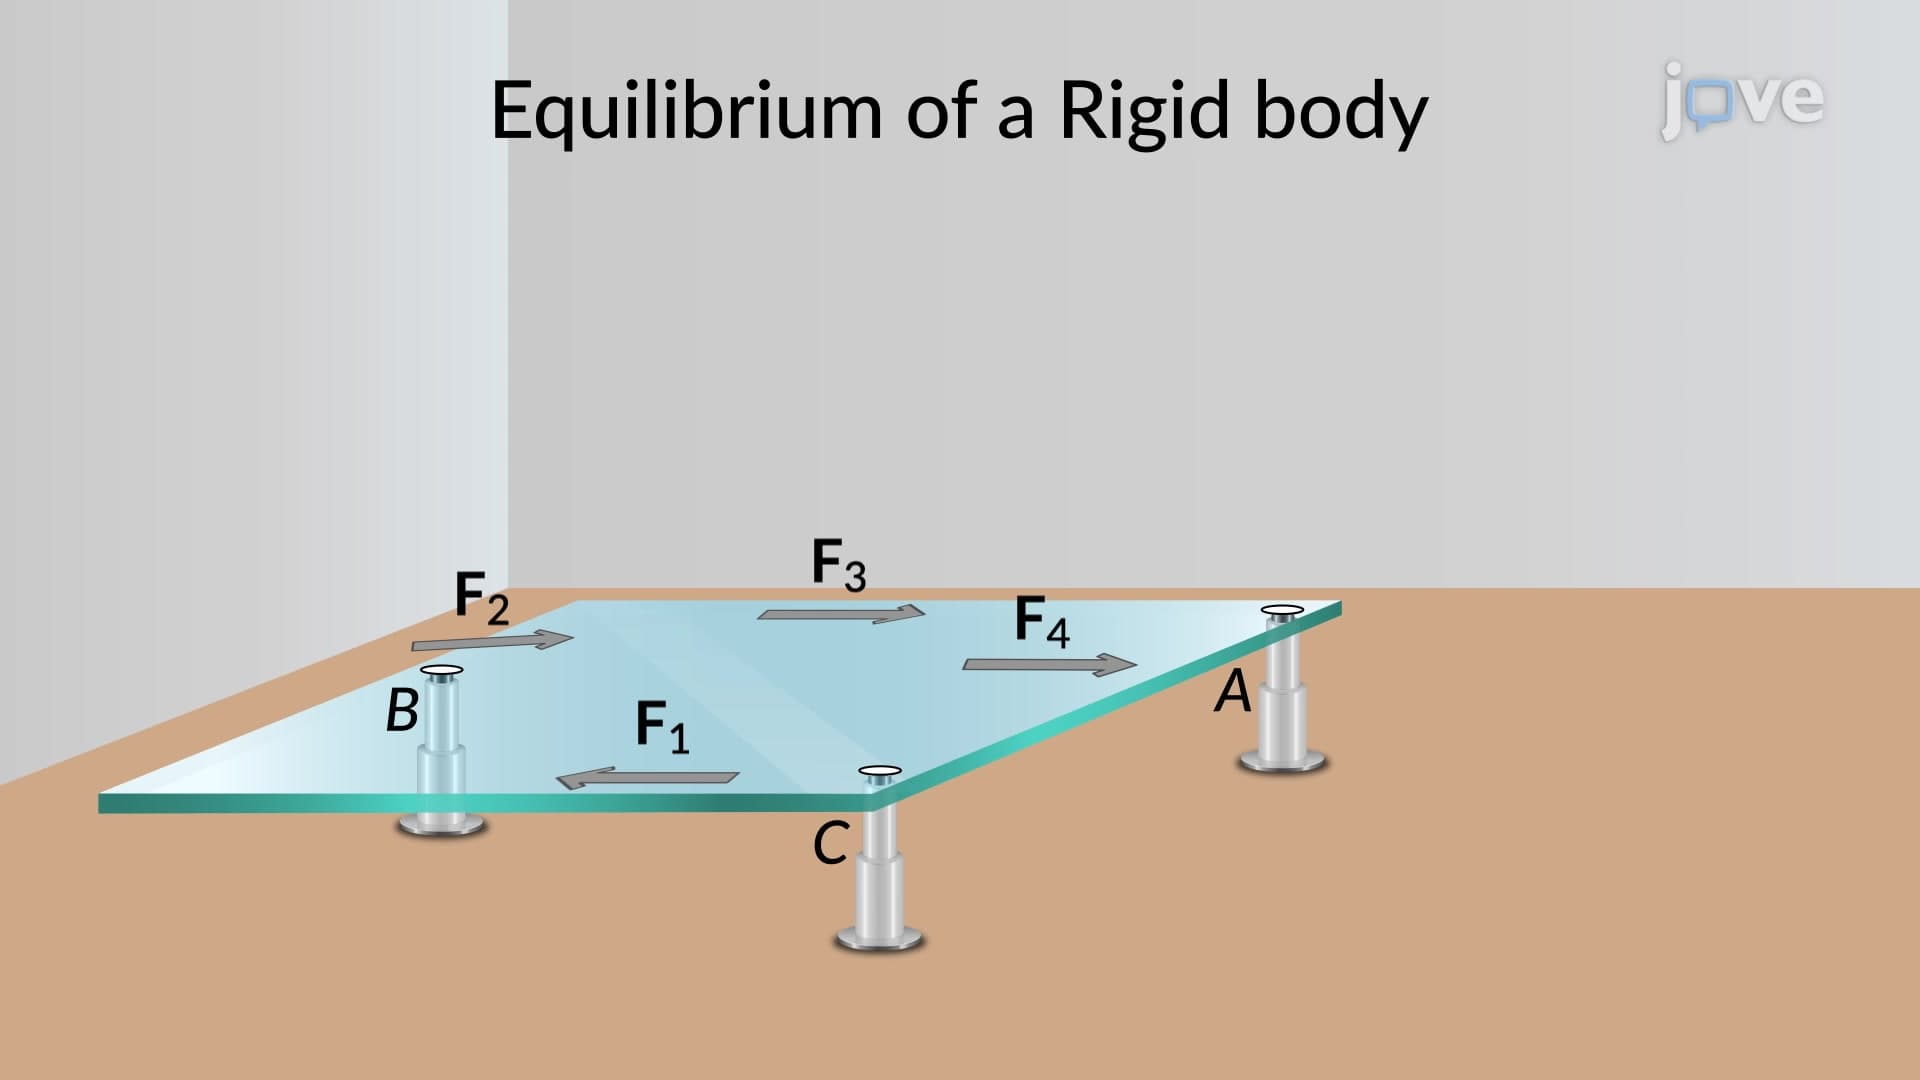
Alternative Sets of Equilibrium Equations
One example of such a situation can be observed in a...
 01:13
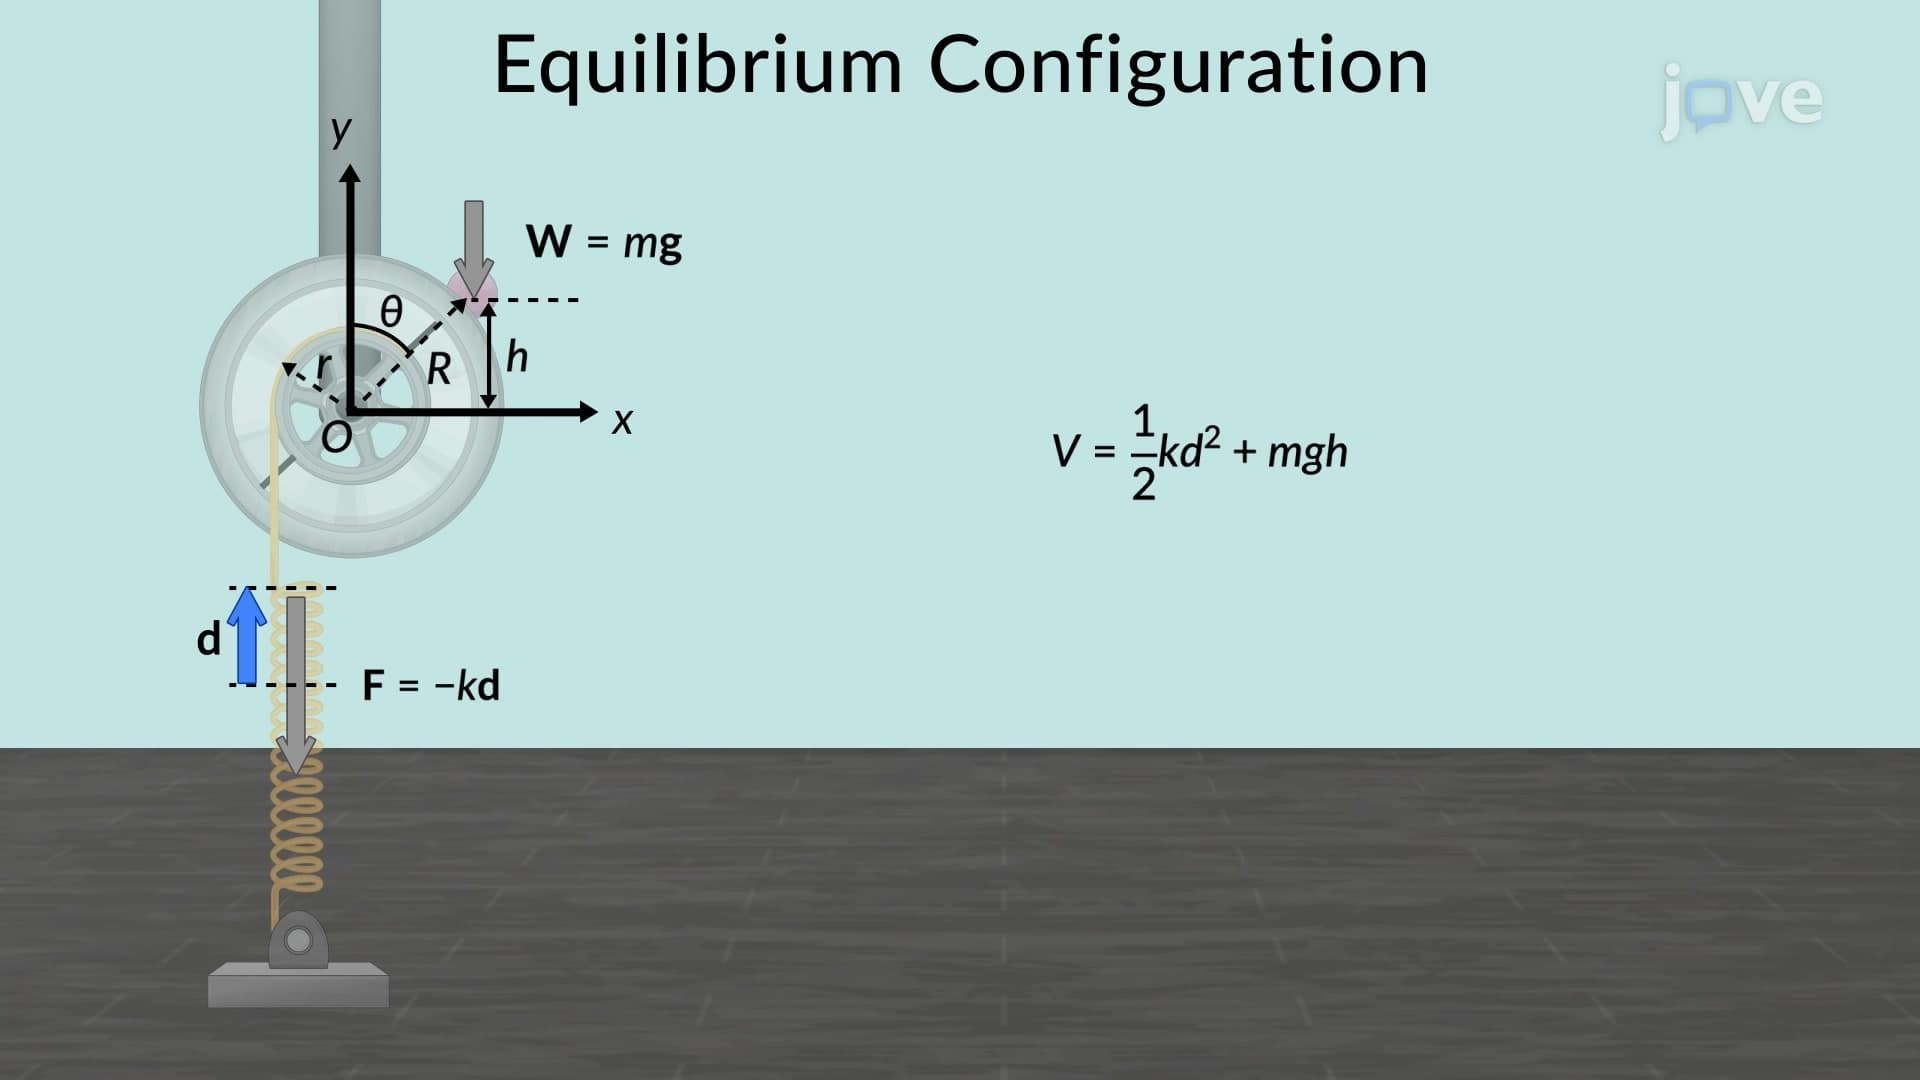
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...