Related Experiment Video
Updated: Mar 8, 2026

A Tactile Automated Passive-Finger Stimulator TAPS
Published on: June 3, 2009
Adaptive 6-DoF Haptic Contact Stiffness Using the Gauss Map

Abstract:
The penalty method is a popular approach to resolving contact in haptic rendering. In simulations involving complex distributed contact, there are, however, many simultaneous individual contacts. These contacts have normals pointing in several directions, many of which may be parallel, causing the stiffness effectively to add up in a temporally highly-varying and unpredictable way. Consequently, penalty-based simulation suffers from stability problems. Previous methods tackled this problem using implicit integration, or simply by scaling the stiffness down globally by the number of contacts. Although this provides some control over the net stiffness, it leads to large penetrations, as small contacts are effectively ignored when compared to larger contacts. We propose an adaptive stiffness method that employs the Gauss map of the normal distribution to ensure a spatially uniform and controllable stiffness in all the contact directions. Combined with virtual coupling saturation, the penetration can be kept shallow all the while haptic simulation remains stable, even for large-scale complex geometry with complex distributed 6-DoF contact scenarios. Our method is fast and can be applied to any penalty-based formulation between rigid objects. While used primarily for rigid objects, we also apply our method to reduced deformable objects. We demonstrate the effectiveness of our approach on several challenging 6-DoF haptic rendering scenarios, such as car engine and landing gear virtual assembly.

Related Concept Videos
 01:30
Three-Dimensional Force System
 01:20
Two-Dimensional Force System
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Generalized Hooke's Law
 01:05
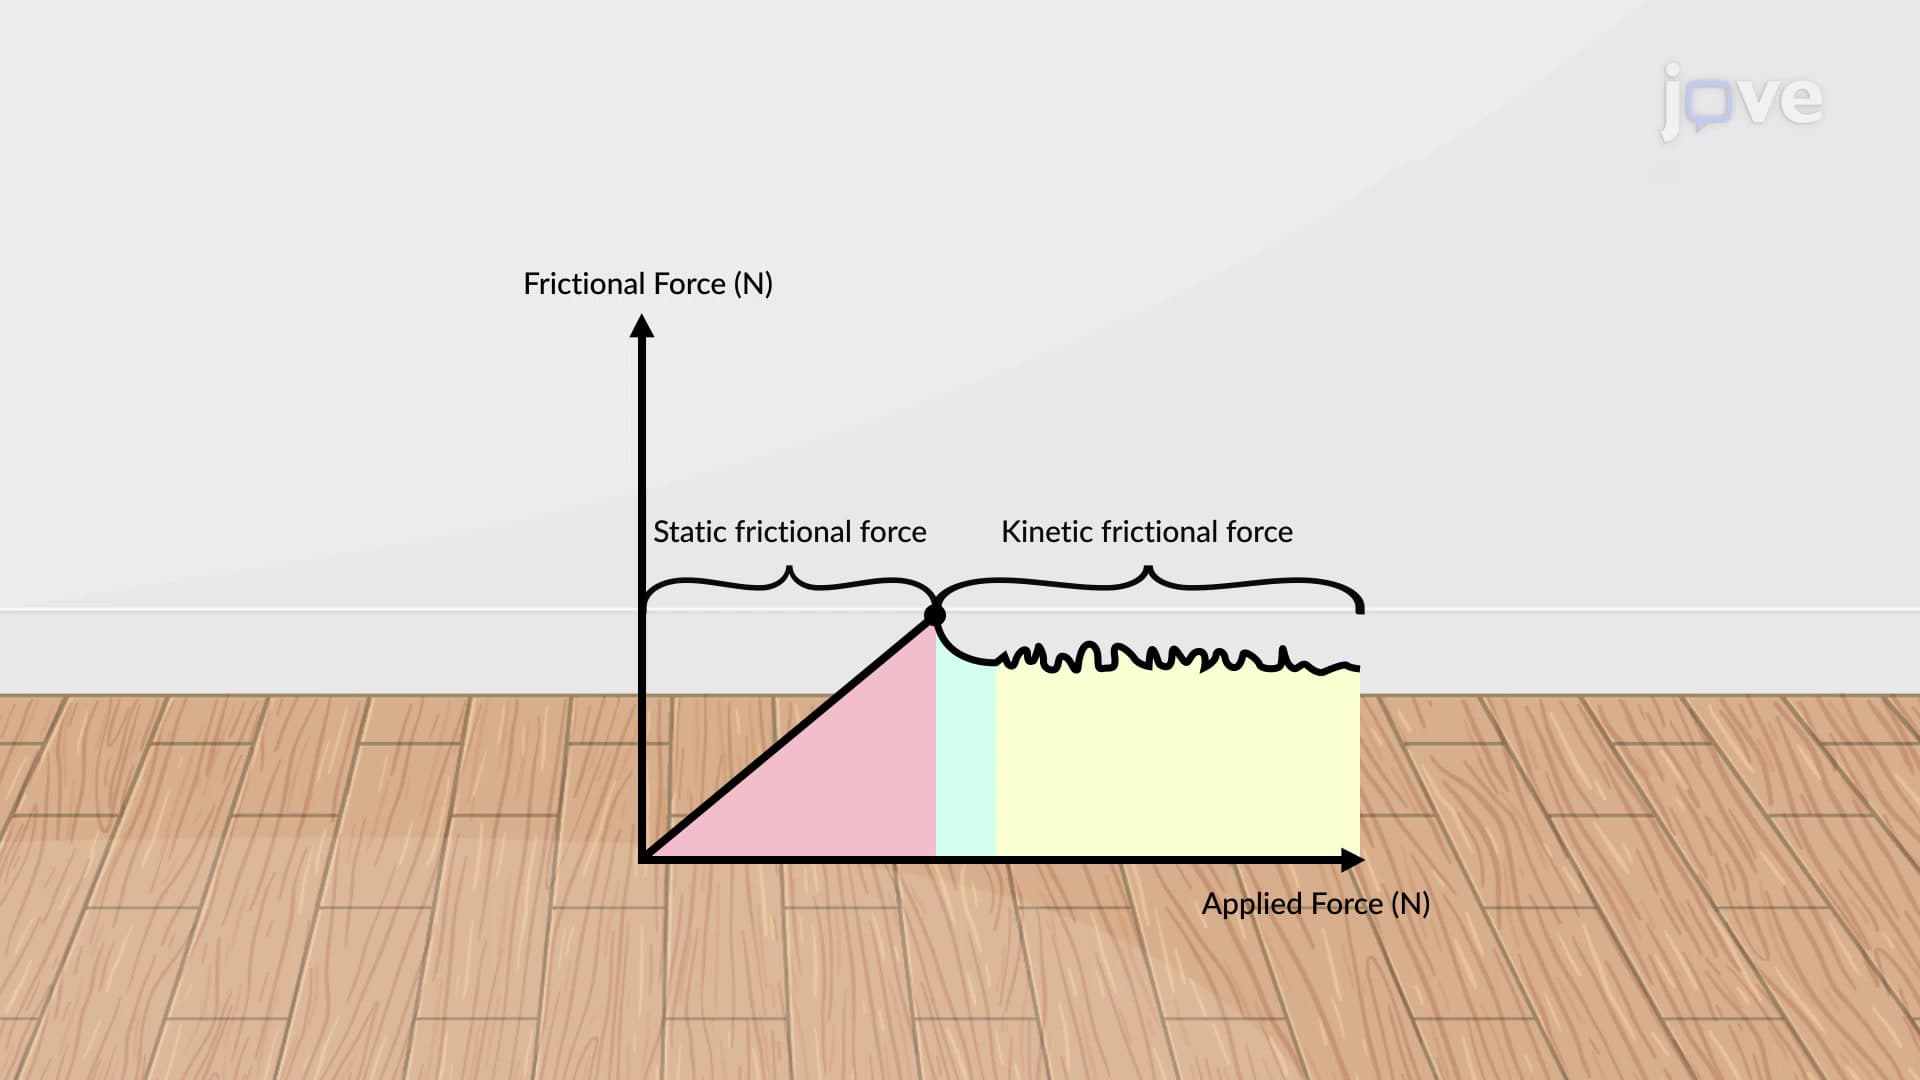
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...