Related Experiment Video
Updated: Mar 7, 2026

Author Spotlight: Investigating the Effects of Mind-Body-Movement Practices on Brain Function
Published on: January 26, 2024
Safe Exploration Algorithms for Reinforcement Learning Controllers

Abstract:
Self-learning approaches, such as reinforcement learning, offer new possibilities for autonomous control of uncertain or time-varying systems. However, exploring an unknown environment under limited prediction capabilities is a challenge for a learning agent. If the environment is dangerous, free exploration can result in physical damage or in an otherwise unacceptable behavior. With respect to existing methods, the main contribution of this paper is the definition of a new approach that does not require global safety functions, nor specific formulations of the dynamics or of the environment, but relies on interval estimation of the dynamics of the agent during the exploration phase, assuming a limited capability of the agent to perceive the presence of incoming fatal states. Two algorithms are presented with this approach. The first is the Safety Handling Exploration with Risk Perception Algorithm (SHERPA), which provides safety by individuating temporary safety functions, called backups. SHERPA is shown in a simulated, simplified quadrotor task, for which dangerous states are avoided. The second algorithm, denominated OptiSHERPA, can safely handle more dynamically complex systems for which SHERPA is not sufficient through the use of safety metrics. An application of OptiSHERPA is simulated on an aircraft altitude control task.


Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:17
Rolling Resistance: Problem Solving
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:16
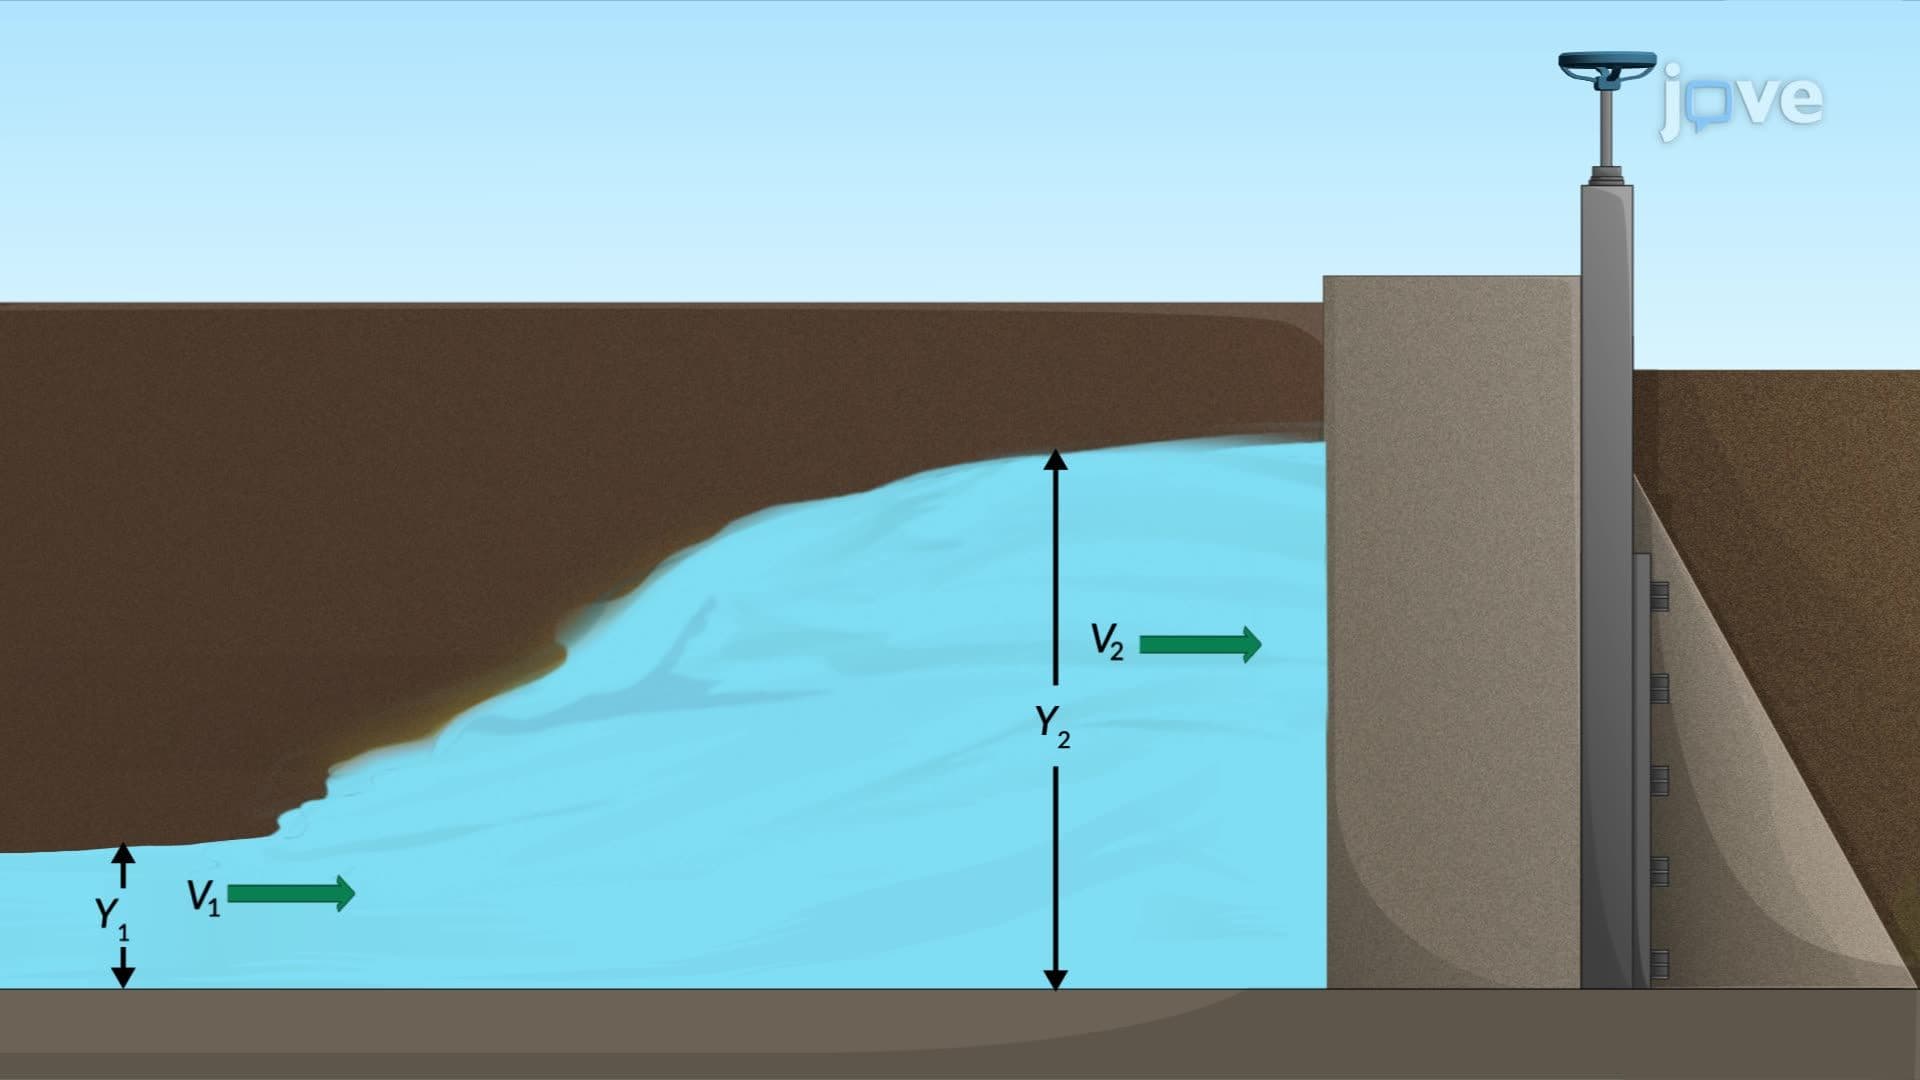
Hydraulic Jump: Problem Solving
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...