Related Experiment Video
Updated: Mar 7, 2026
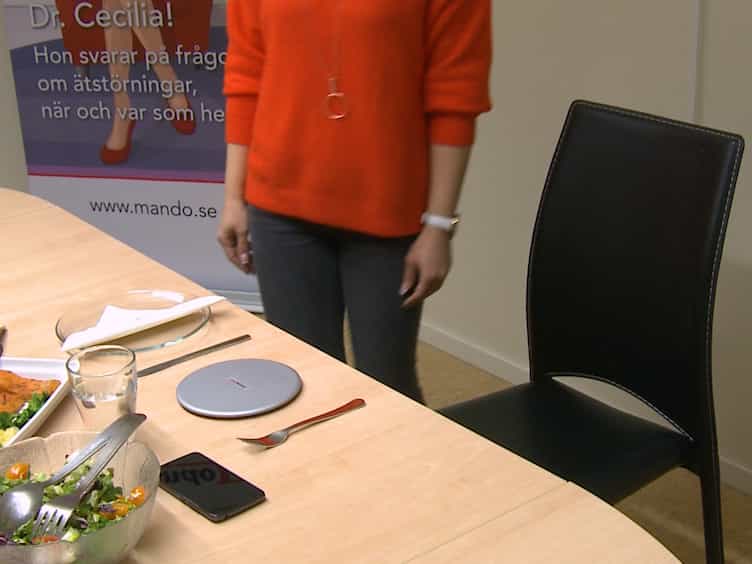
Control of Eating Behavior Using a Novel Feedback System
Published on: May 8, 2018
The effect of real-time vibrotactile feedback delivered through an augmented fork on eating rate, satiation, and food
Roel C J Hermans1, Sander Hermsen2, Eric Robinson3
1Behavioural Science Institute, Radboud University, Nijmegen, The Netherlands.

Abstract:
Eating rate is a basic determinant of appetite regulation, as people who eat more slowly feel sated earlier and eat less. Without assistance, eating rate is difficult to modify due to its automatic nature. In the current study, participants used an augmented fork that aimed to decelerate their rate of eating. A total of 114 participants were randomly assigned to the Feedback Condition (FC), in which they received vibrotactile feedback from their fork when eating too fast (i.e., taking more than one bite per 10 s), or a Non-Feedback Condition (NFC). Participants in the FC took fewer bites per minute than did those in the NFC. Participants in the FC also had a higher success ratio, indicating that they had significantly more bites outside the designated time interval of 10 s than did participants in the NFC. A slower eating rate, however, did not lead to a significant reduction in the amount of food consumed or level of satiation. These findings indicate that real-time vibrotactile feedback delivered through an augmented fork is capable of reducing eating rate, but there is no evidence from this study that this reduction in eating rate is translated into an increase in satiation or reduction in food consumption. Overall, this study shows that real-time vibrotactile feedback may be a viable tool in interventions that aim to reduce eating rate. The long-term effectiveness of this form of feedback on satiation and food consumption, however, awaits further investigation.
Related Concept Videos
 01:30
Regulation of Food Intake
 01:16
Gastric Emptying
 01:24
Facial Feedback Hypothesis
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...