Related Experiment Video
Updated: Mar 7, 2026
Quantum State Engineering of Light with Continuous-wave Optical Parametric Oscillators
Published on: May 30, 2014
Phase reduction theory for hybrid nonlinear oscillators
Sho Shirasaka1, Wataru Kurebayashi2, Hiroya Nakao3
1Graduate School of Information Science and Engineering, Tokyo Institute of Technology, O-okayama 2-12-1, Meguro, Tokyo 152-8552, Japan.

Abstract:
Hybrid dynamical systems characterized by discrete switching of smooth dynamics have been used to model various rhythmic phenomena. However, the phase reduction theory, a fundamental framework for analyzing the synchronization of limit-cycle oscillations in rhythmic systems, has mostly been restricted to smooth dynamical systems. Here we develop a general phase reduction theory for weakly perturbed limit cycles in hybrid dynamical systems that facilitates analysis, control, and optimization of nonlinear oscillators whose smooth models are unavailable or intractable. On the basis of the generalized theory, we analyze injection locking of hybrid limit-cycle oscillators by periodic forcing and reveal their characteristic synchronization properties, such as ultrafast and robust entrainment to the periodic forcing and logarithmic scaling at the synchronization transition. We also illustrate the theory by analyzing the synchronization dynamics of a simple physical model of biped locomotion.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:18
Second Order systems II
 01:07
Damped Oscillations
Although friction and other non-conservative...
 01:30
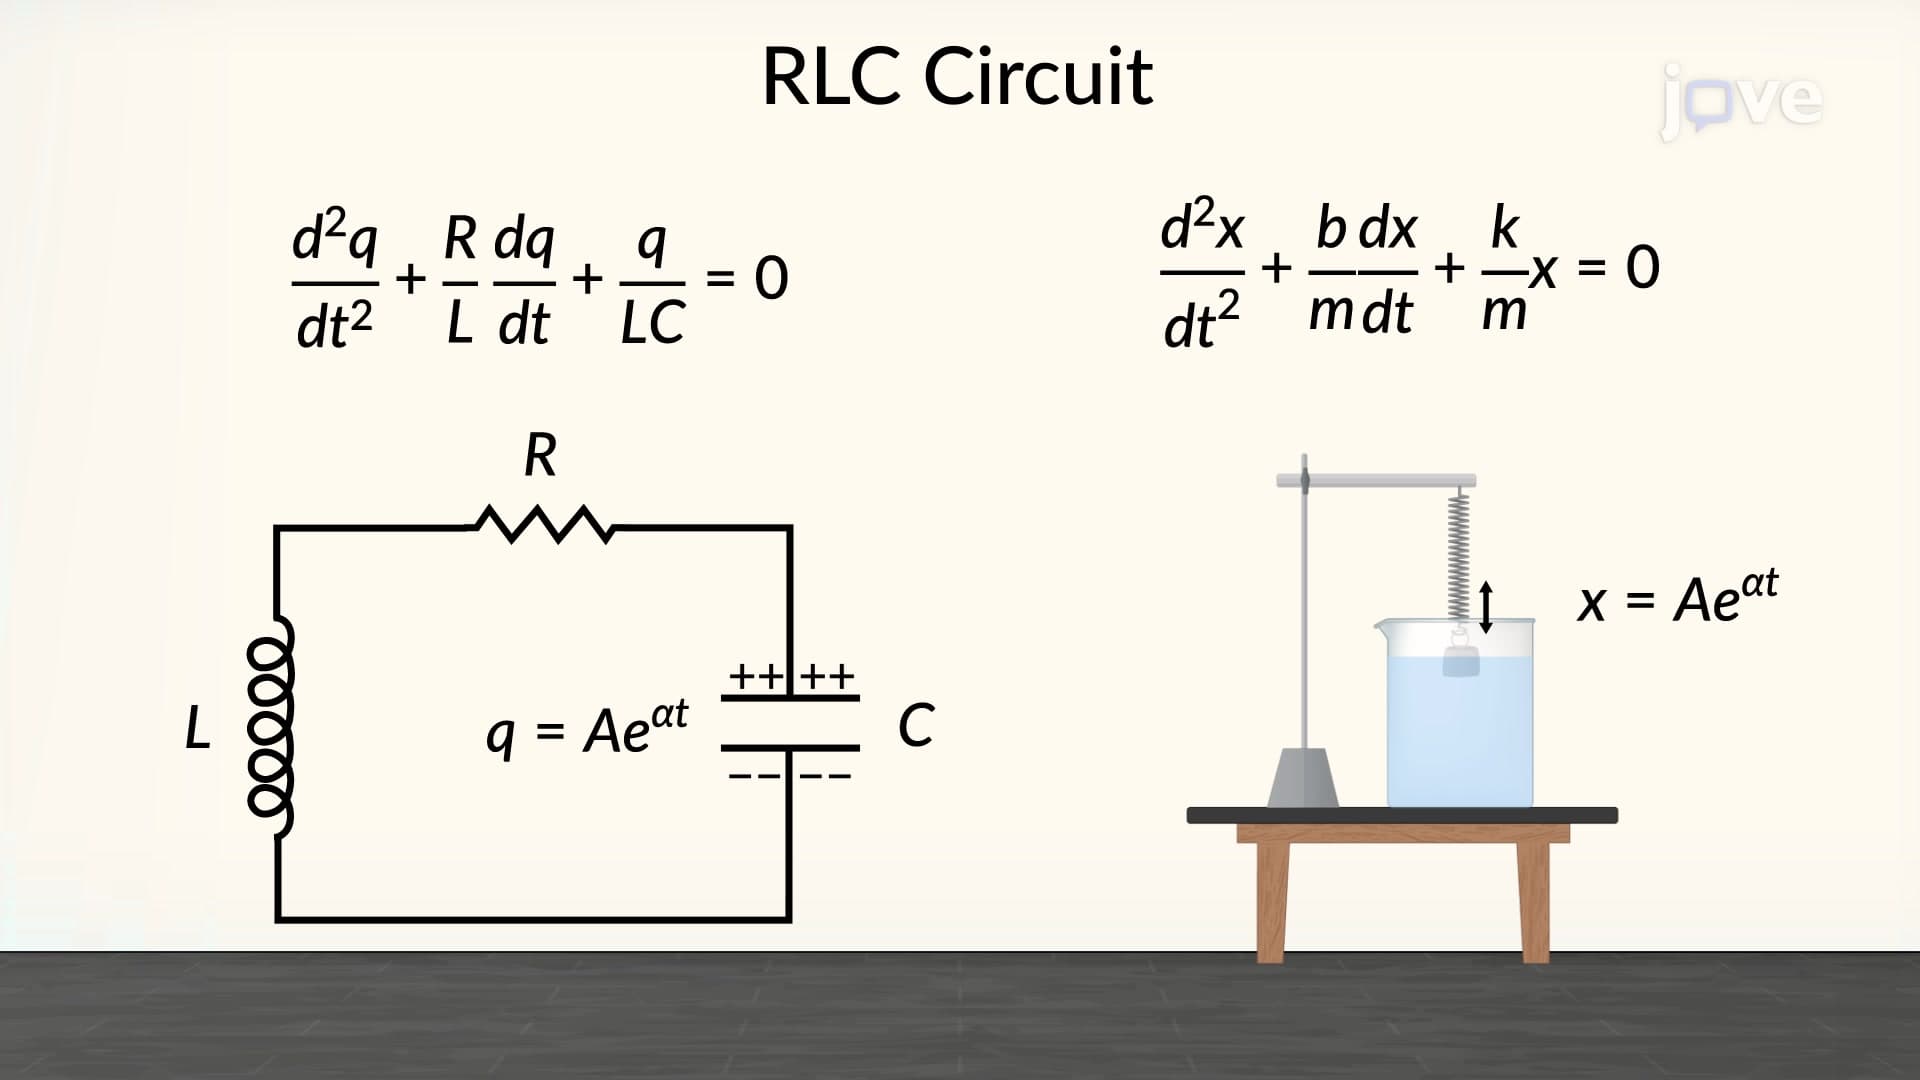
RLC Circuit as a Damped Oscillator
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:17
Design Example: Underdamped Parallel RLC Circuit
Starting with a fixed...