Inertia and universality of avalanche statistics: The case of slowly deformed amorphous solids

Kamran Karimi1, Ezequiel E Ferrero1, Jean-Louis Barrat1

  • 1Université Grenoble Alpes, LIPHY, F-38000 Grenoble, France and CNRS, LIPHY, F-38000 Grenoble, France.

Physical Review. E
|February 18, 2017
PubMed

Related Concept Videos

First Law: Particles in One-dimensional Equilibrium01:10

First Law: Particles in One-dimensional Equilibrium
Newton's first law of motion states that a body at rest remains at rest, or if in motion, remains in motion at constant velocity, unless acted on by a net external force. It also states that there must be a cause for any change in velocity (a change in either magnitude or direction) to occur. This cause is a net external force. For example, consider what happens to an object sliding along a rough horizontal surface. The object quickly grinds to a halt, due to the net force of friction. If...
8.3K
First Law: Particles in Two-dimensional Equilibrium01:18

First Law: Particles in Two-dimensional Equilibrium

Recall that a particle in equilibrium is one for which the external forces are balanced. Static equilibrium involves objects at rest, and dynamic equilibrium involves objects in motion without acceleration; but it is important to remember that these conditions are relative. For instance, an object may be at rest when viewed from one frame of reference, but that same object would appear to be in motion when viewed by someone moving at a constant velocity.
Newton's first law tells us about...
16.9K
Generalized Hooke's Law01:22

Generalized Hooke's Law

The generalized Hooke's Law is a broadened version of Hooke's Law, which extends to all types of stress and in every direction. Consider an isotropic material shaped into a cube subjected to multiaxial loading. In this scenario, normal stresses are exerted along the three coordinate axes. As a result of these stresses, the cubic shape deforms into a rectangular parallelepiped. Despite this deformation, the new shape maintains equal sides, and there is a normal strain in the direction of the...
2.9K
Elastic Collisions: Introduction01:00

Elastic Collisions: Introduction

An elastic collision is one that conserves both internal kinetic energy and momentum. Internal kinetic energy is the sum of the kinetic energies of the objects in a system. Truly elastic collisions can only be achieved with subatomic particles, such as electrons striking nuclei. Macroscopic collisions can be very nearly, but not quite, elastic, as some kinetic energy is always converted into other forms of energy such as heat transfer due to friction and sound. An example of a nearly...
15.4K
Collisions in Multiple Dimensions: Introduction01:05

Collisions in Multiple Dimensions: Introduction
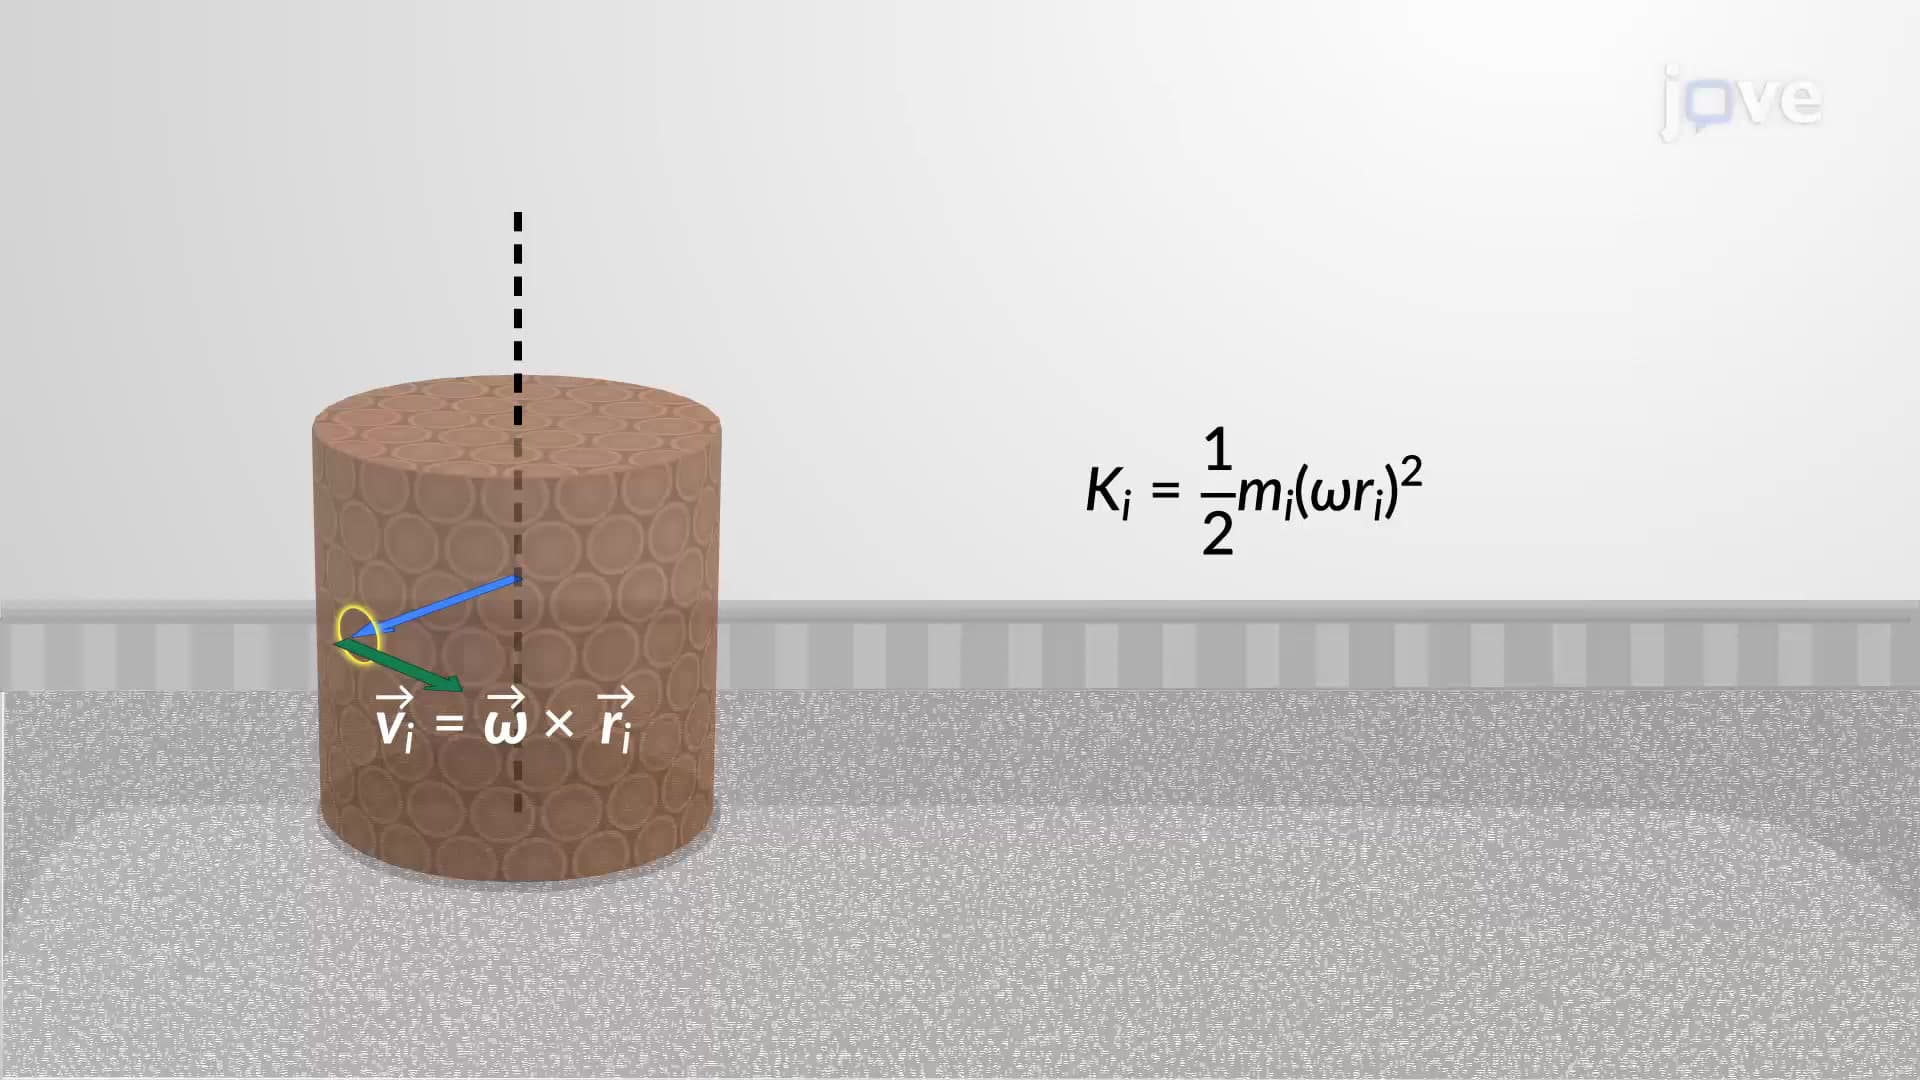
It is far more common for collisions to occur in two dimensions; that is, the initial velocity vectors are neither parallel nor antiparallel to each other. Let's see what complications arise from this. The first idea is that momentum is a vector. Like all vectors, it can be expressed as a sum of perpendicular components (usually, though not always, an x-component and a y-component, and a z-component if necessary). Thus, when the statement of conservation of momentum is written for a...
7.1K
Moment of Inertia01:14

Moment of Inertia

The comparability between linear and angular velocities, linear and angular accelerations, and the kinematic equations of translational and rotational motion can be extended to the concept of inertia.
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
19.8K