Robust and Low-Rank Representation for Fast Face Identification With Occlusions
Related Experiment Video
Updated: Mar 6, 2026

Author Spotlight: Assessment of Visual Acuity in Central Vision Loss Through Motion-Based Peripheral Vision Testing
Published on: February 23, 2024

Abstract:
In this paper, we propose an iterative method to address the face identification problem with block occlusions. Our approach utilizes a robust representation based on two characteristics in order to model contiguous errors (e.g., block occlusion) effectively. The first fits to the errors a distribution described by a tailored loss function. The second describes the error image as having a specific structure (resulting in low-rank in comparison with image size). We will show that this joint characterization is effective for describing errors with spatial continuity. Our approach is computationally efficient due to the utilization of the alternating direction method of multipliers. A special case of our fast iterative algorithm leads to the robust representation method, which is normally used to handle non-contiguous errors (e.g., pixel corruption). Extensive results on representative face databases (in constrained and unconstrained environments) document the effectiveness of our method over existing robust representation methods with respect to both identification rates and computational time.
More Related Videos


Related Concept Videos
 01:21
Association Areas of the Cortex
Prefrontal Association Area: This area is located in the frontal lobe and is involved in planning, decision-making, and moderating social behavior. It connects with primary motor areas,...
 01:20
Structural Classification of Joints
A fibrous joint is where the adjacent bones are united by fibrous connective...
 01:24
Prosopagnosia
 01:19
Routh-Hurwitz Criterion II
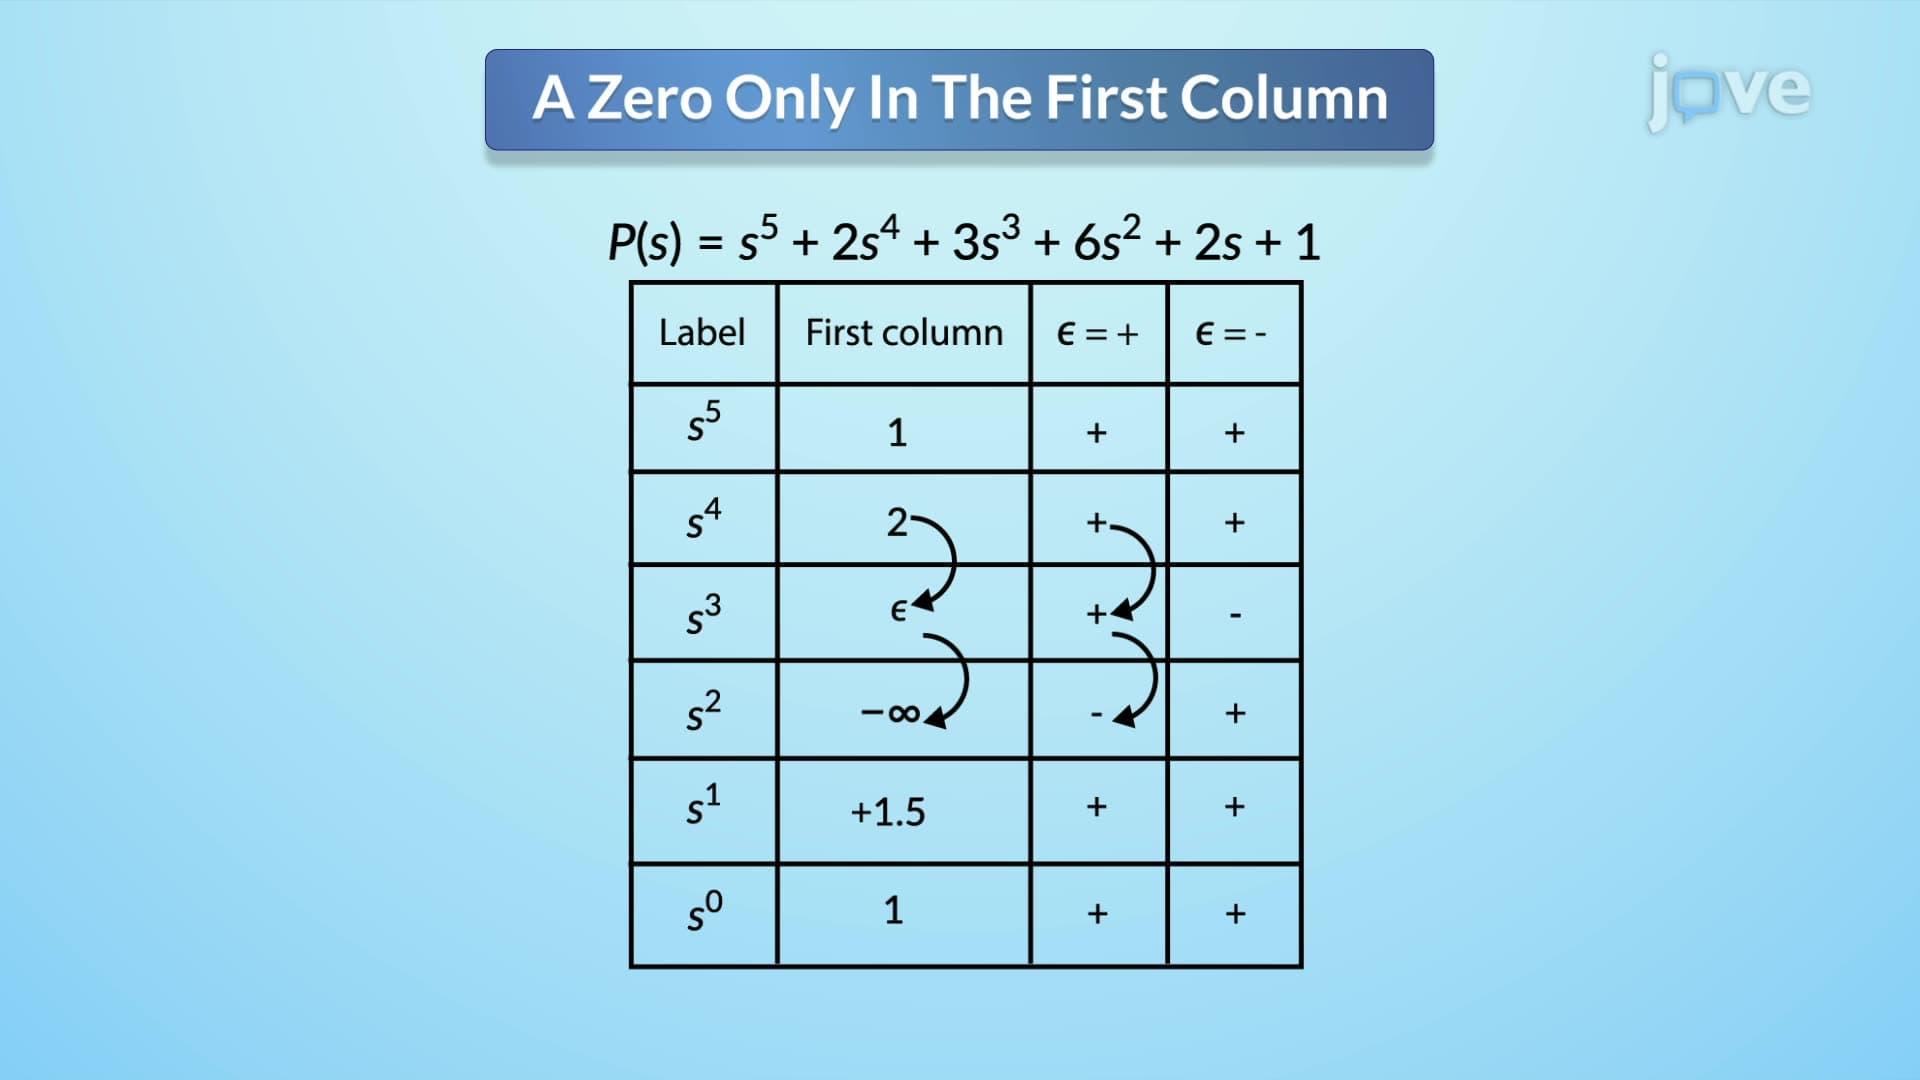
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:19
Masking and Demasking Agents
There are many masking agents, such as cyanide, fluoride, triethanolamine, thiourea, and 2,3-bis(sulfanyl)propan-1-ol (formerly 2,3-dimercapto-1-propanol), with the masking agent chosen based on...