Related Experiment Video
Updated: Mar 6, 2026
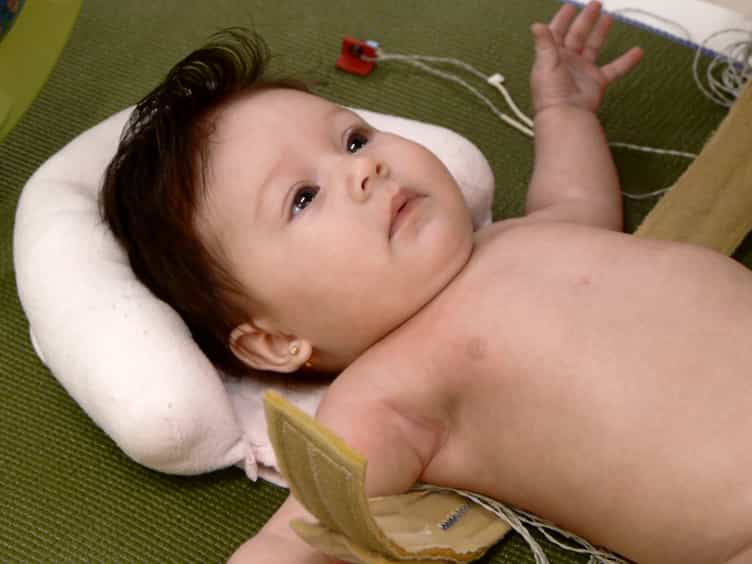

Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
Lower limb pose estimation for monitoring the kicking patterns of infants

Insights
This study presents a computer vision method to track infant leg movements from range images. The technique estimates joint trajectories for analyzing infant kicking kinematics and development.
Area of Science:
- Biomedical Engineering
- Computer Vision
- Developmental Pediatrics
Background:
- Infant spontaneous kicking patterns offer valuable insights into neurodevelopment.
- Accurate kinematic analysis requires precise tracking of joint trajectories.
- Existing methods may lack the precision or accessibility for infant movement studies.
Purpose of the Study:
- To develop and validate a computer vision-based method for estimating infant leg pose from range images.
- To enable quantitative analysis of infant kicking kinematics.
- To provide a tool for monitoring developmental changes in motor patterns.
Main Methods:
- Utilizing range imaging to capture infant leg data.
- Employing Robust Point Set Registration (RPSR) for articulated model fitting.
- Extracting joint trajectories over time from image sequences.
Main Results:
- The method successfully estimated joint trajectories for a robotic humanoid mimicking infant kicking.
- The technique was applied to real infant data, generating kinematic signal estimates.
- Validation demonstrated the feasibility of the approach for infant movement analysis.
Conclusions:
- The proposed computer vision method offers a viable approach for analyzing infant kicking kinematics.
- This technique can aid in the non-invasive monitoring of infant motor development.
- Further application can lead to earlier identification of developmental deviations.
Abstract:
Monitoring the spontaneous kicking patterns of infants can give insight into their development. A computer vision based method for estimating the pose of an infant's leg from range images is presented in this paper. After some manual inputs for initialization, the range data associated with the infant is extracted. The method uses Robust Point Set Registration (RPSR) to fit an articulated model to the subject in every frame in the sequence, thus it provides the joint trajectories over time of the kicking kinematics. For validation, the method is used to track the articulation of a robotic humanoid that was programmed to kick in a fashion similar to an infant. Furthermore, the method is applied to a sequence collected from an actual infant and the resultant signal estimates are presented.
More Related Videos
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
 08:40
Quantifying Arms and Legs Contributions during Repetitive Electrically-Assisted Sit-To-Stand Exercise in Paraplegics: A Pilot Study
Published on: November 11, 2022