Related Experiment Video
Updated: Mar 6, 2026
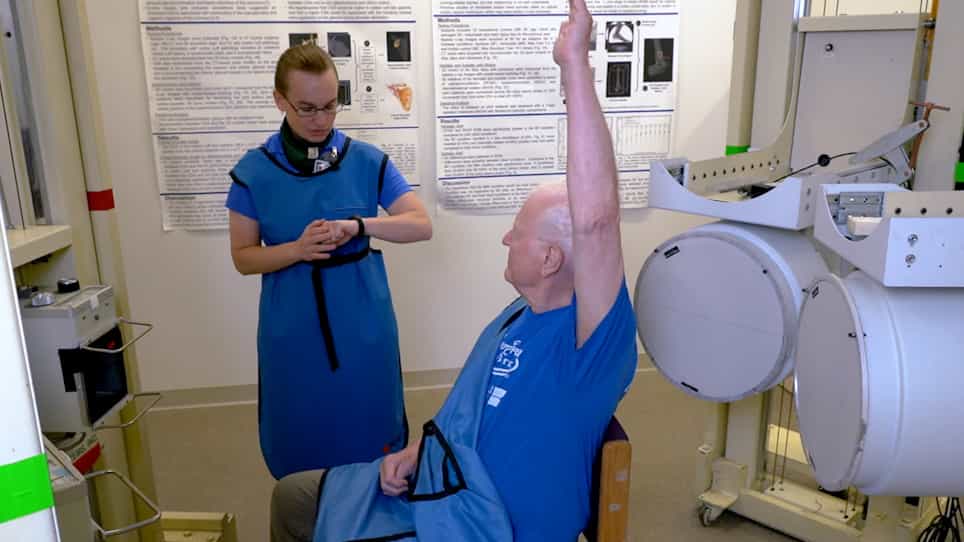
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
The sensitivity of shoulder muscle and joint force predictions to changes in joint kinematics: A Monte-Carlo analysis
Wen Wu1, Peter Vee Sin Lee1, David C Ackland1
1Department of Biomedical Engineering, University of Melbourne, Parkville, Victoria 3010, Australia.

Abstract:
Kinematics of the shoulder girdle obtained from non-invasive measurement systems such as video motion analysis, accelerometers and magnetic tracking sensors has been shown to be adversely affected by instrumentation measurement errors and skin motion artefact. The degree to which musculoskeletal model calculations of shoulder muscle and joint loading are influenced by variations in joint kinematics is currently not well understood. A three-dimensional musculoskeletal model of the upper limb was used to evaluate the sensitivity of shoulder muscle and joint force. Monte-Carlo analyses were performed by randomly perturbing scapular and humeral joint coordinates during abduction and flexion. Muscle and joint force calculations were generally most sensitive to changes in the kinematics of the humerus in elevation and of the scapula in medial-lateral rotation, and were least sensitive to changes in humerus plane of elevation and scapula protraction-retraction. Overall model sensitivity was greater during abduction than flexion, and the influence of specific kinematics perturbations varied from muscle to muscle. In general, muscles that generated greater force, such as the middle deltoid and subscapularis, were more sensitive to changes in shoulder kinematics. This study suggests that musculoskeletal model sensitivity to changes in kinematics is task-specific, and varies depending on the plane of motion. Calculations of shoulder muscle and joint function depend on reliable humeral and scapula motion data, particularly that of humeral elevation and scapula medial-lateral rotation. The findings in this study have implications for the use of kinematic data in musculoskeletal model development and simulations.
Related Concept Videos
 01:23
Muscles of the Shoulder
Anterior Thoracic Muscles
The anterior thoracic muscles include the serratus anterior, subclavius, and...
 01:30
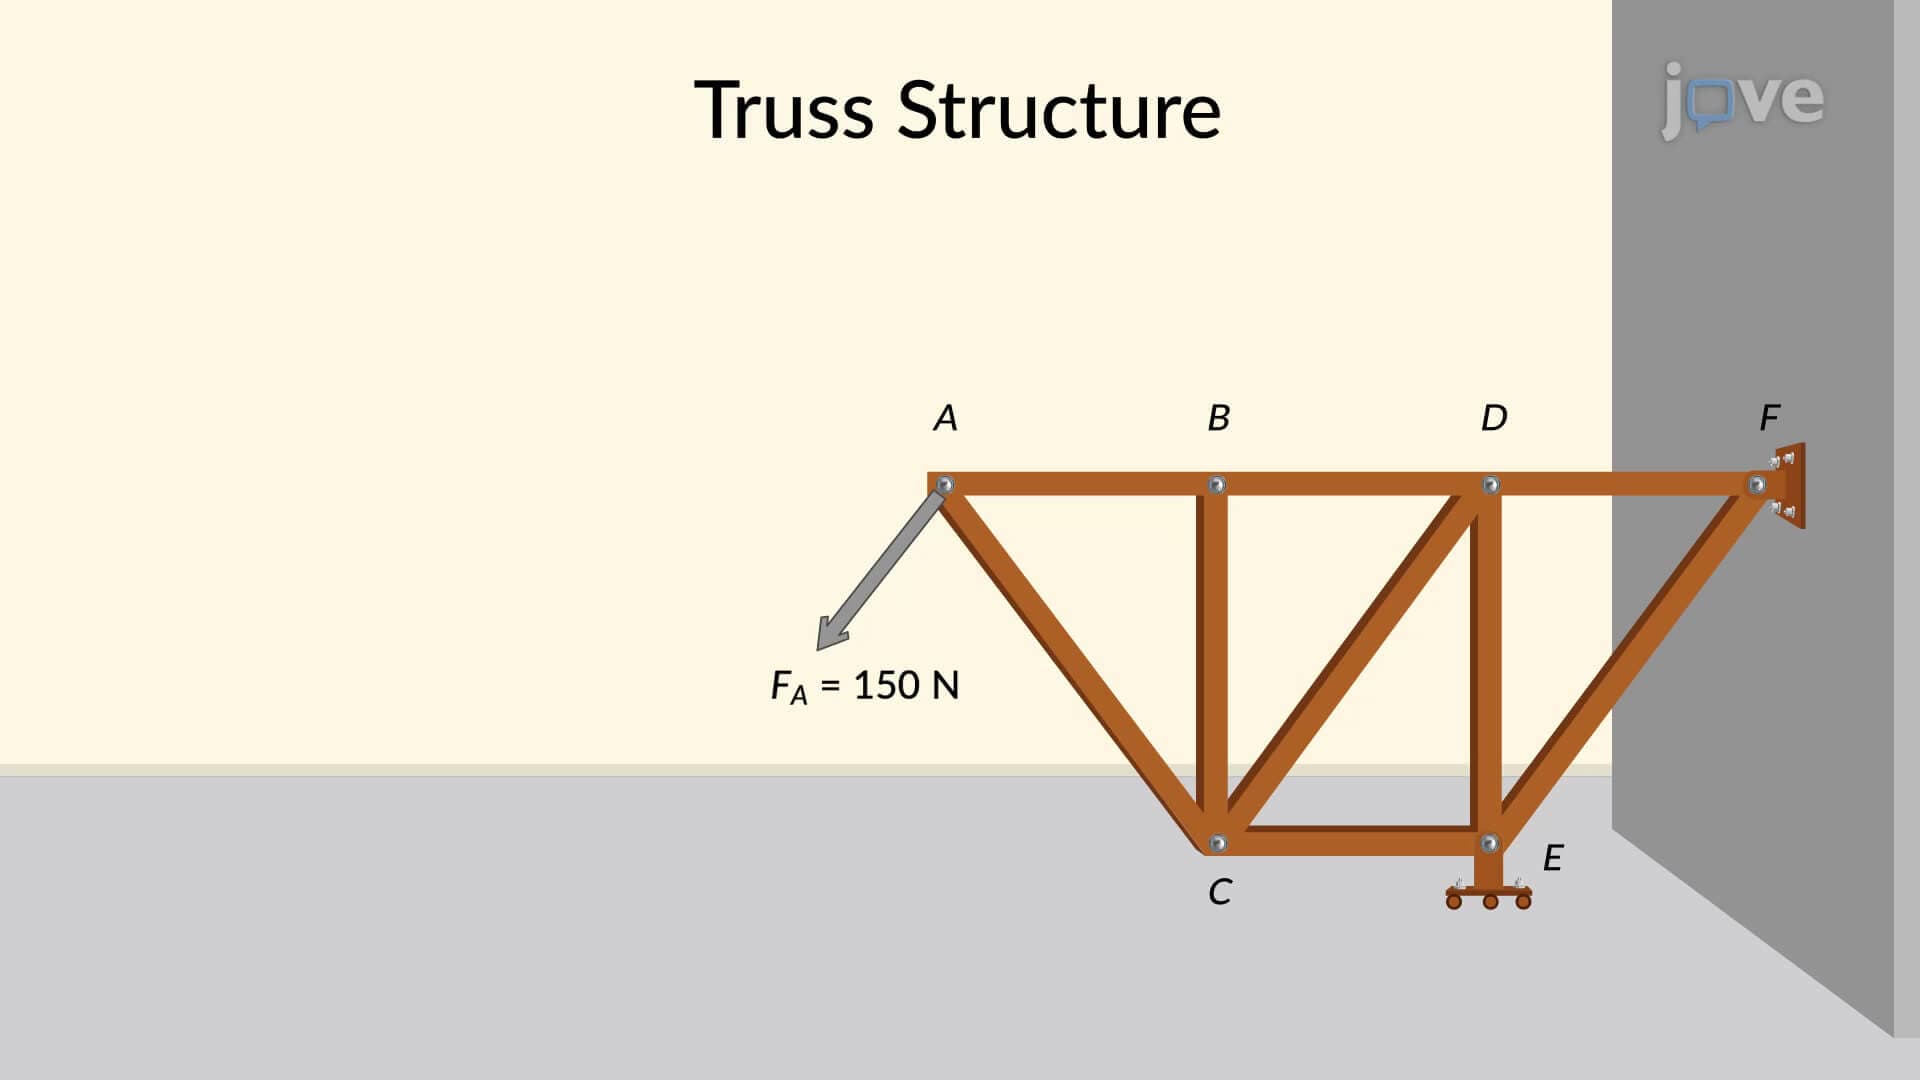
Method of Joints: Problem Solving II
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:15
Kinematic Equations: Problem Solving