Related Experiment Video
Updated: Mar 6, 2026


Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Design and stable flight of a 21 g insect-like tailless flapping wing micro air vehicle with angular rates feedback
Hoang Vu Phan1, Taesam Kang, Hoon Cheol Park
1Department of Advanced Technology Fusion, Artificial Muscle Research Center, Konkuk University, Seoul 05029, Republic of Korea.

Abstract:
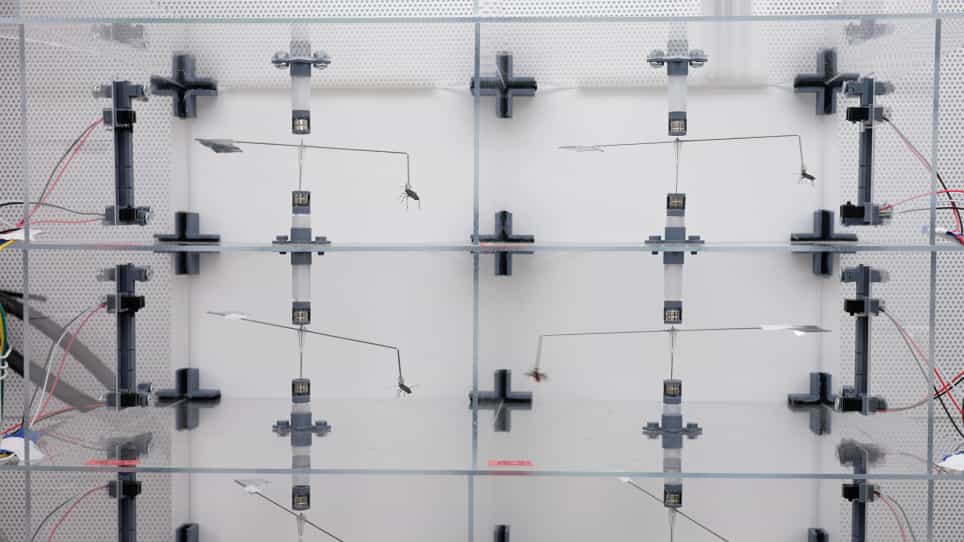
An insect-like tailless flapping wing micro air vehicle (FW-MAV) without feedback control eventually becomes unstable after takeoff. Flying an insect-like tailless FW-MAV is more challenging than flying a bird-like tailed FW-MAV, due to the difference in control principles. This work introduces the design and controlled flight of an insect-like tailless FW-MAV, named KUBeetle. A combination of four-bar linkage and pulley-string mechanisms was used to develop a lightweight flapping mechanism that could achieve a high flapping amplitude of approximately 190°. Clap-and-flings at dorsal and ventral stroke reversals were implemented to enhance vertical force. In the absence of a control surface at the tail, adjustment of the location of the trailing edges at the wing roots to modulate the rotational angle of the wings was used to generate control moments for the attitude control. Measurements by a 6-axis load cell showed that the control mechanism produced reasonable pitch, roll and yaw moments according to the corresponding control inputs. The control mechanism was integrated with three sub-micro servos to realize the pitch, roll and yaw controls. A simple PD feedback controller was implemented for flight stability with an onboard microcontroller and a gyroscope that sensed the pitch, roll and yaw rates. Several flight tests demonstrated that the tailless KUBeetle could successfully perform a vertical climb, then hover and loiter within a 0.3 m ground radius with small variations in pitch and roll body angles.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:23
Lift
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...