Related Experiment Video
Updated: Mar 6, 2026
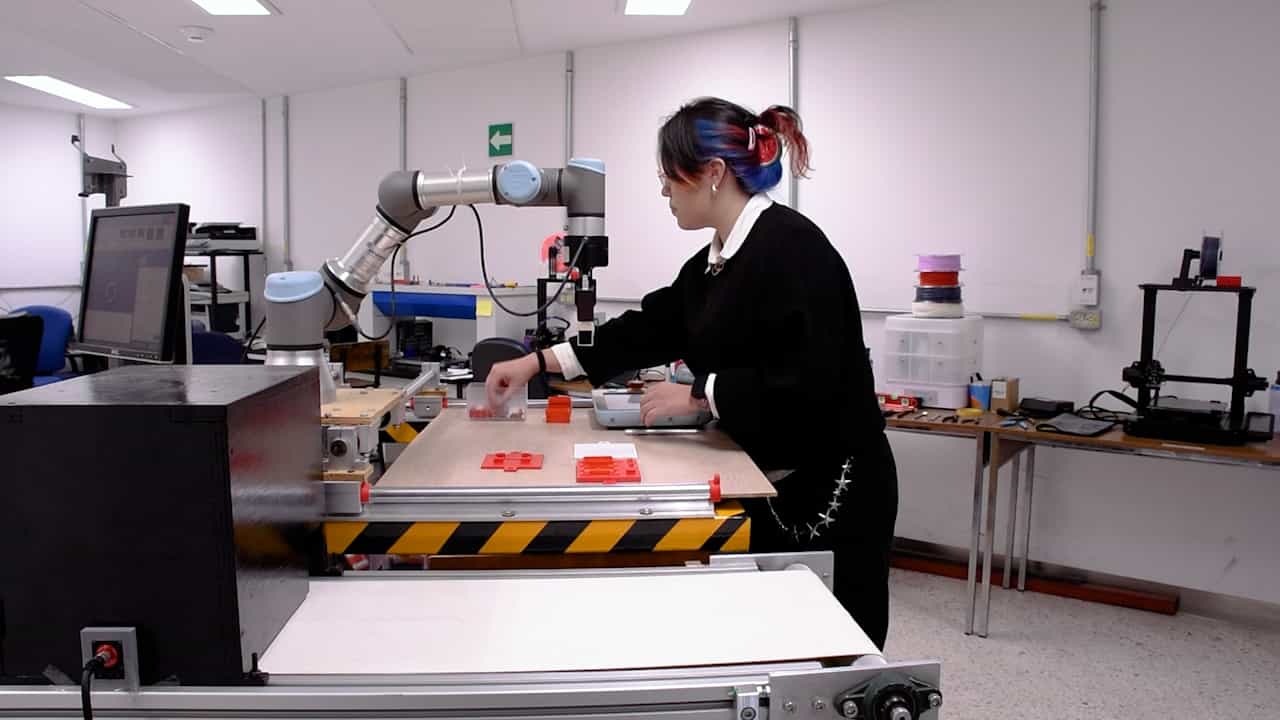

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Global finite-time adaptive control for uncalibrated robot manipulator based on visual servoing
1School of Electrical Engineering and Automation, Tianjin University, Tianjin 300072, PR China.

Abstract:
The paper addresses the finite-time convergence problem of a uncalibrated camera-robot system with uncertainties. These uncertainties include camera extrinsic and intrinsic parameters, robot dynamics and feature depth parameters, which are all considered as time-varying uncertainties. In order to achieve a better dynamic stability performance of the camera-robot system, a novel FTS adaptive controller is presented to cope with rapid convergence problem. Meanwhile, FTS adaptive laws are proposed to handle these uncertainties which exist both in robot and in camera model. The finite-time stability analysis is discussed in accordance with homogeneous theory and Lyapunov function formalism. The control method we proposed extends the asymptotic stability results of visual servoing control to a finite-time stability. Simulation has been conducted to demonstrate the performance of the trajectory tracking errors convergence under control of the proposed method.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:10
Control Systems
At the heart...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...