Related Experiment Video
Updated: Mar 6, 2026


Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Introduction of a computer-based method for automated planning of reduction paths under consideration of simulated
Jan Buschbaum1, Rainer Fremd2, Tim Pohlemann3
1Fachbereich Angewandte Ingenieurwissenschaften, Hochschule Kaiserslautern - University of Applied Sciences, Schoenstraße 11, 67659, Kaiserslautern, Germany. jan.buschbaum@hs-kl.de.

Purpose:
Reduction is a crucial step in the surgical treatment of bone fractures. Finding an optimal path for restoring anatomical alignment is considered technically demanding because collisions as well as high forces caused by surrounding soft tissues can avoid desired reduction movements. The repetition of reduction movements leads to a trial-and-error process which causes a prolonged duration of surgery. By planning an appropriate reduction path-an optimal sequence of target-directed movements-these problems should be overcome. For this purpose, a computer-based method has been developed.
Methods:
Using the example of simple femoral shaft fractures, 3D models are generated out of CT images. A reposition algorithm aligns both fragments by reconstructing their broken edges. According to the criteria of a deduced planning strategy, a modified A*-algorithm searches collision-free route of minimal force from the dislocated into the computed target position. Muscular forces are considered using a musculoskeletal reduction model (OpenSim model), and bone collisions are detected by an appropriate method.
Results:
Five femoral SYNBONE models were broken into different fracture classification types and were automatically reduced from ten randomly selected displaced positions. Highest mean translational and rotational error for achieving target alignment is [Formula: see text] and [Formula: see text]. Mean value and standard deviation of occurring forces are [Formula: see text] for M. tensor fasciae latae and [Formula: see text] for M. semitendinosus over all trials. These pathways are precise, collision-free, required forces are minimized, and thus regarded as optimal paths.
Conclusions:
A novel method for planning reduction paths under consideration of collisions and muscular forces is introduced. The results deliver additional knowledge for an appropriate tactical reduction procedure and can provide a basis for further navigated or robotic-assisted developments.


Related Concept Videos
 01:29
Relaxation of Skeletal Muscles
When an action potential reaches the axon terminal, it depolarizes the membrane and opens voltage-gated sodium channels. Sodium ions enter the cell, further depolarizing the presynaptic membrane. This depolarization causes voltage-gated calcium channels to open....
 01:22
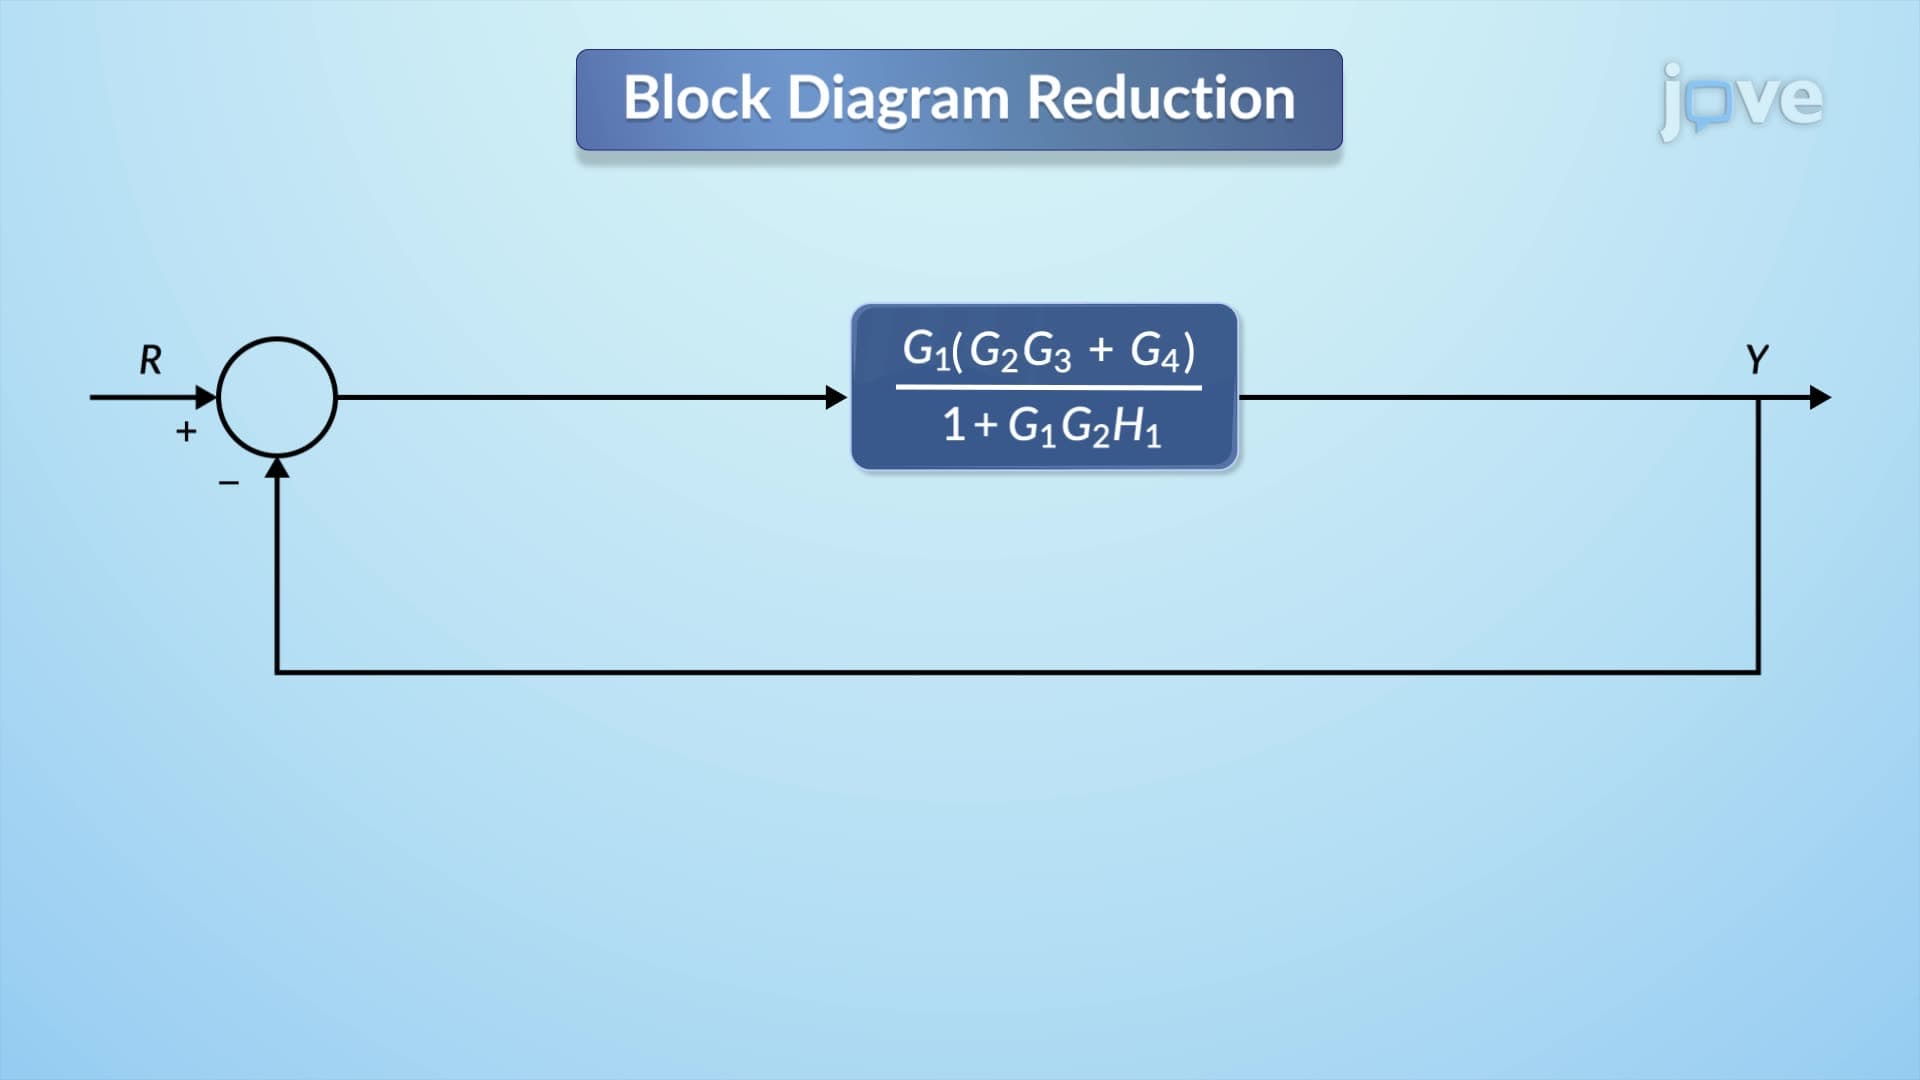
Block Diagram Reduction
The first step in this process is the identification and relocation of a branch point. A branch point, where a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
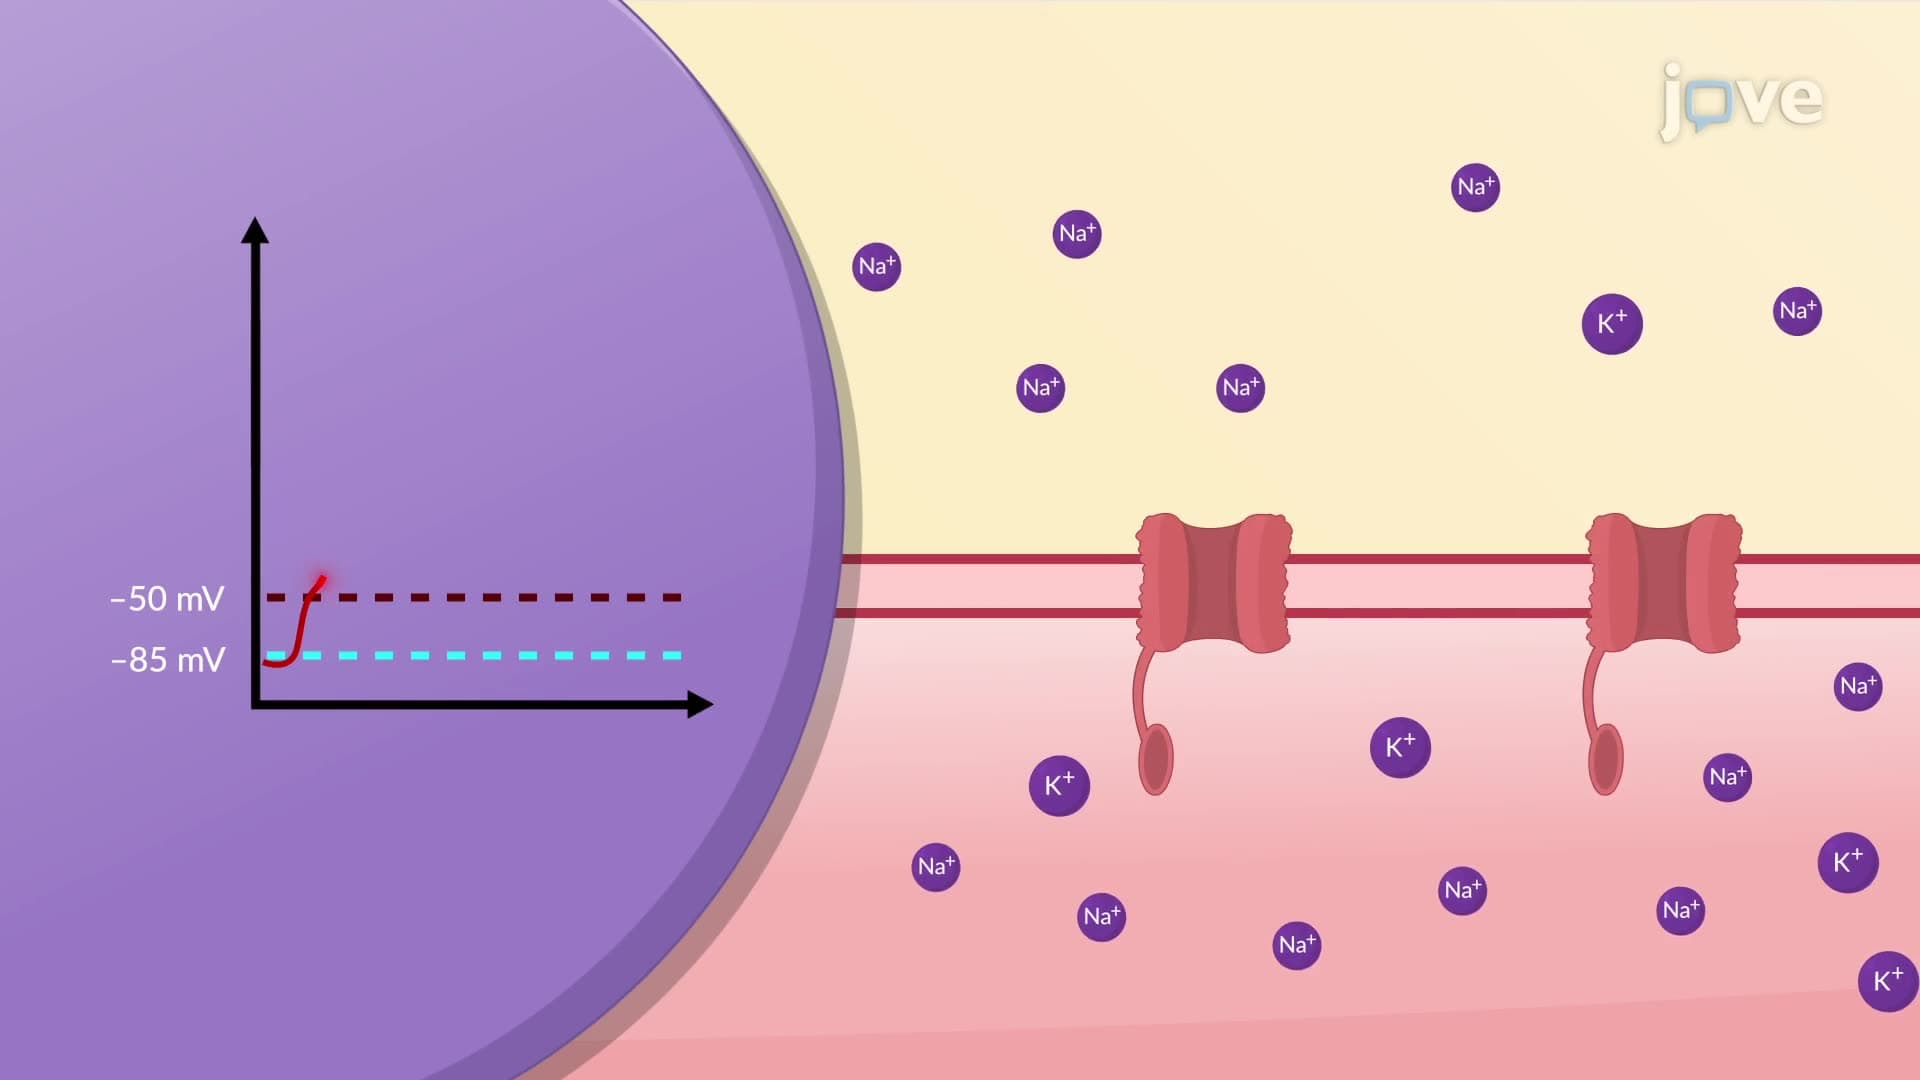
Generation of Action Potential in Skeletal Muscles
Like neurons, muscle cells are also regarded as excitable due to their capacity to change in response to stimuli, primarily due to voltage-gated ion channels embedded in their plasma membranes, which get activated by alterations in the...
 01:11
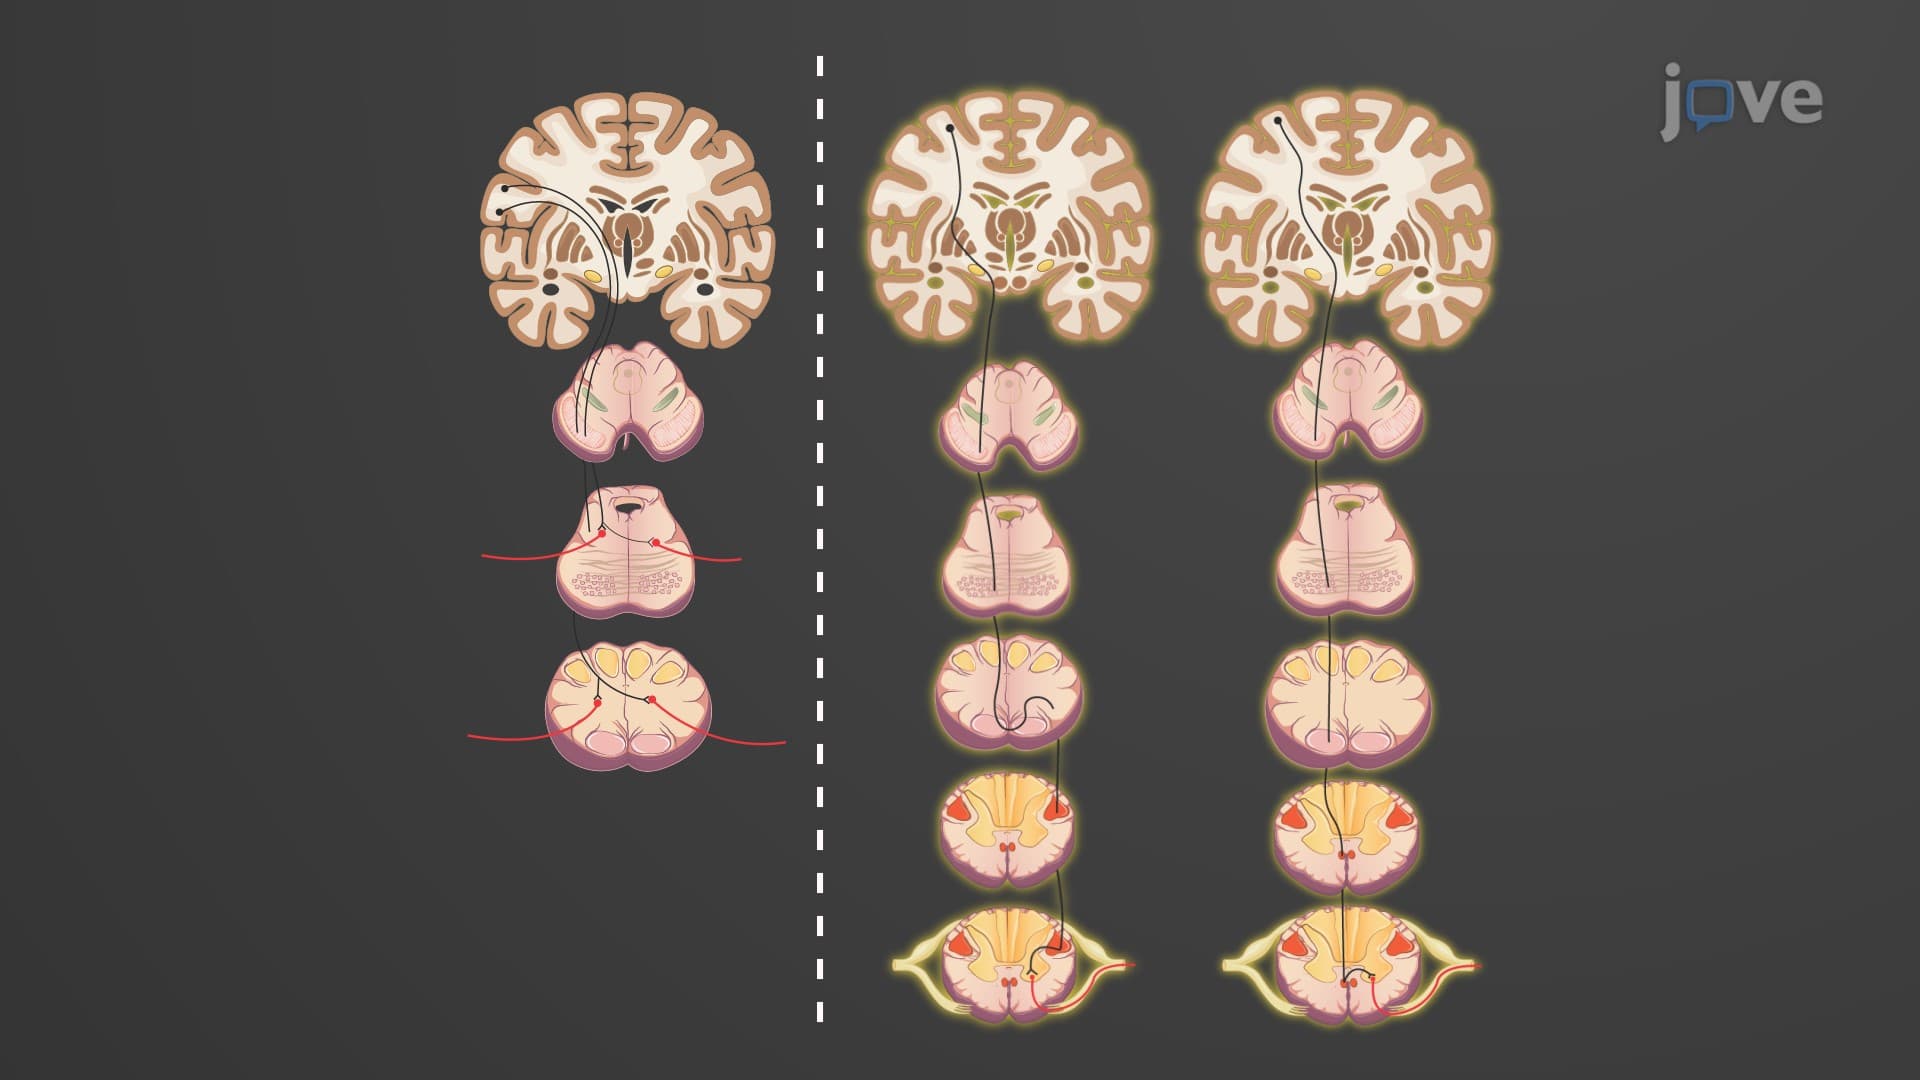
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...