Take-over again: Investigating multimodal and directional TORs to get the driver back into the loop
Related Experiment Video
Updated: Aug 13, 2026
Methods to Explore the Influence of Top-down Visual Processes on Motor Behavior
Published on: April 16, 2014
Sebastiaan Petermeijer1, Pavlo Bazilinskyy2, Klaus Bengler1
1Department for Ergonomics, Faculty of Mechanical Engineering, Technical University Munich, Boltzmannstraße 15, 85747 Garching, Germany.

Abstract:
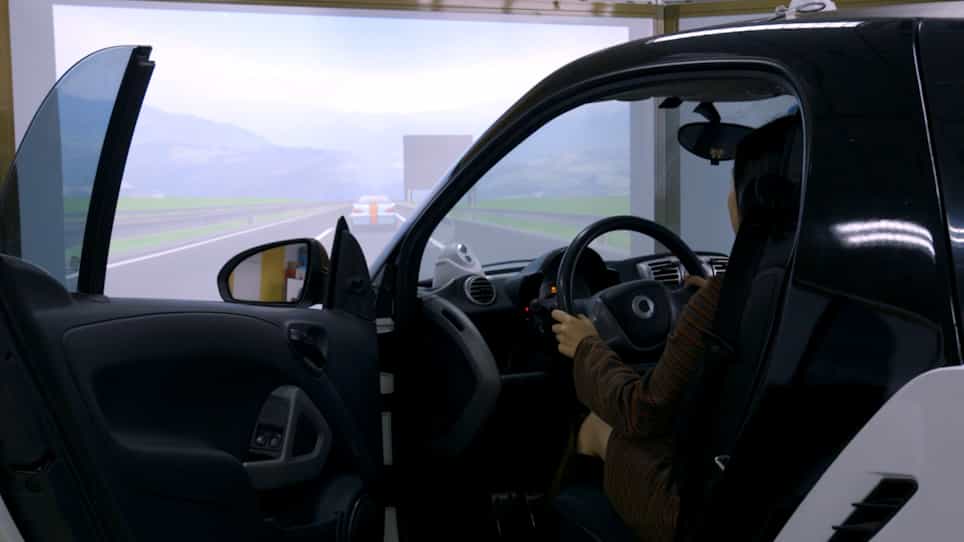
When a highly automated car reaches its operational limits, it needs to provide a take-over request (TOR) in order for the driver to resume control. The aim of this simulator-based study was to investigate the effects of TOR modality and left/right directionality on drivers' steering behaviour when facing a head-on collision without having received specific instructions regarding the directional nature of the TORs. Twenty-four participants drove three sessions in a highly automated car, each session with a different TOR modality (auditory, vibrotactile, and auditory-vibrotactile). Six TORs were provided per session, warning the participants about a stationary vehicle that had to be avoided by changing lane left or right. Two TORs were issued from the left, two from the right, and two from both the left and the right (i.e., nondirectional). The auditory stimuli were presented via speakers in the simulator (left, right, or both), and the vibrotactile stimuli via a tactile seat (with tactors activated at the left side, right side, or both). The results showed that the multimodal TORs yielded statistically significantly faster steer-touch times than the unimodal vibrotactile TOR, while no statistically significant differences were observed for brake times and lane change times. The unimodal auditory TOR yielded relatively low self-reported usefulness and satisfaction ratings. Almost all drivers overtook the stationary vehicle on the left regardless of the directionality of the TOR, and a post-experiment questionnaire revealed that most participants had not realized that some of the TORs were directional. We conclude that between the three TOR modalities tested, the multimodal approach is preferred. Moreover, our results show that directional auditory and vibrotactile stimuli do not evoke a directional response in uninstructed drivers. More salient and semantically congruent cues, as well as explicit instructions, may be needed to guide a driver into a specific direction during a take-over scenario.

Related Concept Videos
 01:10
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:13
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:17
Rolling Resistance: Problem Solving
 01:15
Torque Free Motion
 01:09
Transmission Shafts: Problem Solving
Next, use bending moment diagrams for the shaft to...
 01:25
Maximizing the Directional Derivative