Improving Robot Motor Learning with Negatively Valenced Reinforcement Signals
Related Experiment Video
Updated: Mar 4, 2026
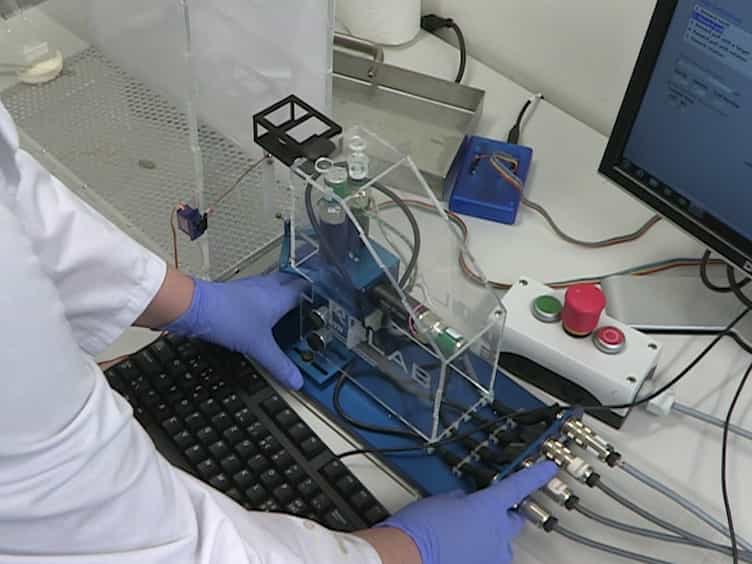
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
Nicolás Navarro-Guerrero1, Robert J Lowe2,3, Stefan Wermter1
1Knowledge Technology, Informatics Department, University of Hamburg, Hamburg, Germany.

Abstract:
Both nociception and punishment signals have been used in robotics. However, the potential for using these negatively valenced types of reinforcement learning signals for robot learning has not been exploited in detail yet. Nociceptive signals are primarily used as triggers of preprogrammed action sequences. Punishment signals are typically disembodied, i.e., with no or little relation to the agent-intrinsic limitations, and they are often used to impose behavioral constraints. Here, we provide an alternative approach for nociceptive signals as drivers of learning rather than simple triggers of preprogrammed behavior. Explicitly, we use nociception to expand the state space while we use punishment as a negative reinforcement learning signal. We compare the performance-in terms of task error, the amount of perceived nociception, and length of learned action sequences-of different neural networks imbued with punishment-based reinforcement signals for inverse kinematic learning. We contrast the performance of a version of the neural network that receives nociceptive inputs to that without such a process. Furthermore, we provide evidence that nociception can improve learning-making the algorithm more robust against network initializations-as well as behavioral performance by reducing the task error, perceived nociception, and length of learned action sequences. Moreover, we provide evidence that punishment, at least as typically used within reinforcement learning applications, may be detrimental in all relevant metrics.
Related Concept Videos
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:18
Positive and Negative Feedback Loops
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:27
Punishment
Punishment can be positive or negative. Positive punishment involves adding an undesirable stimulus, such as scolding, to decrease a behavior. Negative punishment involves removing a desirable stimulus, such as taking away a favorite toy, to decrease behavior....
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...