Related Experiment Video
Updated: Mar 4, 2026


Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Template for the neural control of directed stepping generalized to all legs of MantisBot
Nicholas S Szczecinski1, Roger D Quinn
1Case Western Reserve University, 10900 Euclid Avenue, Cleveland, OH 44106, United States of America.

Abstract:
We previously developed a neural controller for one leg of our six-legged robot, MantisBot, that could direct locomotion toward a goal by modulating leg-local reflexes with simple descending commands from a head sensor. In this work, we successfully apply an automated method to tune the control network for all three pairs of legs of our hexapod robot MantisBot in only 90 s with a desktop computer. Each foot's motion changes appropriately as the body's intended direction of travel changes. In addition, several results from studies of walking insects are captured by this model. This paper both demonstrates the broad applicability of this control method for robots, and suggests neural mechanisms underlying observations from walking insects.
More Related Videos
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
 07:28
Author Spotlight: Using the MouseWalker to Quantify Locomotor Dysfunction in a Mouse Model of Spinal Cord Injury
Published on: March 24, 2023
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:11
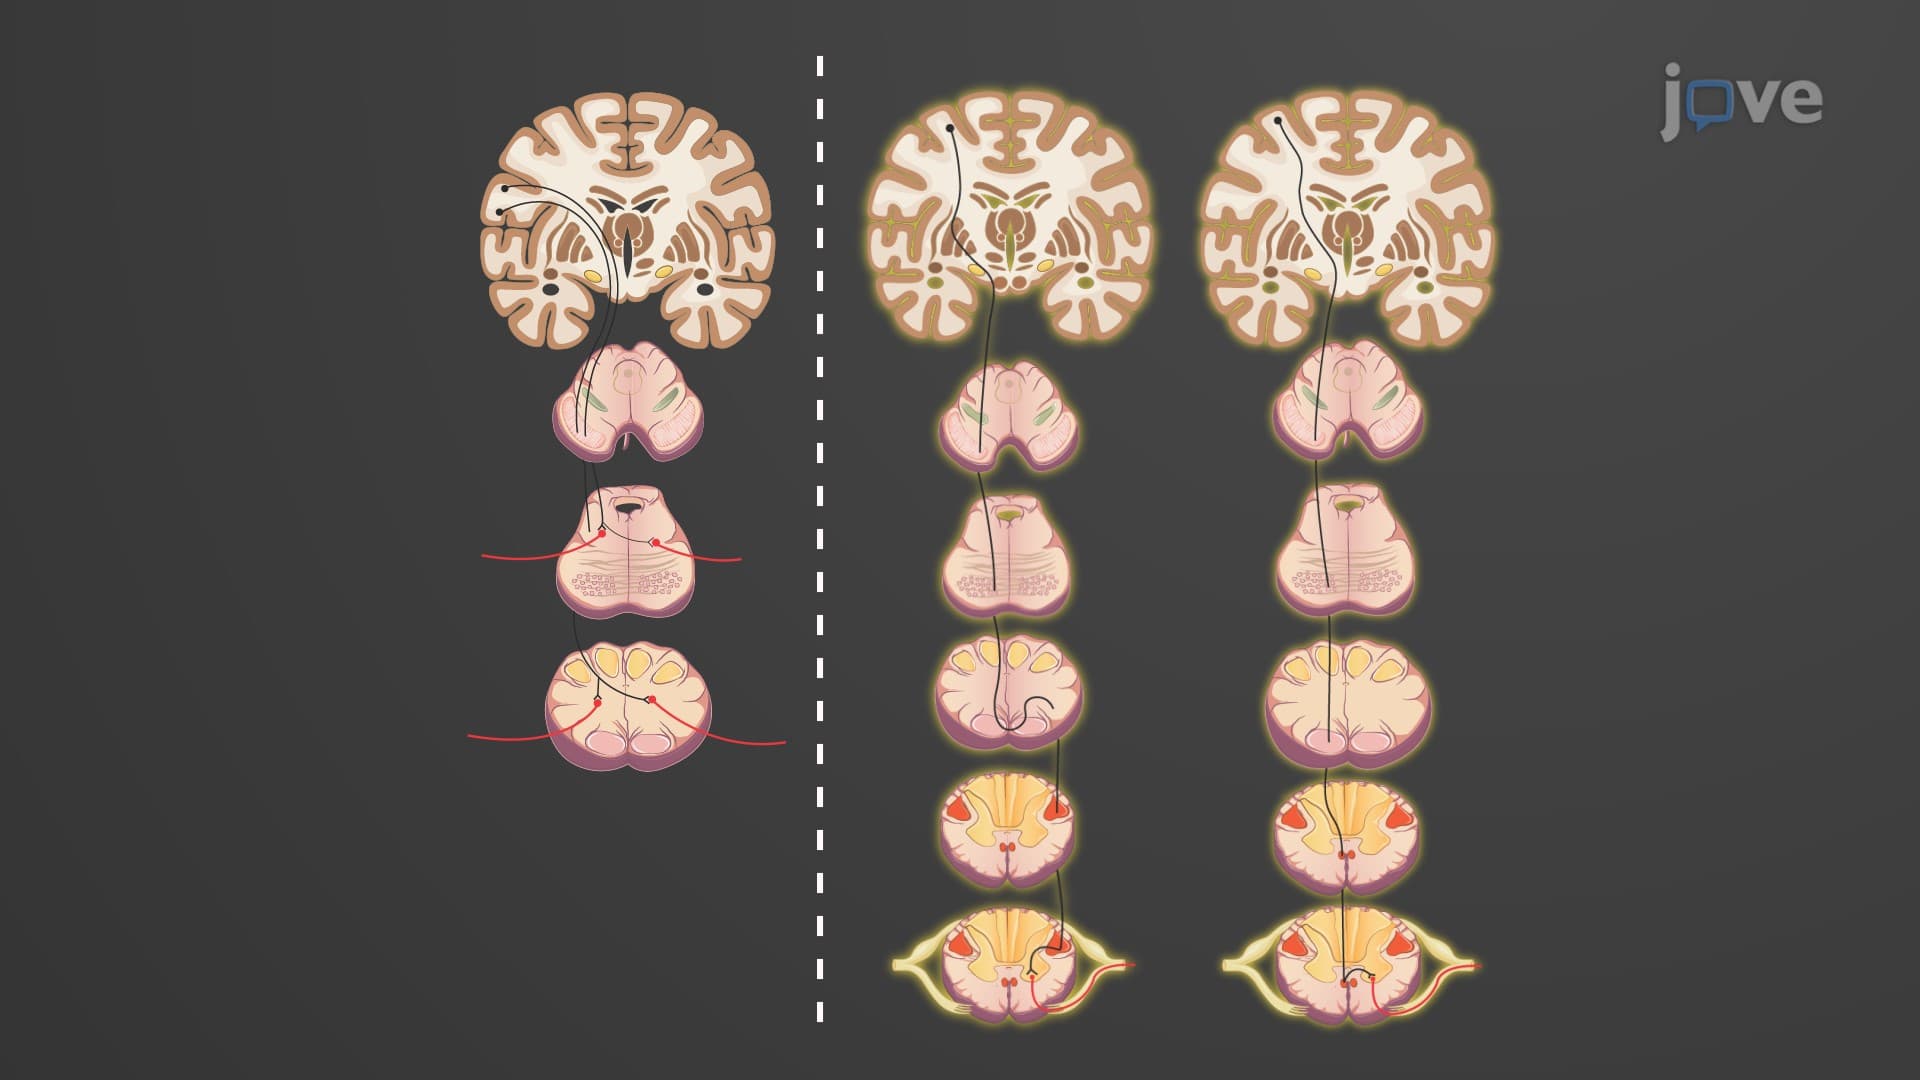
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:28
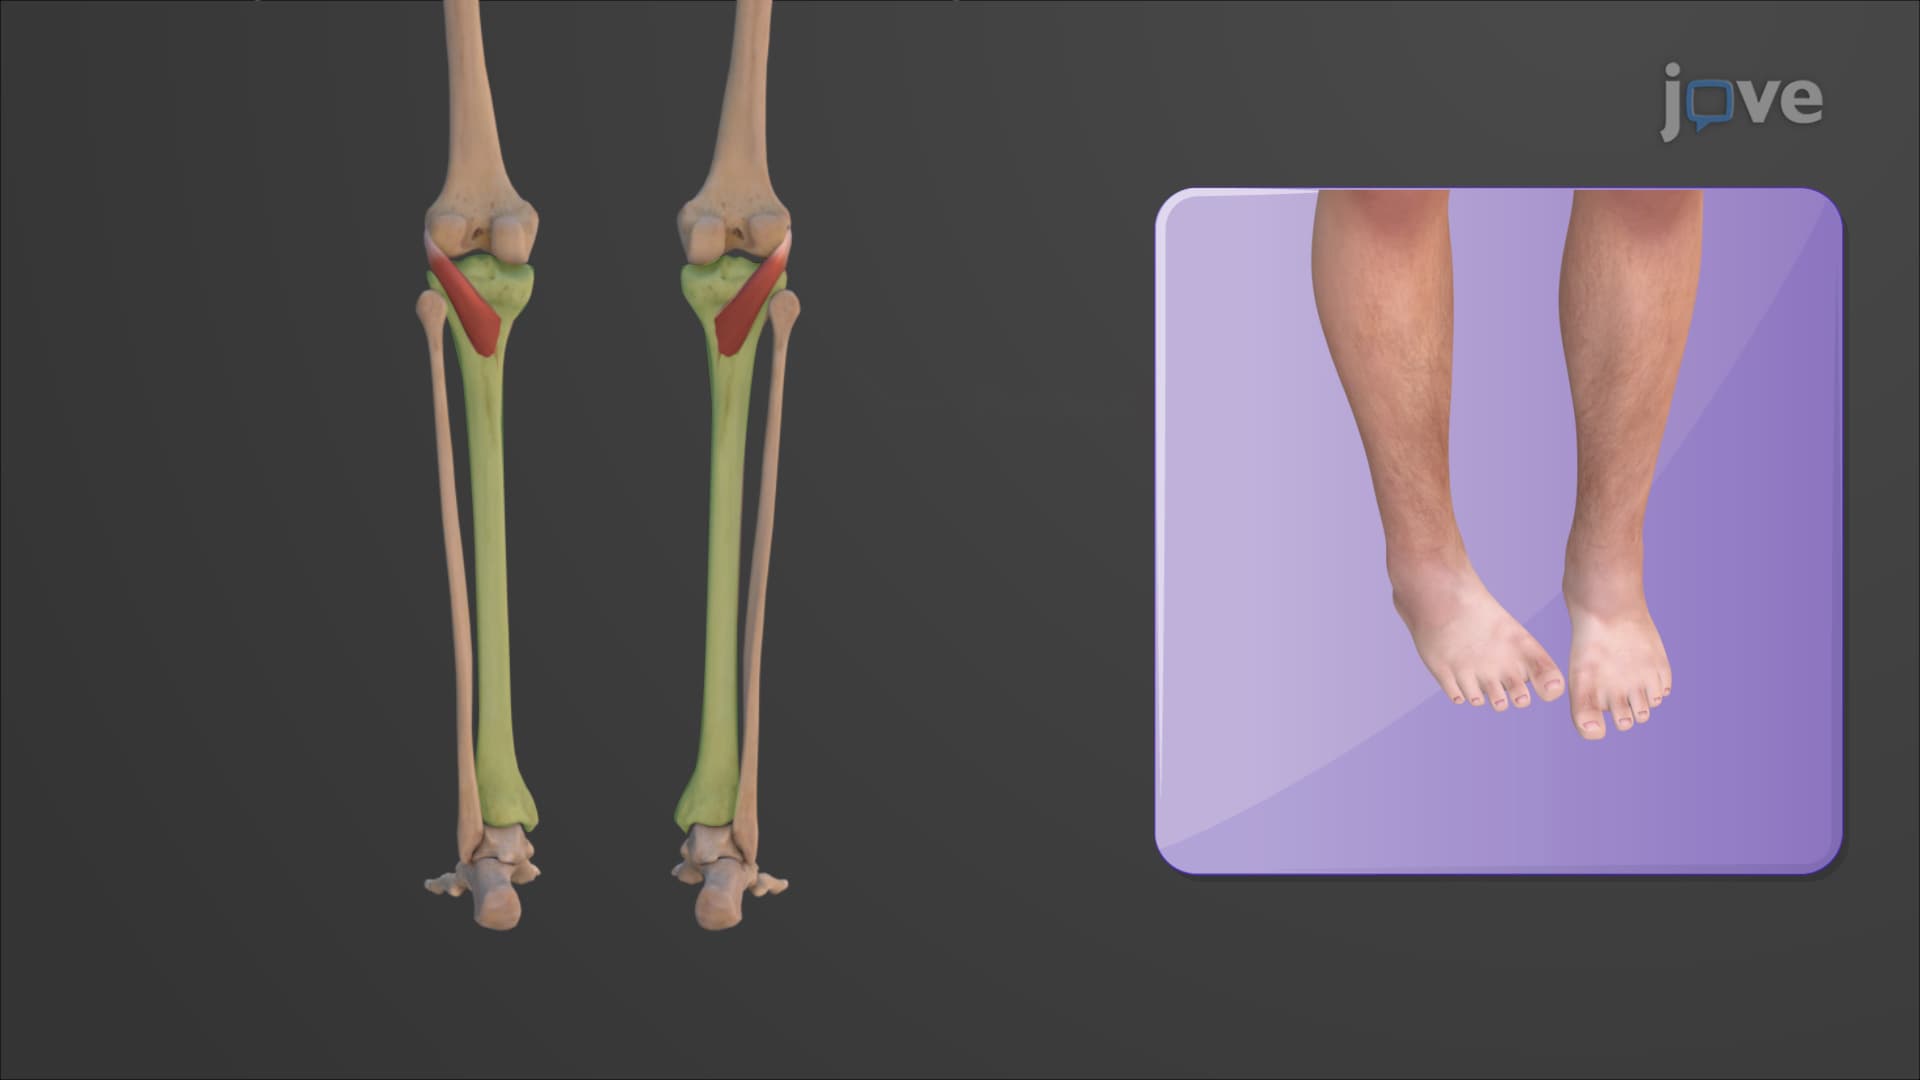
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...