Related Experiment Video
Updated: Mar 3, 2026
Pavlovian Conditioned Approach Training in Rats
Published on: February 4, 2016
Learning to Predict Consequences as a Method of Knowledge Transfer in Reinforcement Learning

Abstract:
The reinforcement learning (RL) paradigm allows agents to solve tasks through trial-and-error learning. To be capable of efficient, long-term learning, RL agents should be able to apply knowledge gained in the past to new tasks they may encounter in the future. The ability to predict actions' consequences may facilitate such knowledge transfer. We consider here domains where an RL agent has access to two kinds of information: agent-centric information with constant semantics across tasks, and environment-centric information, which is necessary to solve the task, but with semantics that differ between tasks. For example, in robot navigation, environment-centric information may include the robot's geographic location, while agent-centric information may include sensor readings of various nearby obstacles. We propose that these situations provide an opportunity for a very natural style of knowledge transfer, in which the agent learns to predict actions' environmental consequences using agent-centric information. These predictions contain important information about the affordances and dangers present in a novel environment, and can effectively transfer knowledge from agent-centric to environment-centric learning systems. Using several example problems including spatial navigation and network routing, we show that our knowledge transfer approach can allow faster and lower cost learning than existing alternatives.
More Related Videos
 08:05
A Prediction Error-driven Retrieval Procedure for Destabilizing and Rewriting Maladaptive Reward Memories in Hazardous Drinkers
Published on: January 5, 2018
 11:20
Recording Single Neurons' Action Potentials from Freely Moving Pigeons Across Three Stages of Learning
Published on: June 2, 2014
Related Concept Videos
 01:22
Purposive Learning
 01:12
Observational Learning
 01:24
Generalization, Discrimination, and Extinction
Generalization occurs when a behavior reinforced in one context is performed in similar situations. For instance, a student who studies diligently for calculus and receives excellent grades might apply the same study habits to psychology and history, expecting similar results. Generalization shows how learning in one setting can influence behavior in...
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:08
Timing and Consequences on Behavior
Humans, however, can respond to delayed reinforcers. We often make decisions between immediate small rewards and delayed larger rewards. This ability to delay gratification is a significant...
 01:06
Law of Effect
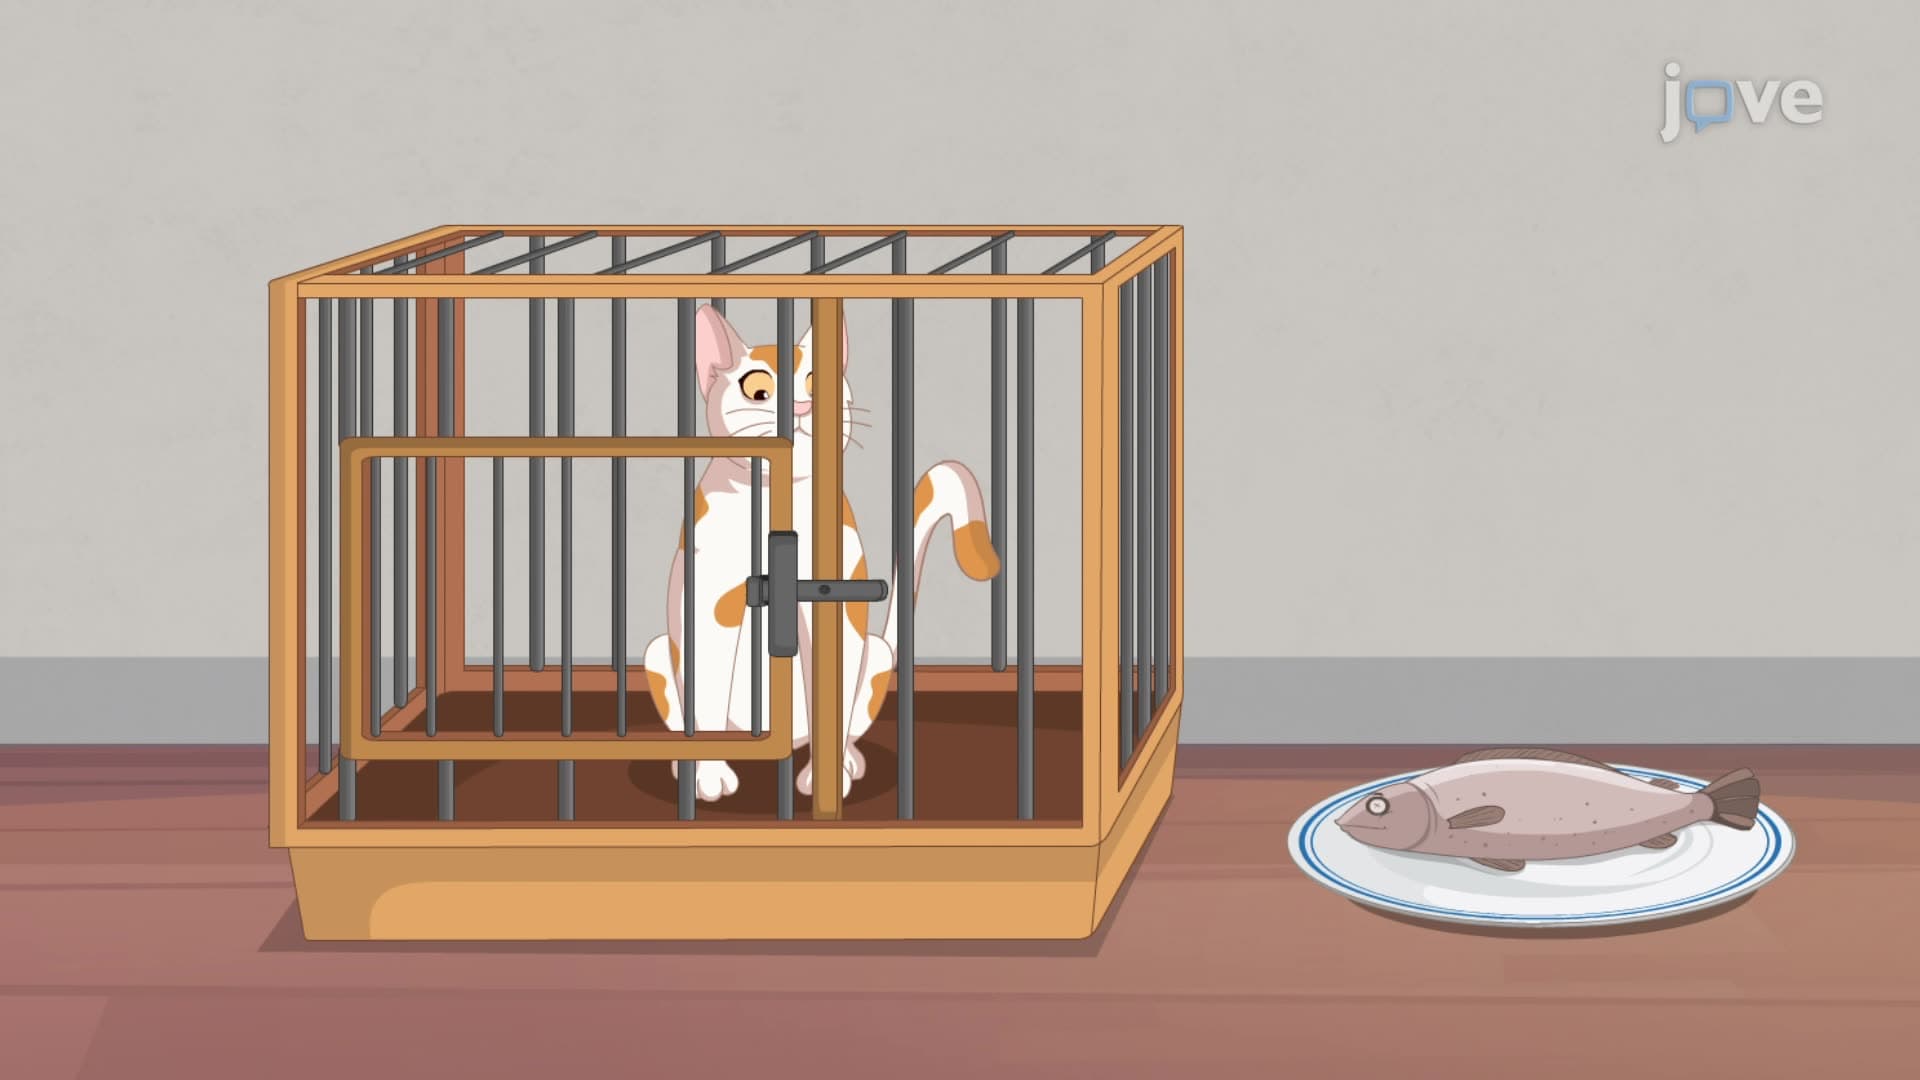
Edward Thorndike's foundational work involved studying learning in animals, particularly using puzzle...