A variable stiffness dielectric elastomer actuator based on electrostatic chucking
Related Experiment Video
Updated: Mar 3, 2026
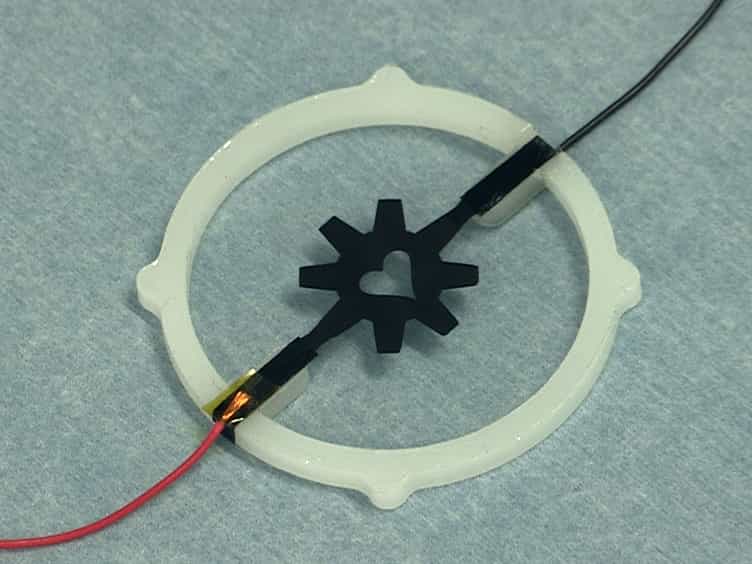
Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Hiroya Imamura1, Kevin Kadooka, Minoru Taya
1Technology and R&D Division, Nabtesco Corporation, Chiyoda-ku, Tokyo, 1020093, Japan.

Abstract:
Dielectric elastomer actuators (DEA) are one type of promising artificial muscle; however, applications of bending-type DEA for robotic end-effectors may be limited by their low stiffness and ability to resist external loads without buckling. Unimorph DEA can produce large out-of-plane deformation suitable for use as robotic end effectors; however, design of such actuators for large displacement comes at the cost of low stiffness and blocking force. This work proposes and demonstrates a variable stiffness dielectric elastomer actuator (VSDEA) consisting of a plurality of unimorph DEA units operating in parallel, which can exhibit variable electrostatic chucking to modulate the structure's bending stiffness. The unimorph DEA units are additively manufactured using a high-resolution pneumatic dispenser, and VSDEA comprising various numbers of units are assembled. The performance of the DEA units and VSDEA are compared to model predictions, exhibiting a maximum stiffness change of 39.2×. A claw actuator comprising two VSDEA and weighing 0.6 grams is demonstrated grasping and lifting a 10 gram object.
More Related Videos

Related Concept Videos
 01:27
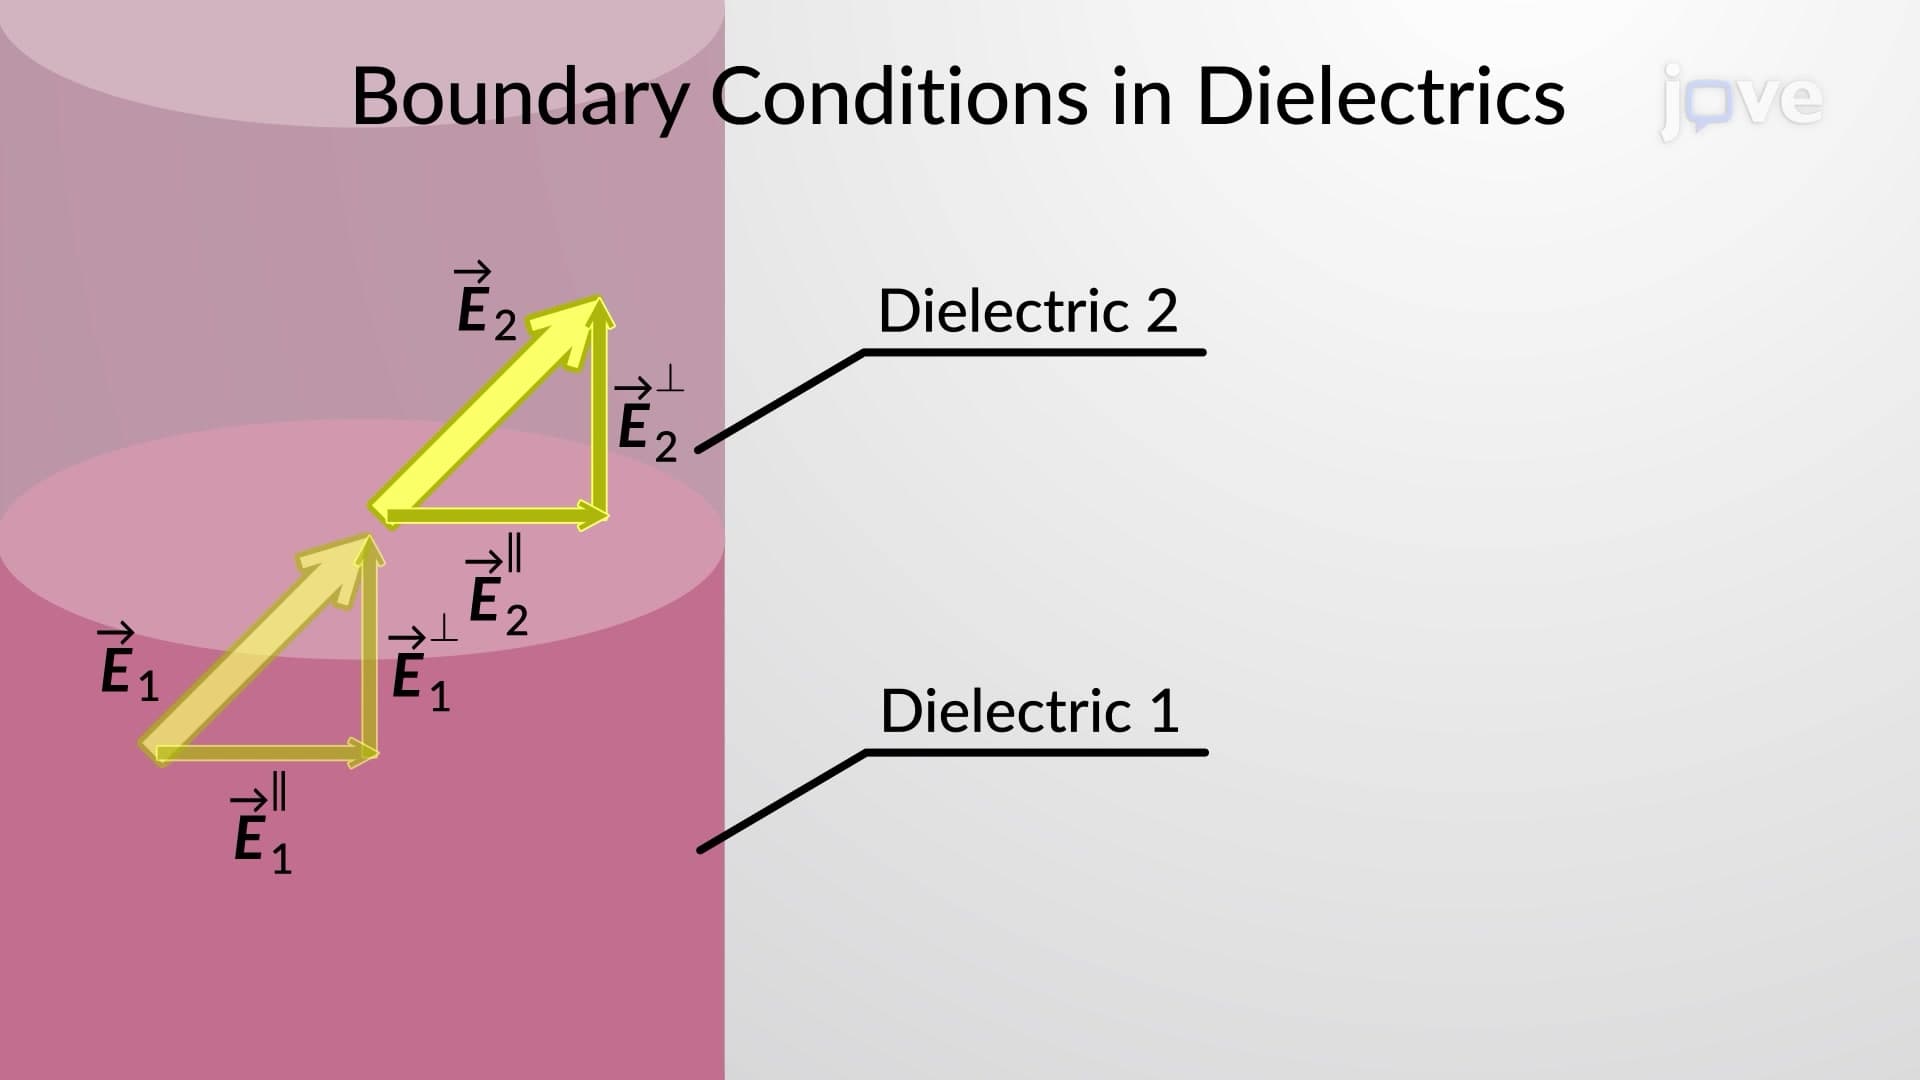
Electrostatic Boundary Conditions in Dielectrics
Consider a case where both the mediums across a boundary are two different dielectric materials. Recall that the electric field and electric displacement are proportional and related through the material's permittivity....
 01:18
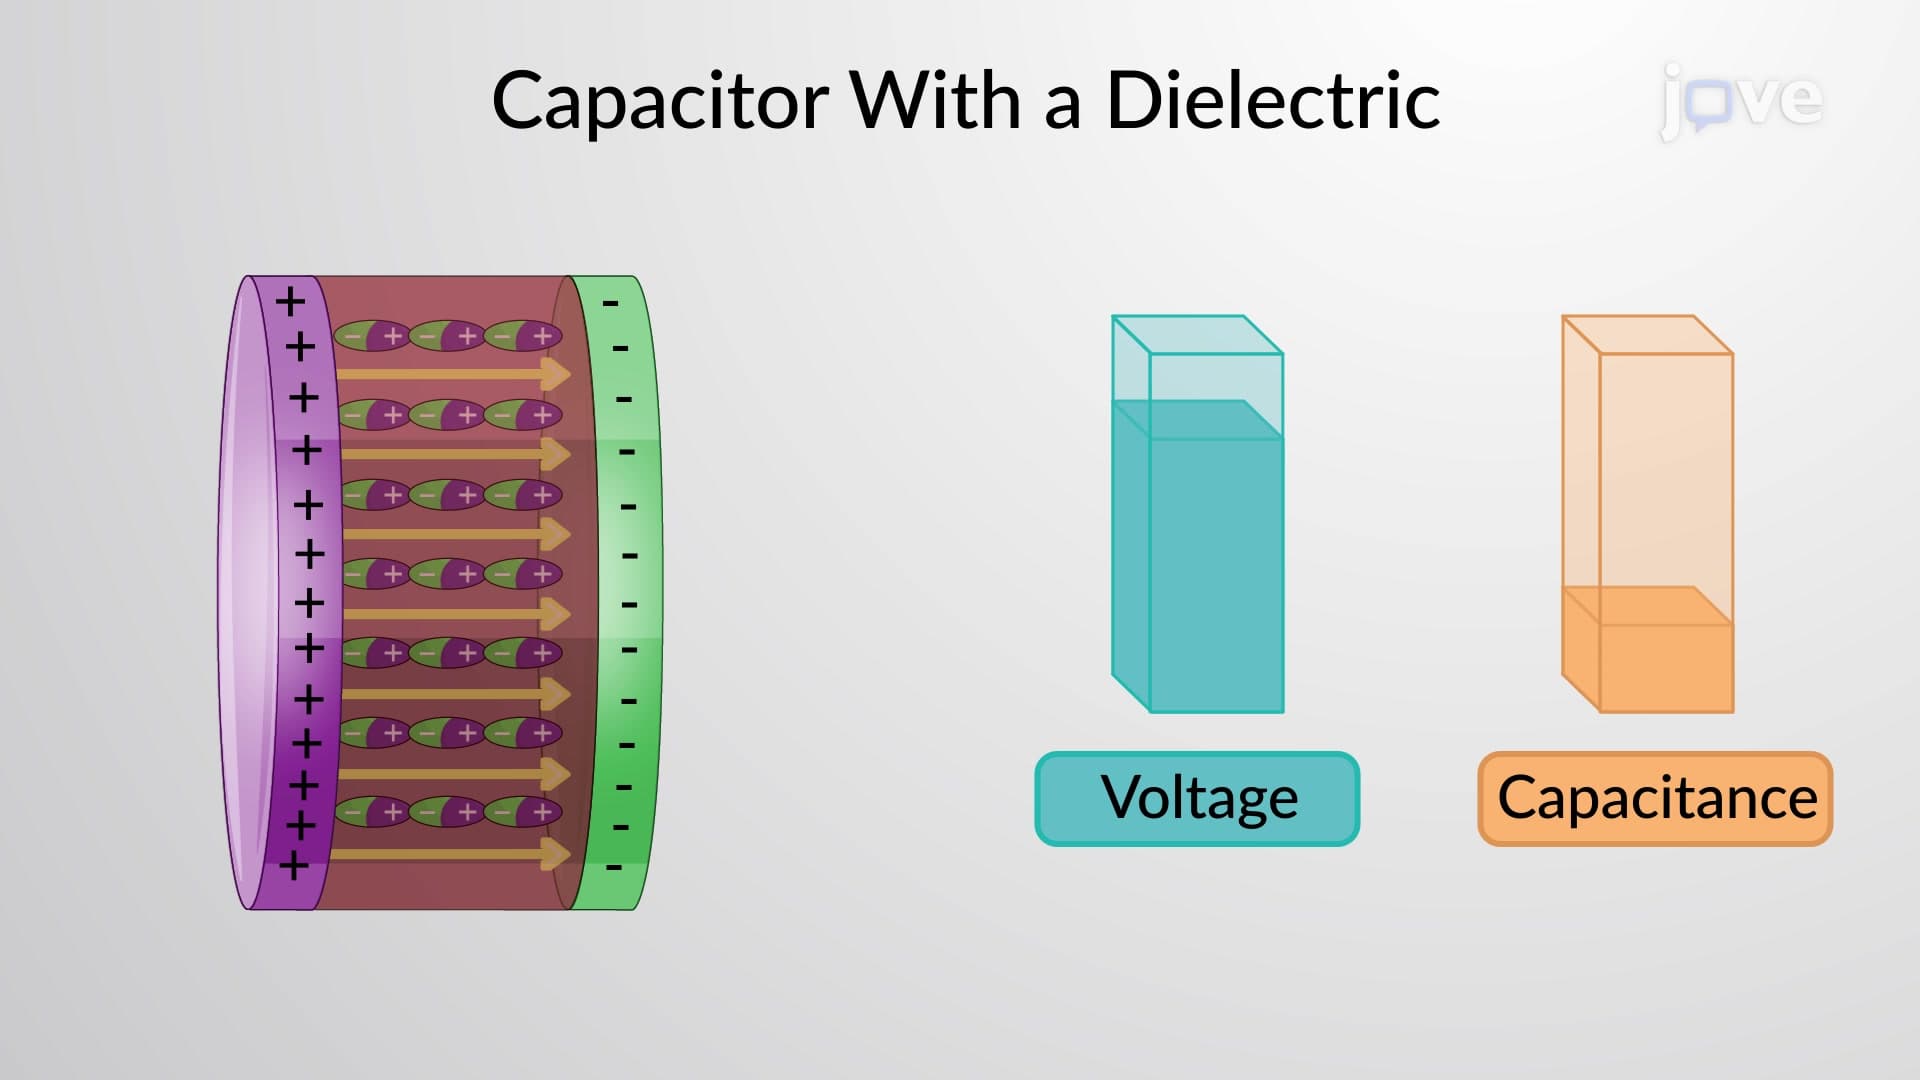
Capacitor With A Dielectric
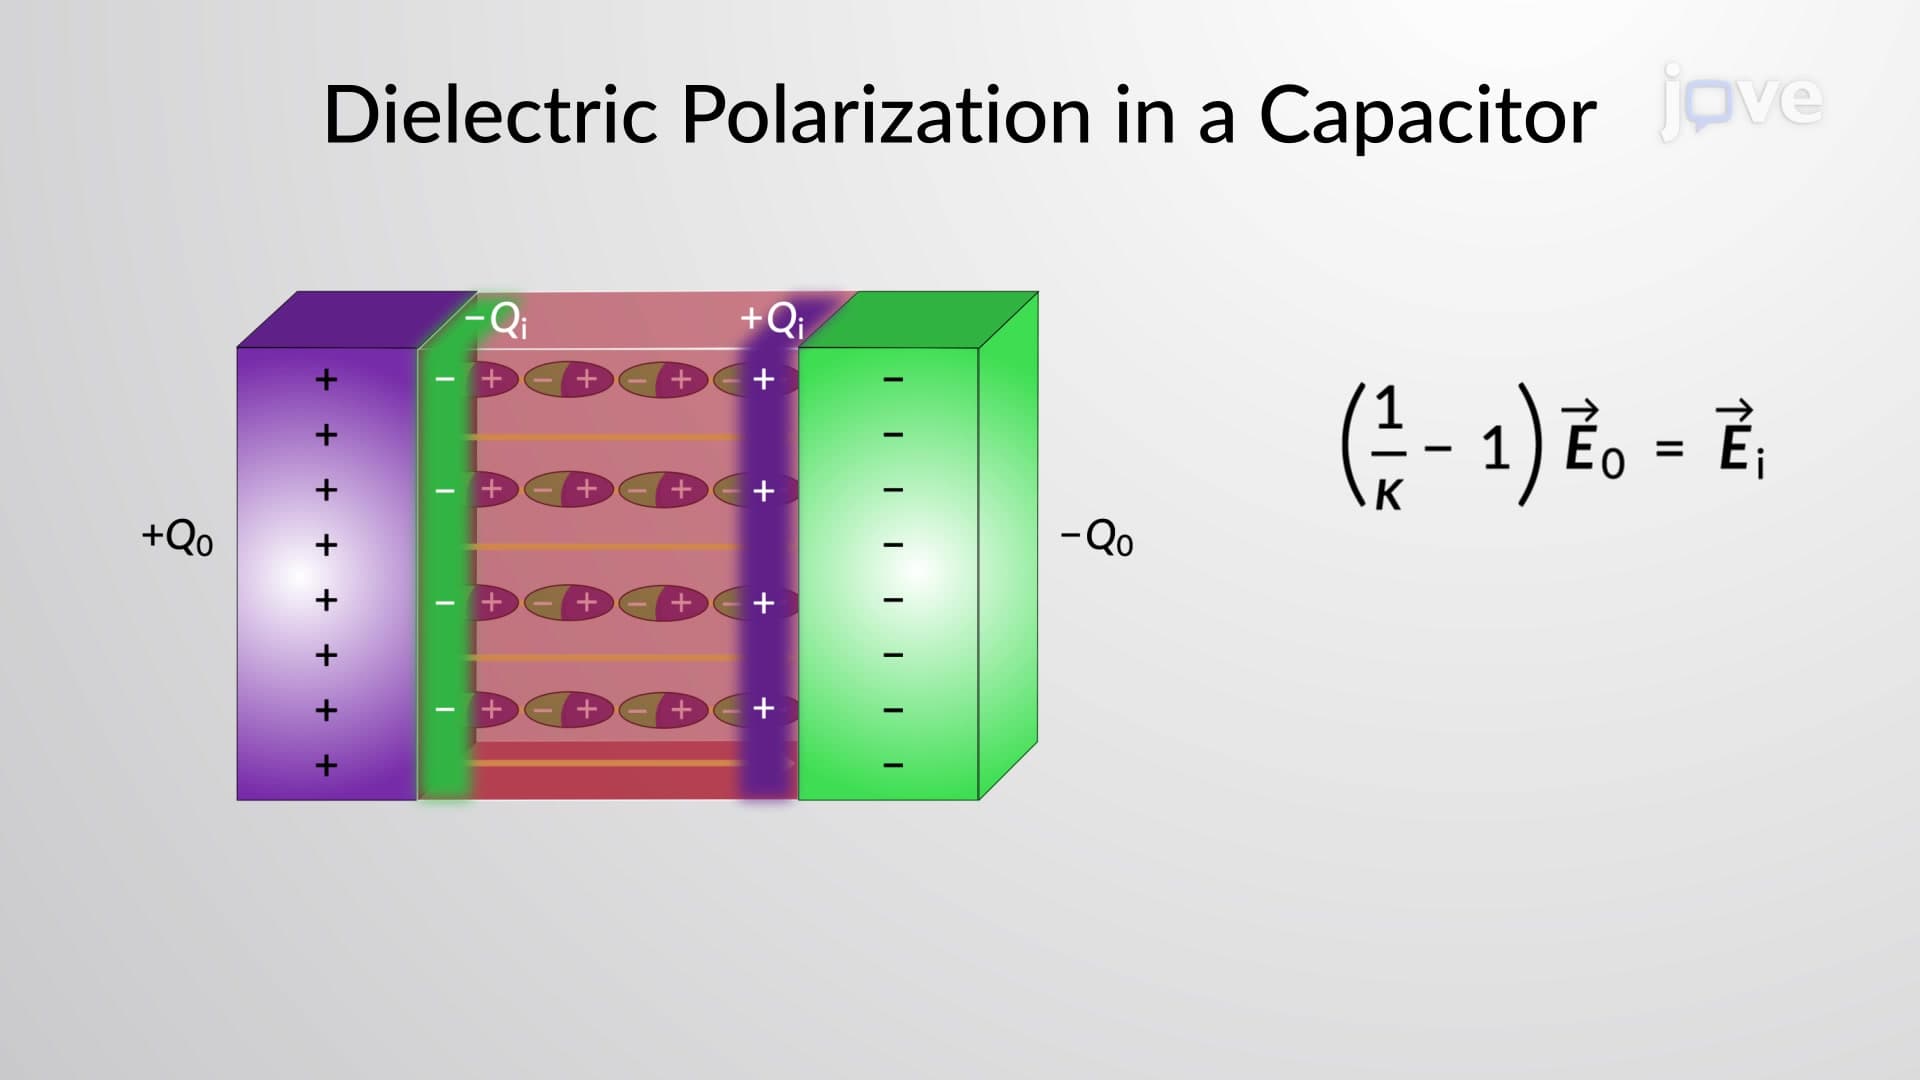
Dielectrics are non-conducting materials with no free or loosely bound electrons. When a dielectric is...
 01:31
Dielectric Polarization in a Capacitor