Related Experiment Video
Updated: Mar 3, 2026


Design and Analysis for Fall Detection System Simplification
Published on: April 6, 2020
Sensor Fusion Based on an Integrated Neural Network and Probability Density Function (PDF) Dual Kalman Filter for
Leandro Vargas-Melendez1, Beatriz L Boada2, Maria Jesus L Boada3
1Mechanical Engineering Department, Research Institute of Vehicle Safety, Universidad Carlos III de Madrid, Avda. de la Universidad 30, 28911 Madrid, Spain. lvargas@ing.uc3m.es.

Abstract:
Vehicles with a high center of gravity (COG), such as light trucks and heavy vehicles, are prone to rollover. This kind of accident causes nearly 33 % of all deaths from passenger vehicle crashes. Nowadays, these vehicles are incorporating roll stability control (RSC) systems to improve their safety. Most of the RSC systems require the vehicle roll angle as a known input variable to predict the lateral load transfer. The vehicle roll angle can be directly measured by a dual antenna global positioning system (GPS), but it is expensive. For this reason, it is important to estimate the vehicle roll angle from sensors installed onboard in current vehicles. On the other hand, the knowledge of the vehicle's parameters values is essential to obtain an accurate vehicle response. Some of vehicle parameters cannot be easily obtained and they can vary over time. In this paper, an algorithm for the simultaneous on-line estimation of vehicle's roll angle and parameters is proposed. This algorithm uses a probability density function (PDF)-based truncation method in combination with a dual Kalman filter (DKF), to guarantee that both vehicle's states and parameters are within bounds that have a physical meaning, using the information obtained from sensors mounted on vehicles. Experimental results show the effectiveness of the proposed algorithm.
More Related Videos
 03:31
Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:27
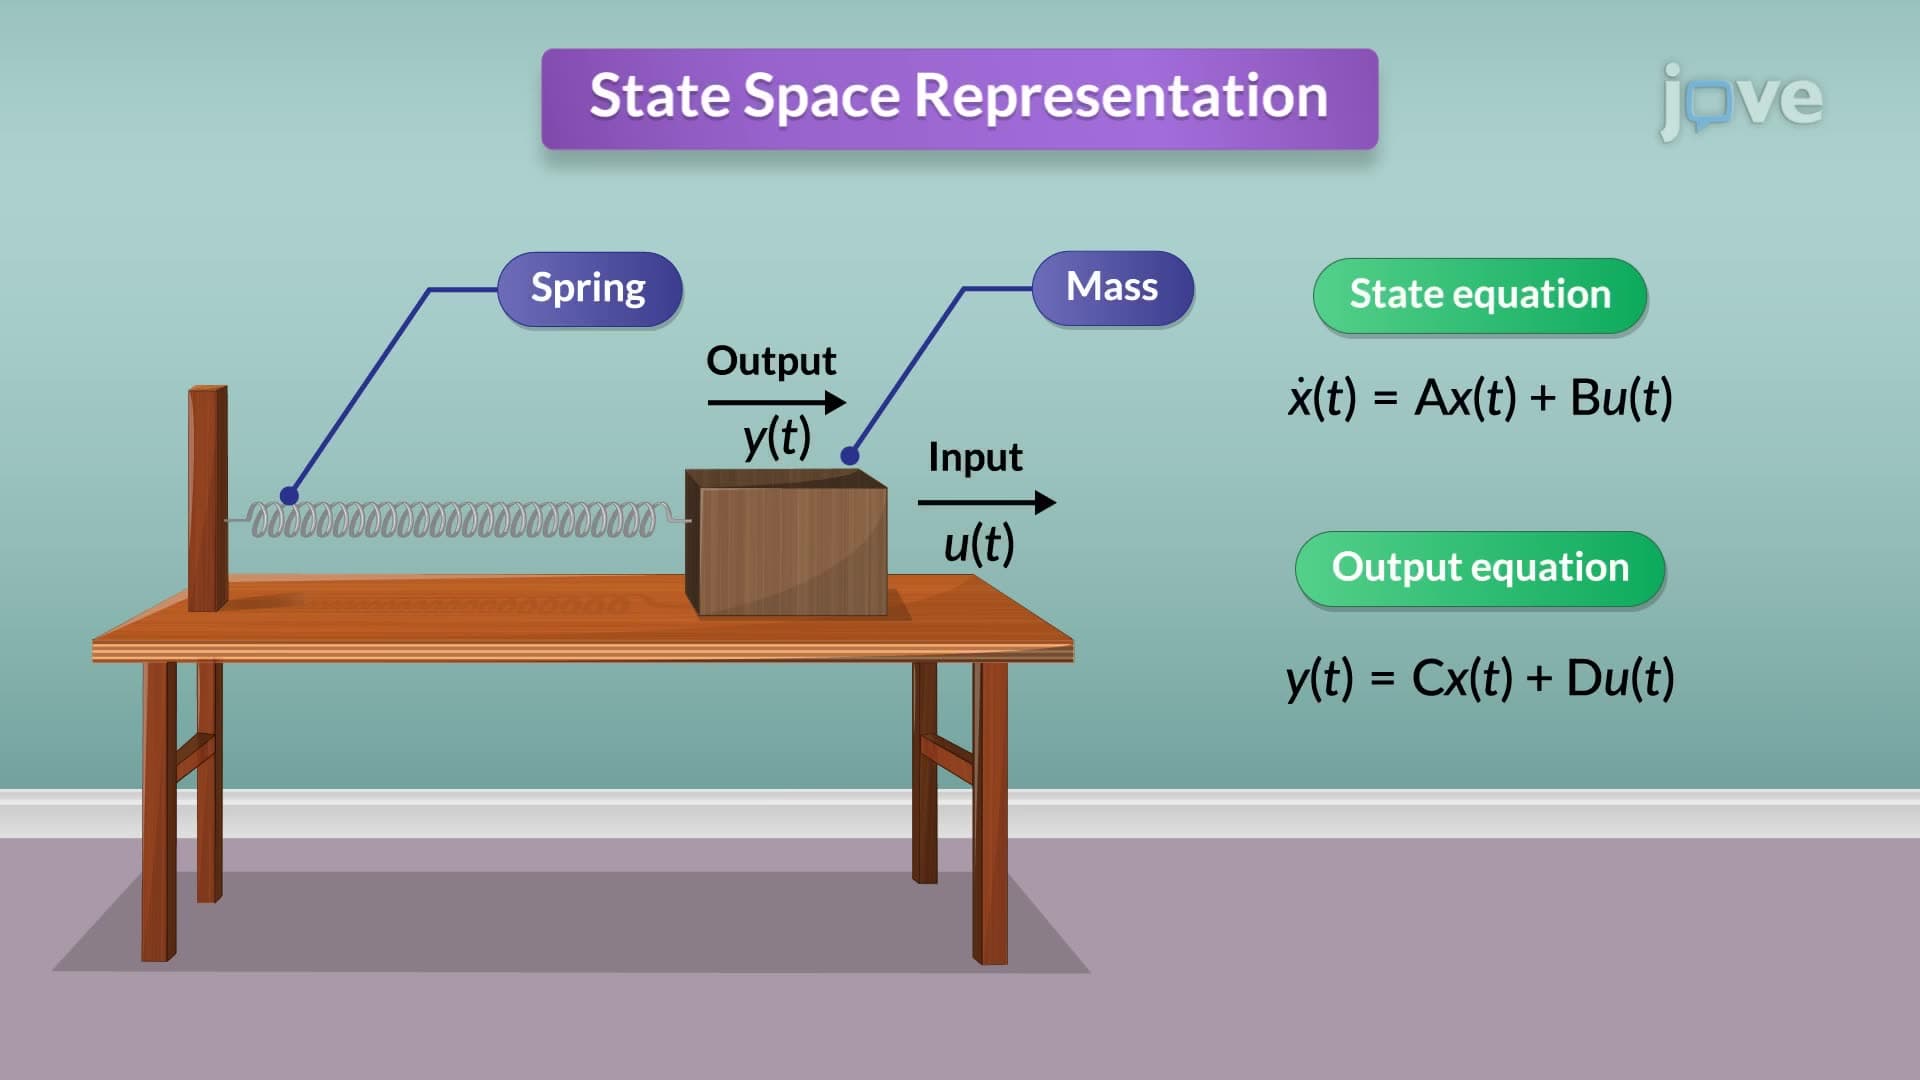
State Space Representation
Consider an RLC circuit, a...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: