Related Experiment Video
Updated: Mar 3, 2026

Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Optimal input design for multibody systems by using an extended adjoint approach
Stefan Oberpeilsteiner1,2, Thomas Lauss1,2, Karin Nachbagauer1
1Faculty of Engineering and Environmental Sciences, University of Applied Sciences Upper Austria, Stelzhamerstrasse 23, 4600 Wels, Austria.

Abstract:
We present a method for optimizing inputs of multibody systems for a subsequently performed parameter identification. Herein, optimality with respect to identifiability is attained by maximizing the information content in measurements described by the Fisher information matrix. For solving the resulting optimization problem, the adjoint system of the sensitivity differential equation system is employed. The proposed approach combines these two well-established methods and can be applied to multibody systems in a systematic, automated manner. Furthermore, additional optimization goals can be added and used to find inputs satisfying, for example, end conditions or state constraints.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
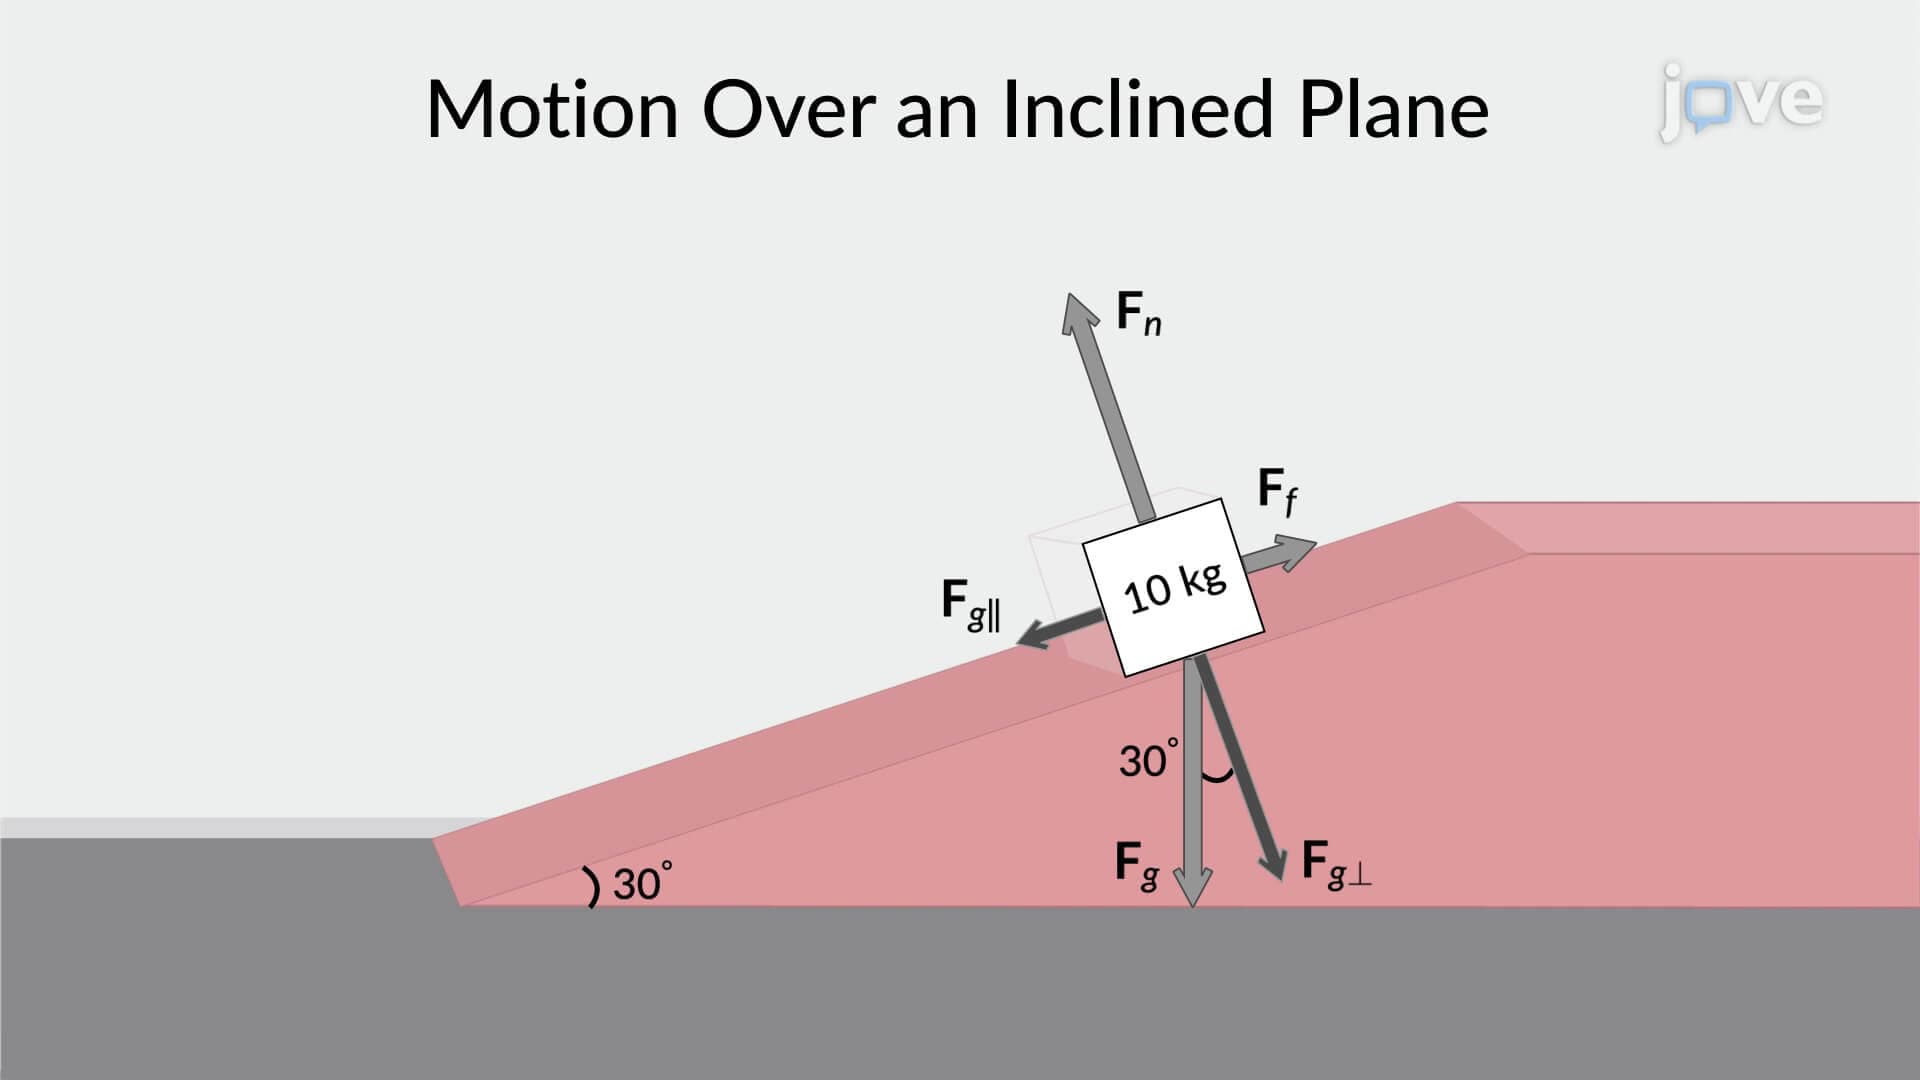
Free-body Diagrams: Problem Solving
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...