Robust absolute stability analysis for interval nonlinear active disturbance rejection based control system
Related Experiment Video
Updated: Mar 3, 2026

Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Jie Li1, Yuanqing Xia2, Xiaohui Qi1
1Department of Unmanned Aerial Vehicle Engineering, Mechanical Engineering College, Shijiazhuang 050003, PR China.

Abstract:
Active disturbance rejection control (ADRC) is a relatively new, quite different but very practical control technology, which shows much promise in replacement of proportion-integration-differentiation (PID) with unmistakable advantage in performance and practicality. This paper mainly concerns with the robust absolute stability of the ADRC based control system with parameter perturbations of the plant, i.e., ADRC based interval control system. Firstly, the system is transformed into a perturbed indirect Lurie system. Then, the Popov criterion and its robust version are presented and some new methods are developed to analyze the (robust) absolute stability for the interval control system. Furthermore, an example is presented to illustrate (robust) absolute stability analysis via the above methods, which verifies the convenience and practicability of these methods and shows the strong stability robustness of ADRC in the presence of parametric uncertainties.


Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:28
Stability
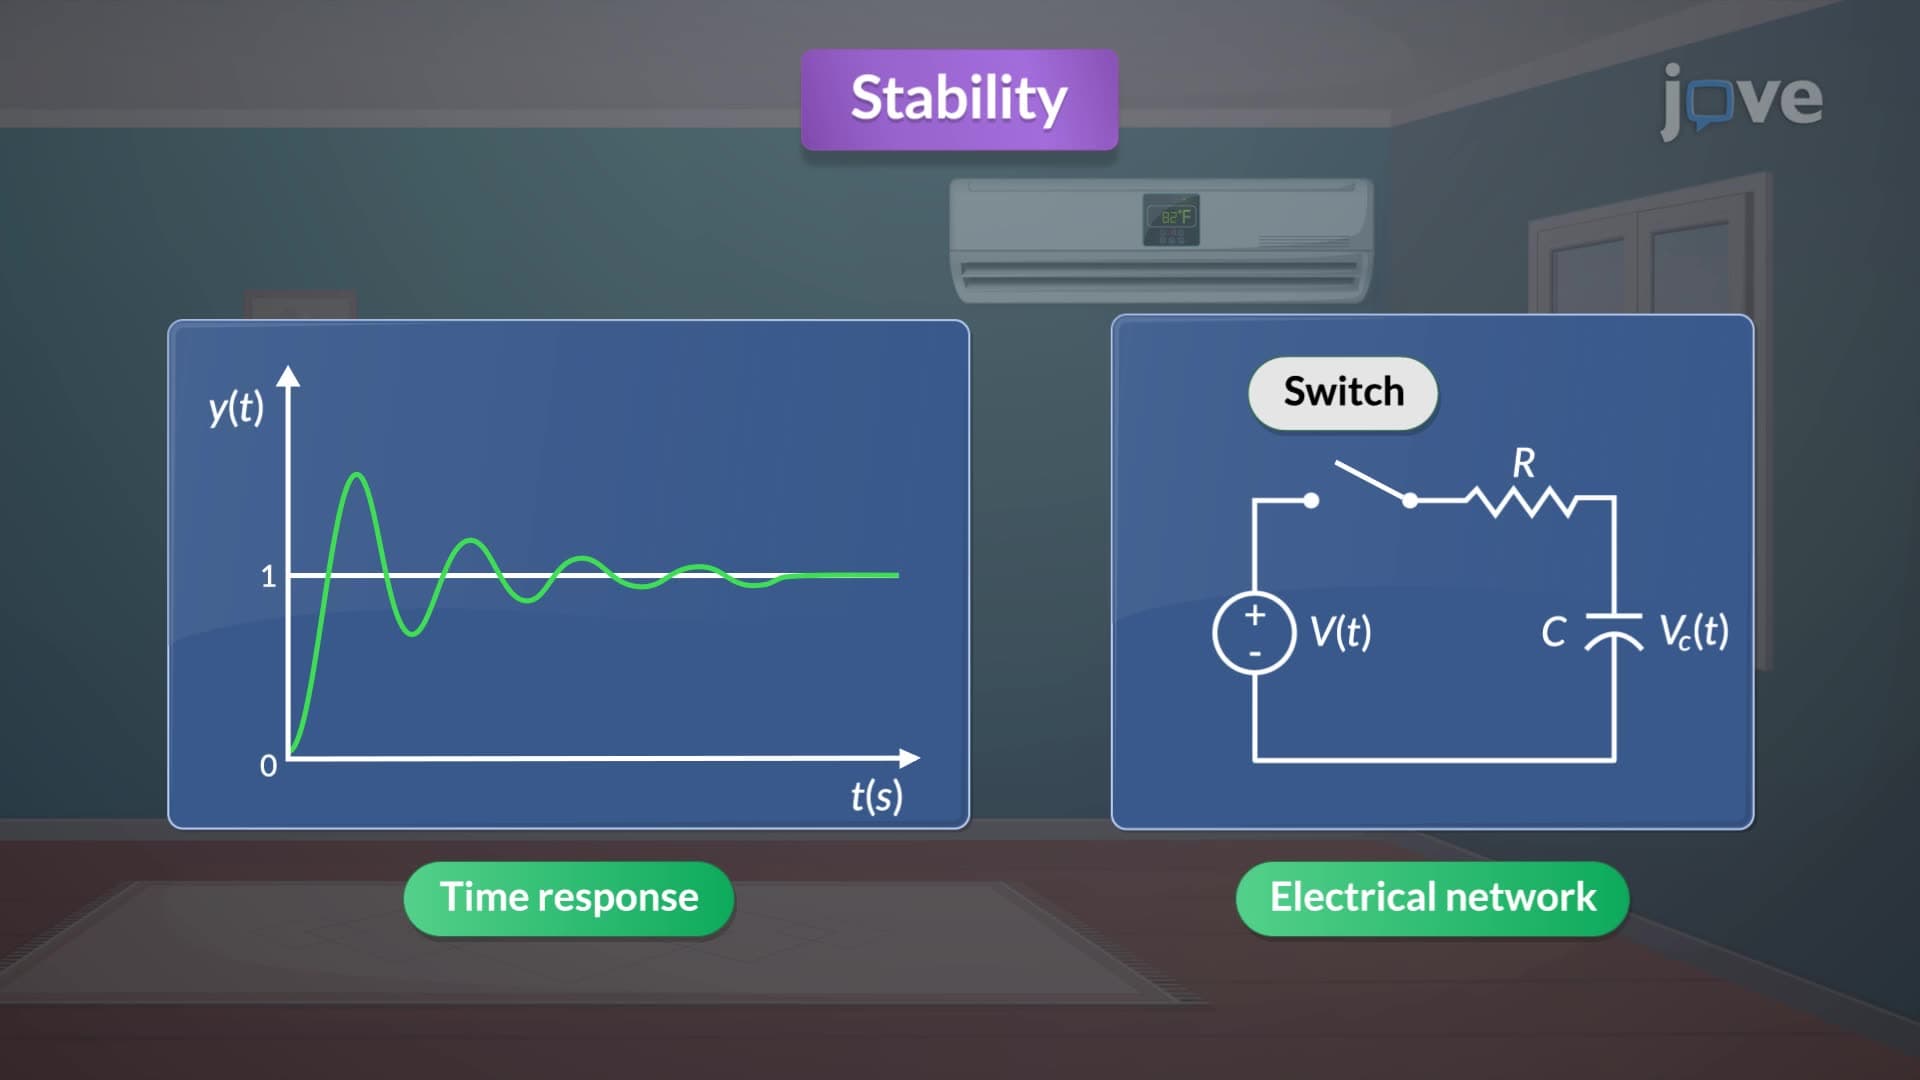
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...