Related Experiment Video
Updated: Mar 2, 2026
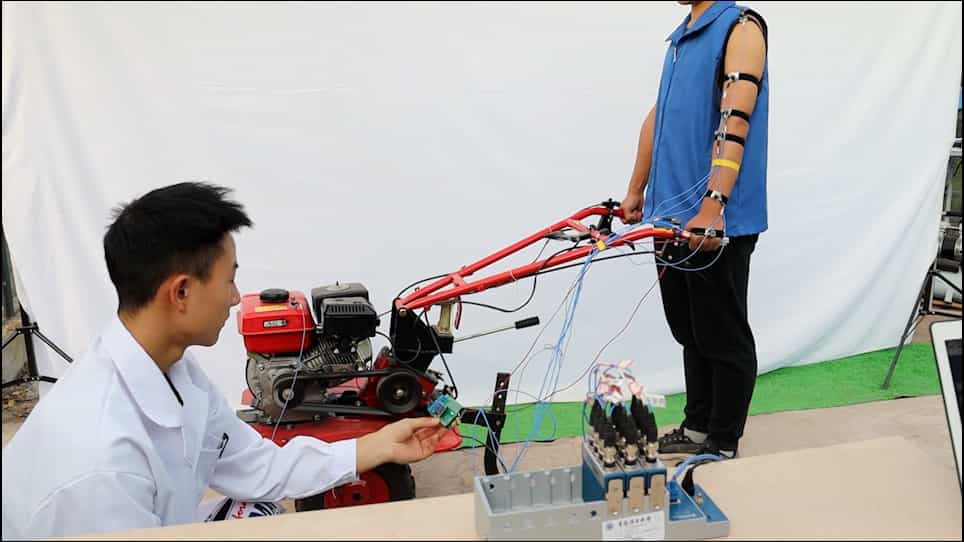

Measurement of the Hand Transmitted Vibration of the Human Hand Arm System During Operation of a Hand Tractor
Published on: June 16, 2021
Modeling of the interaction between grip force and vibration transmissibility of a finger
John Z Wu1, Daniel E Welcome1, Thomas W McDowell1
1Health Effects Laboratory Division, National Institute for Occupational Safety and Health, Morgantown, WV 26505, USA.

Abstract:
It is known that the vibration characteristics of the fingers and hand and the level of grip action interacts when operating a power tool. In the current study, we developed a hybrid finger model to simulate the vibrations of the hand-finger system when gripping a vibrating handle covered with soft materials. The hybrid finger model combines the characteristics of conventional finite element (FE) models, multi-body musculoskeletal models, and lumped mass models. The distal, middle, and proximal finger segments were constructed using FE models, the finger segments were connected via three flexible joint linkages (i.e., distal interphalangeal joint (DIP), proximal interphalangeal joint (PIP), and metacarpophalangeal (MCP) joint), and the MCP joint was connected to the ground and handle via lumped parameter elements. The effects of the active muscle forces were accounted for via the joint moments. The bone, nail, and hard connective tissues were assumed to be linearly elastic whereas the soft tissues, which include the skin and subcutaneous tissues, were considered as hyperelastic and viscoelastic. The general trends of the model predictions agree well with the previous experimental measurements in that the resonant frequency increased from proximal to the middle and to the distal finger segments for the same grip force, that the resonant frequency tends to increase with increasing grip force for the same finger segment, especially for the distal segment, and that the magnitude of vibration transmissibility tends to increase with increasing grip force, especially for the proximal segment. The advantage of the proposed model over the traditional vibration models is that it can predict the local vibration behavior of the finger to a tissue level, while taking into account the effects of the active musculoskeletal force, the effects of the contact conditions on vibrations, the global vibration characteristics.

Related Concept Videos
 01:05
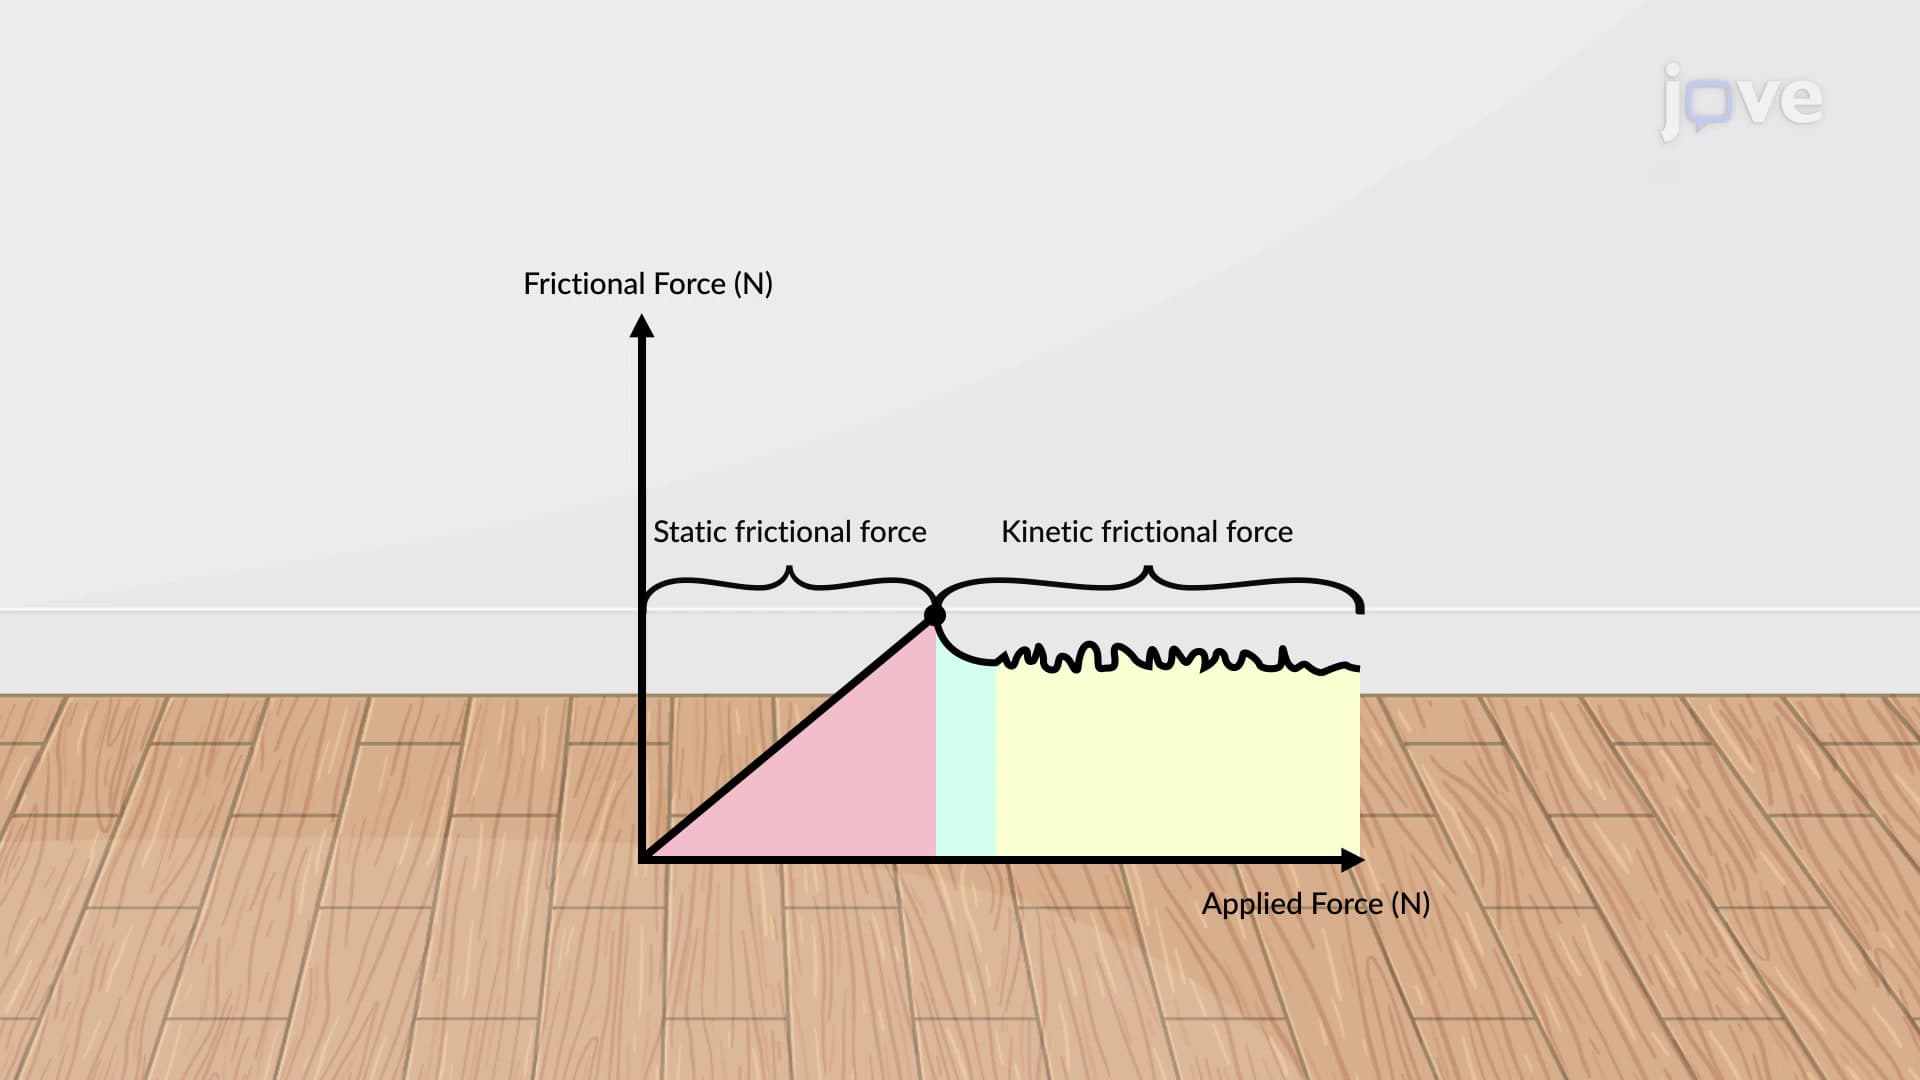
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:21
Characteristics of Dry Friction
Before the wheelbarrow starts moving, the static frictional force acts tangentially to the contact surface, opposing the force that is about to induce the motion. This frictional force prevents the...
 01:17
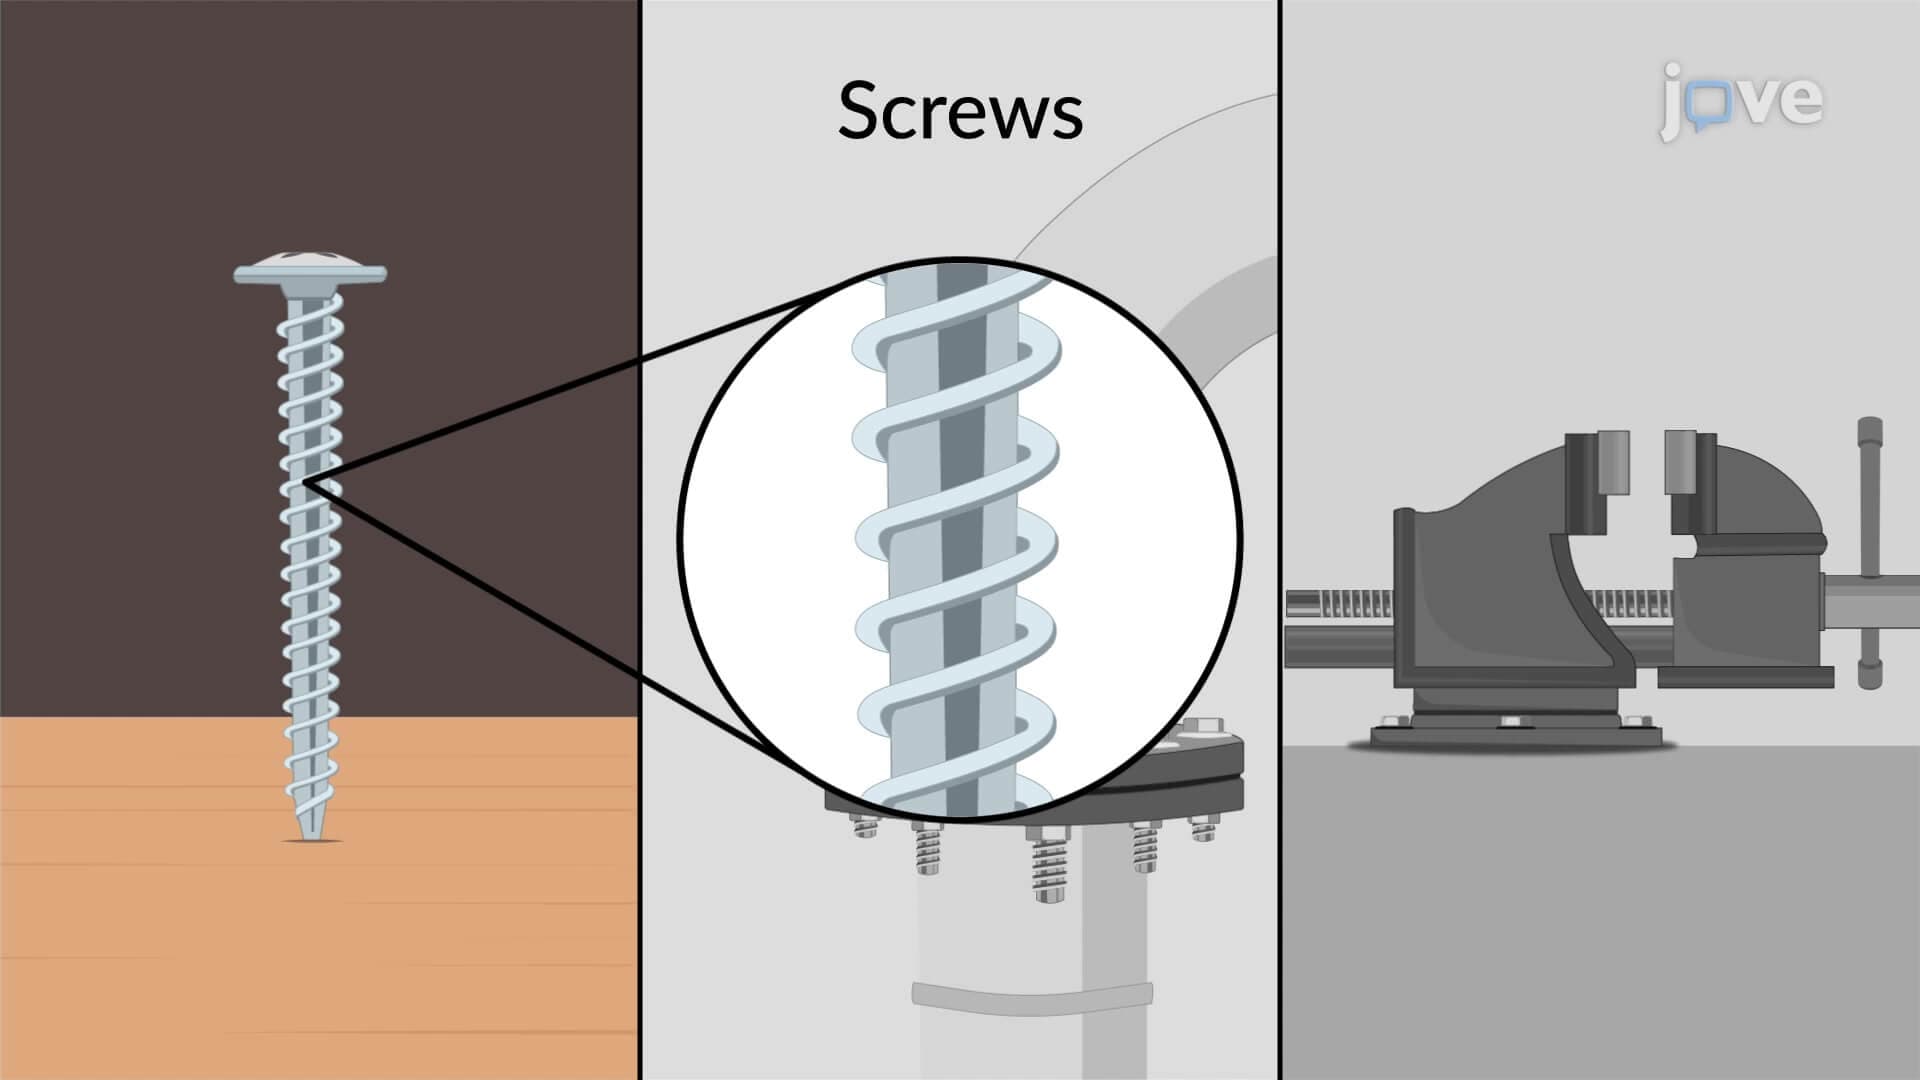
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:26
Kinetic Friction
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion....
 01:28
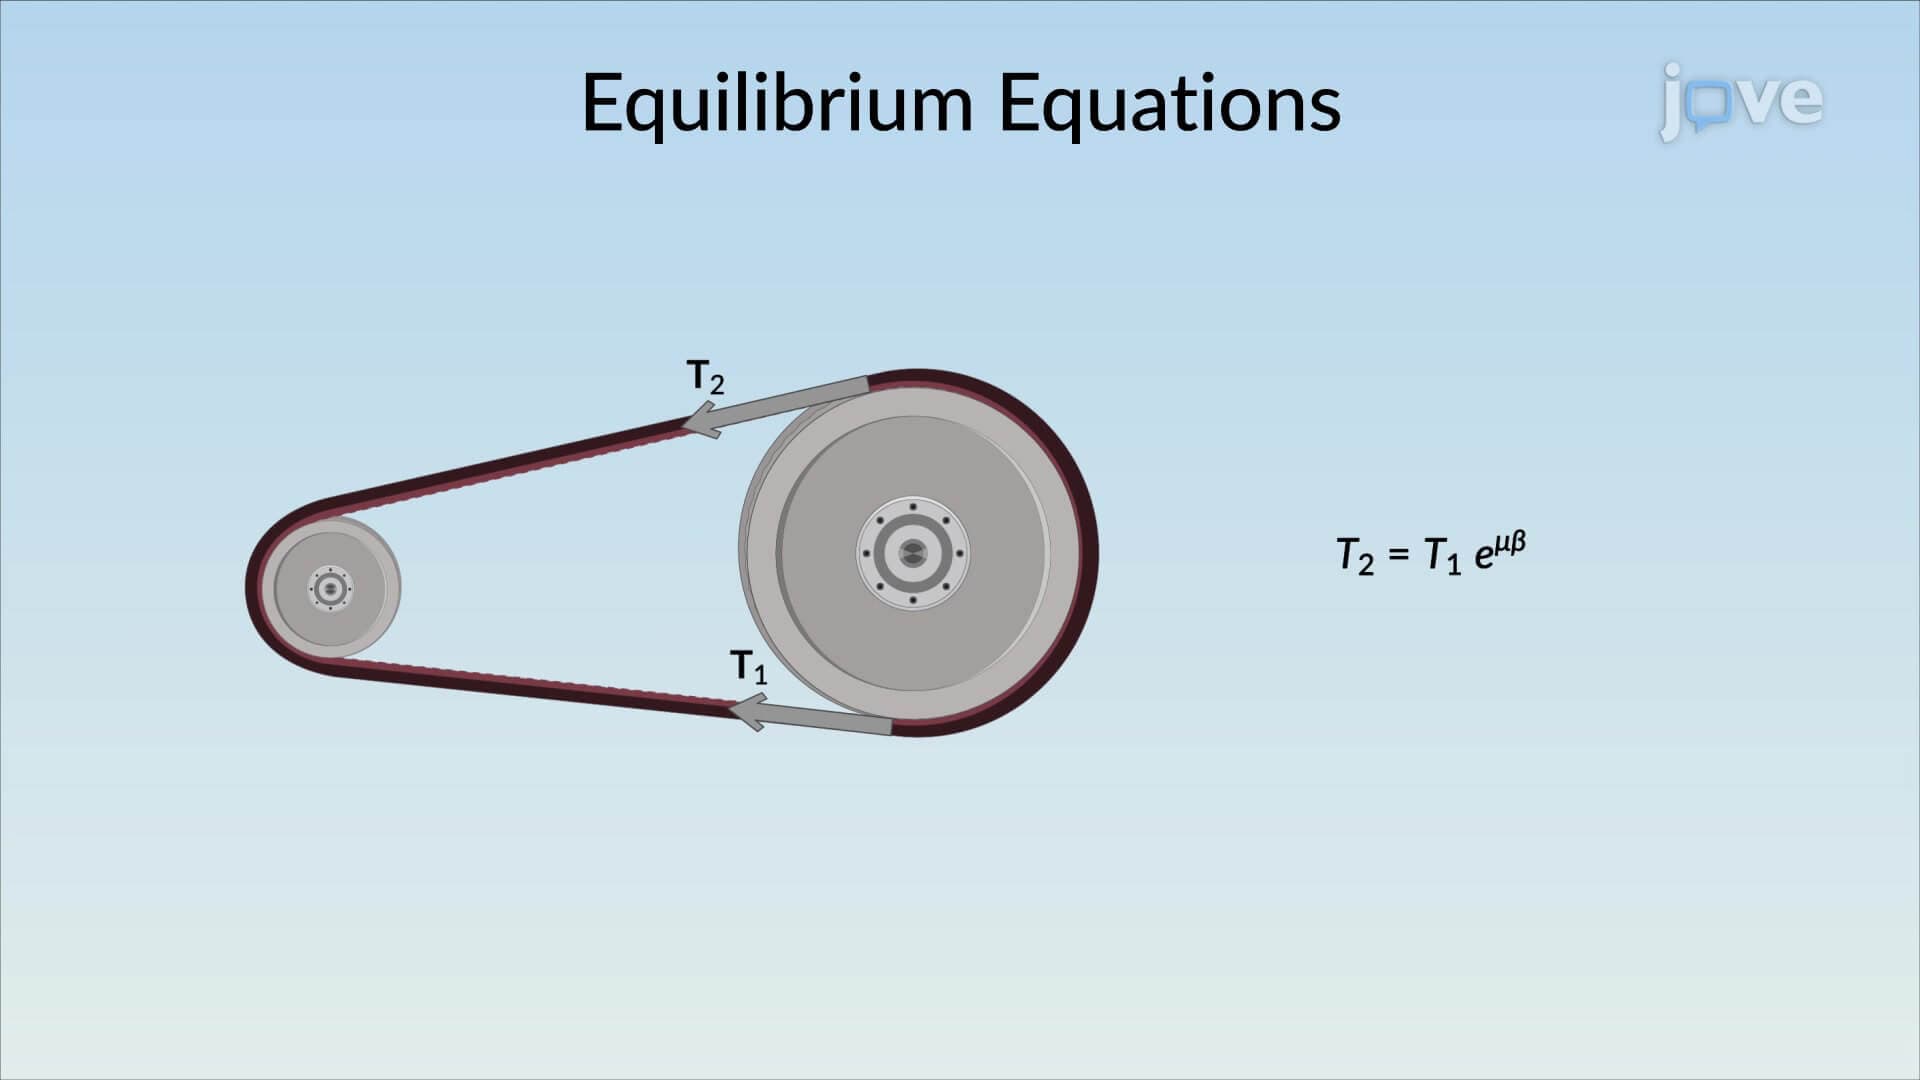
Frictional Forces on Flat Belts