Related Experiment Video
Updated: Mar 2, 2026


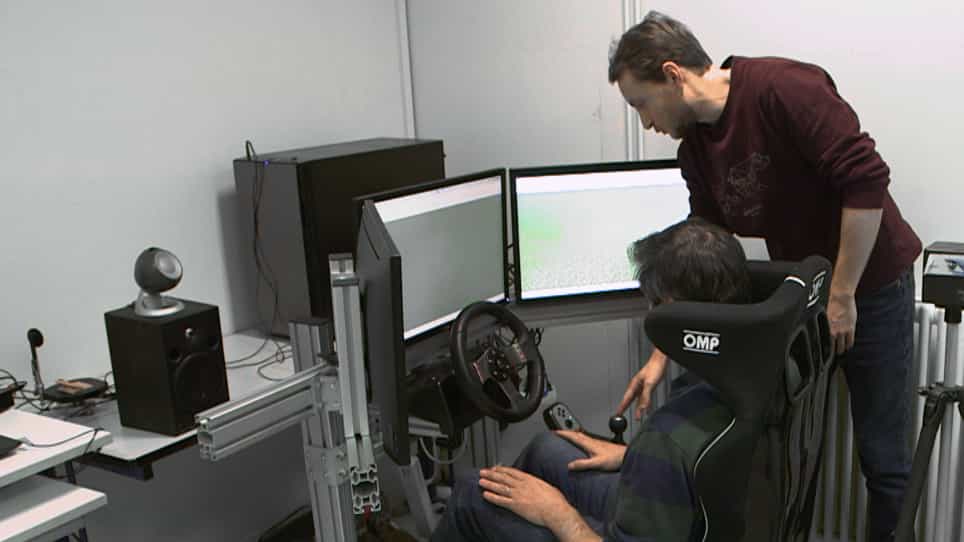
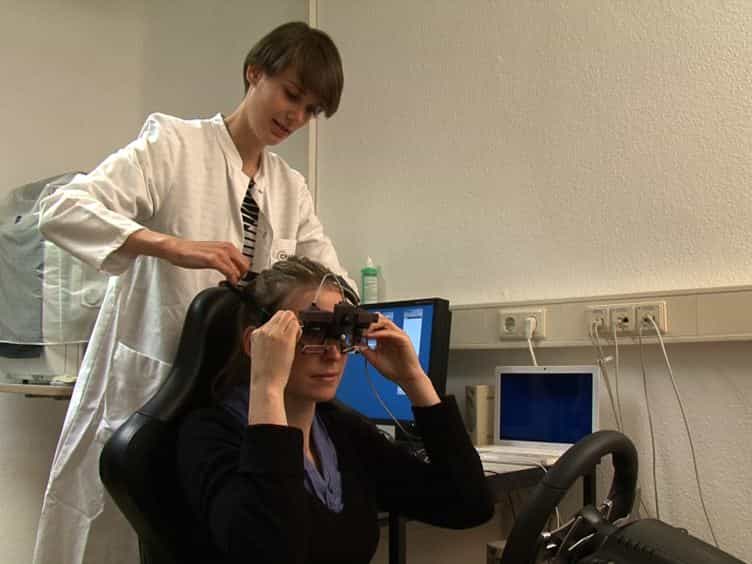
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Evaluating the safety impact of adaptive cruise control in traffic oscillations on freeways
1School of Transportation, Southeast University, 2 Si pai lou, Nanjing, 210096, PR China.

Abstract:
Adaptive cruise control (ACC) has been considered one of the critical components of automated driving. ACC adjusts vehicle speeds automatically by measuring the status of the ego-vehicle and leading vehicle. Current commercial ACCs are designed to be comfortable and convenient driving systems. Little attention is paid to the safety impacts of ACC, especially in traffic oscillations when crash risks are the highest. The primary objective of this study was to evaluate the impacts of ACC parameter settings on rear-end collisions on freeways. First, the occurrence of a rear-end collision in a stop-and-go wave was analyzed. A car-following model in an integrated ACC was developed for a simulation analysis. The time-to-collision based factors were calculated as surrogate safety measures of the collision risk. We also evaluated different market penetration rates considering that the application of ACC will be a gradual process. The results showed that the safety impacts of ACC were largely affected by the parameters. Smaller time delays and larger time gaps improved safety performance, but inappropriate parameter settings increased the collision risks and caused traffic disturbances. A higher reduction of the collision risk was achieved as the ACC vehicle penetration rate increased, especially in the initial stage with penetration rates of less than 30%. This study also showed that in the initial stage, the combination of ACC and a variable speed limit achieved better safety improvements on congested freeways than each single technique.
More Related Videos
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:20
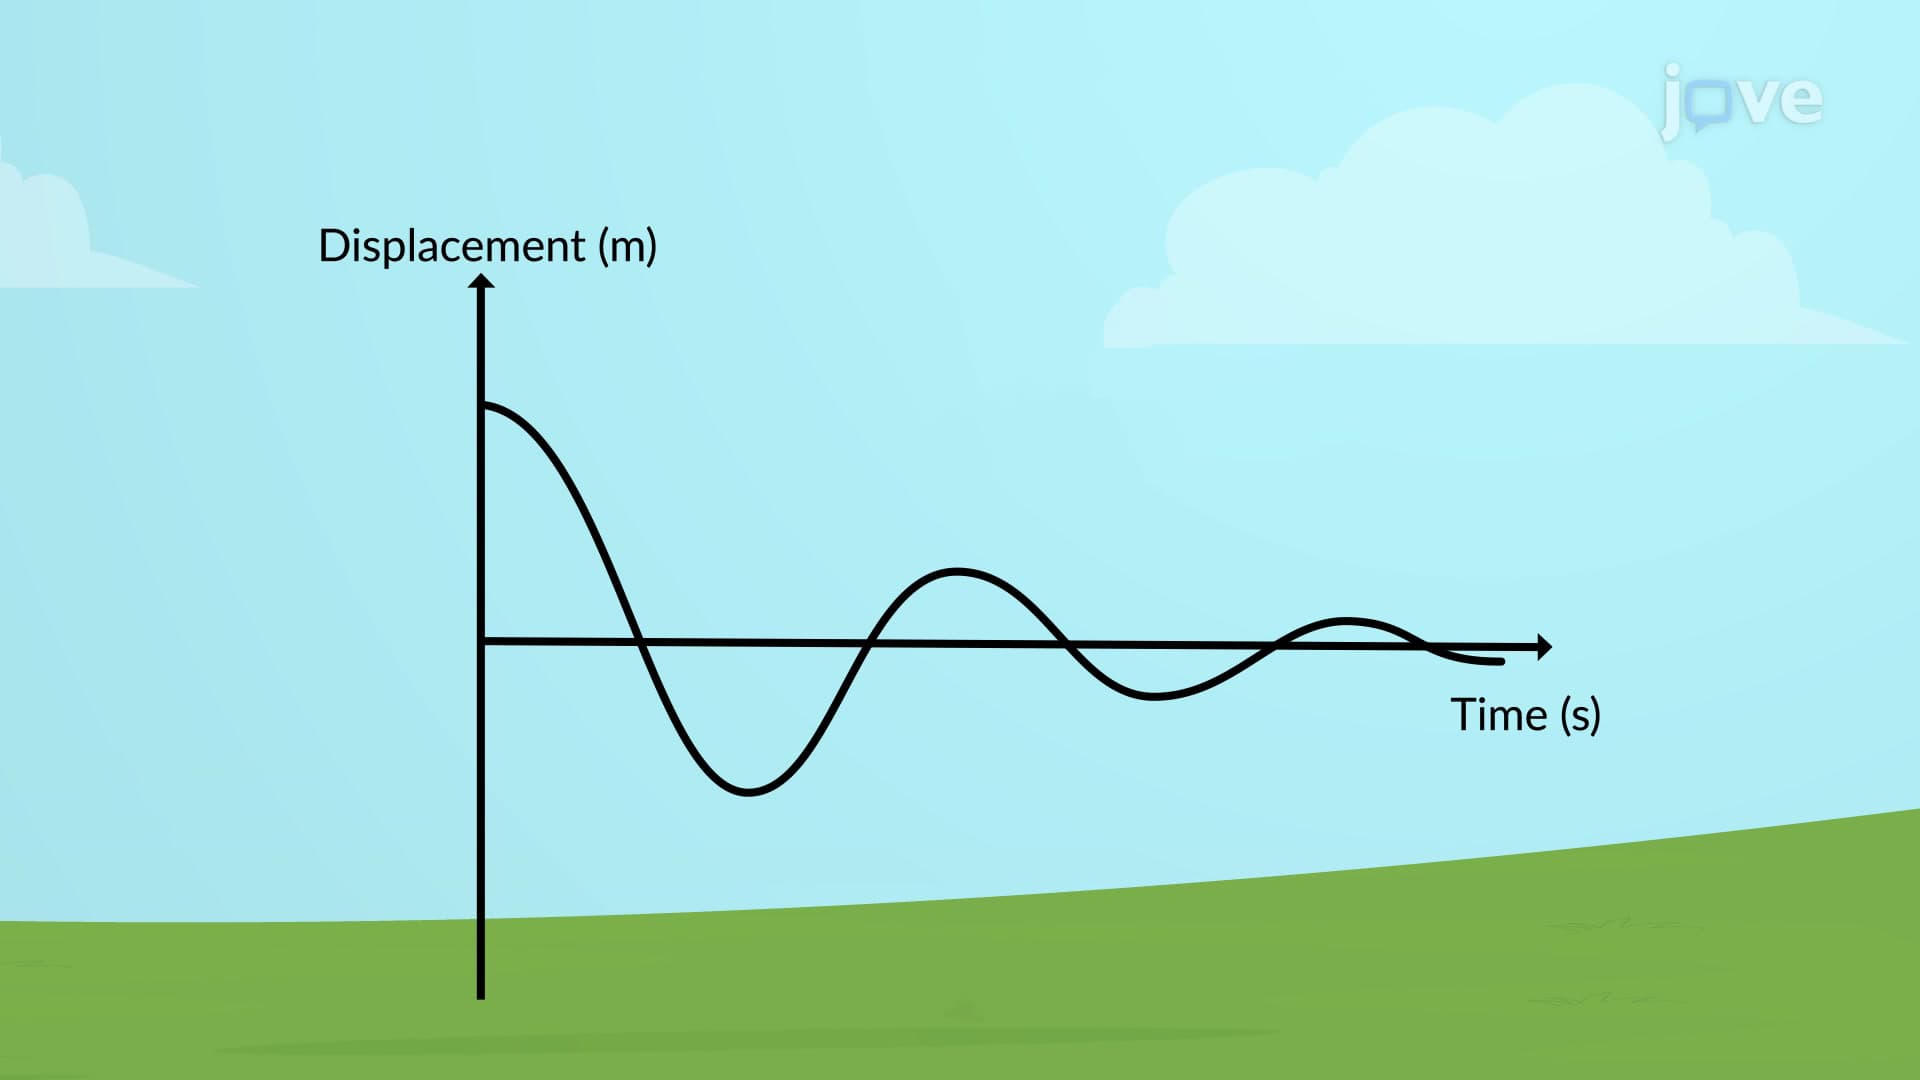
Types of Damping
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:28
Load-frequency control