Related Experiment Video
Updated: Dec 16, 2025
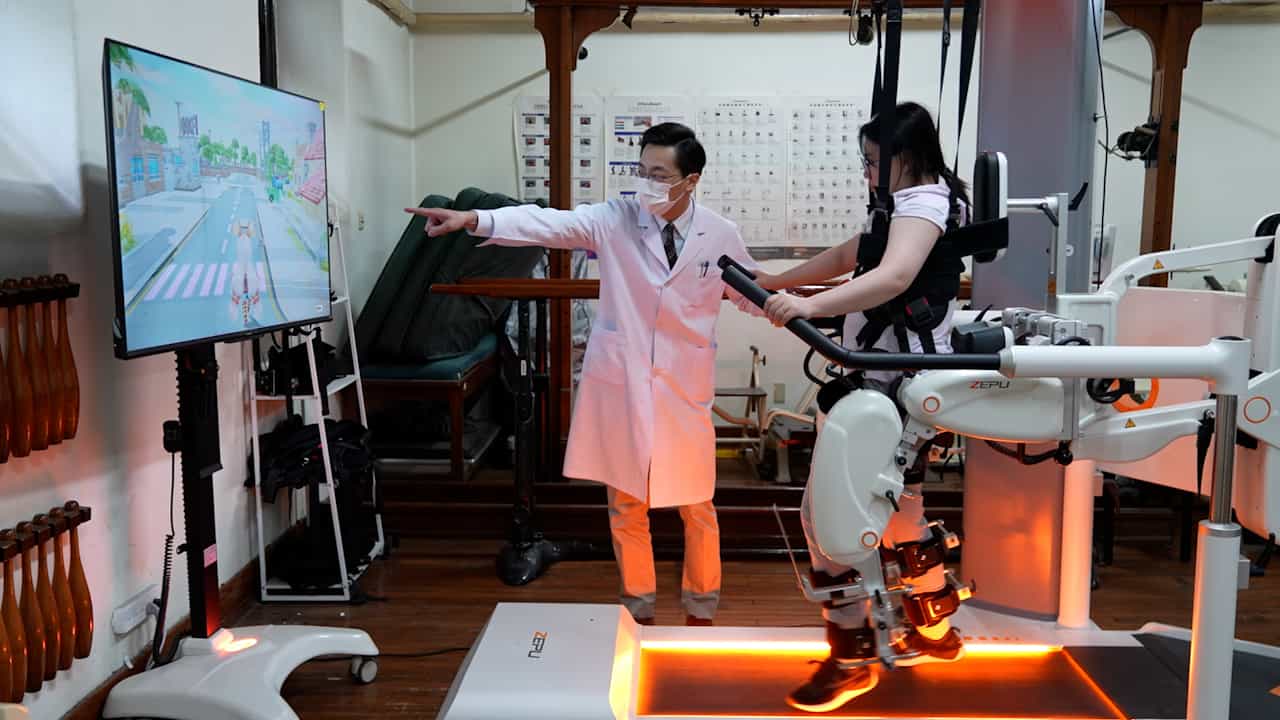
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
Toward Multimodal Human-Robot Interaction to Enhance Active Participation of Users in Gait Rehabilitation

Abstract:
Robotic exoskeletons for physical rehabilitation have been utilized for retraining patients suffering from paraplegia and enhancing motor recovery in recent years. However, users are not voluntarily involved in most systems. This paper aims to develop a locomotion trainer with multiple gait patterns, which can be controlled by the active motion intention of users. A multimodal human-robot interaction (HRI) system is established to enhance subject's active participation during gait rehabilitation, which includes cognitive HRI (cHRI) and physical HRI (pHRI). The cHRI adopts brain-computer interface based on steady-state visual evoked potential. The pHRI is realized via admittance control based on electromyography. A central pattern generator is utilized to produce rhythmic and continuous lower joint trajectories, and its state variables are regulated by cHRI and pHRI. A custom-made leg exoskeleton prototype with the proposed multimodal HRI is tested on healthy subjects and stroke patients. The results show that voluntary and active participation can be effectively involved to achieve various assistive gait patterns.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 05:25
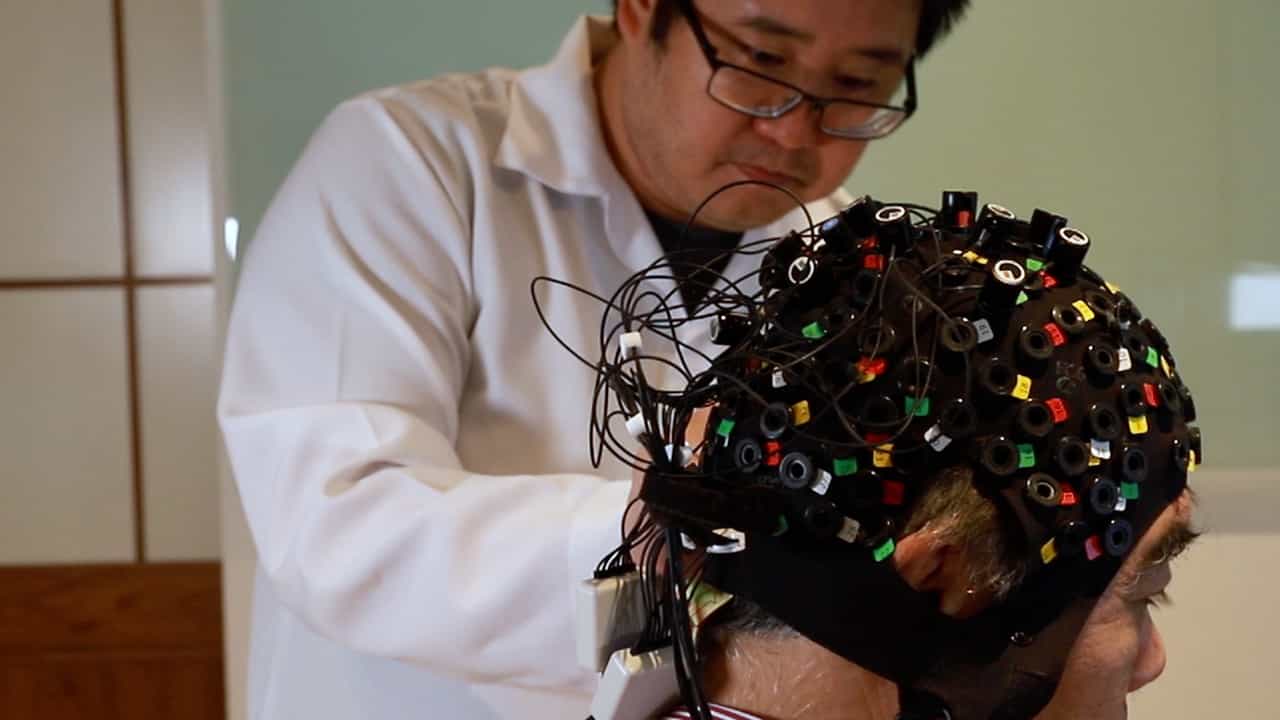
Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024