Related Experiment Video
Updated: Mar 1, 2026

Photodiode-Based Optical Imaging for Recording Network Dynamics with Single-Neuron Resolution in Non-Transgenic Invertebrates
Published on: July 9, 2020
Serpentine locomotion through elastic energy release
F Dal Corso1, D Misseroni1, N M Pugno1,2,3,4
1DICAM-University of Trento, via Mesiano 77, Trento, Italy.

Abstract:
A model for serpentine locomotion is derived from a novel perspective based on concepts from configurational mechanics. The motion is realized through the release of the elastic energy of a deformable rod, sliding inside a frictionless channel, which represents a snake moving against lateral restraints. A new formulation is presented, correcting previous results and including situations never analysed so far, as in the cases when the serpent's body lies only partially inside the restraining channel or when the body has a muscle relaxation localized in a small zone. Micromechanical considerations show that propulsion is the result of reactions tangential to the frictionless constraint and acting on the snake's body, a counter-intuitive feature in mechanics. It is also experimentally demonstrated that the propulsive force driving serpentine motion can be directly measured on a designed apparatus in which flexible bars sweep a frictionless channel. Experiments fully confirm the theoretical modelling, so that the presented results open the way to exploration of effects, such as variability in the bending stiffness or channel geometry or friction, on the propulsive force of snake models made up of elastic rods.
Related Concept Videos
 01:01
Elastic Potential Energy
Potential energy is also associated with the elastic force exerted by an ideal spring. The work done by this force can be represented as a change in the elastic potential energy of the spring. Thus, the work done by a perfectly elastic spring, in one dimension, depends...
 01:23
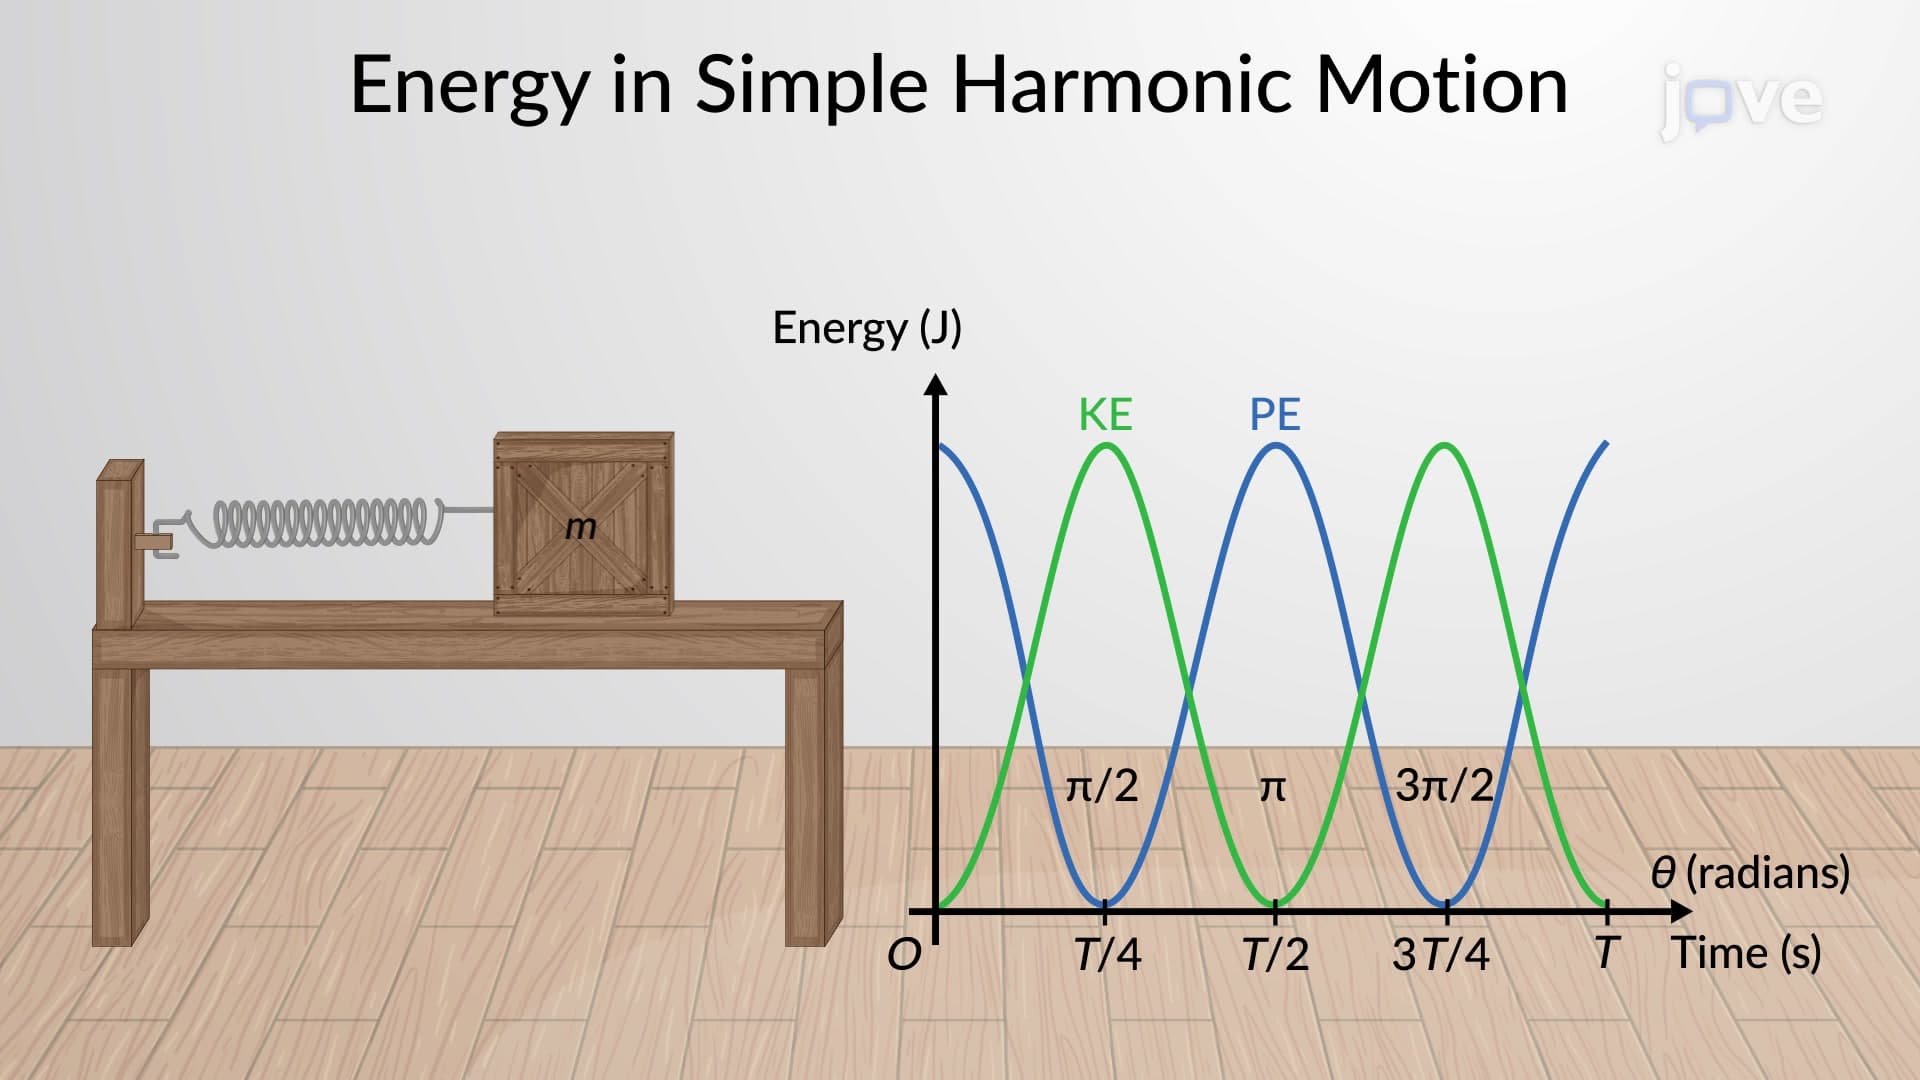
Energy in Simple Harmonic Motion
 01:10
Energy Diagrams - II
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The...
 01:20
Elastic Strain Energy for Shearing Stresses
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:22
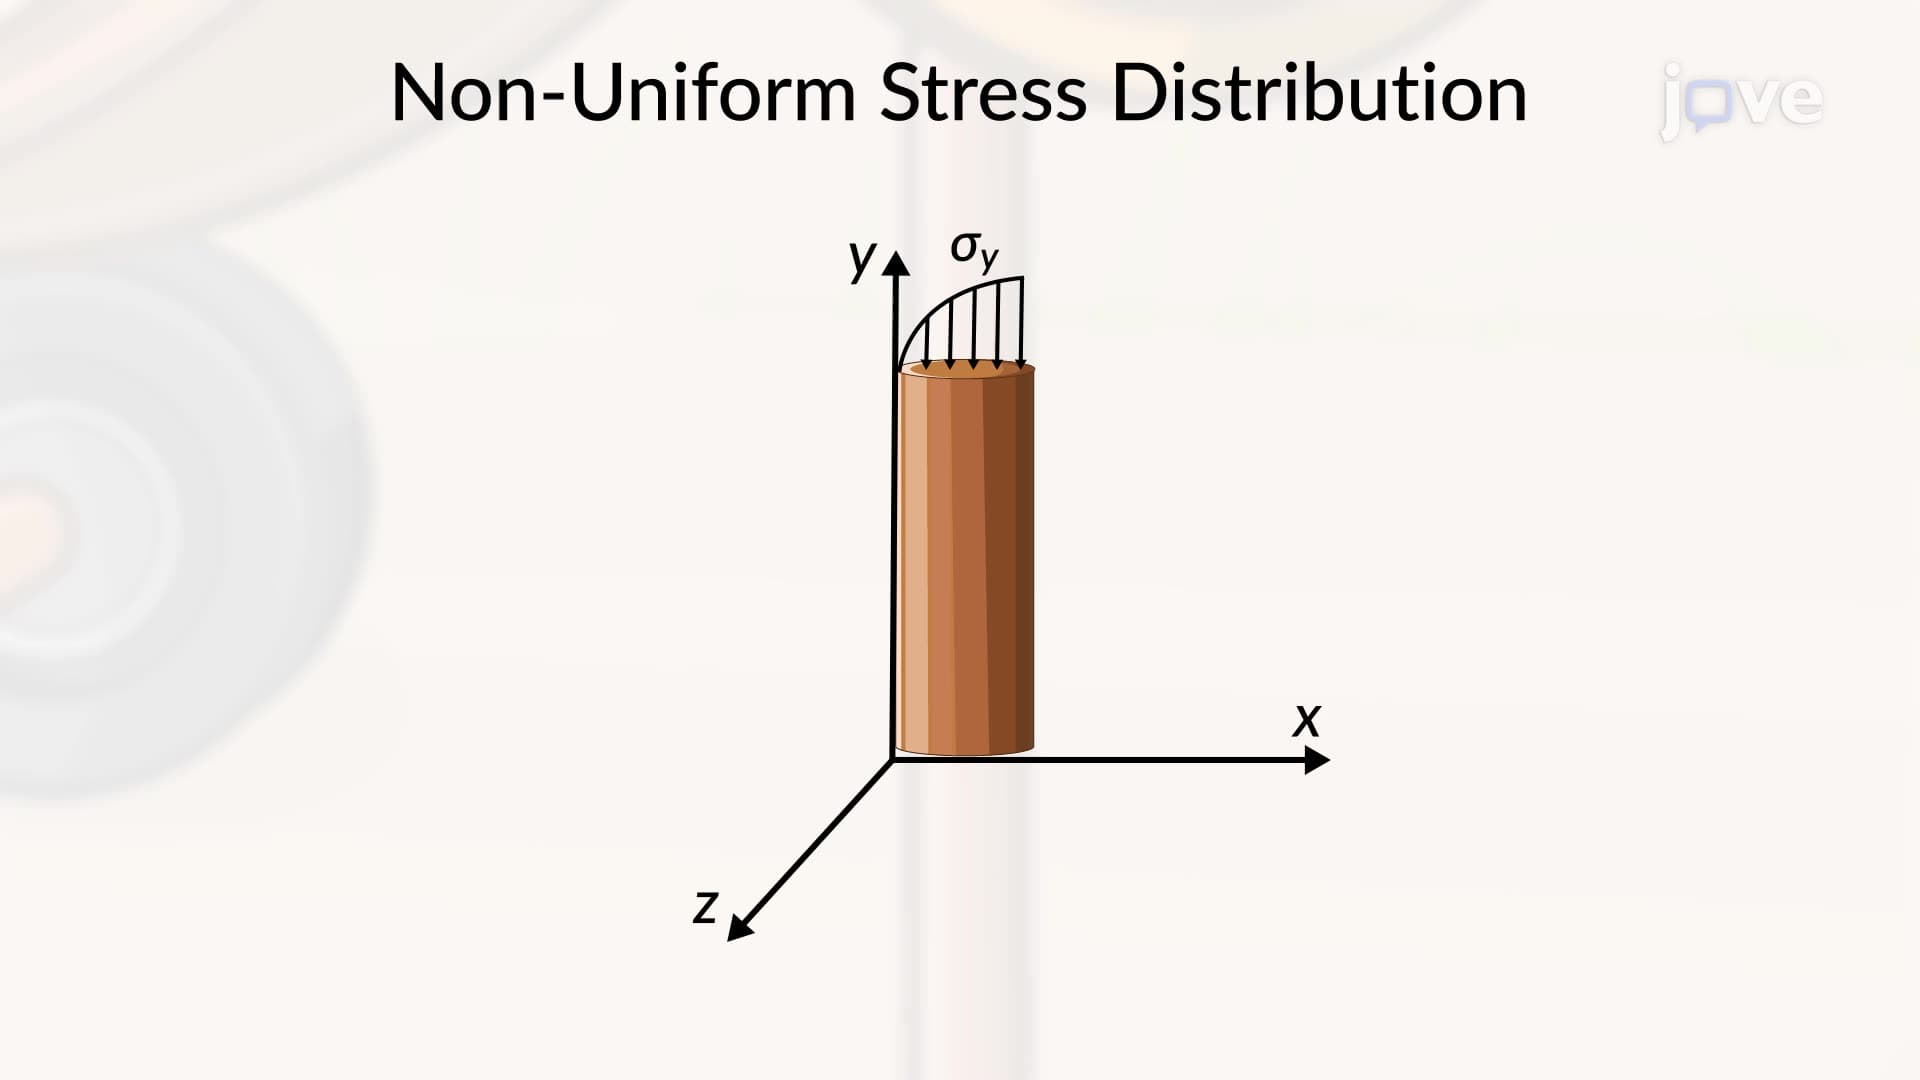
Elastic Strain Energy for Normal Stresses
If...