Related Experiment Video
Updated: Mar 1, 2026
Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
Impact of in-vehicle navigation information on lane-change behavior in urban expressway diverge segments
Meiping Yun1, Jing Zhao2, Jianzhen Zhao1
1Key Laboratory of Road and Traffic Engineering of the Ministry of Education, Tongji University, 4800 Cao'an Road, Shanghai, PR China.

Abstract:
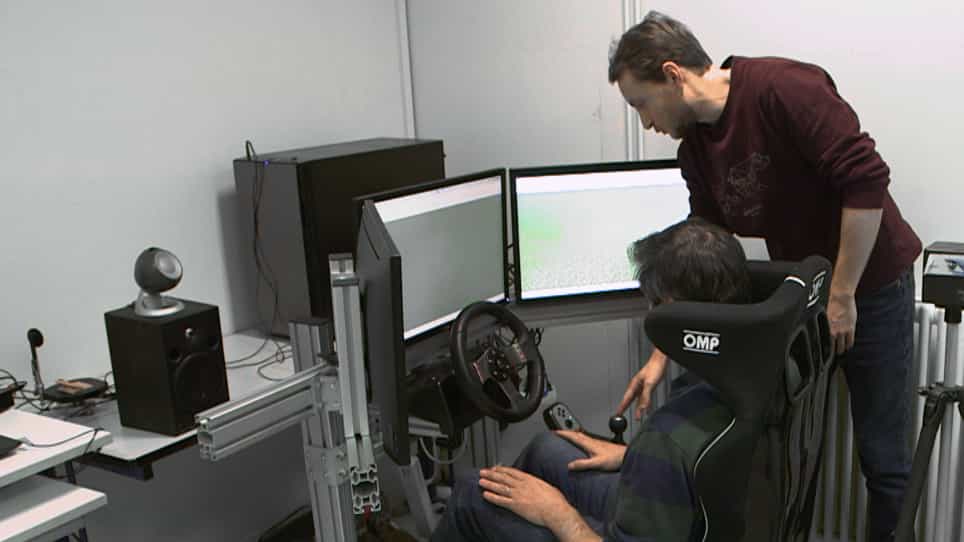
Lane-changing behaviors frequently occur at upstream of the urban expressway off-ramp, which possibly cause bottleneck or accident. This paper studies how in-vehicle navigation information impacts lane-changing behavior at this urban expressway diverge segments with comparison to the traditional road signs by conducting a series of driving simulator experiments, in consideration of variation of the first provision time point and traffic flow density. Firstly, the driving simulator is validated by comparing data of lane-changing position and merging gap from both field survey and simulator. Then comparison study was performed for twelve scenarios which comprise four information provision design schemes under three different traffic flow density status. Lane-changing characteristics are analyzed by selecting six indicators, which are lane-changing merging gap, lane-changing position, lane change delay, lane-changing steering angle, lane-changing deceleration, and the safe distance of lane-changing. The results show that the impact of in-vehicle navigation information on lane-changing behavior varies with traffic flow density and the time point of the first navigation information provided. The in-vehicle navigation information had significant positive impact on lane-changing safety under medium to high density condition. However, the effect is not significant under light density condition. Moreover, more improvement in operational safety and smooth could be gained when the in-vehicle navigation information is provided earlier within range of 2km upstream of the exit gore.
Related Concept Videos
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:27
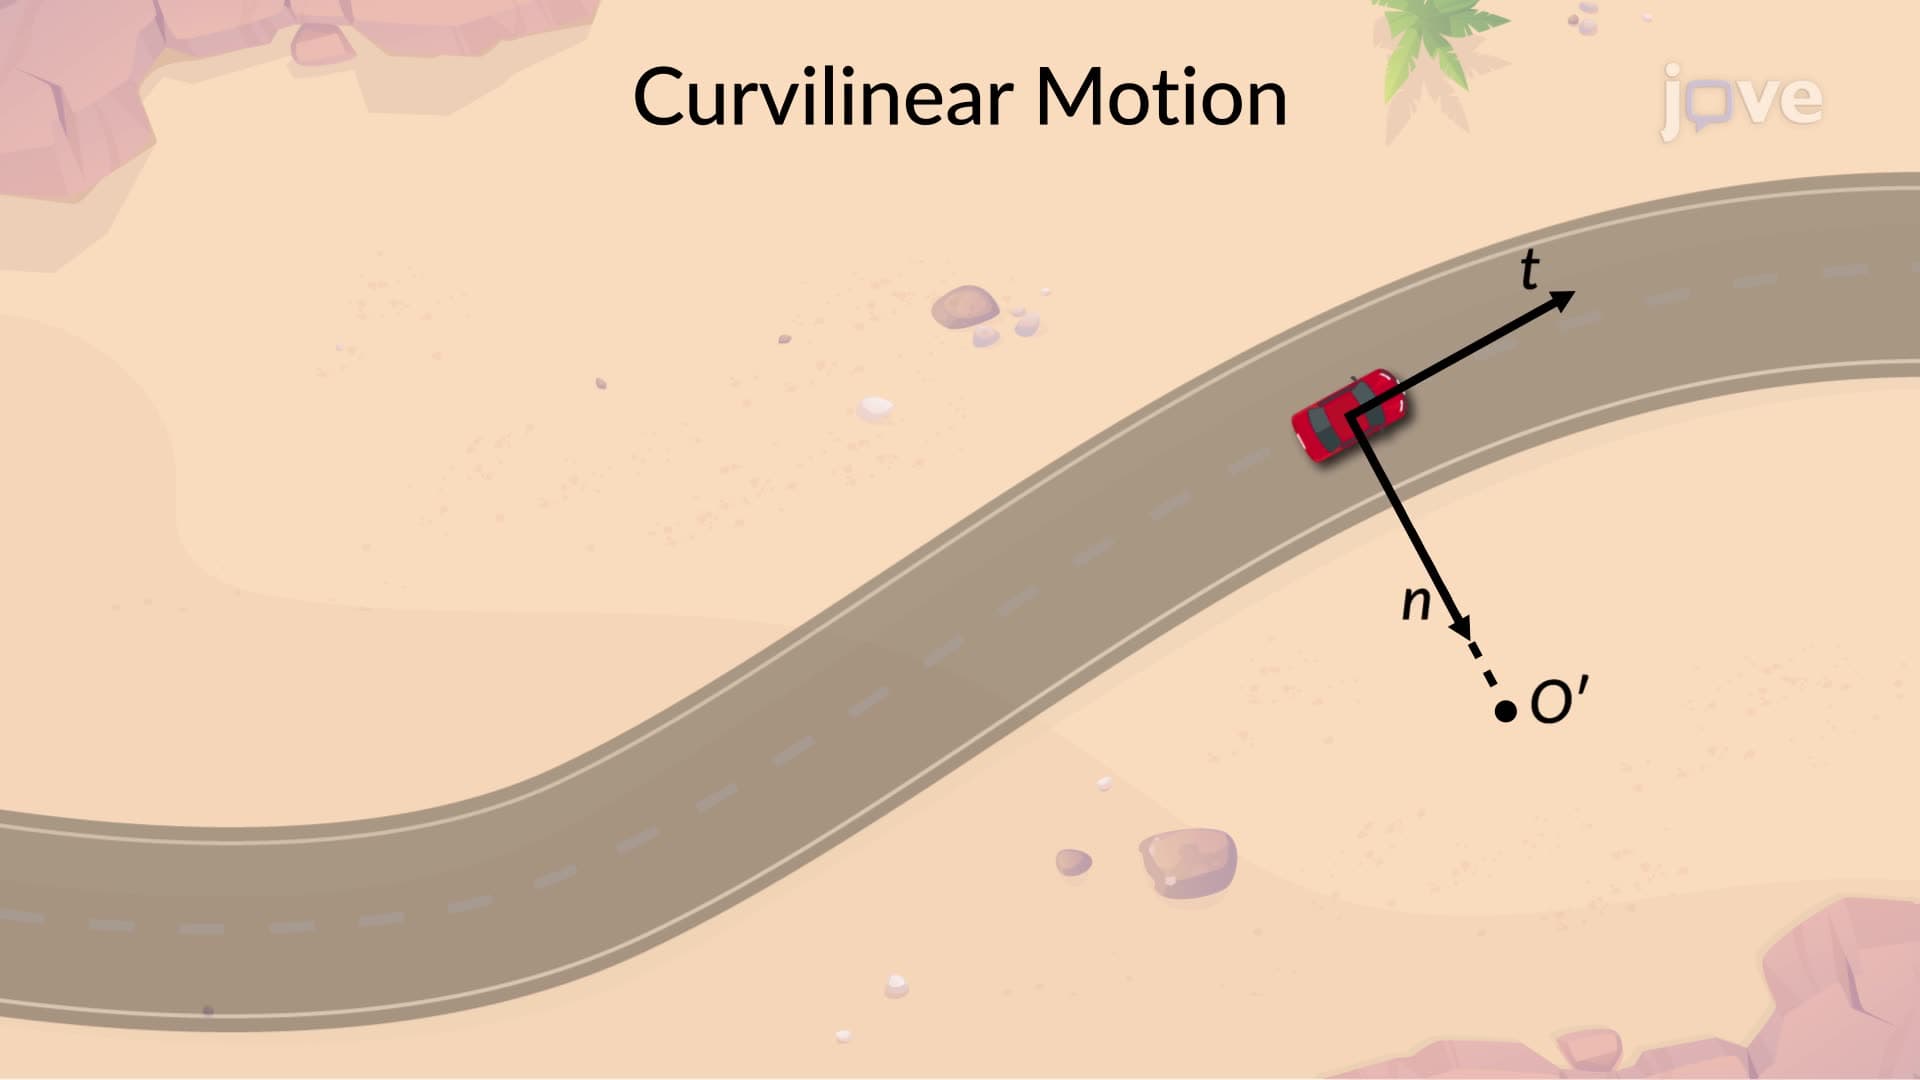
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:25
The Anchoring-and-Adjustment Heuristic
 01:24
Introduction to Vertical Curves
 01:20
Elevation of Intermediate Points on Vertical Curves
 01:29
Sight Distance in a Vertical Curve