Related Experiment Video
Updated: Mar 1, 2026
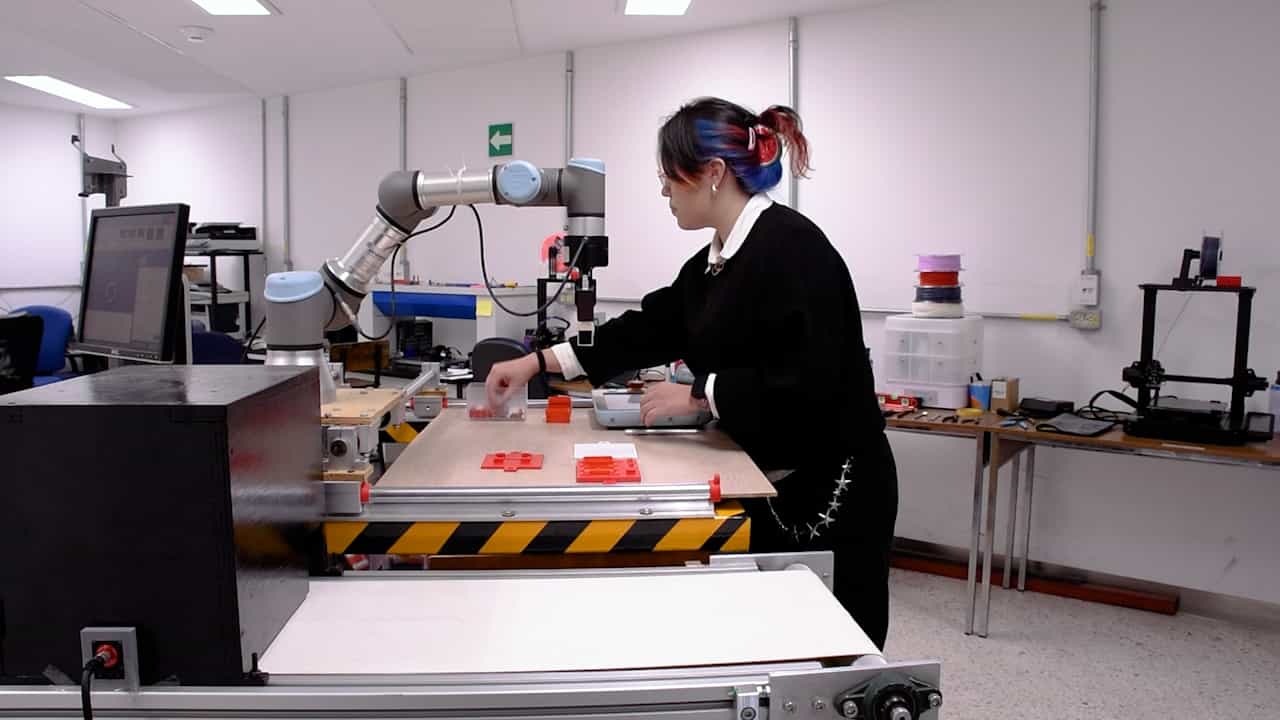
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
From biokinematics to a robotic active vision system
Ouriel Barzilay1, Lihi Zelnik-Manor, Yoram Gutfreund
1Faculty of Mechanical Engineering Technion, Israel Institute of Technology, Haifa, Israel.

Abstract:
Barn owls move their heads in very particular motions, compensating for the quasi-immovability of their eyes. These efficient predators often perform peering side-to-side head motions when scanning their surroundings and seeking prey. In this work, we use the head movements of barn owls as a model to bridge between biological active vision and machine vision. The biomotions are measured and used to actuate a specially built robot equipped with a depth camera for scanning. We hypothesize that the biomotions improve scan accuracy of static objects. Our experiments show that barn owl biomotion-based trajectories consistently improve scan accuracy when compared to intuitive scanning motions. This constitutes proof-of-concept evidence that the vision of robotic systems can be enhanced by bio-inspired viewpoint manipulation. Such biomimetic scanning systems can have many applications, e.g. manufacturing inspection or in autonomous robots.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...