Indirect adaptive fuzzy wavelet neural network with self- recurrent consequent part for AC servo system

Runmin Hou1, Li Wang1, Qiang Gao1
1Department of Mechanical Engineering, Nanjing University of Science and Technology, Nanjing 210094, China.

Abstract:
This paper proposes a novel indirect adaptive fuzzy wavelet neural network (IAFWNN) to control the nonlinearity, wide variations in loads, time-variation and uncertain disturbance of the ac servo system. In the proposed approach, the self-recurrent wavelet neural network (SRWNN) is employed to construct an adaptive self-recurrent consequent part for each fuzzy rule of TSK fuzzy model. For the IAFWNN controller, the online learning algorithm is based on back propagation (BP) algorithm. Moreover, an improved particle swarm optimization (IPSO) is used to adapt the learning rate. The aid of an adaptive SRWNN identifier offers the real-time gradient information to the adaptive fuzzy wavelet neural controller to overcome the impact of parameter variations, load disturbances and other uncertainties effectively, and has a good dynamic. The asymptotical stability of the system is guaranteed by using the Lyapunov method. The result of the simulation and the prototype test prove that the proposed are effective and suitable.
Related Concept Videos
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
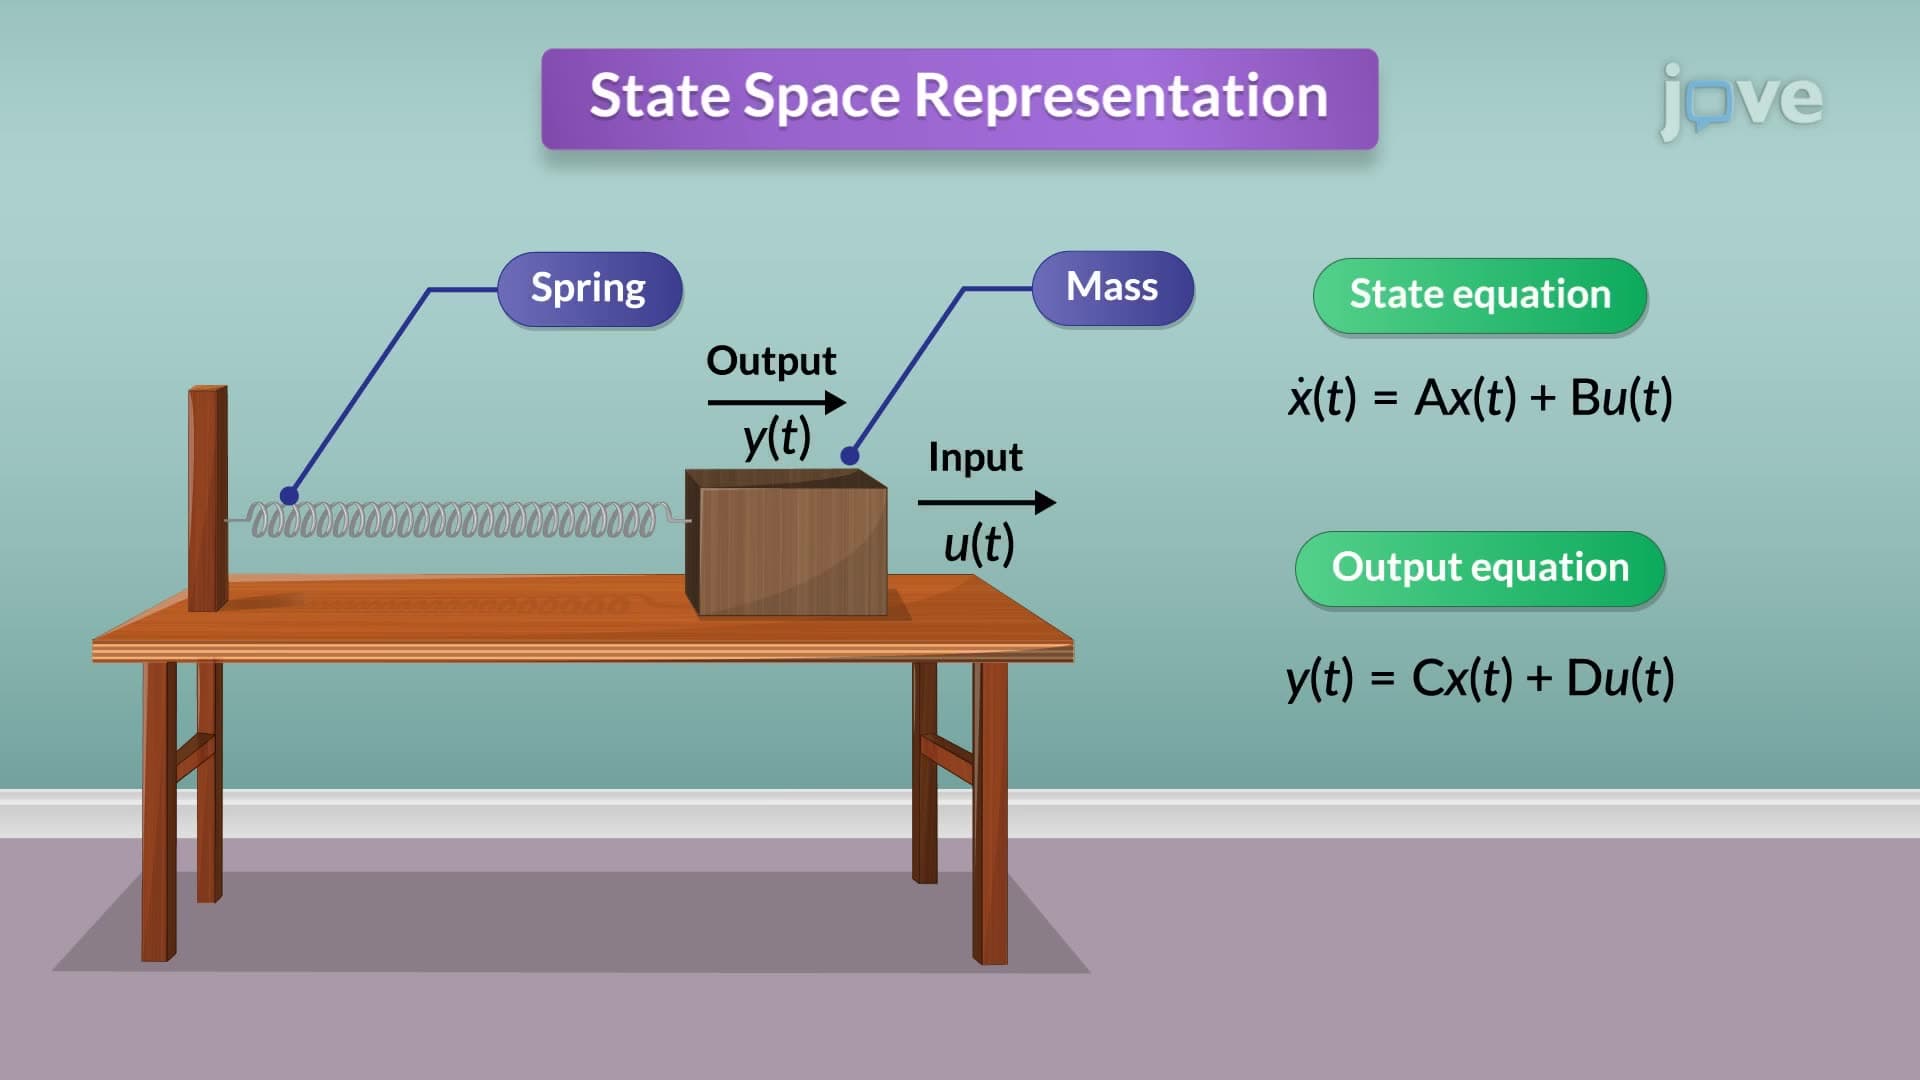
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:23
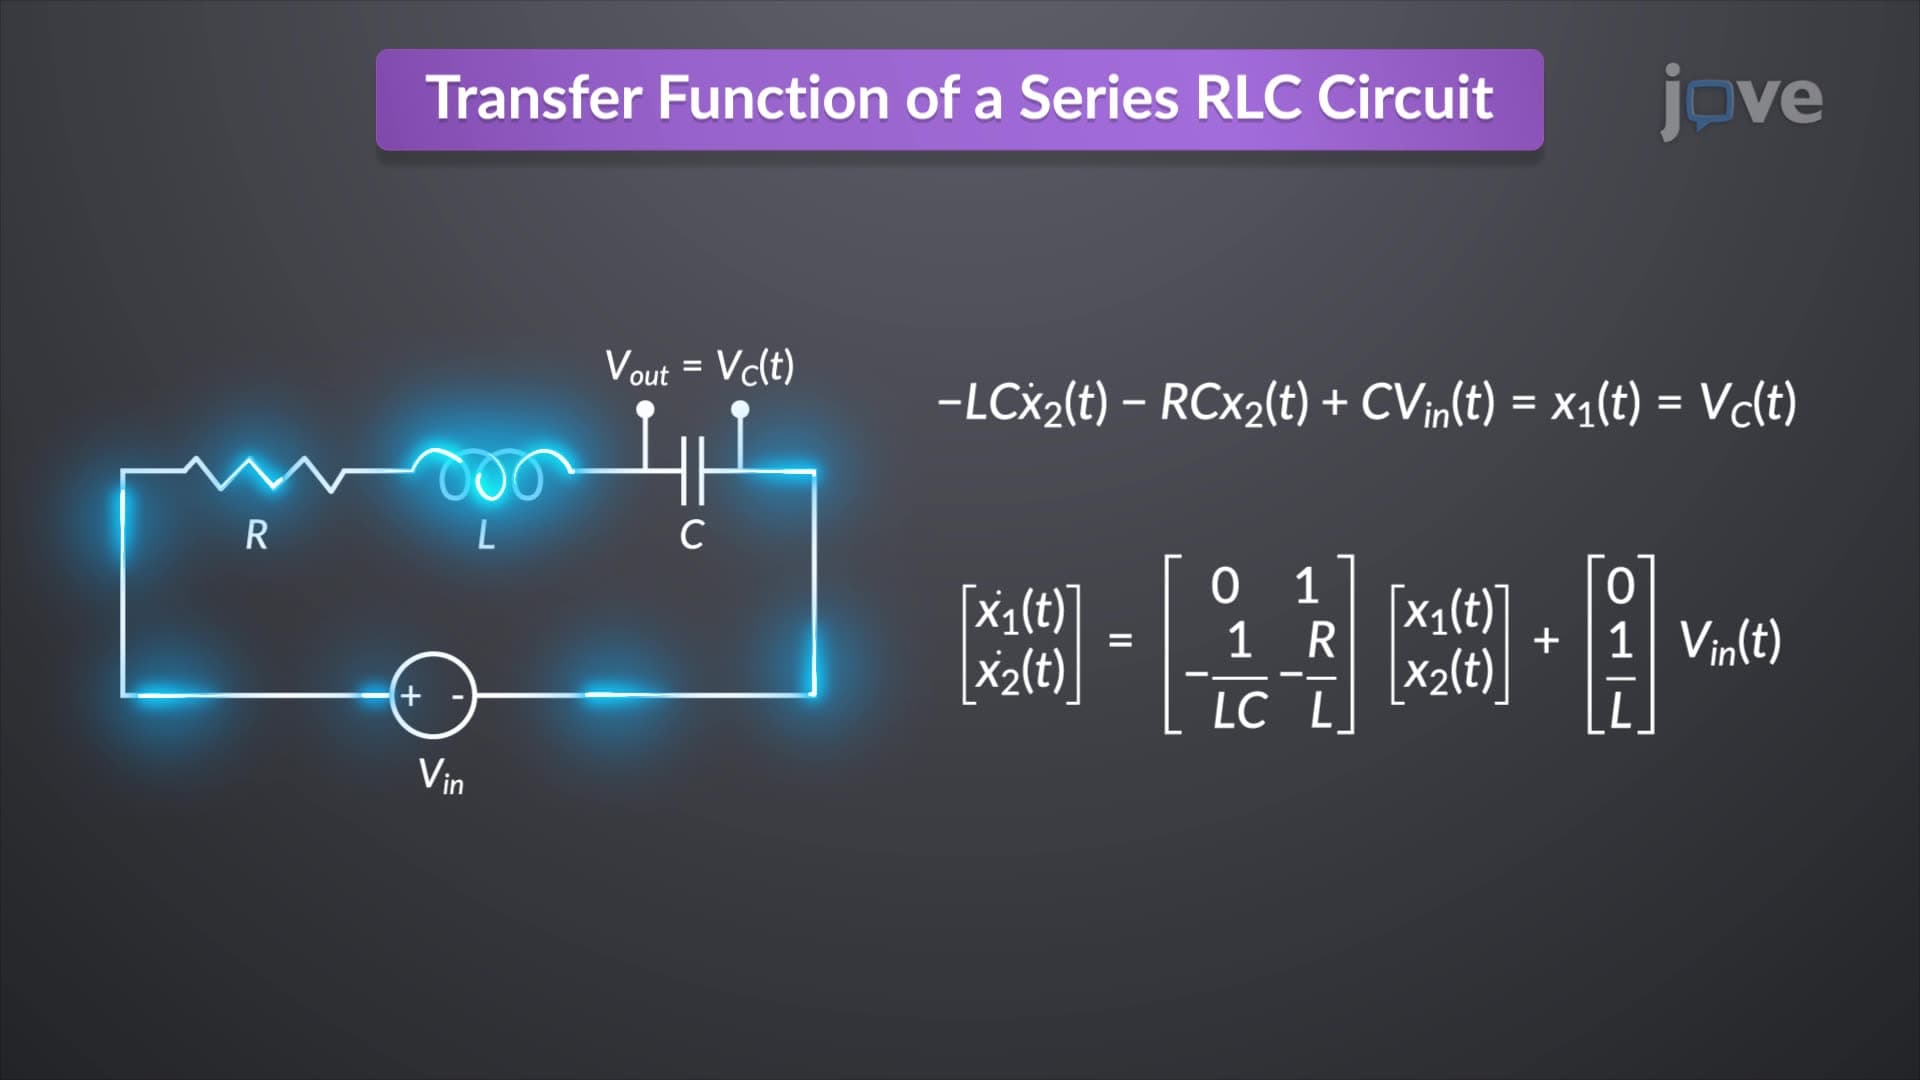
Transfer Function to State Space
In an RLC...
 01:19
PID Controller