Stabilization of systems with interval time-varying delay based on delay decomposing approach
Related Experiment Video
Updated: Mar 1, 2026
Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
Wei Qian1, Manman Yuan1, Lei Wang2
1School of Electrical Engineering and Automation, Henan Polytechnic University, 454000 Henan, China.

Abstract:
The paper considers the stabilization for systems with interval time-varying delay. By decomposing the delay interval into multiple equidistant subintervals and considering the triple integral terms, a novel Lyapunov-krasovskii functional(LKF) is defined. Then extended integral inequality and convex combination approach are used to estimate the derivative of the constructed functional, and as a result, the new stability criterion with less conservatism and decision variables is obtained. On this basis, the state feedback controller is designed, by using linearization method, the existence condition of controller is obtained in terms of linear matrix inequalities(LMIs), and the specific form of controller is also given, moreover, by selecting the appropriate parameter value, the stabilization time of the system can be reduced. Numerical examples are given to illustrate the effectiveness of the proposed method.
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:31
Classification of Systems-II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:28
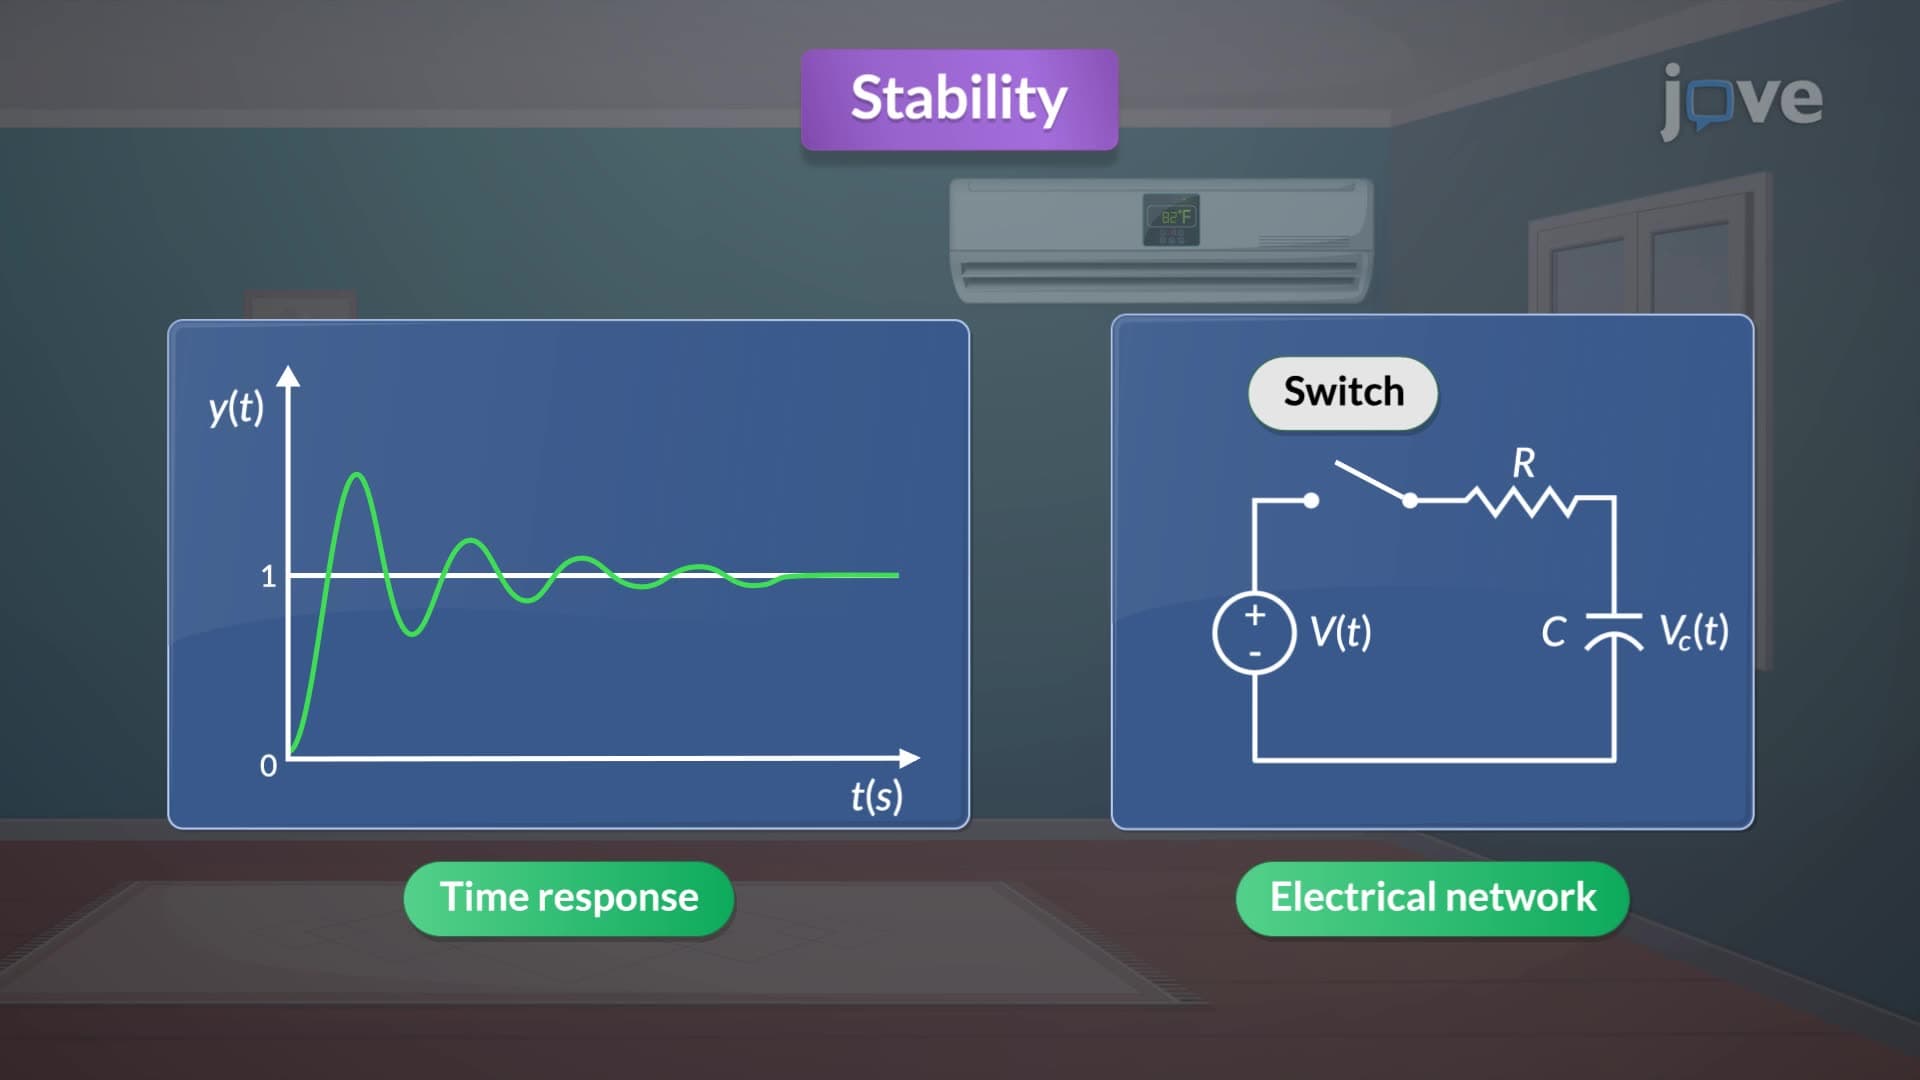
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:18
Second Order systems II