Related Experiment Video
Updated: Feb 28, 2026

Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Indoor Autonomous Control of a Two-Wheeled Inverted Pendulum Vehicle Using Ultra Wide Band Technology
Dunzhu Xia1, Yanhong Yao2, Limei Cheng3
1Key Laboratory of Micro-inertial Instrument and Advanced Navigation Technology, Ministry of Education, School of Instrument Science and Engineering, Southeast University, Nanjing 210096, China. xiadz_1999@163.com.

Abstract:
In this paper, we aimed to achieve the indoor tracking control of a two-wheeled inverted pendulum (TWIP) vehicle. The attitude data are acquired from a low cost micro inertial measurement unit (IMU), and the ultra-wideband (UWB) technology is utilized to obtain an accurate estimation of the TWIP's position. We propose a dual-loop control method to realize the simultaneous balance and trajectory tracking control for the TWIP vehicle. A robust adaptive second-order sliding mode control (2-RASMC) method based on an improved super-twisting (STW) algorithm is investigated to obtain the control laws, followed by several simulations to verify its robustness. The outer loop controller is designed using the idea of backstepping. Moreover, three typical trajectories, including a circle, a trifolium and a hexagon, have been designed to prove the adaptability of the control combinations. Six different combinations of inner and outer loop control algorithms have been compared, and the characteristics of inner and outer loop algorithm combinations have been analyzed. Simulation results demonstrate its tracking performance and thus verify the validity of the proposed control methods. Trajectory tracking experiments in a real indoor environment have been performed using our experimental vehicle to further validate the feasibility of the proposed algorithm in practice.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:09
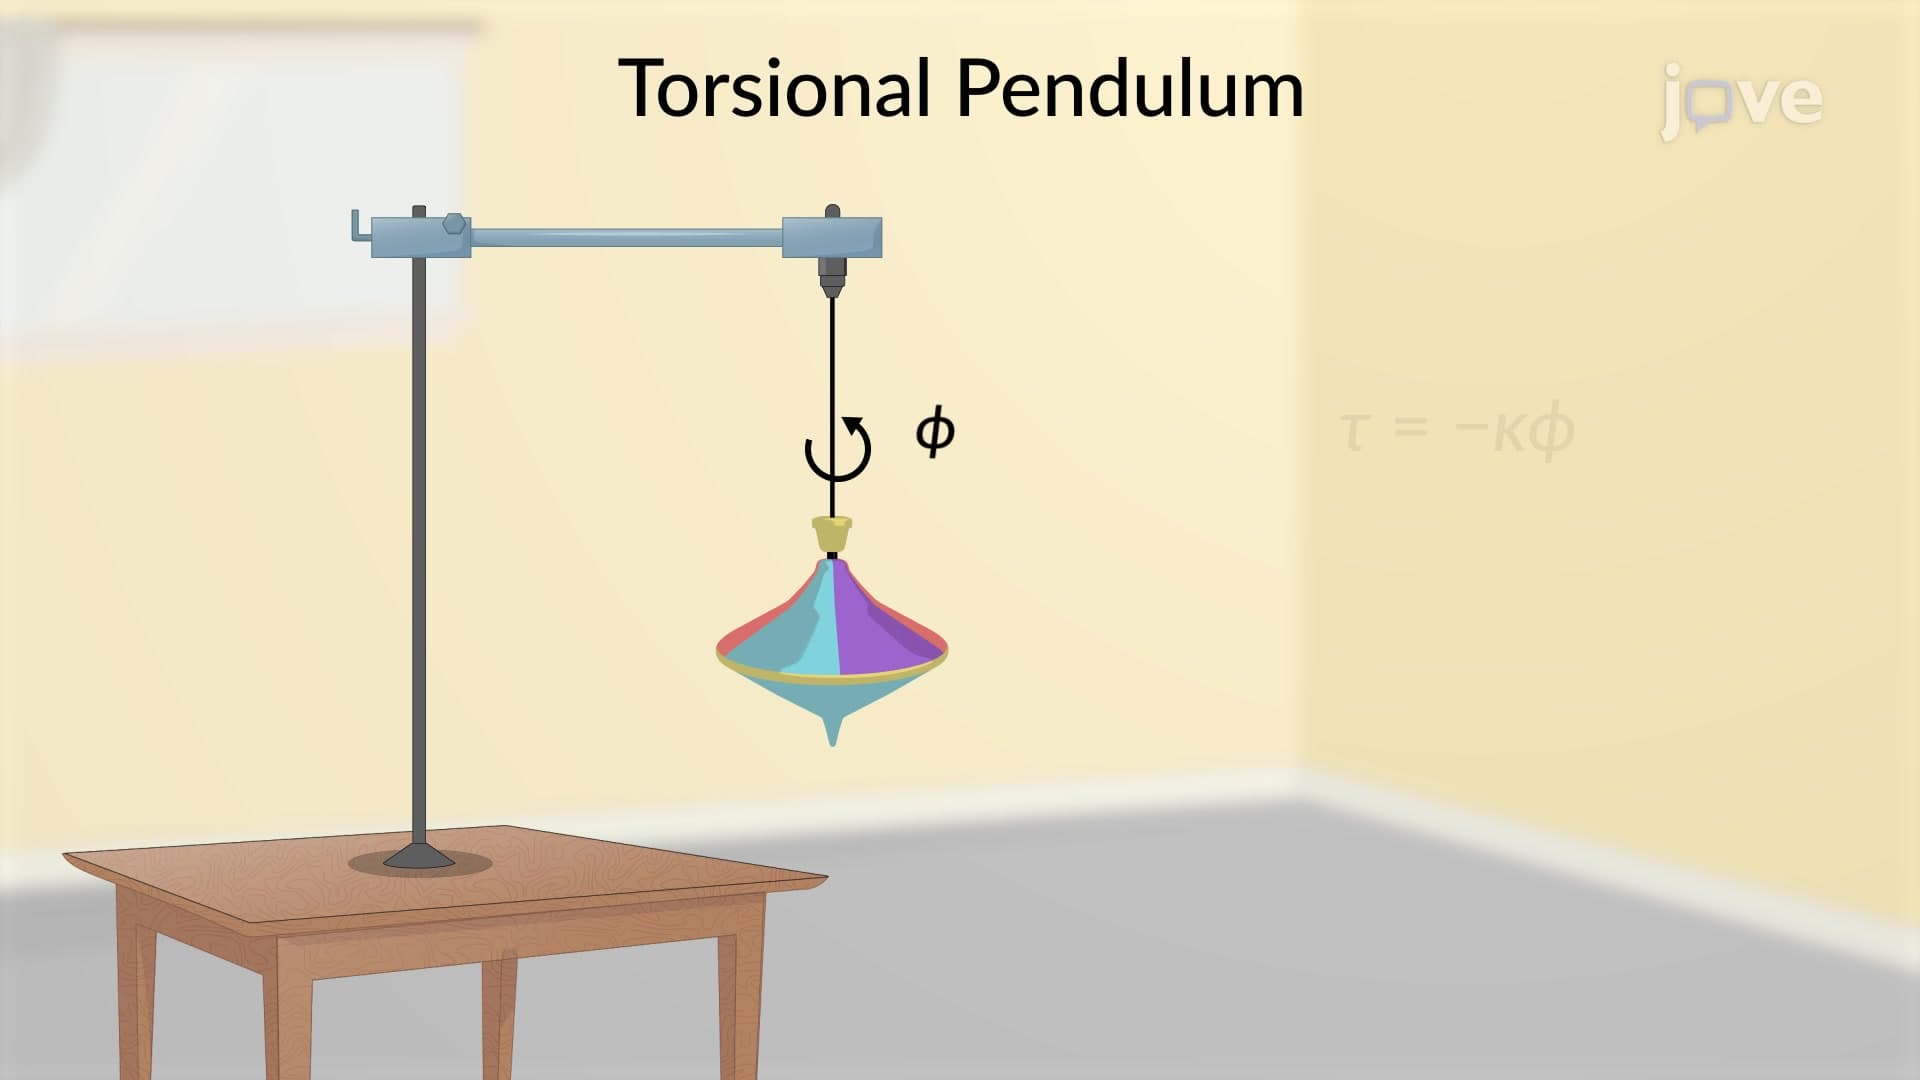
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
Simple Harmonic Motion
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...