Distributed fault-tolerant time-varying formation control for high-order linear multi-agent systems with actuator failures

Yongzhao Hua1, Xiwang Dong1, Qingdong Li1
1School of Automation Science and Electrical Engineering, Science and Technology on Aircraft Control Laboratory, Beihang University, Beijing, 100191, P.R. China.

Abstract:
This paper investigates the fault-tolerant time-varying formation control problems for high-order linear multi-agent systems in the presence of actuator failures. Firstly, a fully distributed formation control protocol is presented to compensate for the influences of both bias fault and loss of effectiveness fault. Using the adaptive online updating strategies, no global knowledge about the communication topology is required and the bounds of actuator failures can be unknown. Then an algorithm is proposed to determine the control parameters of the fault-tolerant formation protocol, where the time-varying formation feasible conditions and an approach to expand the feasible formation set are given. Furthermore, the stability of the proposed algorithm is proven based on the Lyapunov-like theory. Finally, two simulation examples are given to demonstrate the effectiveness of the theoretical results.

Related Concept Videos
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:21
Distributed Loads: Problem Solving
 01:28
Load-frequency control
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:18
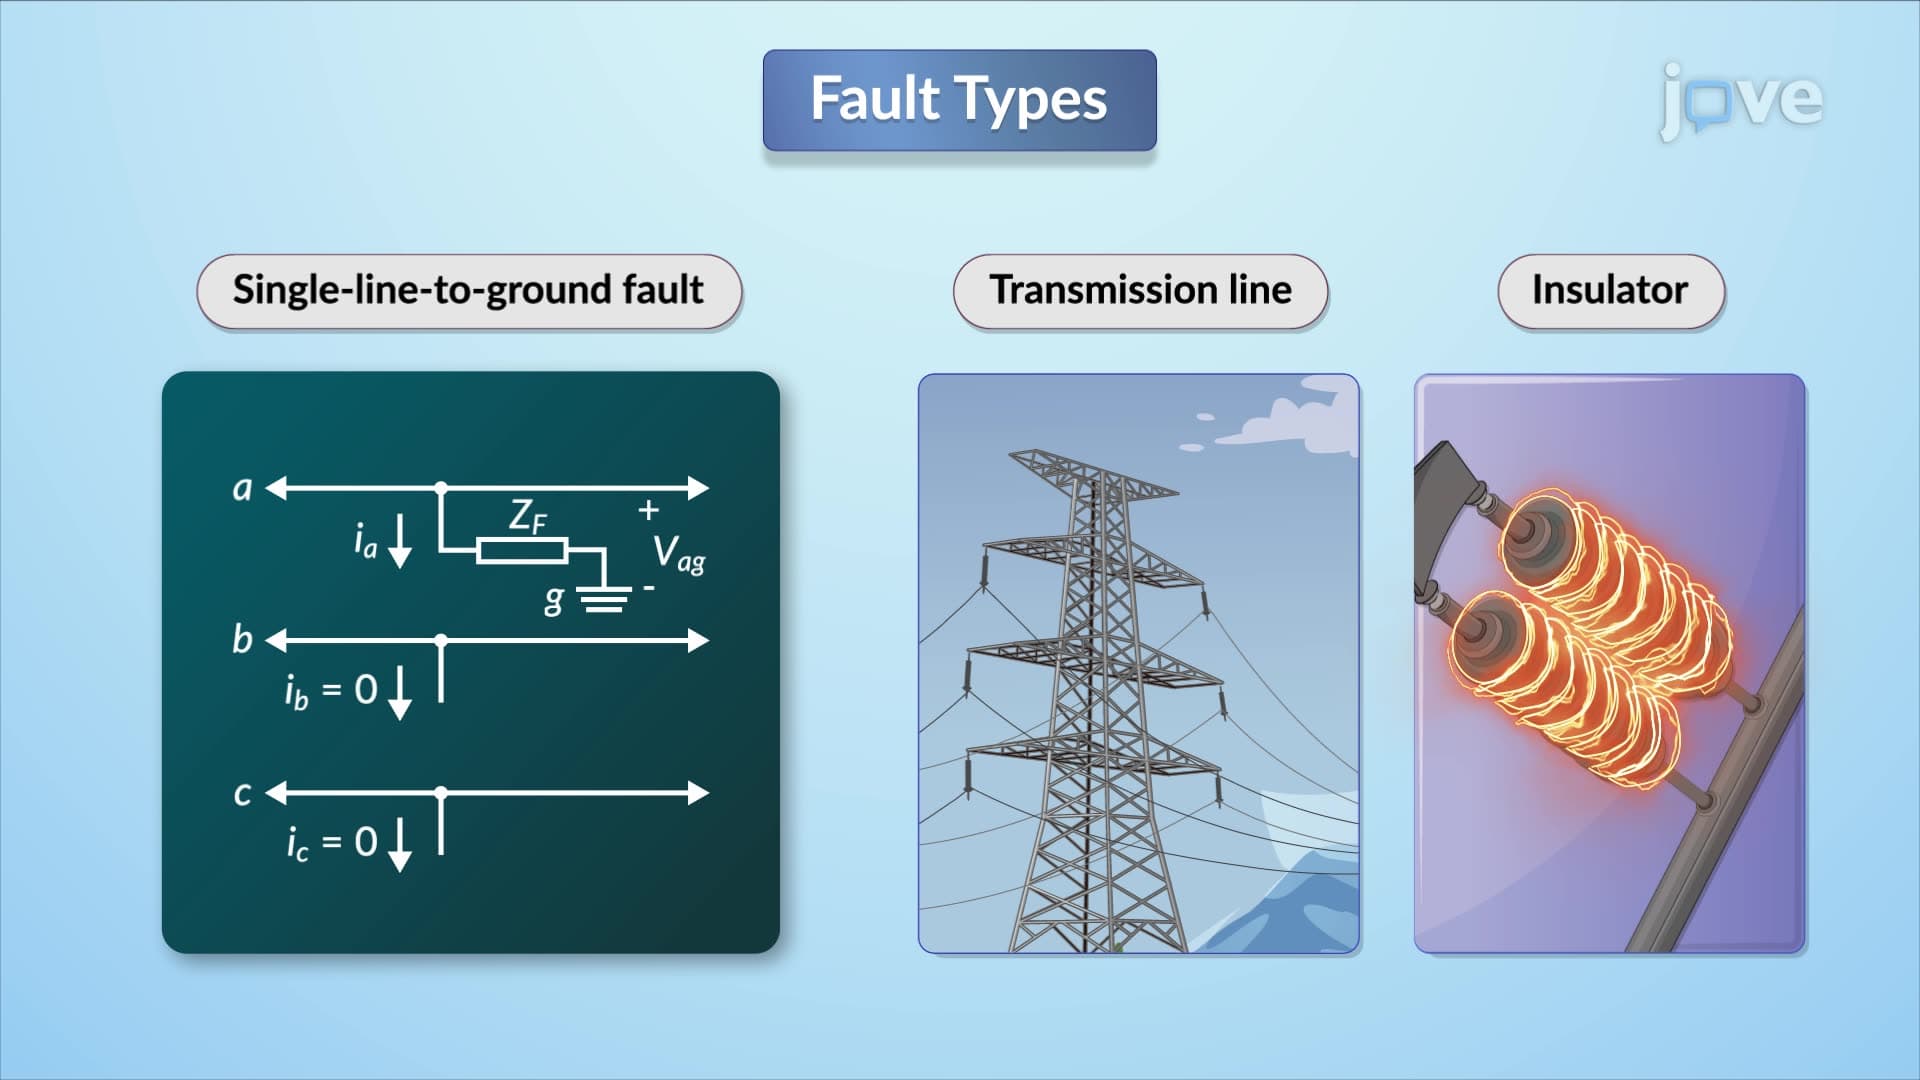
Fault Types
For line-to-line faults occurring between phases B and C, the...