Related Experiment Video
Updated: Feb 27, 2026

Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Reduced-order description of transient instabilities and computation of finite-time Lyapunov exponents
Hessam Babaee1, Mohamad Farazmand1, George Haller2
1Department of Mechanical Engineering, MIT Cambridge, Cambridge, Massachusetts 02139, USA.

Abstract:
High-dimensional chaotic dynamical systems can exhibit strongly transient features. These are often associated with instabilities that have a finite-time duration. Because of the finite-time character of these transient events, their detection through infinite-time methods, e.g., long term averages, Lyapunov exponents or information about the statistical steady-state, is not possible. Here, we utilize a recently developed framework, the Optimally Time-Dependent (OTD) modes, to extract a time-dependent subspace that spans the modes associated with transient features associated with finite-time instabilities. As the main result, we prove that the OTD modes, under appropriate conditions, converge exponentially fast to the eigendirections of the Cauchy-Green tensor associated with the most intense finite-time instabilities. Based on this observation, we develop a reduced-order method for the computation of finite-time Lyapunov exponents (FTLE) and vectors. In high-dimensional systems, the computational cost of the reduced-order method is orders of magnitude lower than the full FTLE computation. We demonstrate the validity of the theoretical findings on two numerical examples.
Related Concept Videos
 01:28
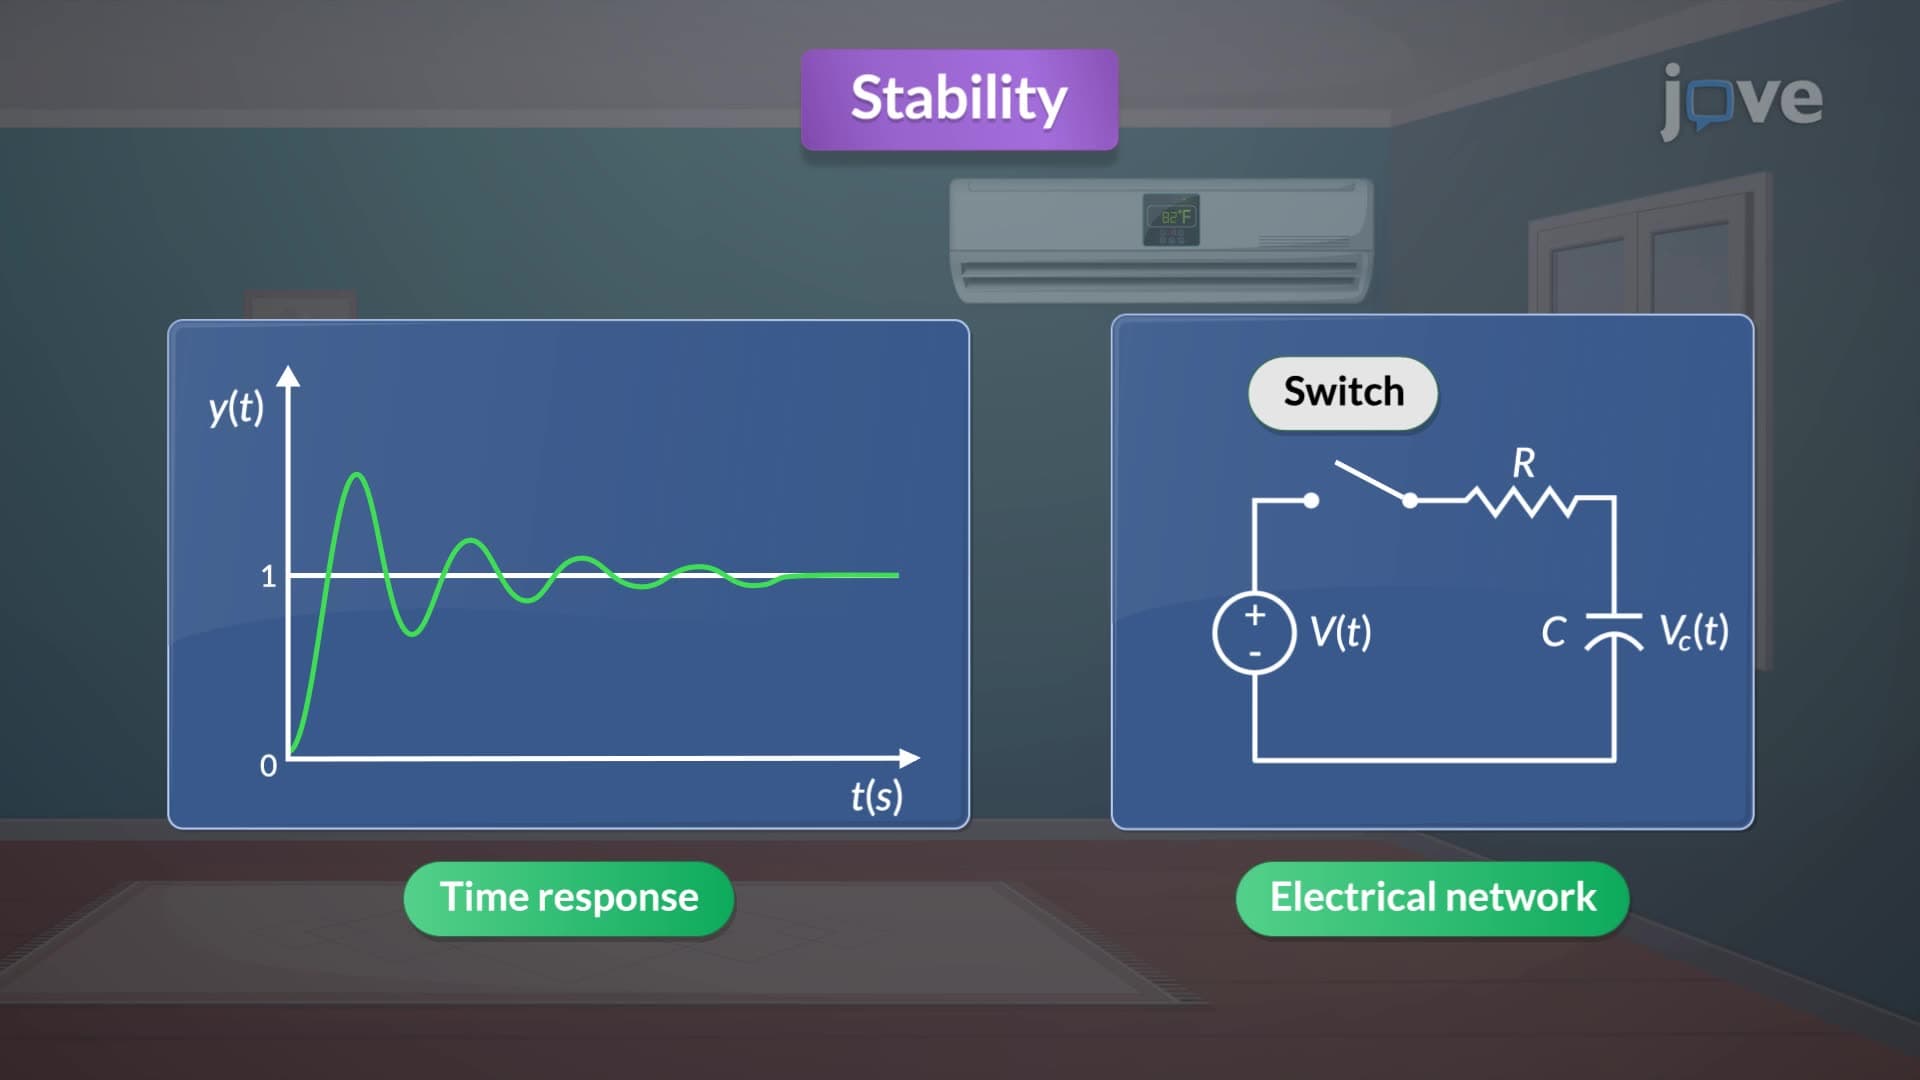
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:21
First Order Systems
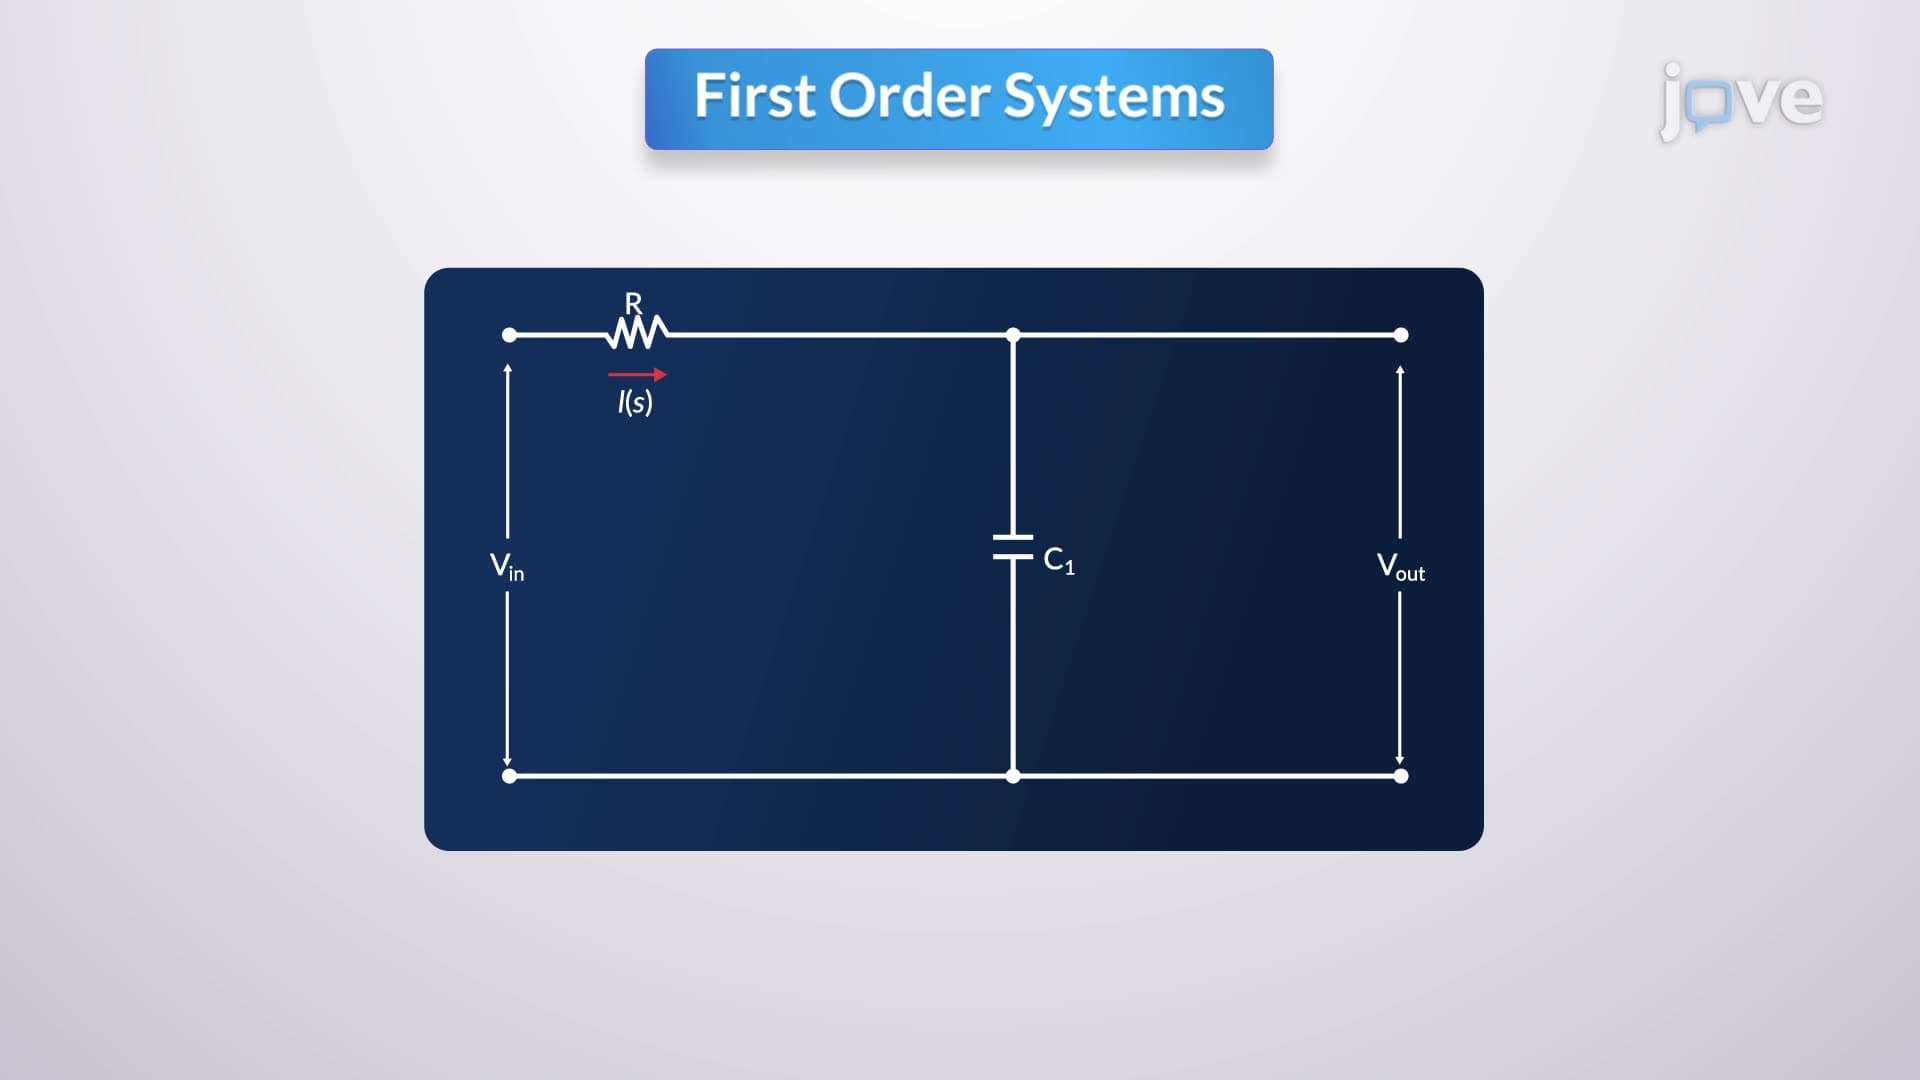
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:18
Second Order systems II
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...