Related Experiment Video
Updated: Feb 25, 2026
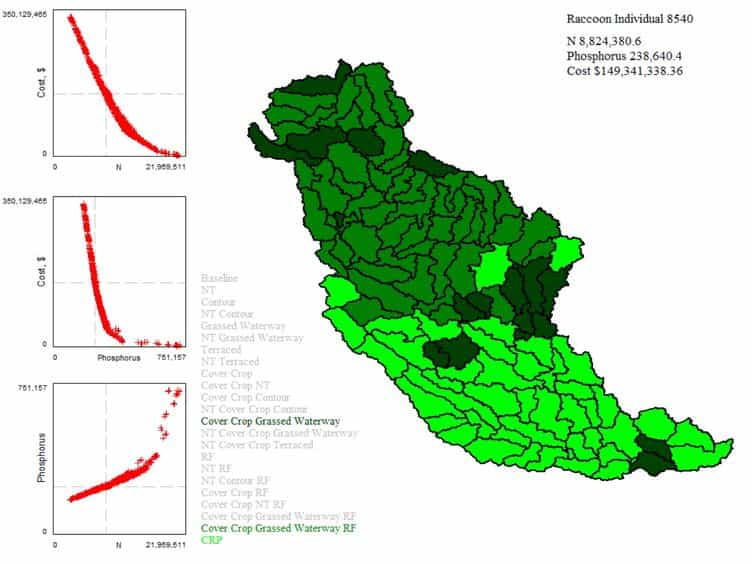
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Geomagnetic Navigation of Autonomous Underwater Vehicle Based on Multi-objective Evolutionary Algorithm
Hong Li1, Mingyong Liu1, Feihu Zhang1
1School of Marine Science and Technology, Northwestern Polytechnical UniversityXi'an, China.

Abstract:
This paper presents a multi-objective evolutionary algorithm of bio-inspired geomagnetic navigation for Autonomous Underwater Vehicle (AUV). Inspired by the biological navigation behavior, the solution was proposed without using a priori information, simply by magnetotaxis searching. However, the existence of the geomagnetic anomalies has significant influence on the geomagnetic navigation system, which often disrupts the distribution of the geomagnetic field. An extreme value region may easily appear in abnormal regions, which makes AUV lost in the navigation phase. This paper proposes an improved bio-inspired algorithm with behavior constraints, for sake of making AUV escape from the abnormal region. First, the navigation problem is considered as the optimization problem. Second, the environmental monitoring operator is introduced, to determine whether the algorithm falls into the geomagnetic anomaly region. Then, the behavior constraint operator is employed to get out of the abnormal region. Finally, the termination condition is triggered. Compared to the state-of- the-art, the proposed approach effectively overcomes the disturbance of the geomagnetic abnormal. The simulation result demonstrates the reliability and feasibility of the proposed approach in complex environments.

Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:30
Types of Global Positioning System Surveys
 01:18
Other Unique Bacteria
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...