Related Experiment Video
Updated: Feb 25, 2026


Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Leg-local neural mechanisms for searching and learning enhance robotic locomotion
Nicholas S Szczecinski1, Roger D Quinn2
1, 10900 Euclid Ave, Cleveland, OH, 44106, USA. nicholas.szczecinski@case.edu.

Abstract:
Adapting motor output based on environmental forces is critical for successful locomotion in the real world. Arthropods use at least two neural mechanisms to adjust muscle activation while walking based on detected forces. Mechanism 1 uses negative feedback of leg depressor force to ensure that each stance leg supports an appropriate amount of the body's weight. Mechanism 2 encourages searching for ground contact if the leg supports no body weight. We expand the neural controller for MantisBot, a robot based upon a praying mantis, to include these mechanisms by incorporating leg-local memory and command neurons, as observed in arthropods. We present results from MantisBot transitioning between searching and stepping, mimicking data from animals as reported in the literature.


Related Concept Videos
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:18
Hierarchy of Motor Control
 01:11
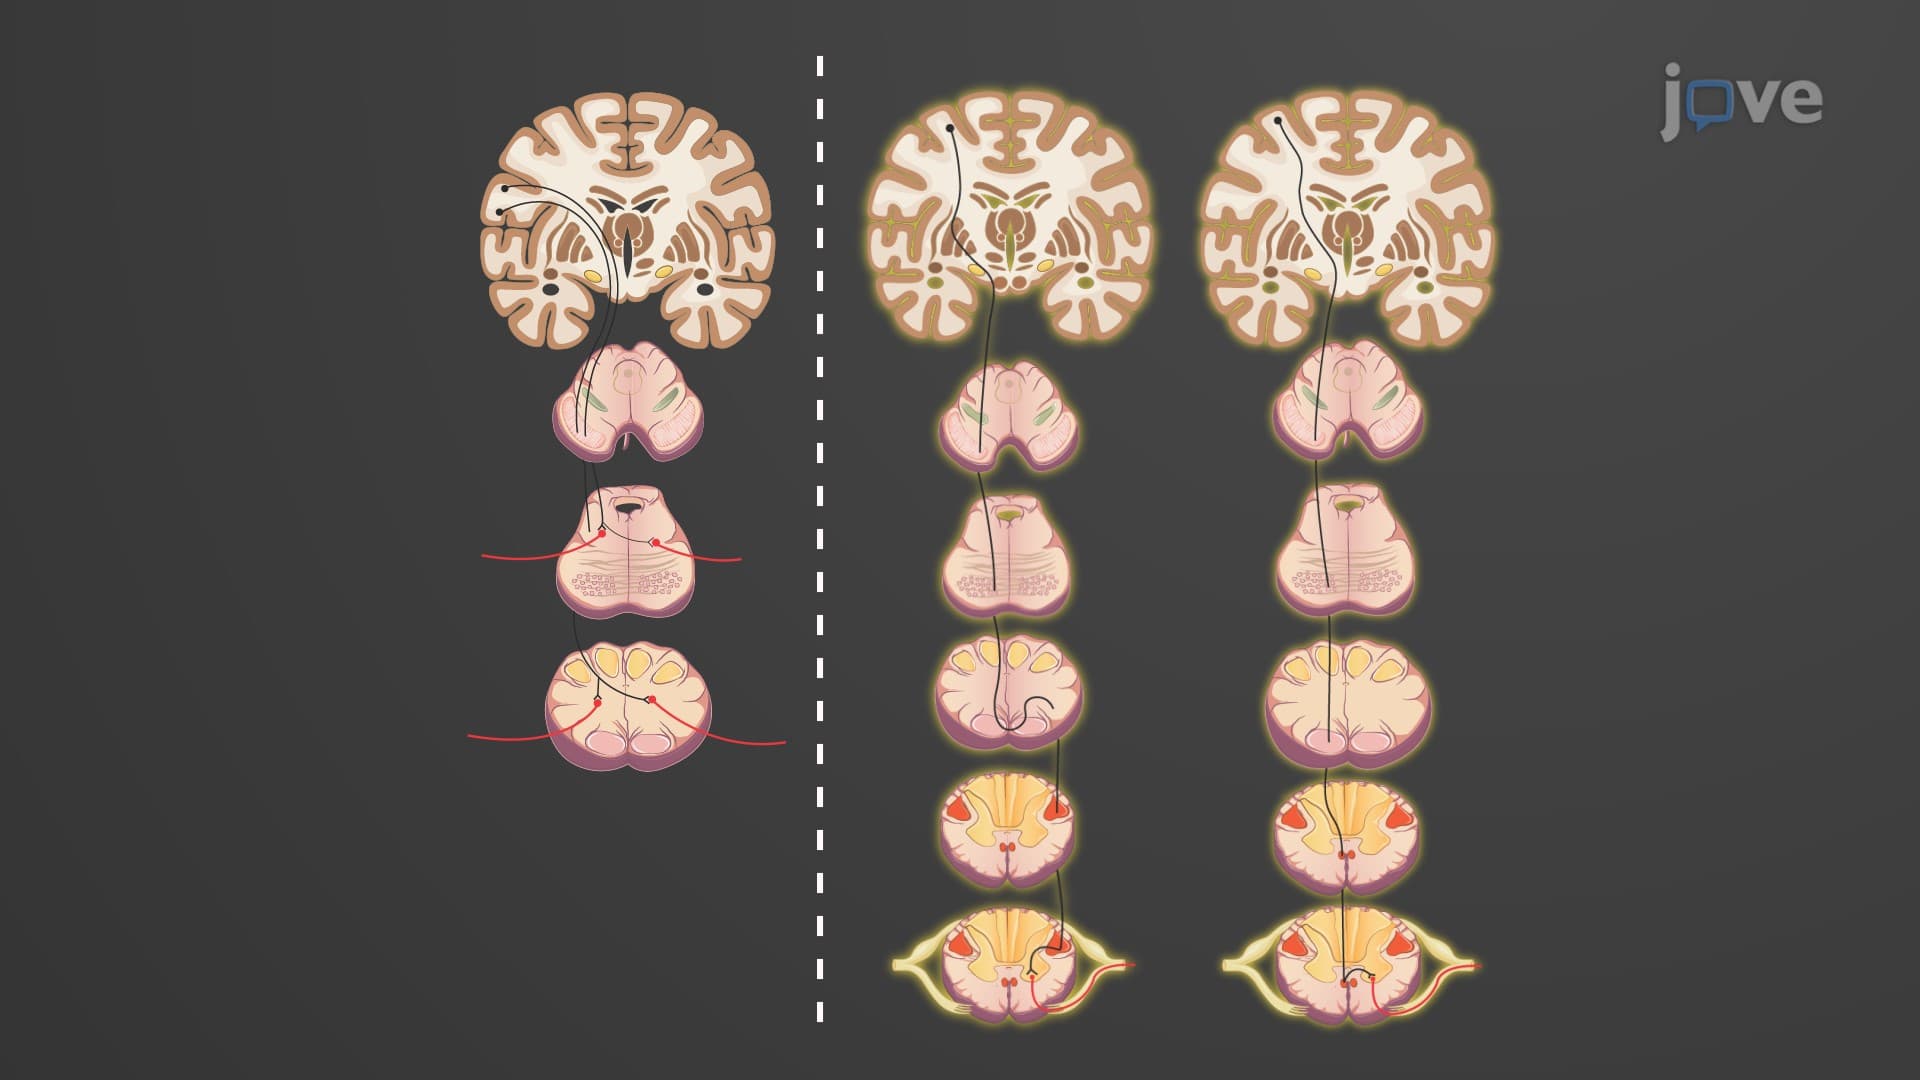
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...