Related Experiment Video
Updated: Feb 25, 2026

Using Neuron Spiking Activity to Trigger Closed-Loop Stimuli in Neurophysiological Experiments
Published on: November 12, 2019
The Mechanical Representation of Temporal Delays
Raz Leib1, Amir Karniel2, Ferdinando A Mussa-Ivaldi3,4
1Department of Biomedical Engineering, Ben-Gurion University of the Negev, Beer Sheva, Israel. leibra@post.bgu.ac.il.

Abstract:
When we knock on a door, we perceive the impact as a collection of simultaneous events, combining sound, sight, and tactile sensation. In reality, information from different modalities but from a single source is flowing inside the brain along different pathways, reaching processing centers at different times. Therefore, interpreting different sensory modalities which seem to occur simultaneously requires information processing that accounts for these different delays. As in a computer-based robotic system, does the brain use some explicit estimation of the time delay, to realign the sensory flows? Or does it compensate for temporal delays by representing them as changes in the body/environment mechanics? Using delayed-state or an approximation for delayed-state manipulations between visual and proprioceptive feedback during a tracking task, we show that tracking errors, grip forces, and learning curves are consistent with predictions of a representation that is based on approximation for delay, refuting an explicit delayed-state representation. Delayed-state representations are based on estimating the time elapsed between the movement commands and their observed consequences. In contrast, an approximation for delay representations result from estimating the instantaneous relation between the expected and observed motion variables, without explicit reference to time.
Related Concept Videos
 01:29
Transformations of Functions II
 01:24
Properties of DTFT I
The linearity property of DTFTs is fundamental. If two discrete-time signals are multiplied by constants a and b respectively, and then combined to...
 01:22
Mechanical Systems
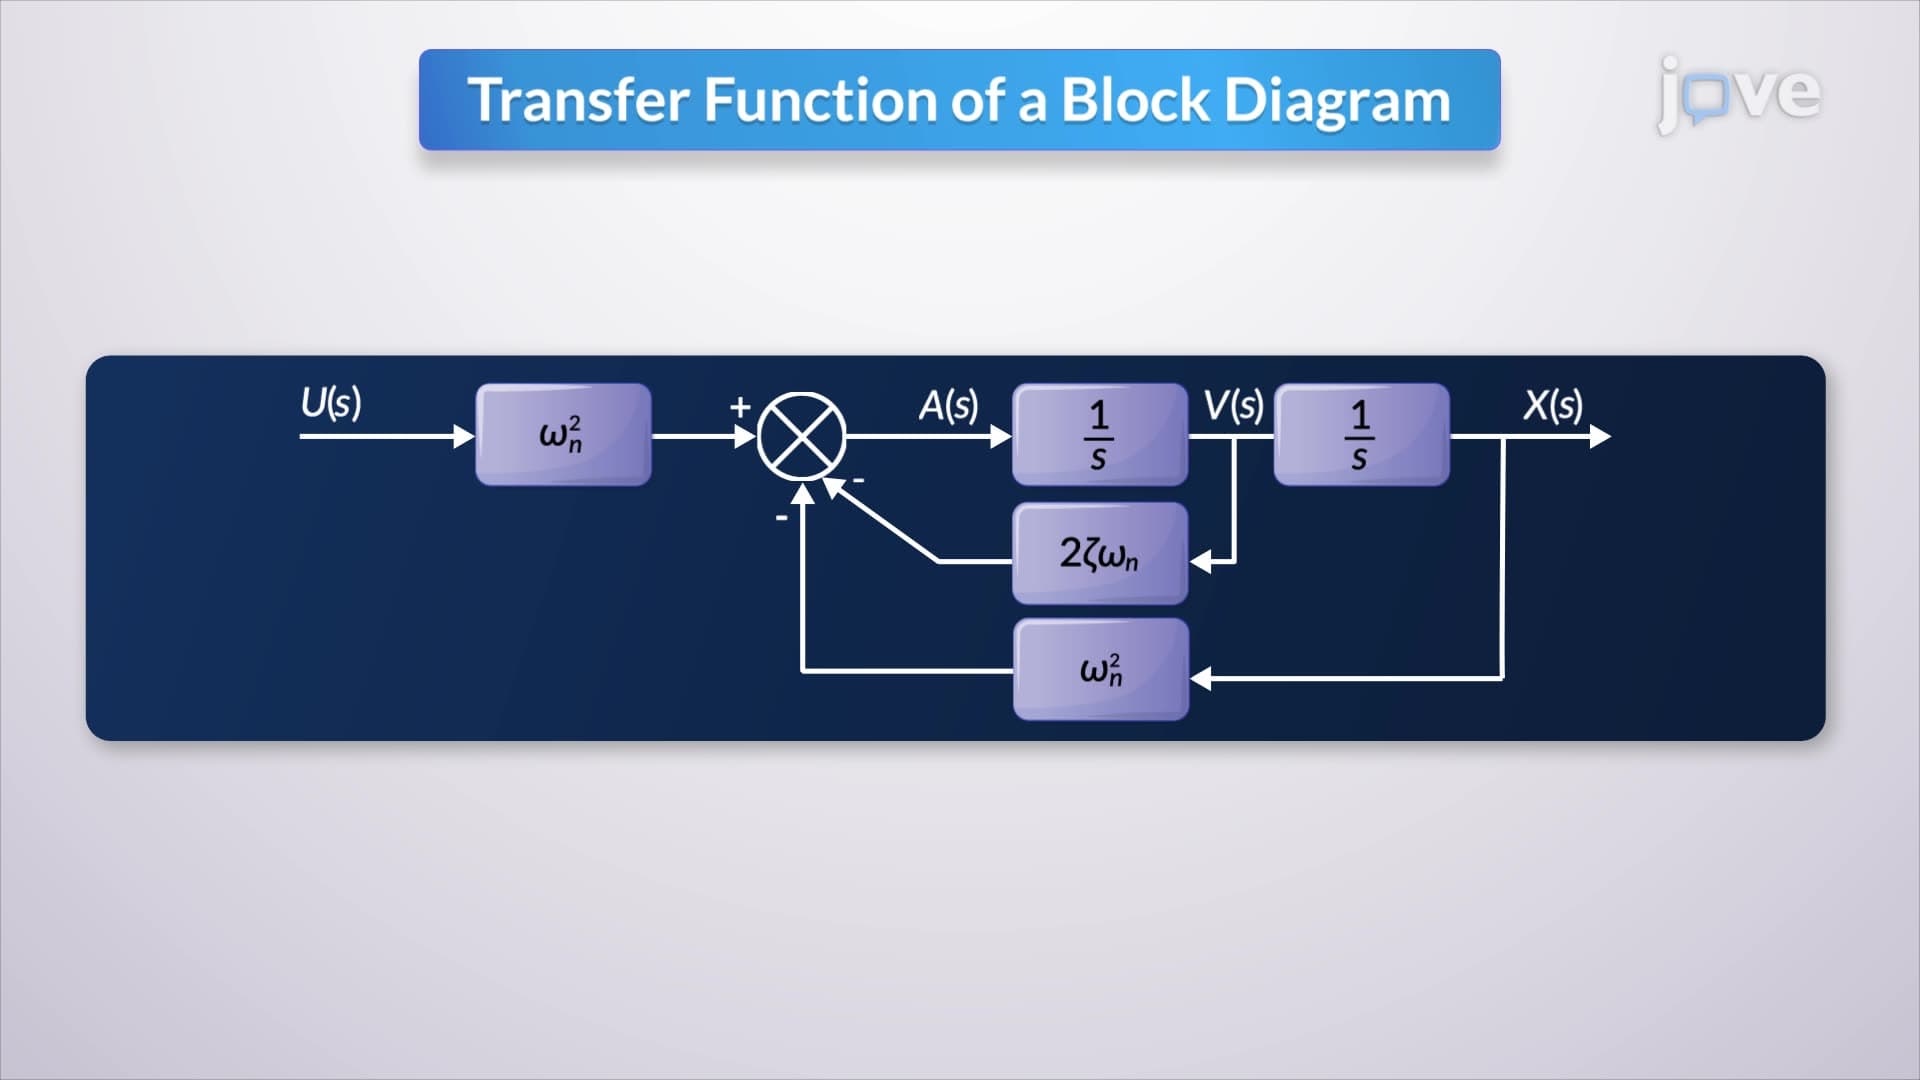 01:20
Relation between Mathematical Equations and Block Diagrams
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
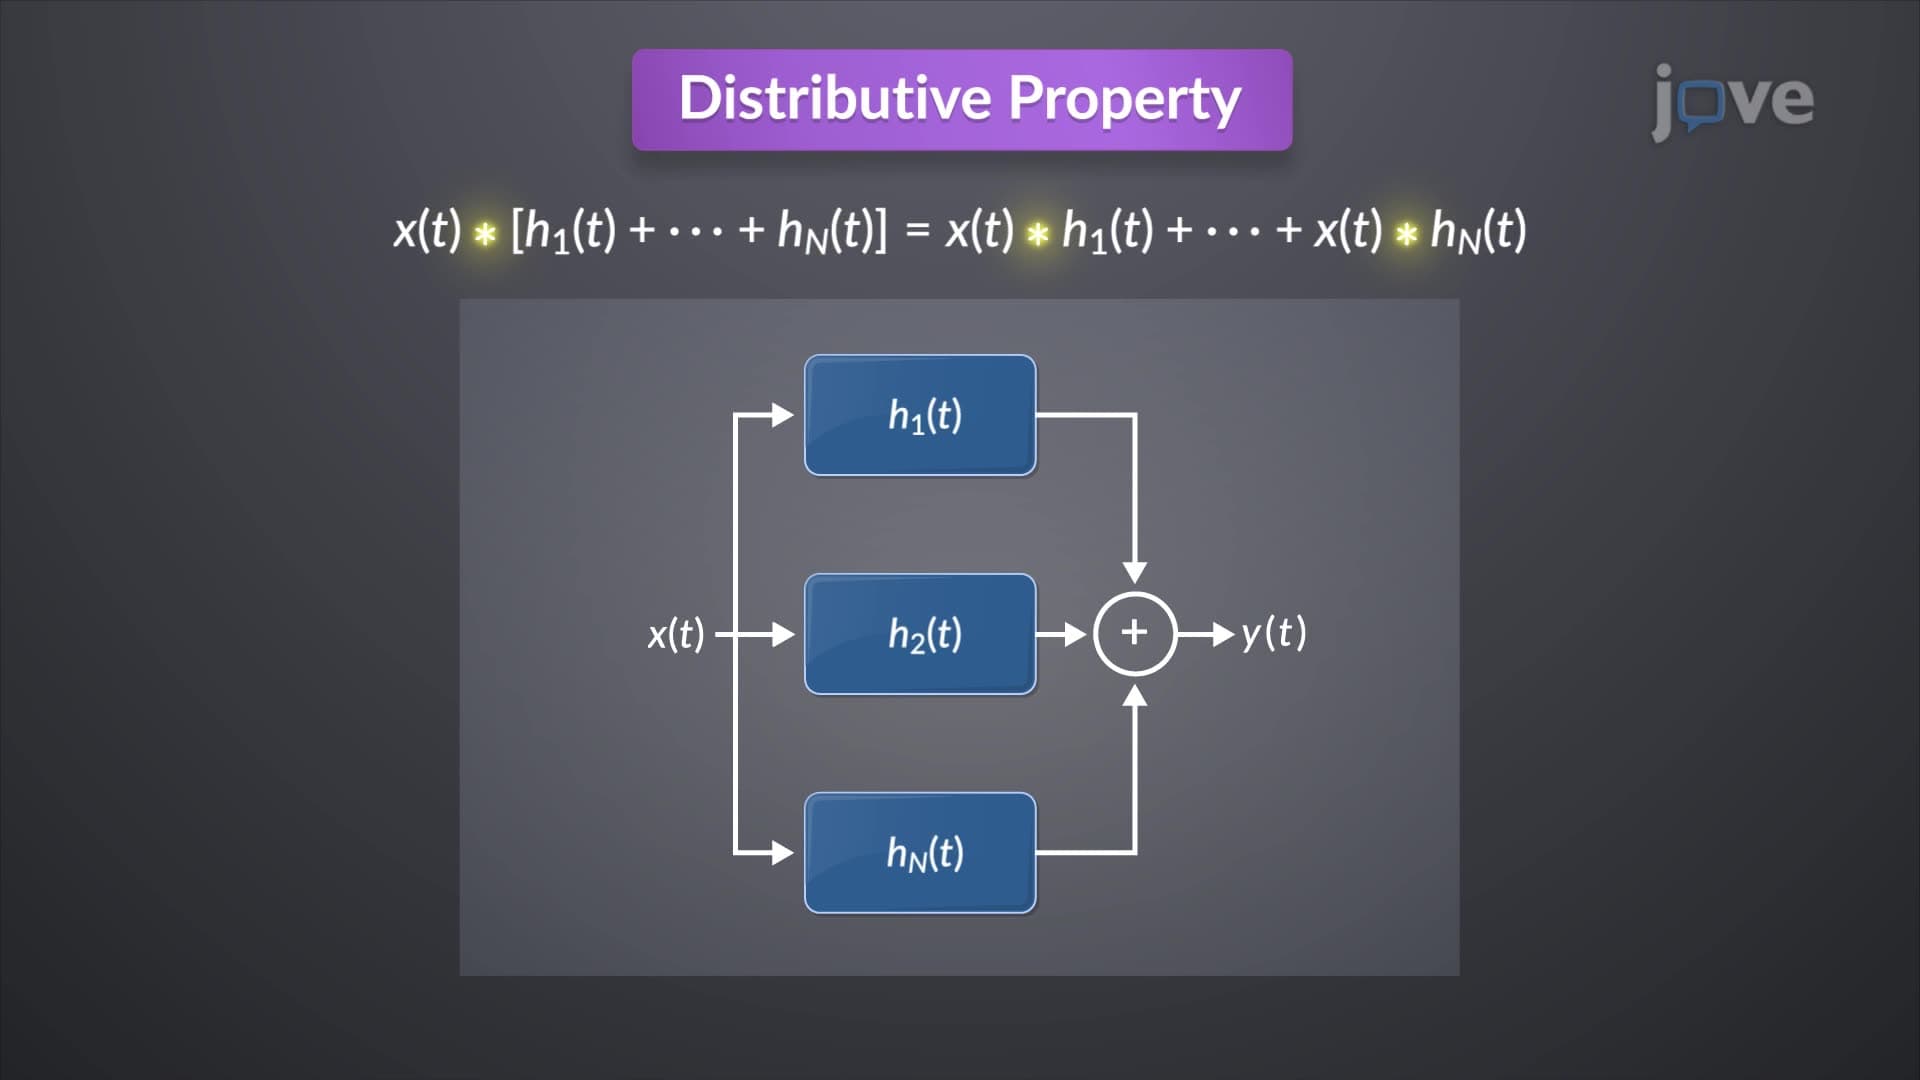 01:20
Convolution Properties I
The commutative property reveals that the input and the impulse response of an LTI (Linear Time-Invariant) system can be interchanged without affecting the output: